Related Experiment Video
Updated: Oct 9, 2026
A Finite Element Approach for Locating the Center of Resistance of Maxillary Teeth
Published on: April 8, 2020
Numerical Estimation of the Centres of Rotation and Resistance in Orthodontic Tooth Movement
1National Technical University of Athens, Department of Mechanical Engineering, 9 Heroes of Polytechnion, 157 73, Zografos Campus, Athens, Greece.

Abstract:
The position of the centre of resistance (Cre) as well as the centre of rotation (Cro) of a tooth under a force-system is still an open question. This paper presents a reliable and efficient three-dimensional rigid-body finite element technique to accurately estimate these centres. The influence of not only the root length but also the root diameter, the thickness of the periodontal ligament, as well as its material properties on the position of the Cre and Cro is investigated. Additionally, an explanation is given for the meaning of the coefficient (0.068 h(2) ) involved in Burstone's theoretical formula which is generalised and is expressed as the ratio of the flexibilities of tooth support in translation and pure moment rotation, respectively. The former ratio determines the position of the centres of rotation as a function of the applied moment-to-force ratio (M/F) and the relevant curve remains an isosceles hyperbola for any arbitrary-shaped tooth. The present study focuses on single-rooted teeth, such as maxillary canines and maxillary incisors, but the proposed methodology is generally applicable to any tooth.
Related Concept Videos
 01:30
Applications of Integration to Find Centers of Mass
 01:13
Angle of Twist: Problem Solving
 01:26
Rotational Motion about a Fixed Axis
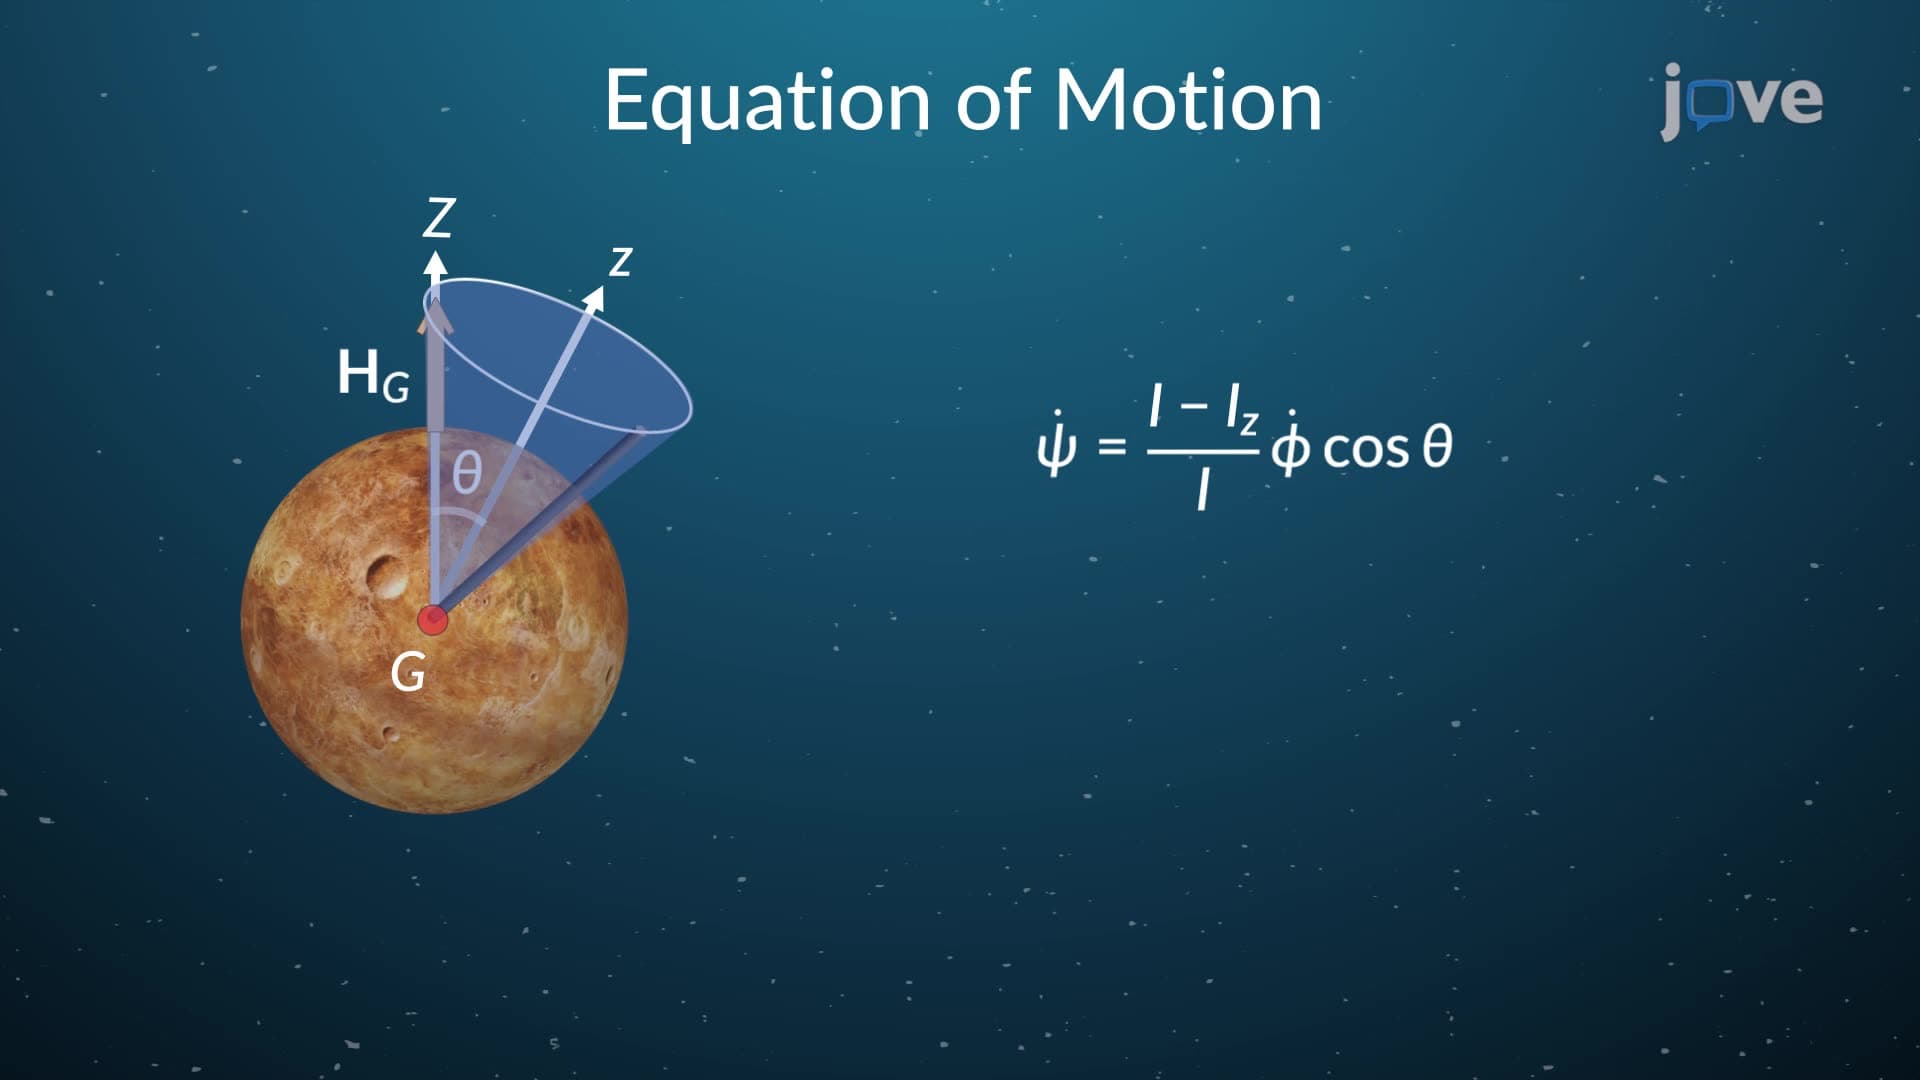 01:15
Torque Free Motion
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
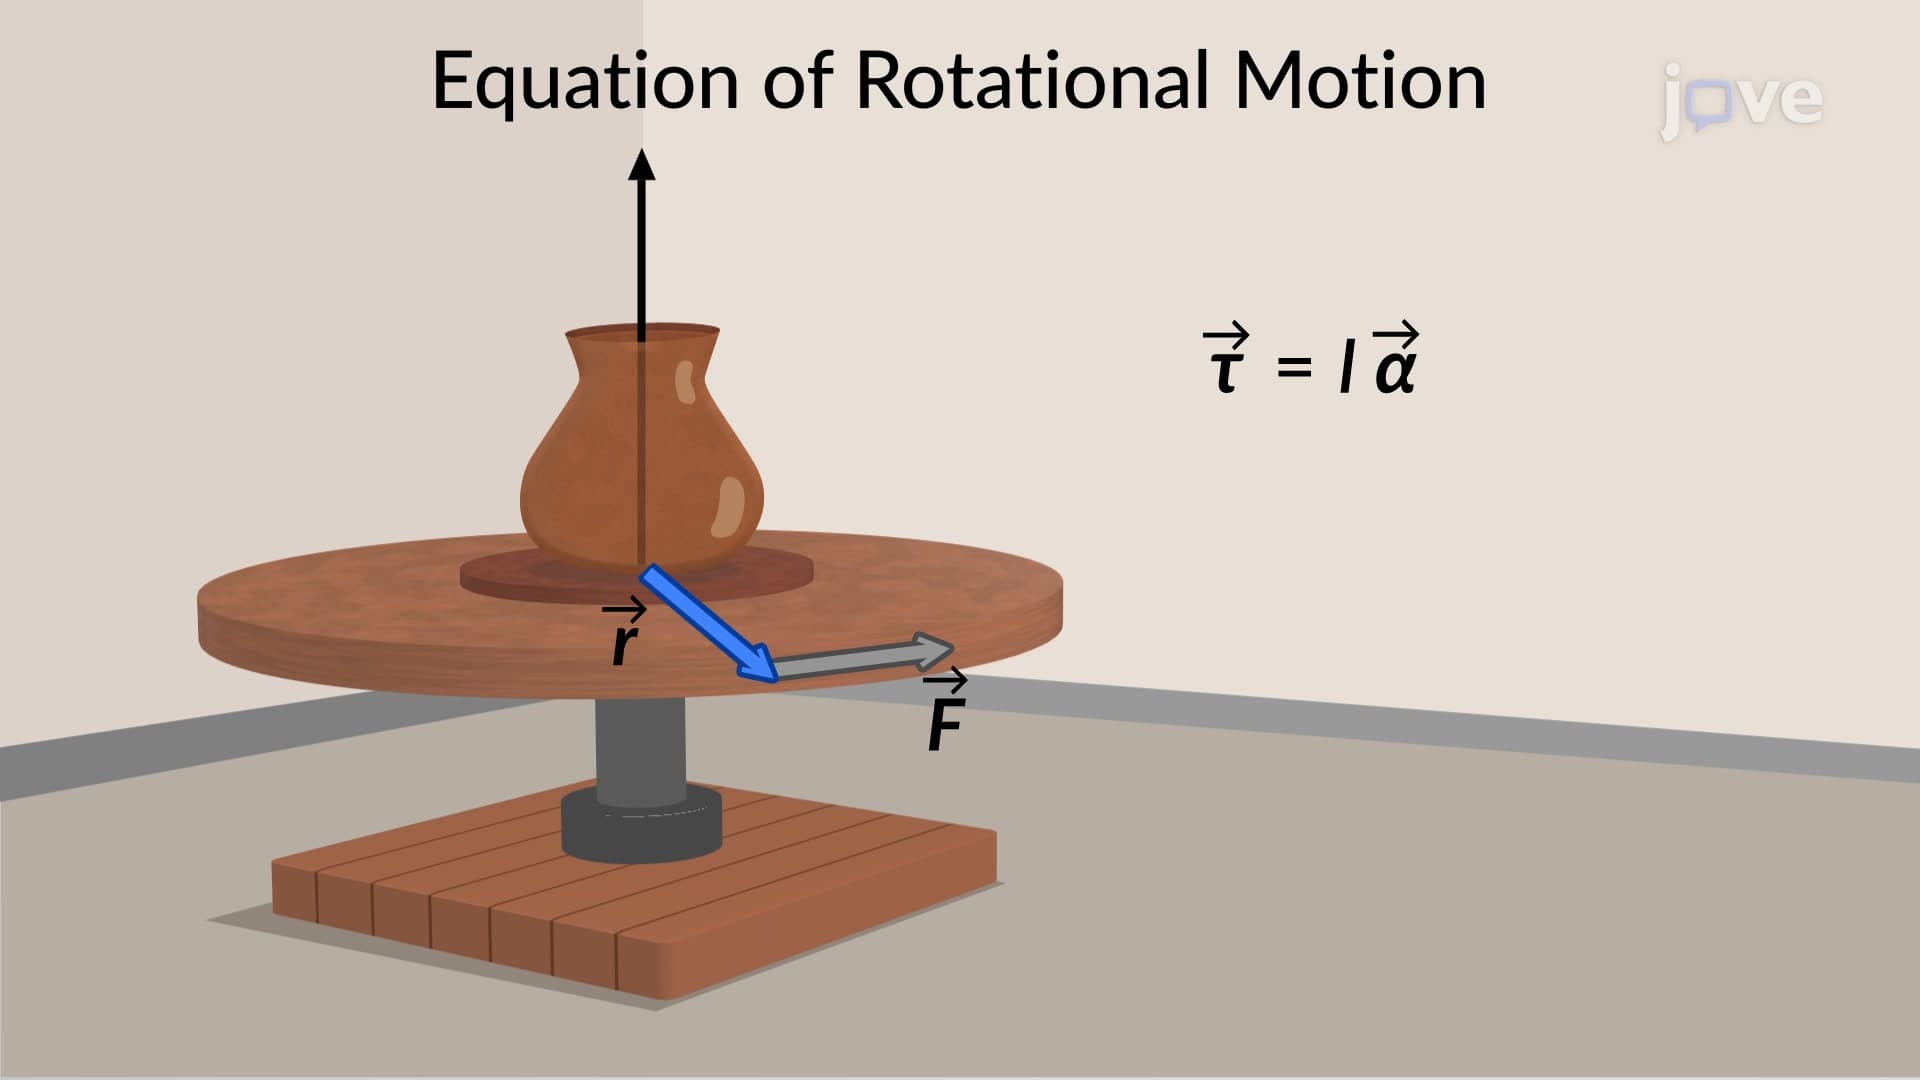 01:08
Equation of Rotational Dynamics