Attractor reconstruction for non-linear systems: a methodological note
Related Experiment Video
Updated: Oct 8, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
1Department of Mechanical Engineering, School of Engineering, Duke University, Durham, NC 27708-0330, USA. jmn@duke.edu

Abstract:
Attractor reconstruction is an important step in the process of making predictions for non-linear time-series and in the computation of certain invariant quantities used to characterize the dynamics of such series. The utility of computed predictions and invariant quantities is dependent on the accuracy of attractor reconstruction, which in turn is determined by the methods used in the reconstruction process. This paper suggests methods by which the delay and embedding dimension may be selected for a typical delay coordinate reconstruction. A comparison is drawn between the use of the autocorrelation function and mutual information in quantifying the delay. In addition, a false nearest neighbor (FNN) approach is used in minimizing the number of delay vectors needed. Results highlight the need for an accurate reconstruction in the computation of the Lyapunov spectrum and in prediction algorithms.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:22
Local Attraction
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
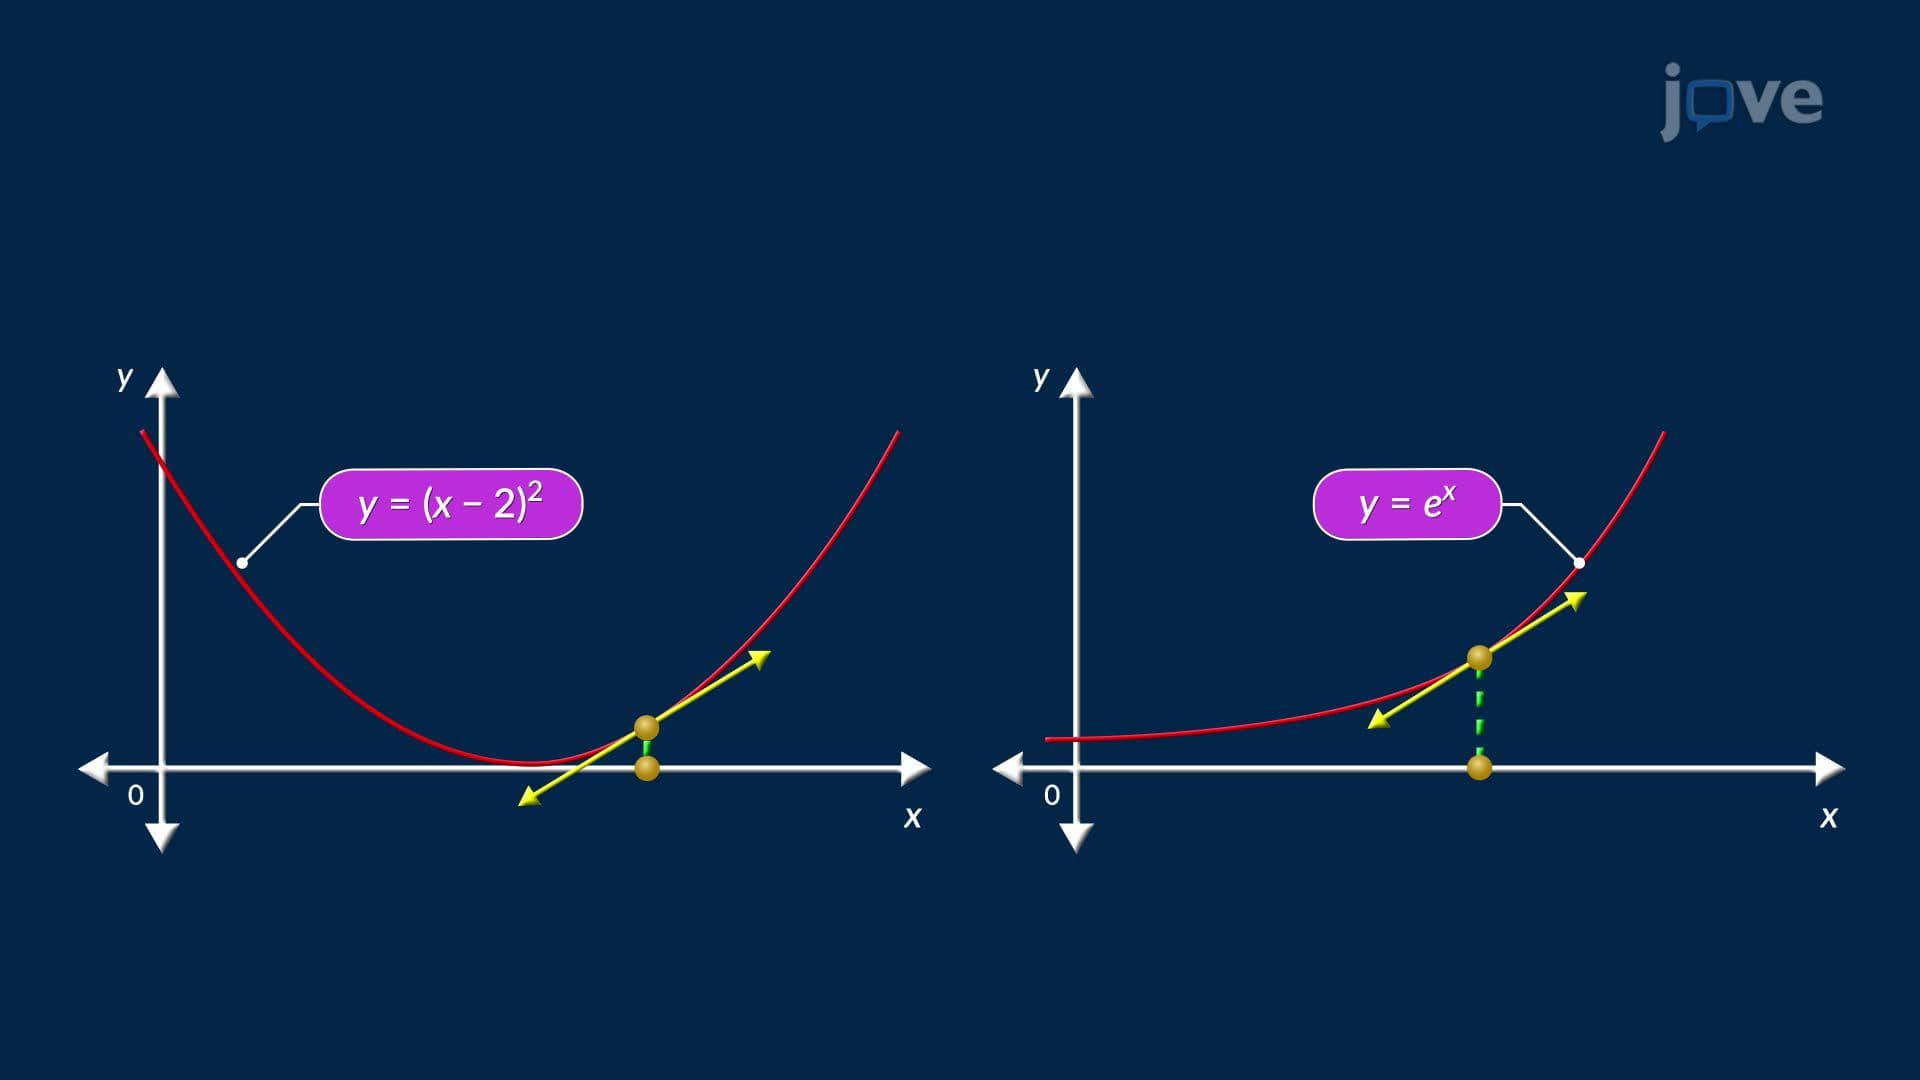
Linearization and Approximation
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as: