Related Experiment Video
Updated: Oct 7, 2026
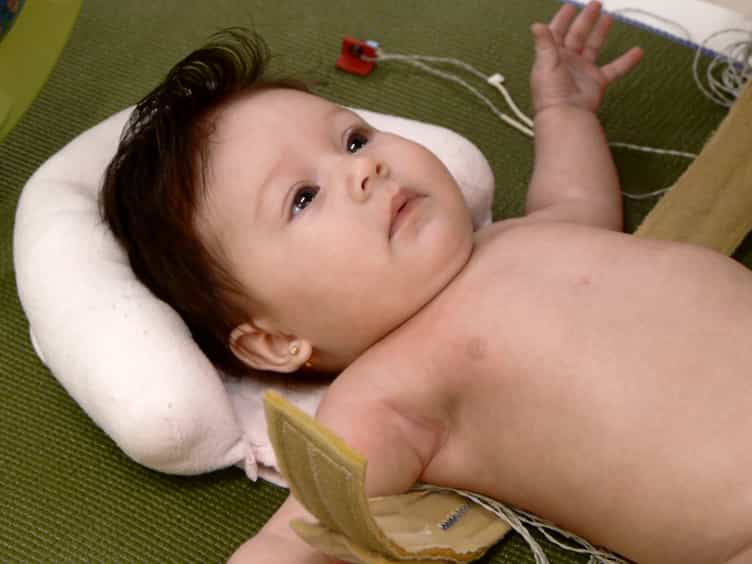
Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Development of a kinematic coordination pattern in toddler locomotion: planar covariation
1Laboratory of Movement Biomechanics, ISEPK, Université Libre de Bruxelles, Avenue P. Héger, CP168, Brussels 1050, Belgium. gcheron@ulb.ac.be

Insights
Children develop coordinated lower limb movements for walking quickly after starting, with early patterns reflecting balance and propulsion. This suggests central neural control guides early motor learning in locomotion.
Area of Science:
- Biomechanics
- Neuroscience
- Developmental Motor Control
Background:
- Human locomotion involves complex coordination of lower limb segments.
- Adult walking exhibits a planar covariation rule for joint angles.
- Understanding early motor development in children is crucial for identifying developmental trajectories.
Purpose of the Study:
- To analyze lower limb segment elevation angle coordination during early unsupported walking in children.
- To investigate the presence and characteristics of the planar covariation rule in developing human locomotion.
- To compare coordination patterns in children with those of adults.
Main Methods:
- Kinematic data of lower limb segments were recorded in children (11-144 months) and adults during walking.
- Orthogonal regression and principal component analysis were used to assess planar covariation.
- Trunk stability in frontal and sagittal planes was evaluated.
- Evolution of plane orientation and trunk oscillations with walking experience was analyzed.
Main Results:
- Children demonstrated a biexponential progression in plane orientation and trunk stability with walking experience, with rapid initial changes (< 6 months) followed by slower maturation.
- Early coordination patterns in children correlated with trunk vertical stability, indicating integration of balance and propulsion.
- The development of planar covariation was faster than anthropometric changes, suggesting neural adaptation.
Conclusions:
- The planar covariation rule emerges early in unsupported walking, reflecting coordinated, centrally controlled behavior beyond simple biomechanical constraints.
- Refinement of planar covariation during growth implies continuous neural command updates to adapt to changing morphology.
- Early integration of postural equilibrium and forward propulsion is key in developing human locomotion.
Abstract:
The purpose of this study is to analyze the coordination patterns of the elevation angles of lower limb segments following the onset of unsupported walking in children and to look for the existence of a planar covariation rule as previously described in adult human locomotion. The kinematic patterns of locomotion were recorded in 21 children (11-144 months of age) and 19 adults. In 4 children we monitored the very first unsupported steps. The extent to which the covariation of thigh, shank, and foot angles was constrained on a plane in 3D space was assessed by means of orthogonal regression and statistically quantified by means of principal component analysis. The orientation of the covariation plane of the children was compared with the mean value of the adults' plane. Trunk stability with respect to the vertical was assessed in both the frontal (roll) and sagittal (pitch) planes. The evolution with walking experience of the plane orientation and trunk oscillations demonstrated biexponential profiles with a relatively fast time constant (< 6 months after the onset of unsupported locomotion) followed by a much slower progression toward adult values. The initial fast changes of these walking parameters did not parallel the slow, monotonic maturation of anthropometric parameters. The early emergence of the covariation plane orientation and its correlation with trunk vertical stability reflect the dynamic integration of postural equilibrium and forward propulsion in a gravity-centered frame. The results support the view that the planar covariation reflects a coordinated, centrally controlled behavior, in addition to biomechanical constraints. The refinement of the planar covariation while morphological variables drastically change as the child grows implies a continuous update of the neural command.
Related Concept Videos
 01:29
Locomotion During Infancy and Toddlerhood
 01:15
Kinematic Equations: Problem Solving
 01:05
Development of Head Control During Infancy
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...