Related Experiment Video
Updated: Aug 13, 2026

A Method for Tracking the Time Evolution of Steady-State Evoked Potentials
Published on: May 25, 2019
Positive Lyapunov exponents calculated from time series of strange nonchaotic attractors
1Department of Biomedical Engineering, Case Western Reserve University, Cleveland, Ohio 44106, USA. shuai@helios.phy.ohiou.edu

Abstract:
Time-series methods for estimating Lyapunov exponents may give a positive exponent when they are applied to the time series of strange nonchaotic systems. Strange nonchaotic systems are characterized by expanding and contracting regions in phase space that result in repeatedly expanding or contracting trajectories. Using time-series methods, the maximum time-series Lyapunov exponent is calculated as an average of the locally most expanding exponents that characterize the divergence of nearby trajectories following a reconstructed attractor over time. A positive exponent is reported by time-series methods for trajectories in an expanding region. While in a converging region, the most expanding dynamics are related to the quasiperiodic driving force. Statistically, a zero exponent related to the quasiperiodic force is obtained through time-series methods within converging regions. As a result, the calculated maximum Lyapunov exponent is positive.


Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:24
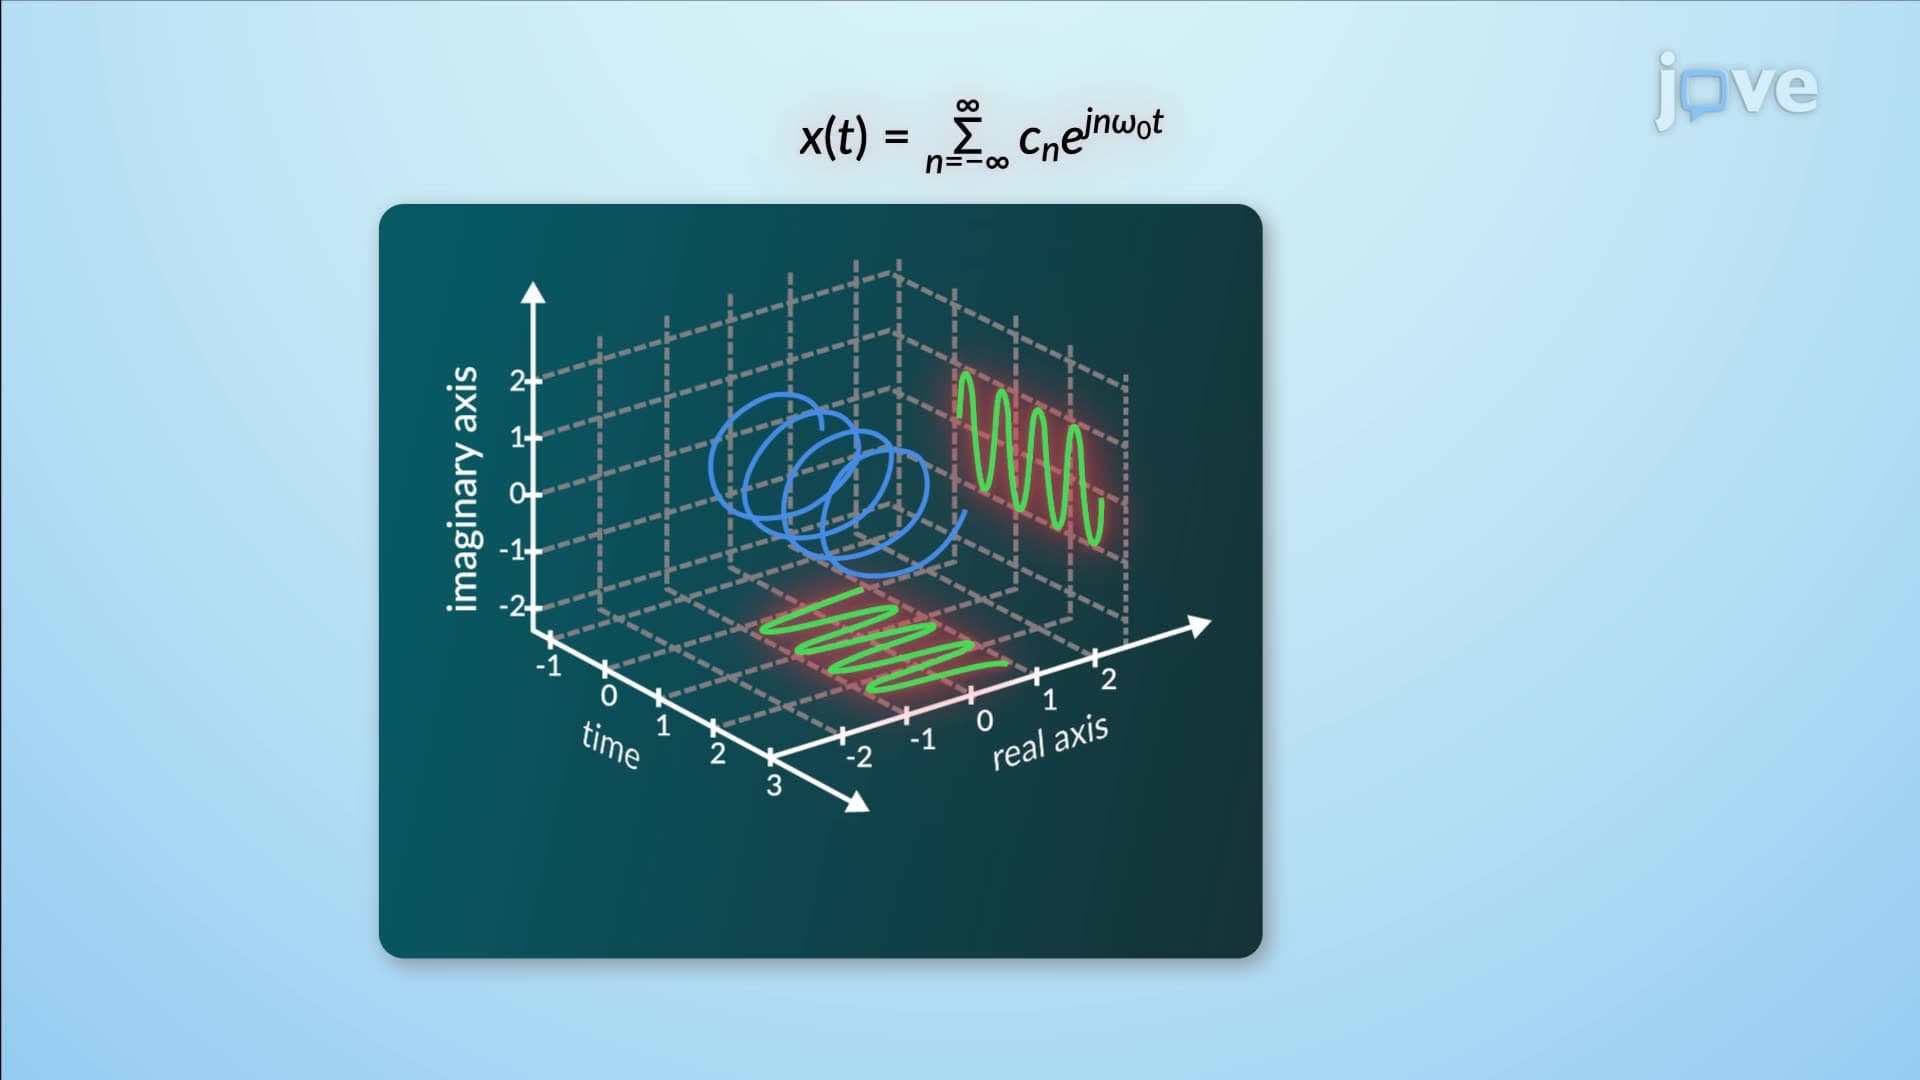
Exponential Fourier series
Euler's identity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:28
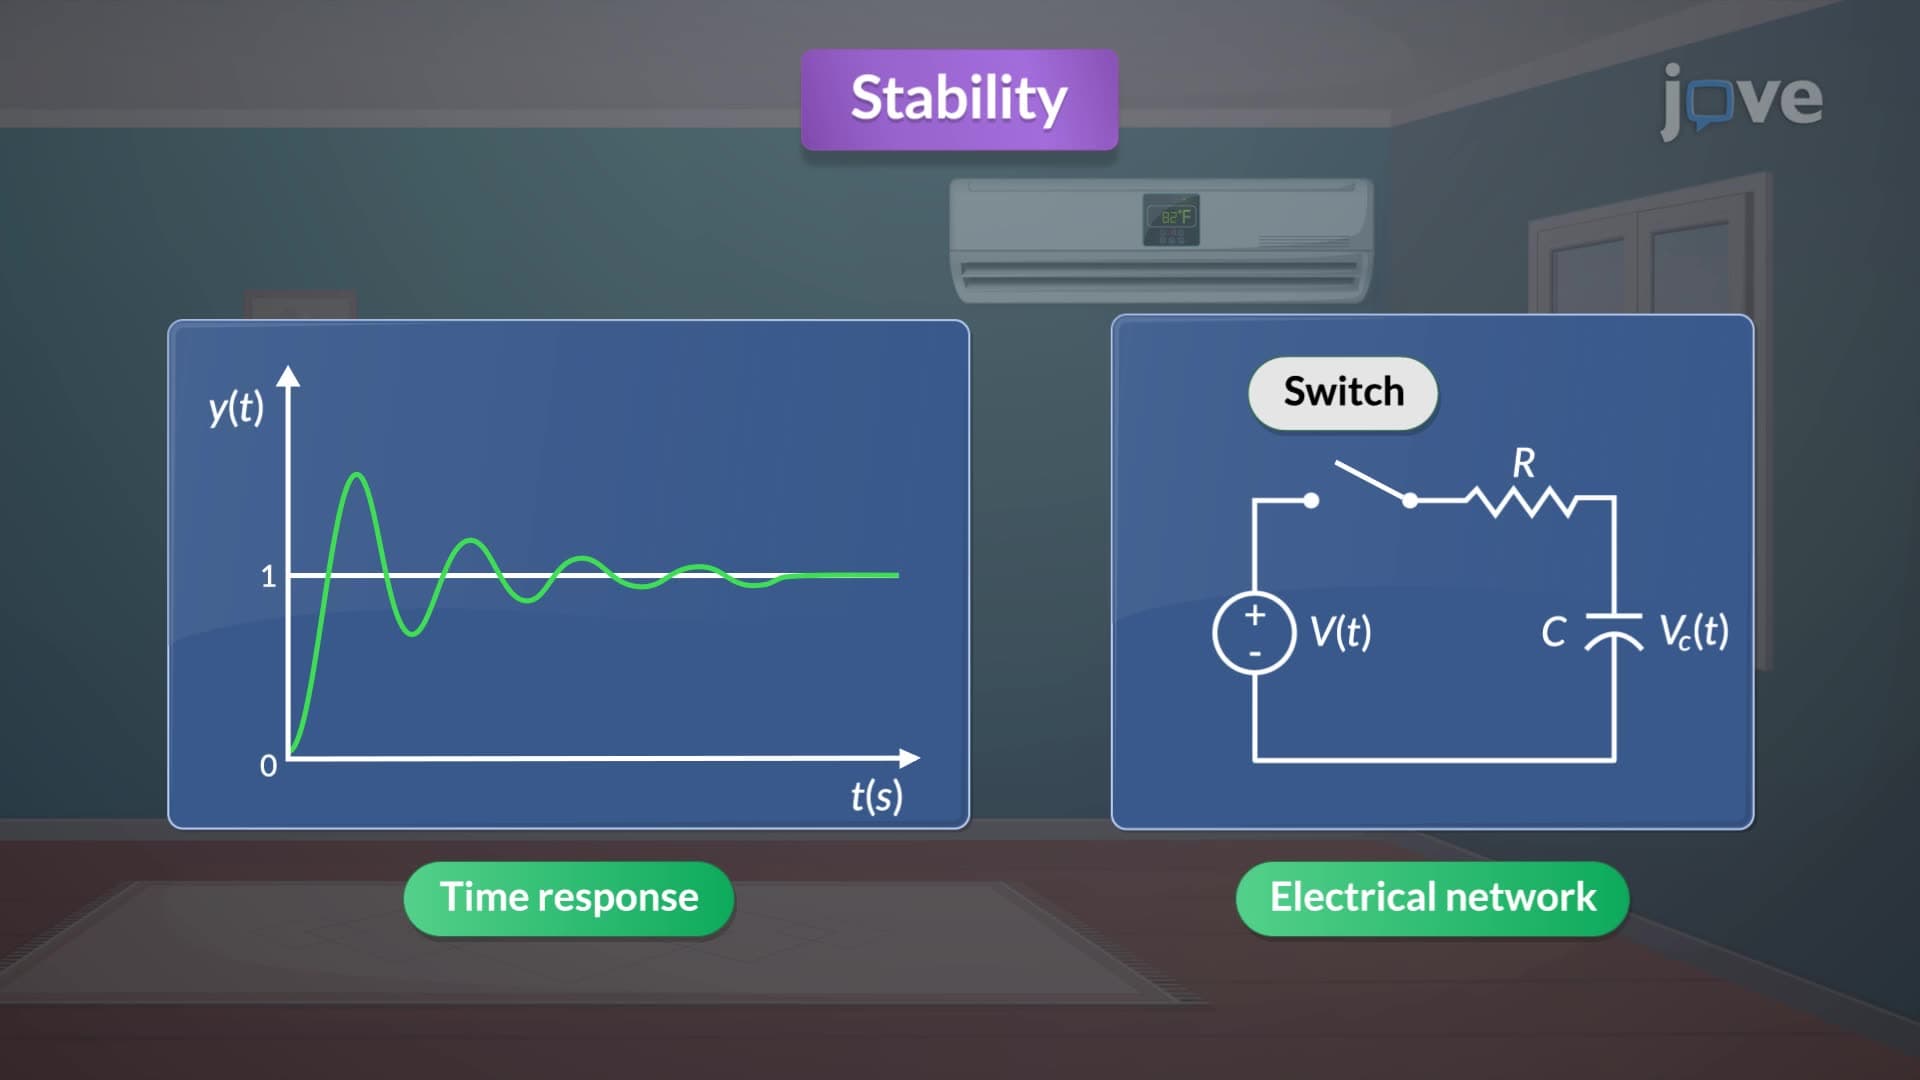
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:23
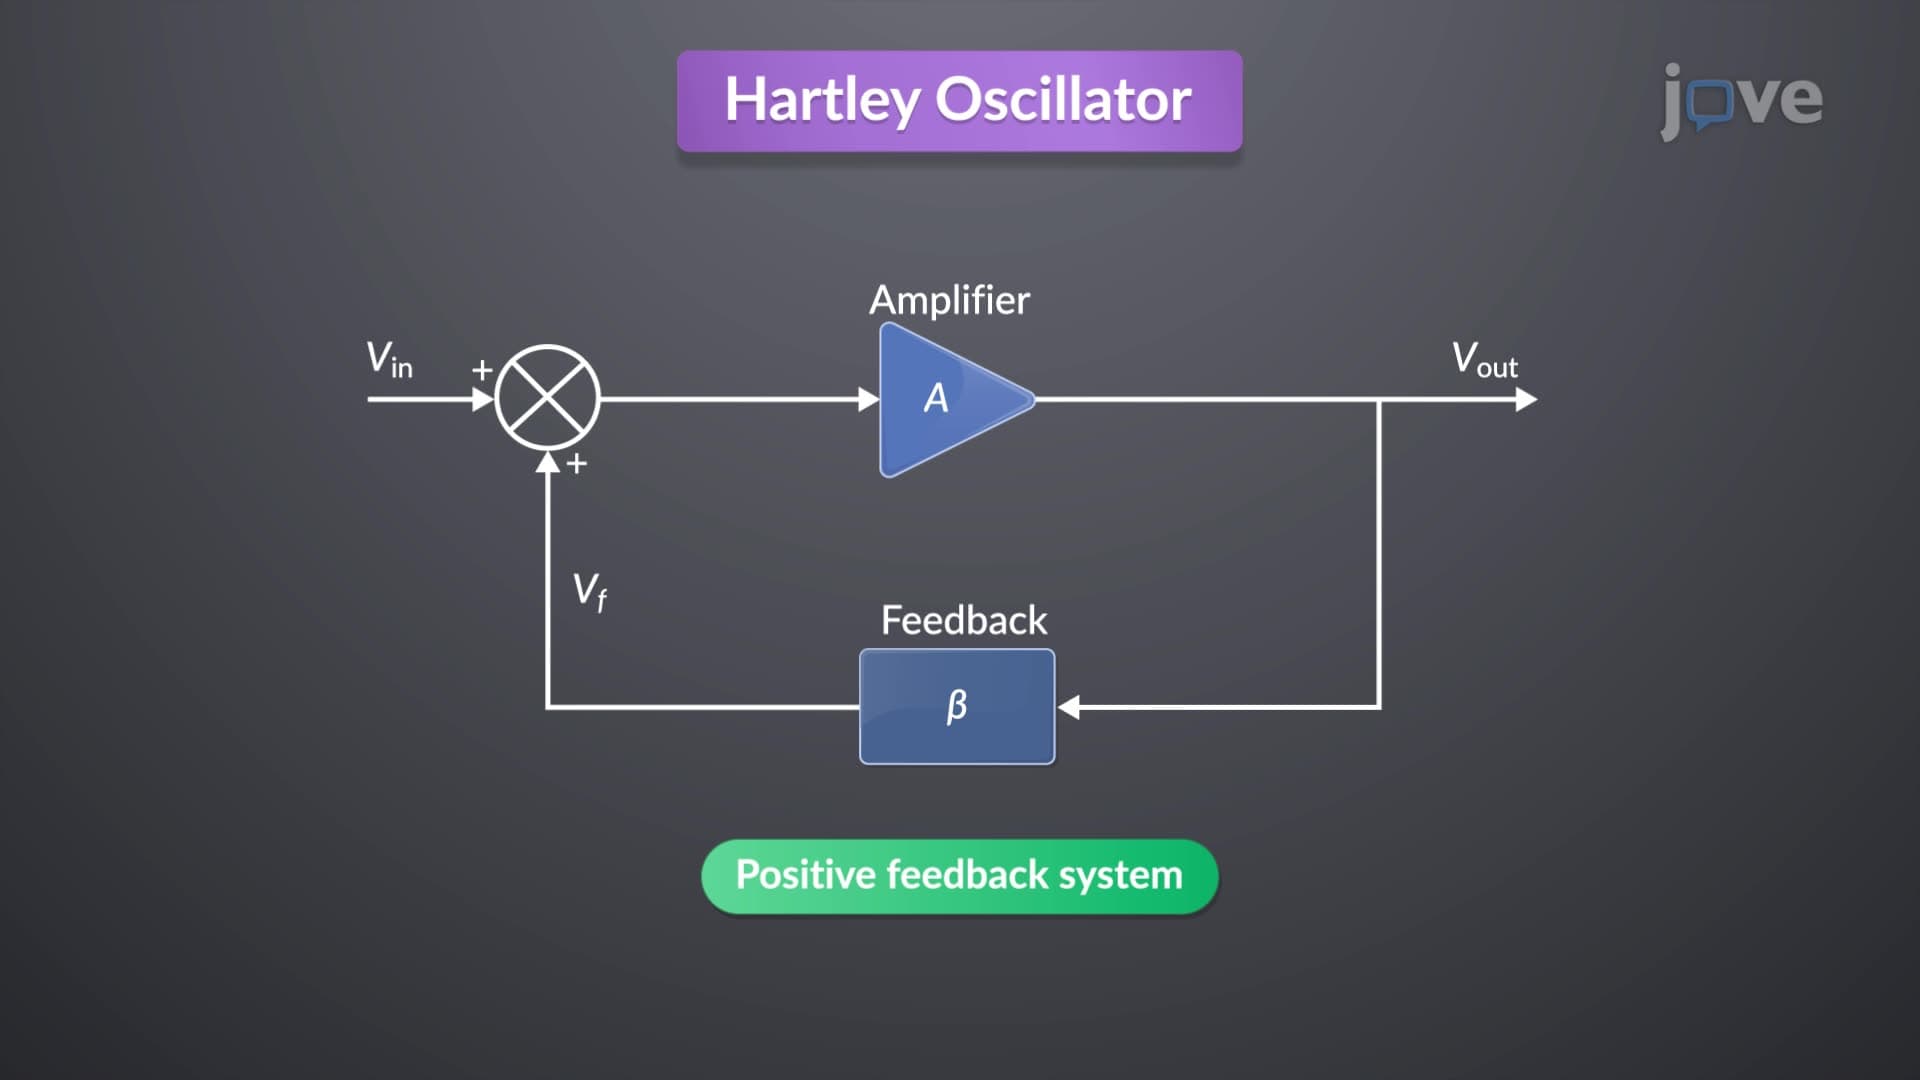
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...