VLSI processors for signal detection in SETI
Related Experiment Video
Updated: Oct 4, 2026
Characterization of SiN Integrated Optical Phased Arrays on a Wafer-Scale Test Station
Published on: April 1, 2020
J F Duluk1, I R Linscott, A M Peterson
1Department of Electrical Engineering, Stanford University, CA 94305-4055.

Abstract:
The objective of the Search for Extraterrestrial Intelligence (SETI) is to locate an artificially created signal coming from a distant star. This is done in two steps: (1) spectral analysis of an incoming radio frequency band, and (2) pattern detection for narrow-band signals. Both steps are computationally expensive and require the development of specially designed computer architectures. To reduce the size and cost of the SETI signal detection machine, two custom VLSI chips are under development. The first chip, the SETI DSP Engine, is used in the spectrum analyzer and is specially designed to compute Discrete Fourier Transforms (DFTs). It is a high-speed arithmetic processor that has two adders, one multiplier-accumulator, and three four-port memories. The second chip is a new type of Content-Addressable Memory. It is the heart of an associative processor that is used for pattern detection. Both chips incorporate many innovative circuits and architectural features.
Related Concept Videos
 01:41
Signal Sequences and Sorting Receptors
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:17
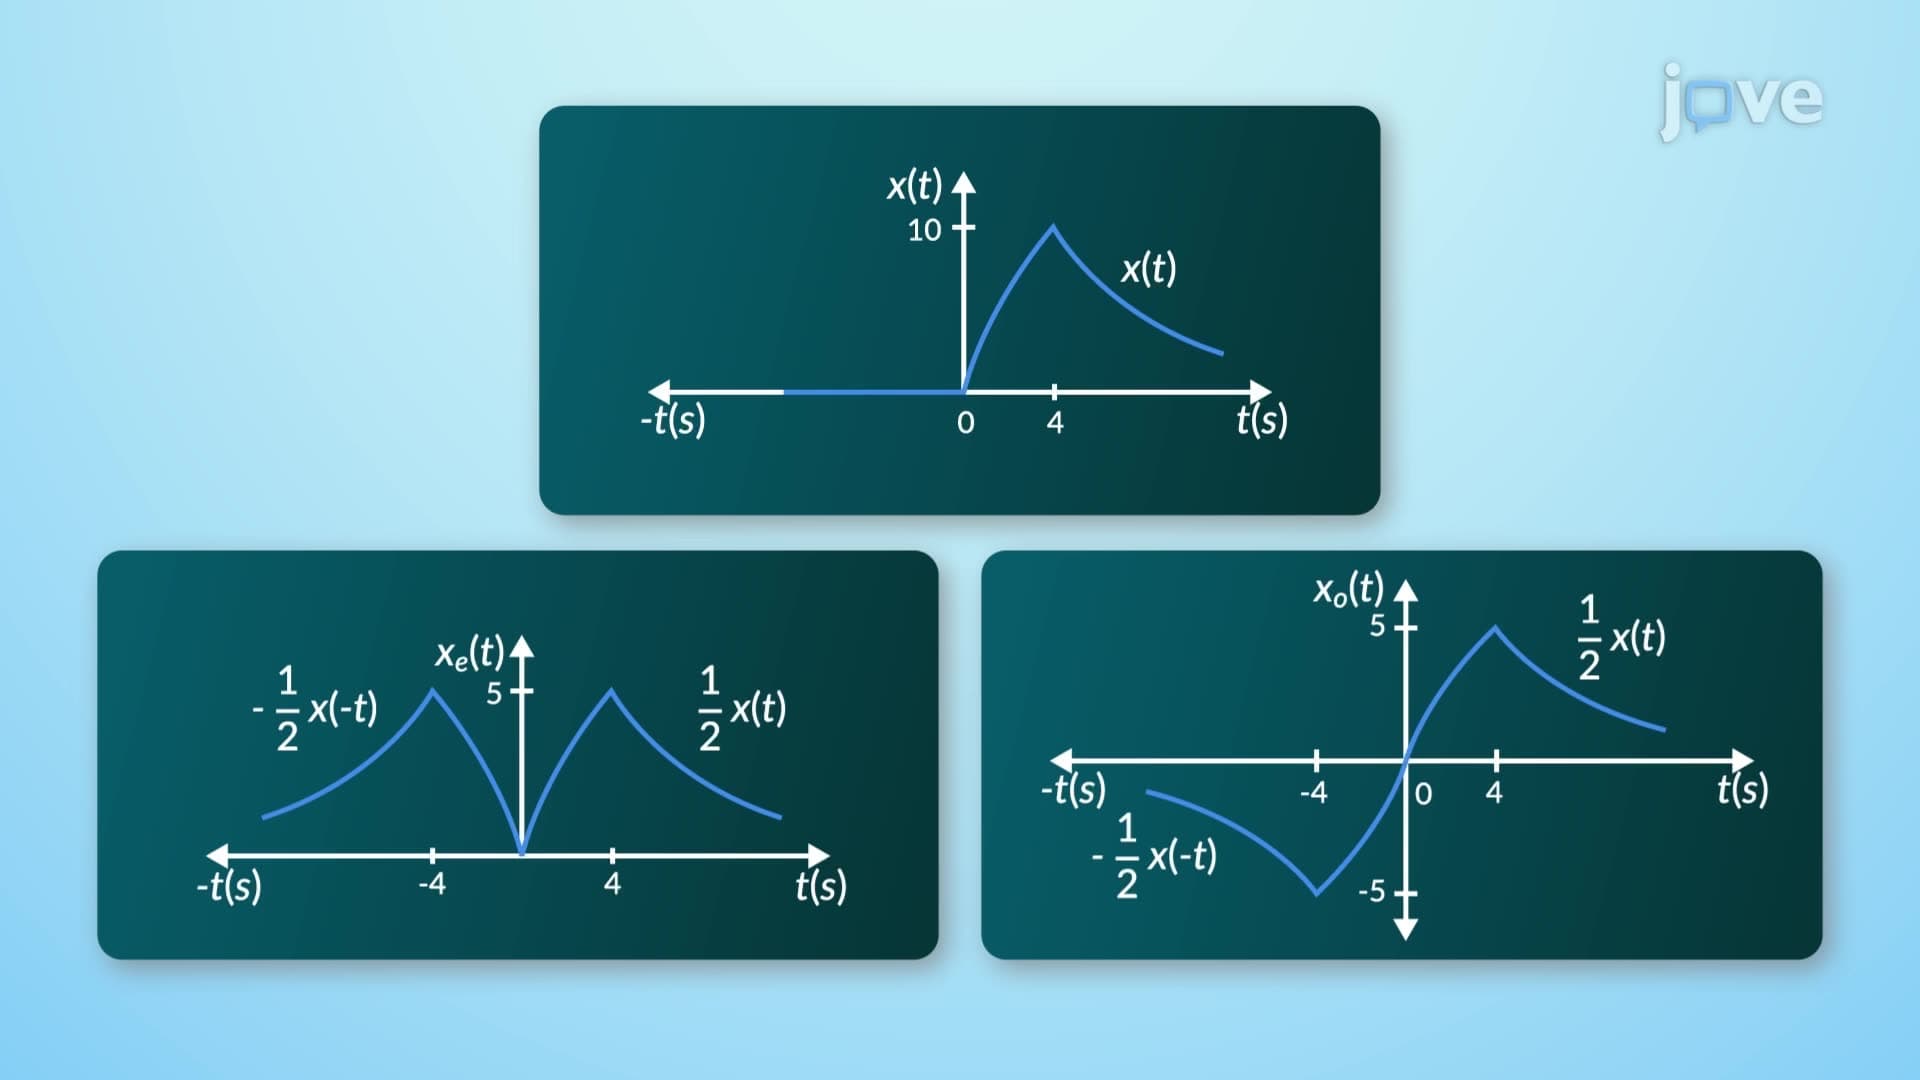
Even and Odd Signals
 01:26
Signal and System