Related Experiment Video
Updated: Oct 4, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Design of a neurofuzzy controller with simplified architecture
M E Bordon1, I N da Silva, E Avolio
1Department of Electrical Engineering, State University of São Paulo, Bauru, São Paulo 17033-360, Brazil. mebordon@bauru.unesp.br

Abstract:
This work presents the design of a neurofuzzy controller with simplified architecture that minimizes the processing time used in several stages associated with systems and processes modelling. The basic procedures of fuzzification and defuzzification are very simplified, whereas the inference procedures are computed in a direct way. The simplified architecture has allowed a fast and easy configuration of the neurofuzzy controller, as consequence, the control rules that define the control actions are obtained automatically. To validate the proposed approach, this neurofuzzy system is used in an industrial application for fluid flow control.

Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
PI Controller: Design
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
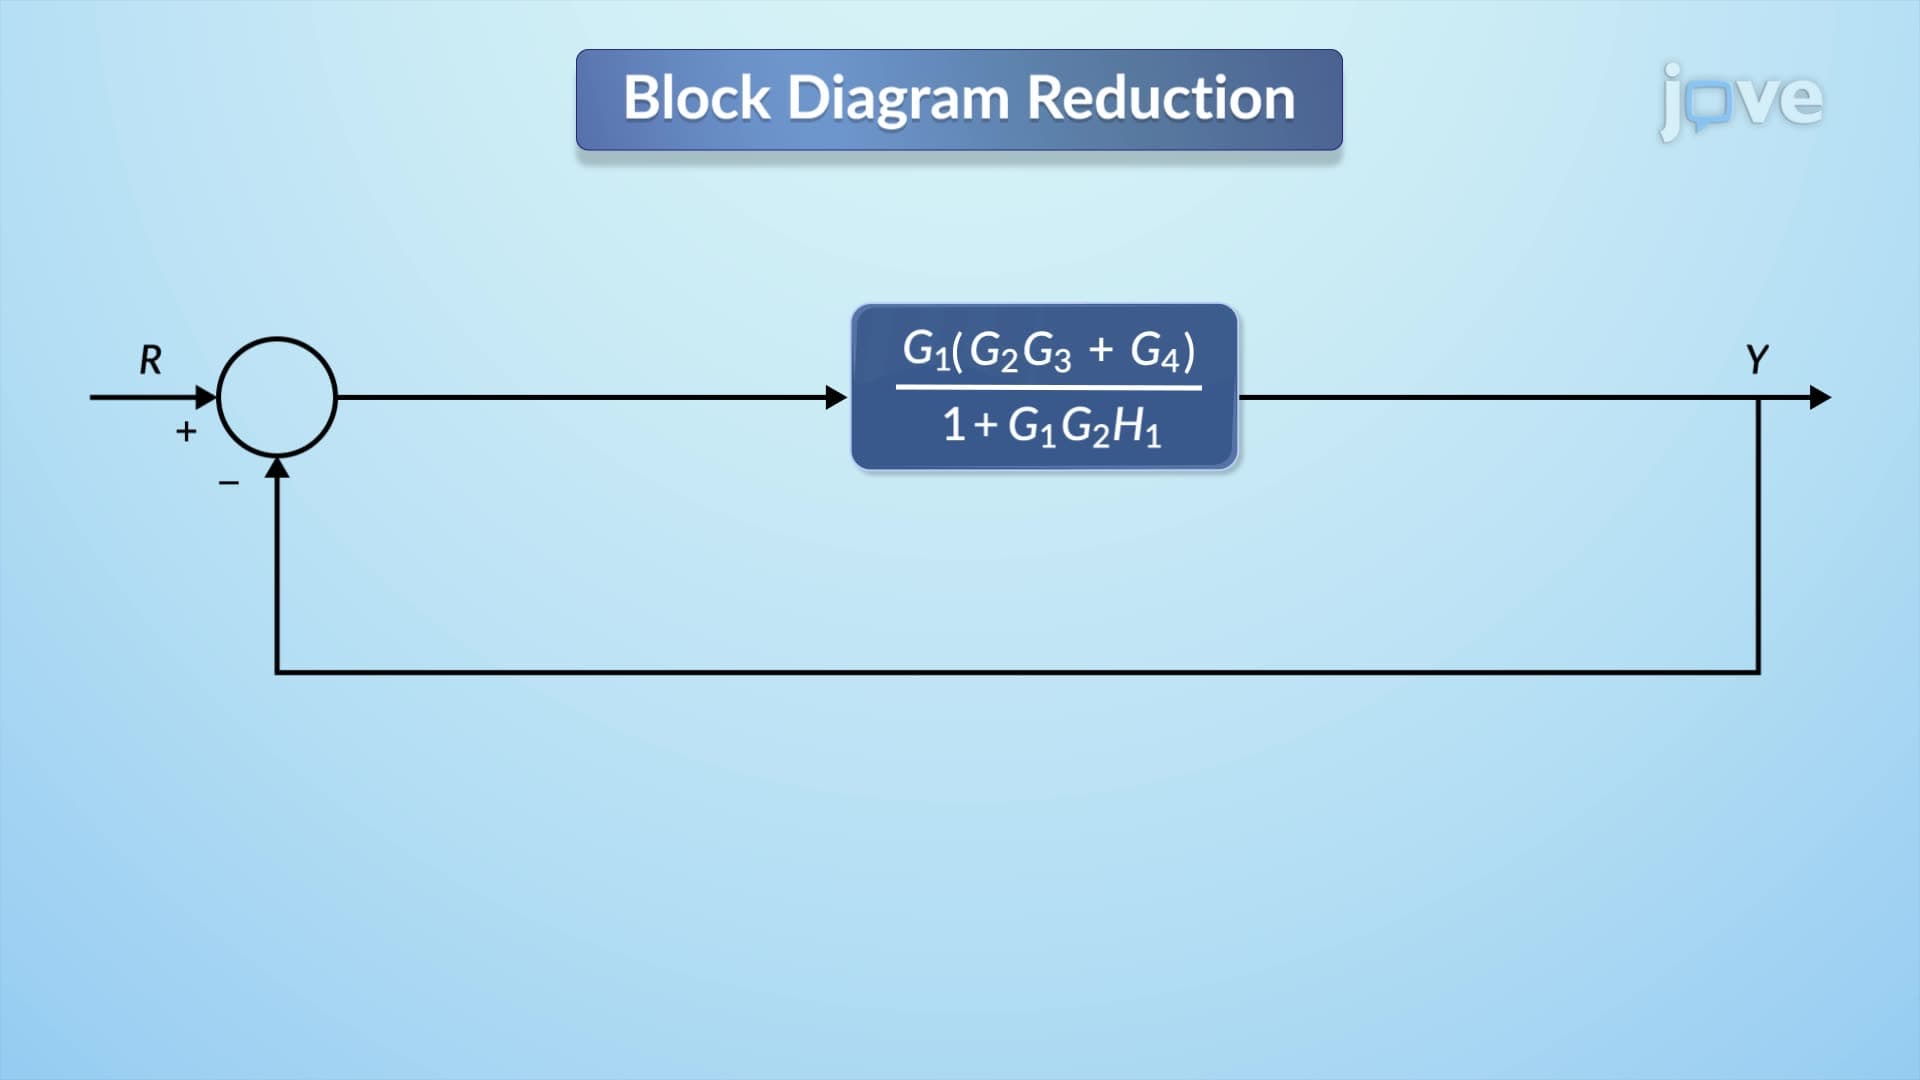 01:22
Block Diagram Reduction
The first step in this process is the identification and relocation of a branch point. A branch point, where a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...