Signals from skin mechanoreceptors used in control of a hand grasp neuroprosthesis
Related Experiment Video
Updated: Oct 4, 2026
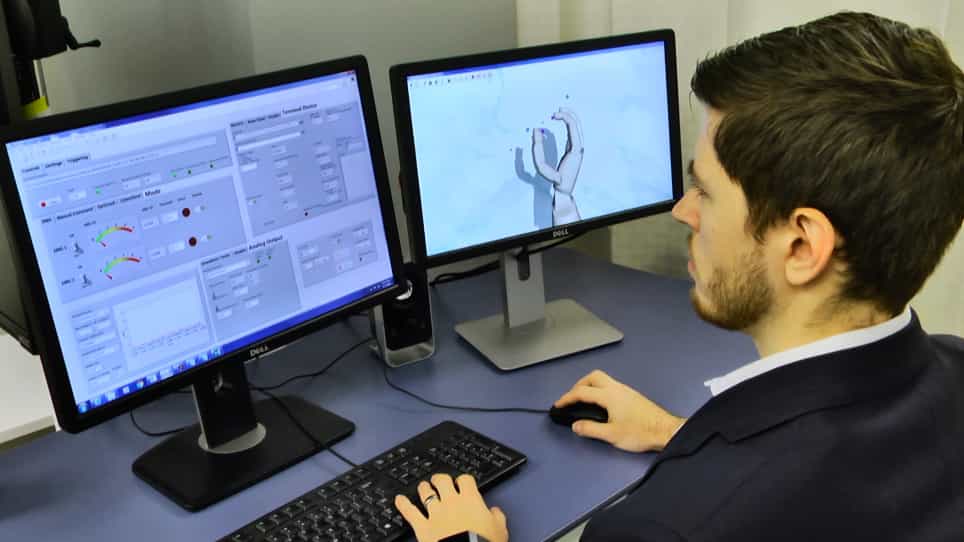
Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
A Inmann1, M Haugland, J Haase
1Center for Sensory-Motor Interaction, Aalborg University [corrected], Fredrik Bajers Vej 7 D-3, DK-9220 Aalborg, Denmark.

Abstract:
We used signals from tactile mechanoreceptors in the skin of the index finger, recorded with an implanted cuff electrode, to automatically control grasp force in a hand grasp neuroprosthesis. Phasic events in the recorded nerve signal, related to mechanical events on the skin, were used to adjust electrical stimulation of hand muscles without any prior knowledge about muscle strength and properties of a held object. A simulated eating task was used to evaluate the hand grasp neuroprosthesis. When using the neuroprosthesis with feedback from natural sensors, the average grasp force could be reduced in comparison to not using feedback. Reducing grasp force is considered a major factor to decrease muscle fatigue, allowing a prolonged use of the hand grasp neuroprosthesis.
Related Concept Videos
 01:16
Sensory Functions of the Skin
There are two main categories of receptors on the skin: capsulated and non-capsulated. The non-capsulated ones are mainly the pain receptors. The capsulated ones can be further categorized based on the...
 01:33
Somatosensation