A modeling study of potential sources of curvature in human reaching movements
Related Experiment Video
Updated: Oct 3, 2026
Assessing Corticospinal Excitability During Goal-Directed Reaching Behavior
Published on: December 2, 2022
D Micci Barreca1, F H Guenther
1Department of Cognitive and Neural Systems, Boston University, 677 Beacon Street, Boston, MA 02215, USA.

Abstract:
The authors of this article suggest that the slight but consistent posture-dependent curvature of the spatial paths in the kinematic transformation between intrinsic and extrinsic coordinates may result in a systematic curvature of movements initially planned as straight-line trajectories toward the target. A kinematic planning model is presented that takes into account the anisotropy of the intrinsic and extrinsic transformation and tends to avoid movements that require excessive joint rotations by introducing slight deviations from a straight-line trajectory. Preliminary simulations showed reasonably good agreement with experimental data, especially considering that the current model is strictly based on kinematics. A quantitative analysis showed that the strategy used in the model achieves a favorable compromise between straight-line movements and angular joint changes: By slightly increasing the spatial length of the movement (i.e., by introducing curvature), an individual can greatly reduce the total amount of joint rotation required to produce the movement.
Related Concept Videos
 01:25
Curvature and Its Interpretation
 01:14
Bending of Curved Members - Strain Analysis
The important part of bending analysis for such a member is the...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:19
Degree of Curvature and Radius of Curvature
 01:27
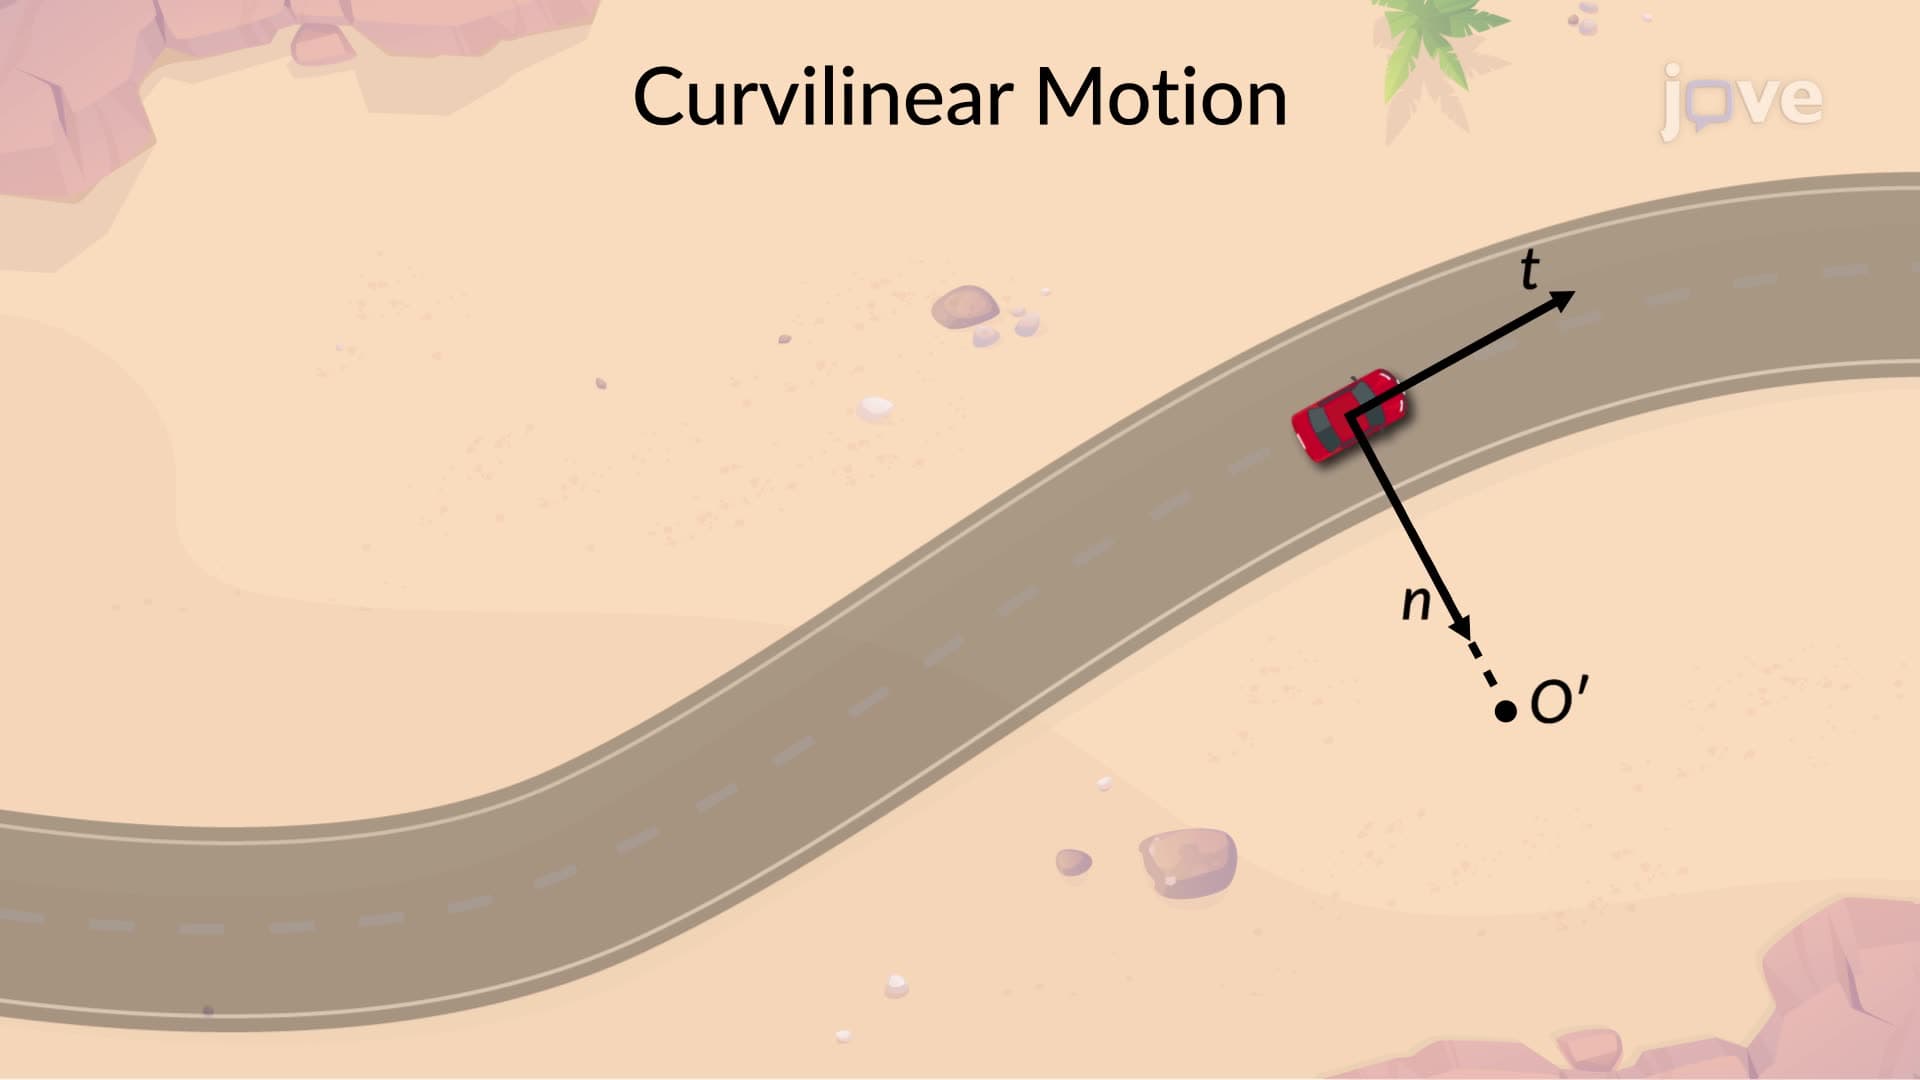
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
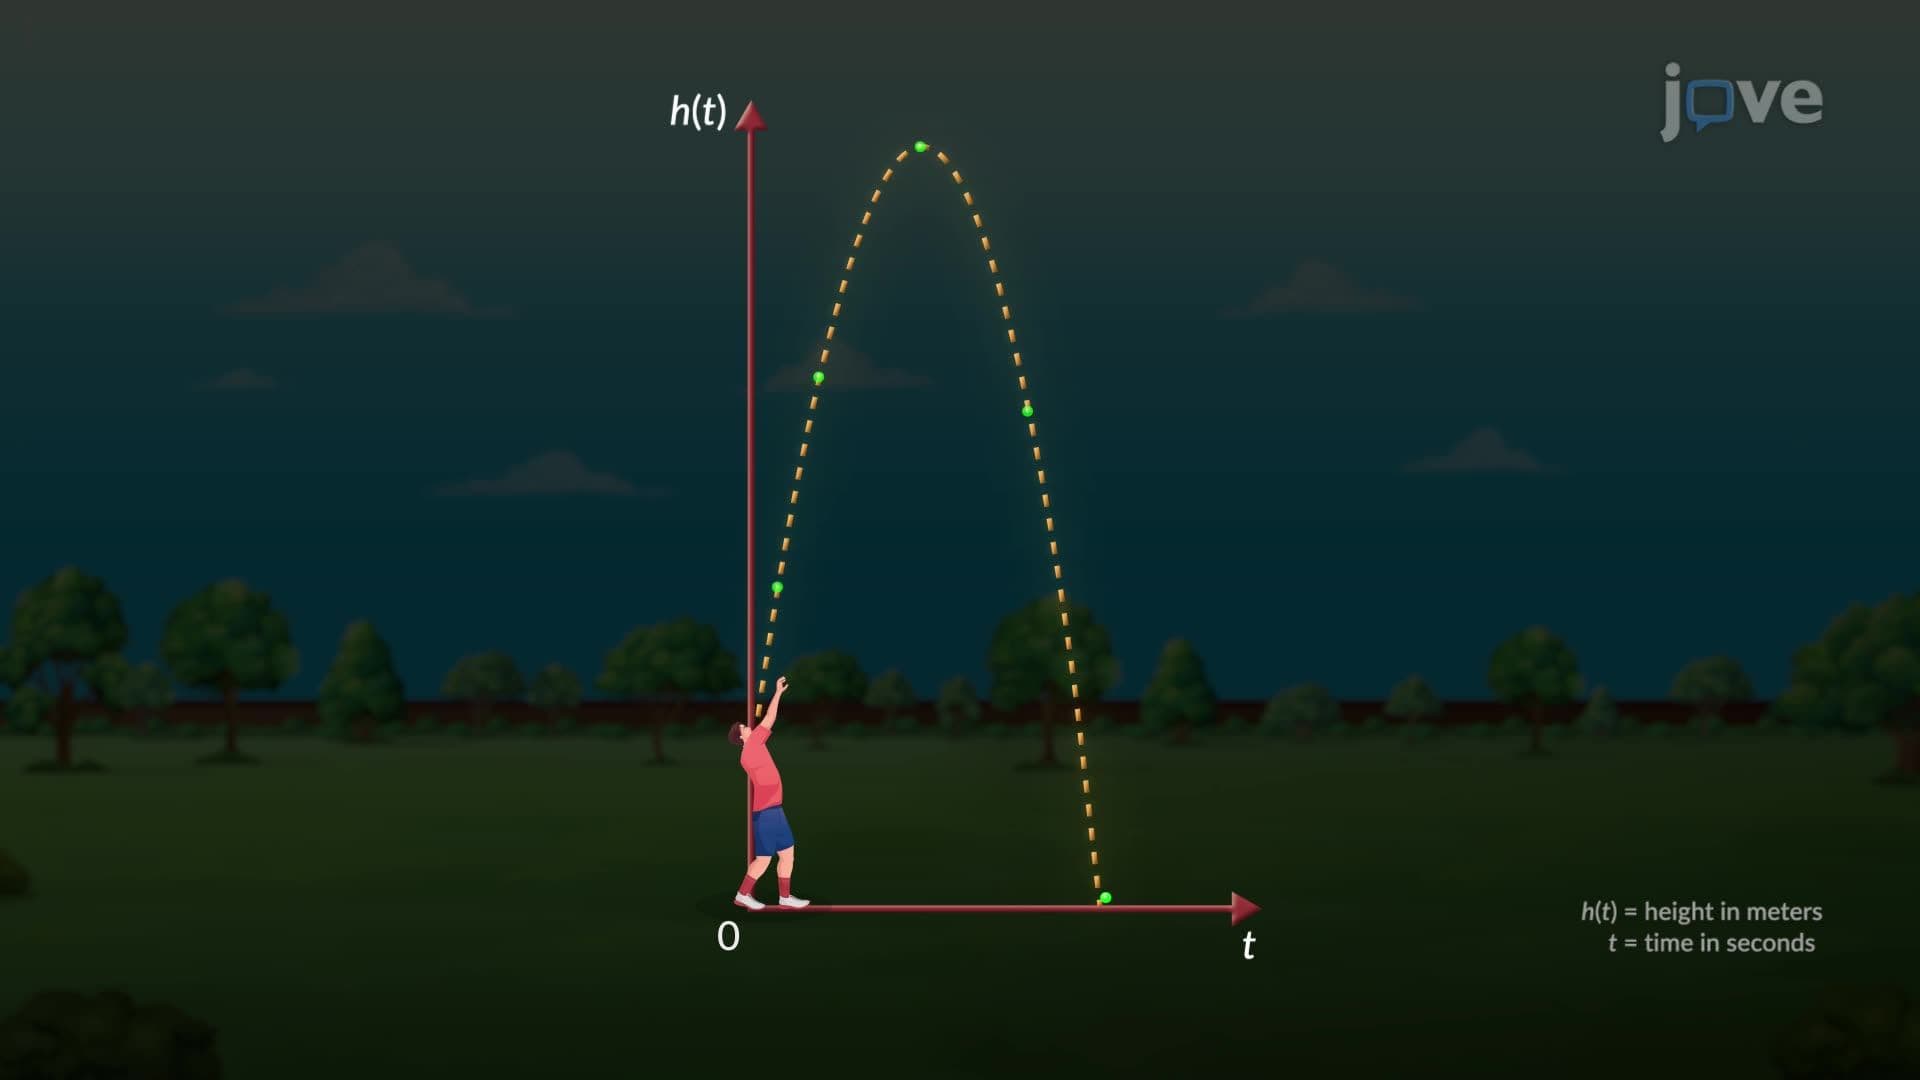
Quadratic Models