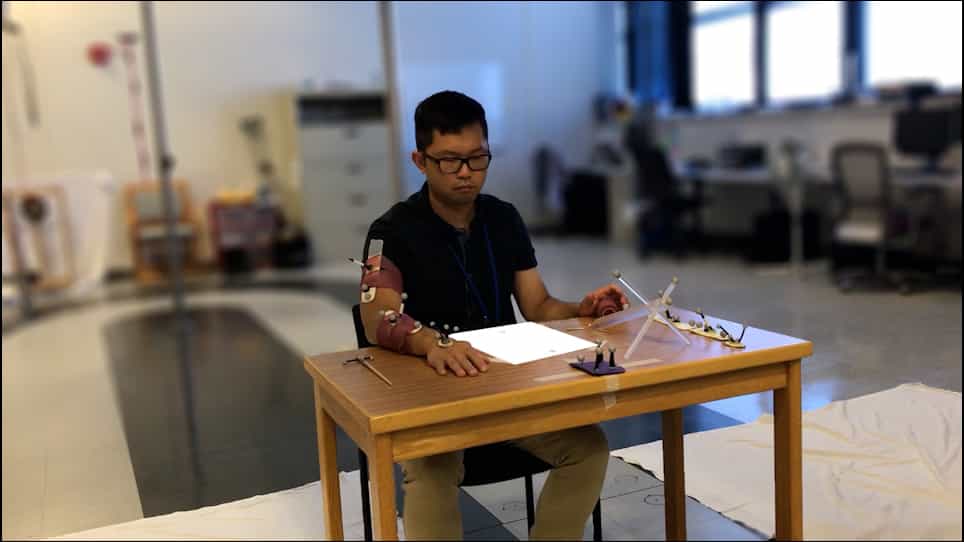
Related Experiment Video
Updated: Oct 2, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Control of manipulative forces during unimanual and bimanual tasks in patients with Huntington's disease
Deborah J Serrien1, Jean-Marc Burgunder, Mario Wiesendanger
1Department of Biology, University of Bern, Switzerland. D.Serrien@ion.ucl.ac.uk

Abstract:
The aim of the study was to investigate grip-load force regulation in Huntington's disease (HD) patients as compared to control subjects during the performance of a manipulative task that required rhythmical unimanual or bimanual isodirectional/non-isodirectional actions in the sagittal plane. Results showed that the profile of grip-load ratio force was characterized by maxima and minima that were attained at upward and downward hand positions, respectively. Minimum force ratio was higher in patients than in controls, which points to an elevated baseline that may be related to the inherent bradykinesia observed in HD. Maximum force ratio was also increased in patients, but this effect depended on the performance condition, with largest amplifications occurring during non-isodirectional movements. The latter rescaling may be associated with the complexity of the coordination mode and its asymmetrical load characteristics. In addition, the temporal delay between the grip and load force peaks was augmented in patients versus controls, indicating a disturbed coupled activation of both forces. Furthermore, the interval was largest during non-isodirectional movements followed by isodirectional and unimanual movements, which denotes that the grip-load force coupling deteriorated as a function of coordinative complexity. Together, these data indicate a deficit in the grip-load force constraint due to HD and illustrate the degrading effect of striatal dysfunction on (bi)manual manipulative function.