Related Experiment Video
Updated: Oct 1, 2026
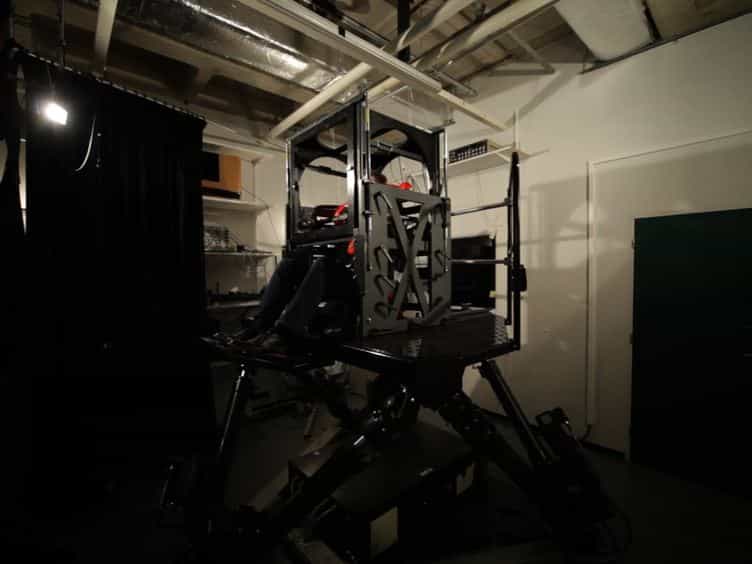

Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
[Development of an optical 3-D position measuring system for simultaneous detection of 6 degrees of freedom]
L Abdelmalek1, E Hempel, A Schmack
1Institut für Medizintechnik und Biophysik, Forschungszentrum Karlsruhe.

Abstract:
A few years ago it became possible to carry out complicated surgical procedures in humans with the required precision by combining medical imaging (MRI, CT) with minimally invasive surgery. The confined space within these imaging systems and the resulting inaccuracies associated with the manual use of instruments increasingly make necessary the help of aids ranging from positioning systems to robotic devices, which themselves must be position controlled. A position sensor has been developed for a medical robotic system allowing the image-controlled insertion of injection needles and the simultaneous administration of different drugs. The 3D position coordinates are determined by a noncontact optical principle, which also enables simultaneous determination of all 6 basic degrees of freedom of the robotic system (3 translational, 3 rotational). On the basis of an area image sensor and the measurement of a geometrically defined structure in the path of the rays between sensor and light source, the position coordinates are calculated almost real time. Special emphasis was placed on designing the sensor system to cover a sufficiently large workspace to enable it to cover the entire intervention area. The sensor described herein determines the position coordinates in a volume of 10 x 10 x 10 cm at a resolution of up to 1 mm for translations and 1 degree for rotations.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...