Related Experiment Video
Updated: Aug 15, 2026

Psychophysically-anchored, Robust Thresholding in Studying Pain-related Lateralization of Oscillatory Prestimulus Activity
Published on: January 21, 2017
Precursory dynamics in threshold systems
J S Sá Martins1, J B Rundle, M Anghel
1Colorado Center for Chaos and Complexity/CIRES and Department of Physics, CB 216, University of Colorado, Boulder, Colorado 80309, USA.

Abstract:
A precursory dynamics, motivated by the analysis of recent experiments on solid-on-solid friction, is introduced in a continuous cellular automaton that mimics the physics of earthquake source processes. The resulting system of equations for the interevent cycle can be decoupled and yields an analytical solution in the mean-field limit, exhibiting a smoothing effect of the dynamics on the stress field. Simulation results show the resulting departure from scaling at the large-event end of the frequency distribution, and support claims that the field leakage may parametrize the superposition of scaling and characteristic regimes observed in real earthquake faults.
Related Concept Videos
 01:19
Graded Potential
Graded potentials fall into two categories: depolarizing and hyperpolarizing. Depolarizing graded potentials typically occur when sodium (Na+) or calcium...
 01:23
Propagation of Action Potentials
Neurons (nerve cells) have a resting membrane potential, with a slightly negative charge inside compared to outside. This is maintained by ion channels, such as sodium (Na+) and potassium (K+) channels, which control the flow of ions. When a stimulus, like a touch or a signal from another neuron, triggers the neuron, sodium channels open, allowing sodium ions to...
 01:21
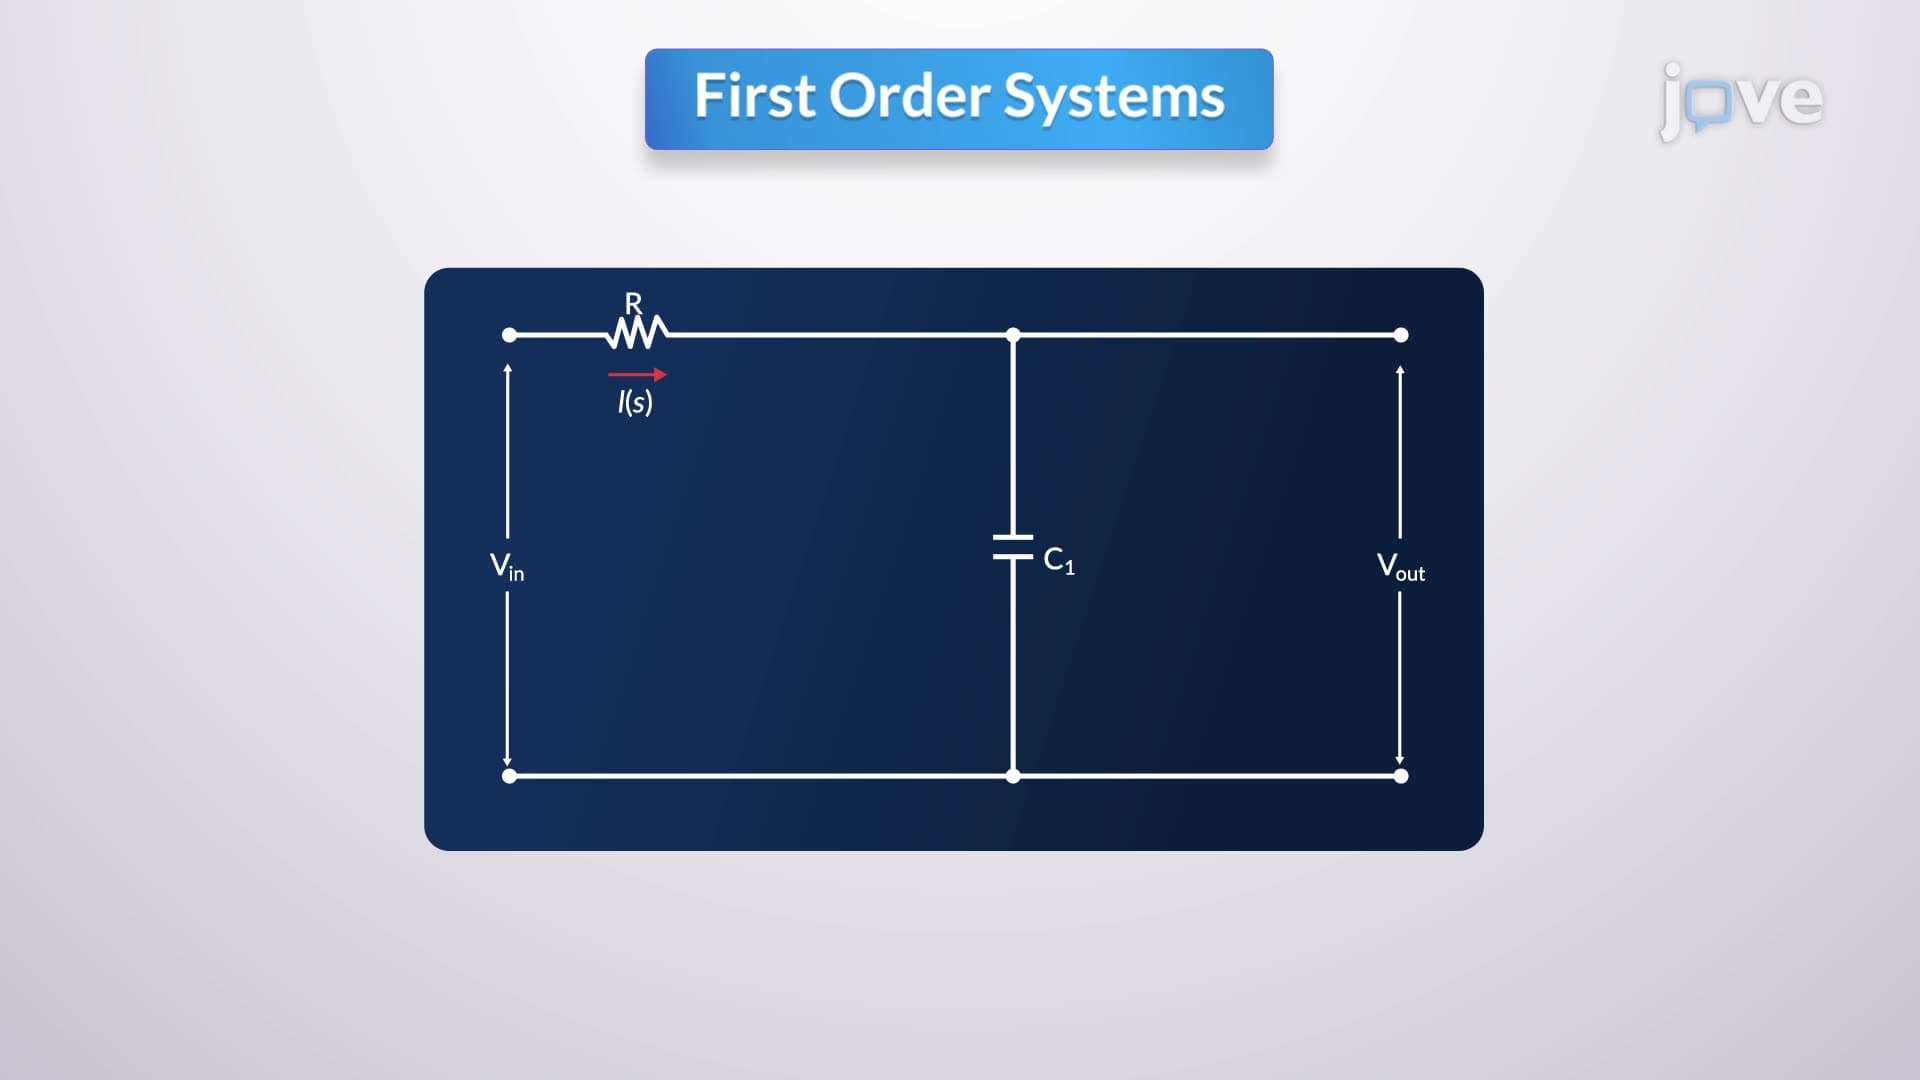
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
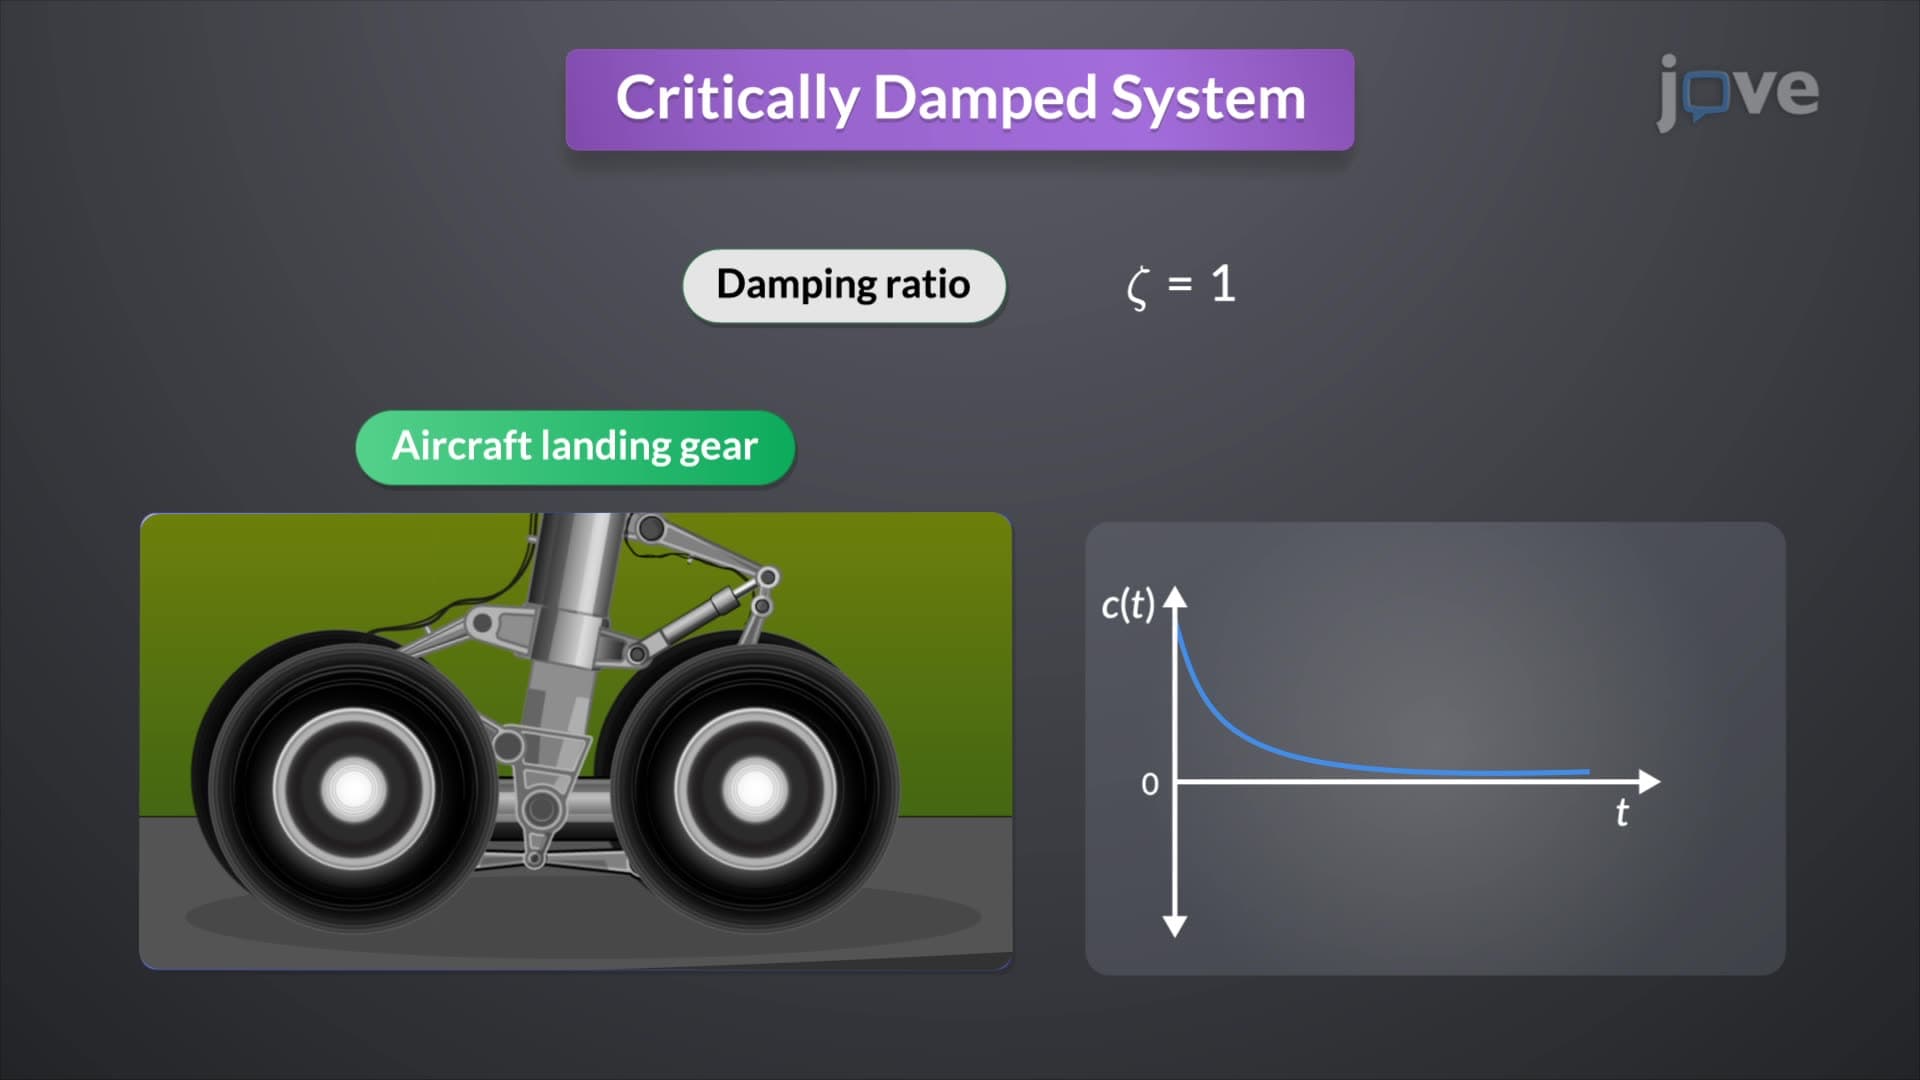
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:18
Second Order systems II
If ζ...
 01:13
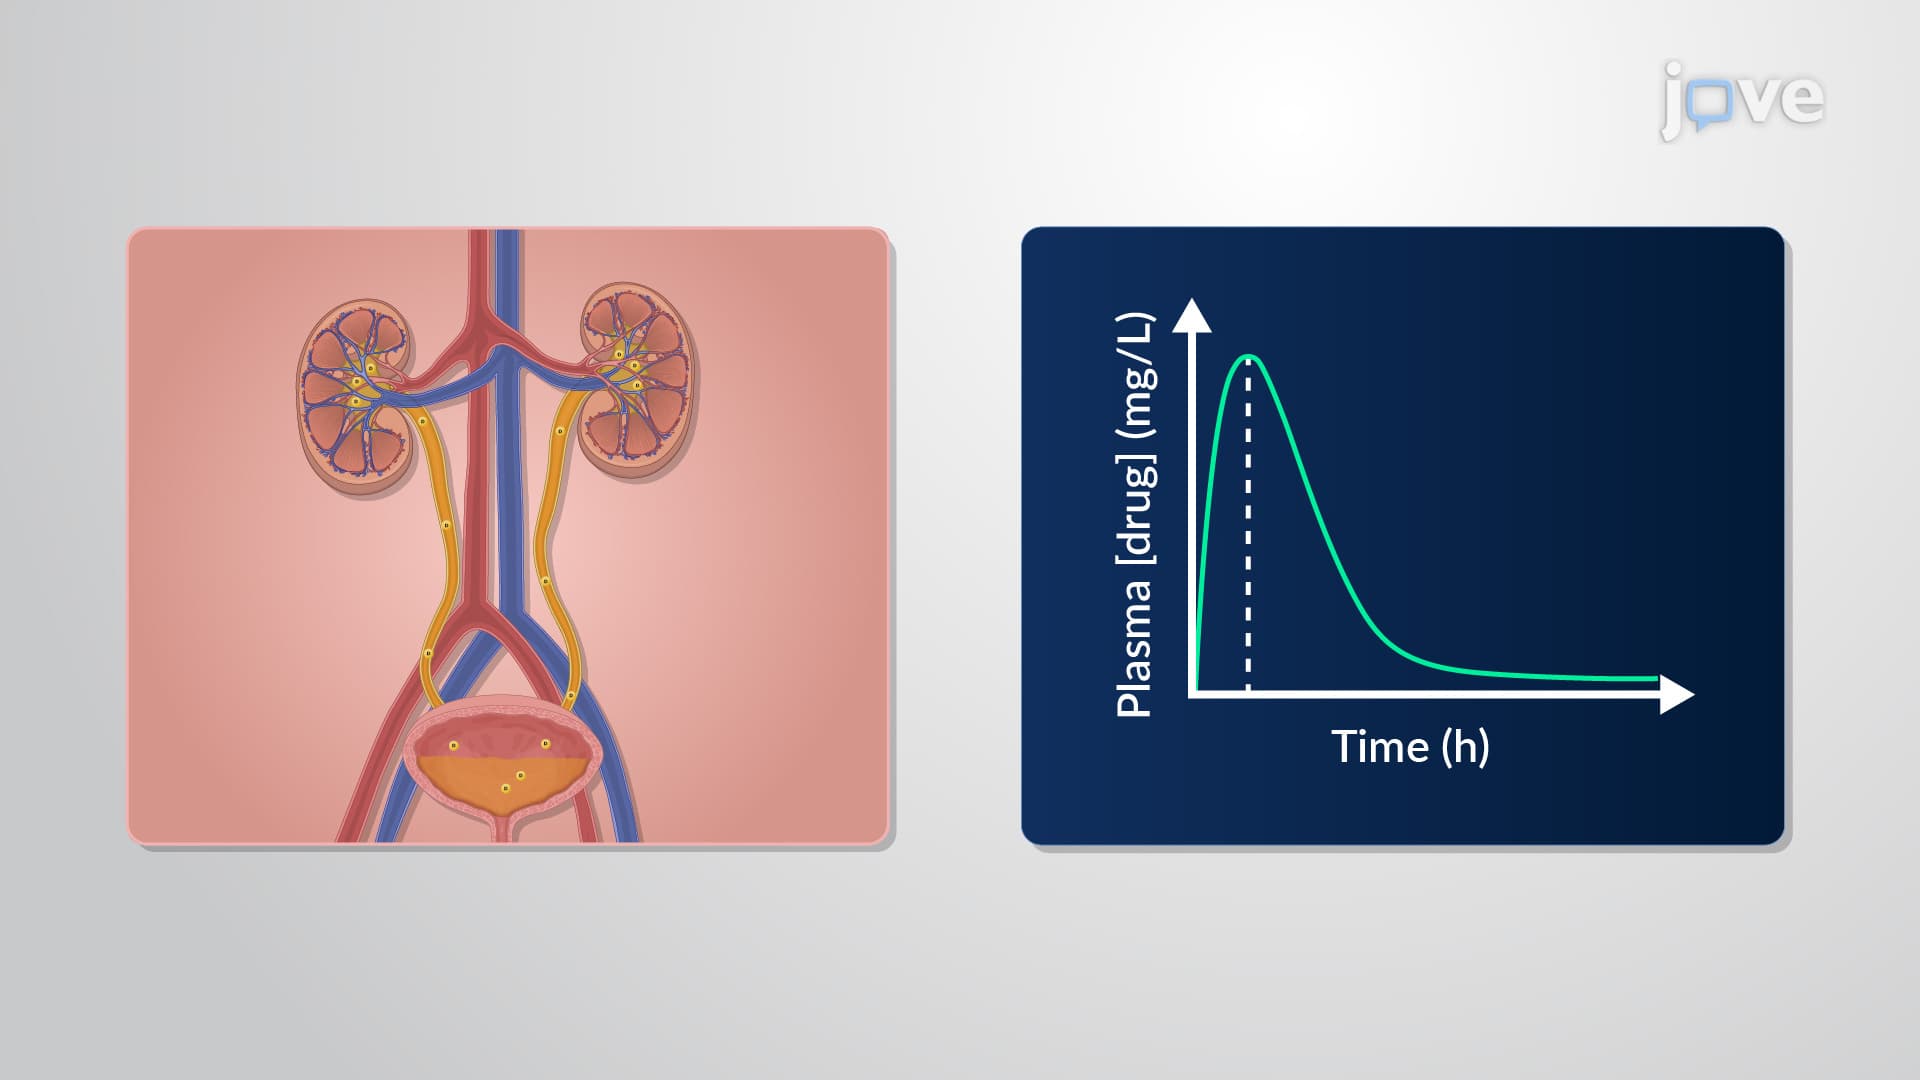
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...