Related Experiment Video
Updated: Sep 29, 2026
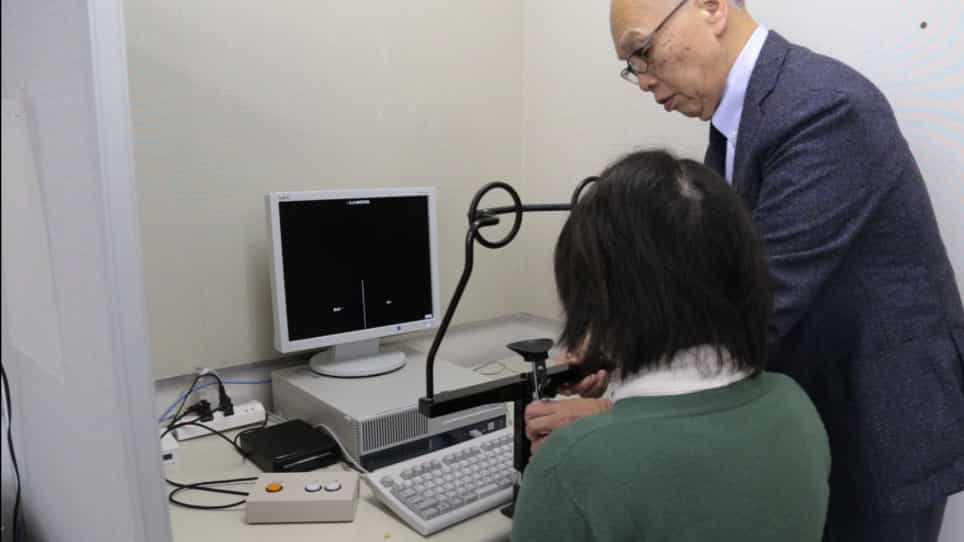
Generating Strictly Controlled Stimuli for Figure Recognition Experiments
Published on: March 18, 2019
Uniformity and asymmetry of rapid curved-line detection explained by parallel categorical coding of contour curvature
David H Foster1, C Julie Savage
1Visual and Computational Neuroscience Group, Department of Optometry and Neuroscience, University of Manchester Institute of Science and Technology, M60 1QD, Manchester, UK. d.h.foster@umist.ac.uk

Abstract:
The aim of this work was to elucidate several characteristic phenomena associated with rapid curved-line detection in multi-element arrays and to provide a unified account of the underlying curvature-sensitive mechanisms. To this end, a parametric experiment was performed in which the detectability of a curved-line target in a briefly presented planar array of curved-line distractors was measured for a range of target and distractor curvatures and distractor numbers. For both vertically oriented and randomly oriented curved lines, it was found that (1) the dependence of target detectability on target curvature was independent of distractor number for small distractor curvatures but not for medium-to-large distractor curvatures; (2) an asymmetry in target detectability with respect to interchange of target and distractor curvatures occurred only with large distractor numbers; and (3) with small distractor numbers, target detectability depended only on the difference between target and distractor curvatures. These properties of spatial parallelism, asymmetry, and uniformity were explained quantitatively by a minimal model of rapid curved-line detection in which contour curvature was coded in terms of just two or three curvature categories, depending on curved-line orientation.
Related Concept Videos
 01:25
Curvature and Its Interpretation
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:22
Level Curves and Contour Maps
 01:27
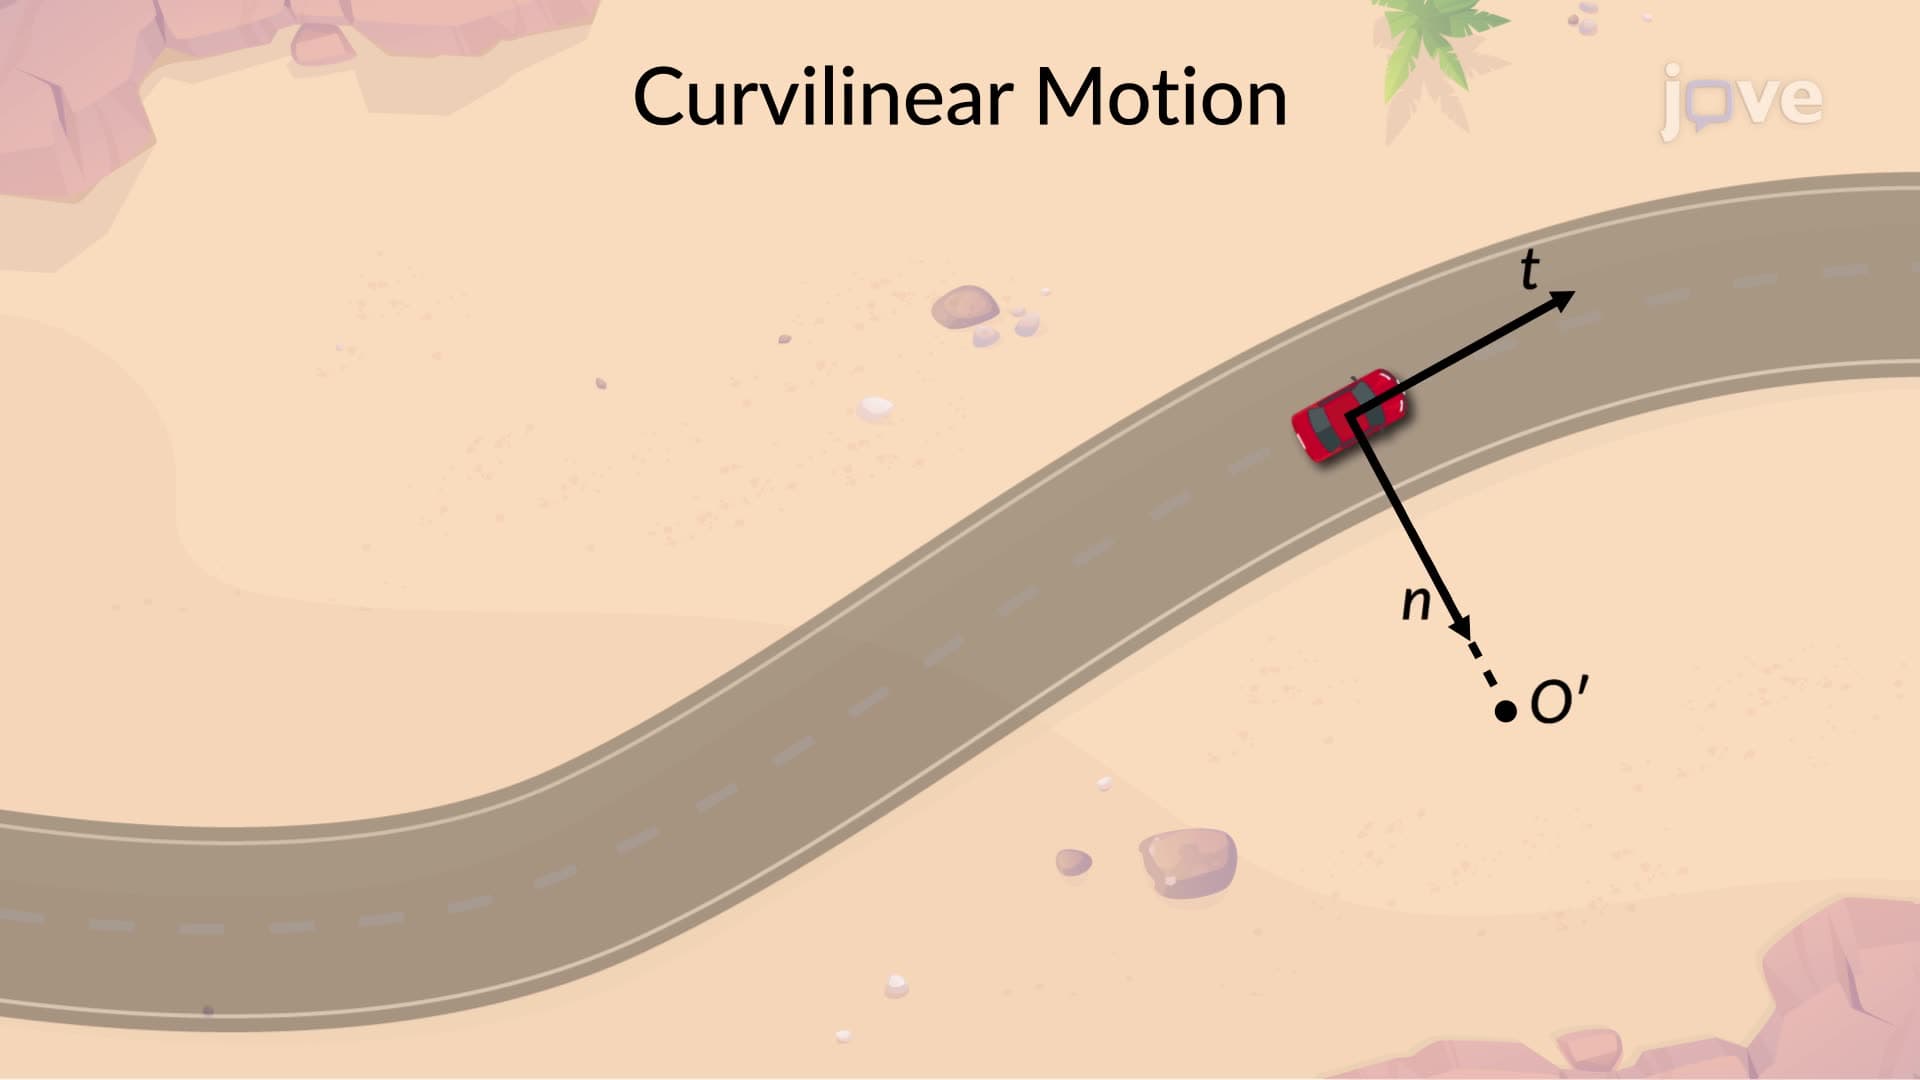
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:29
Real-World Applications of Space Curves
 01:19
Introduction to Horizontal Curves