Controller performance analysis with LQG benchmark obtained under closed loop conditions
Related Experiment Video
Updated: Sep 28, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
1Department of Chemical and Materials Engineering, University of Alberta, Edmonton, Canada.

Abstract:
This paper proposes a new method for obtaining a linear quadratic Gaussian (LQG) benchmark in terms of the variances of process input and output from closed-loop data, for assessing the controller performance. LQG benchmark has been proposed in the literature to assess controller performance since the LQG tradeoff curve represents the limit of performance in terms of input and output variances. However, an explicit parametric model is required to calculate the LQG benchmark. In this work, we propose a data driven subspace approach to calculate the LQG benchmark under closed-loop conditions with certain external excitations. The optimal LQG-benchmark variances are obtained directly from the subspace matrices corresponding to the deterministic inputs and the stochastic inputs, which are identified using closed-loop data with setpoint excitation. These variances are used for assessing the controller performance. The method proposed in this paper is applicable to both univariate and multivariate systems. Profit analysis for the implementation of feedforward control to the existing feedback-only control system is also analyzed under the optimal LQG performance framework. The proposed method is illustrated through a simulation example and an application on a pilot scale process.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:19
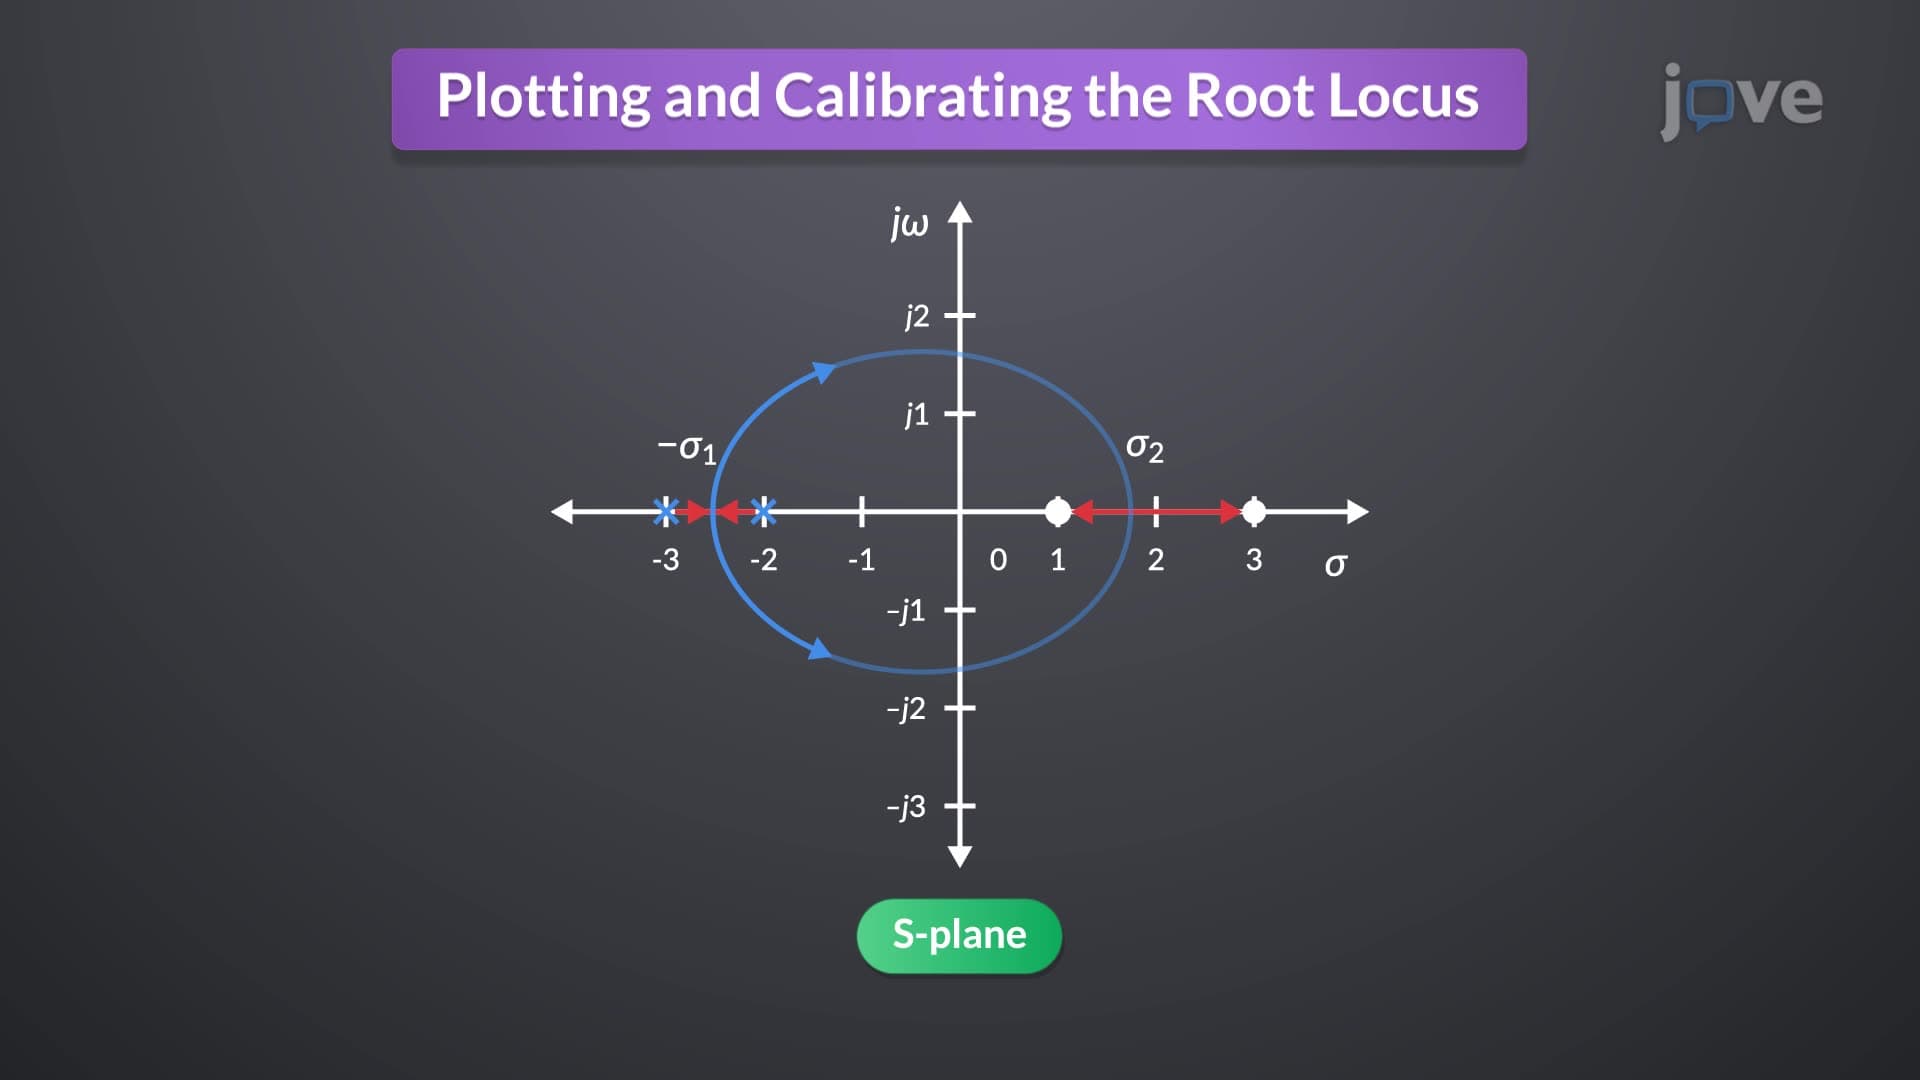
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...