Haptic interaction with highly detailed objects
Related Experiment Video
Updated: Sep 16, 2026
Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011
1Surgical System Lab., Research Center Caesar Friedensplatz 16, 53111 Bonn, Germany. zerfass@caesar.de

Abstract:
Haptic exploration of detailed models from patient specific anatomical structures places high demands on computational resources. Constant collision detection and correct calculation of forces fed back to the operator quickly exceed available processing power with increasing level of detail of the represented objects. To alleviate the strain on computational resources optimisation schemes are employed to speed up processing and guarantee glitch-free operation as well as smooth haptic feedback. Among these are the generation of a local haptic model, a look-ahead strategy to increase its range of validity, small world-shift operations and force extrapolation algorithms for smooth feedback.


Related Concept Videos
 01:33
Somatosensation
 02:26
Responses to Gravity and Touch
 01:30
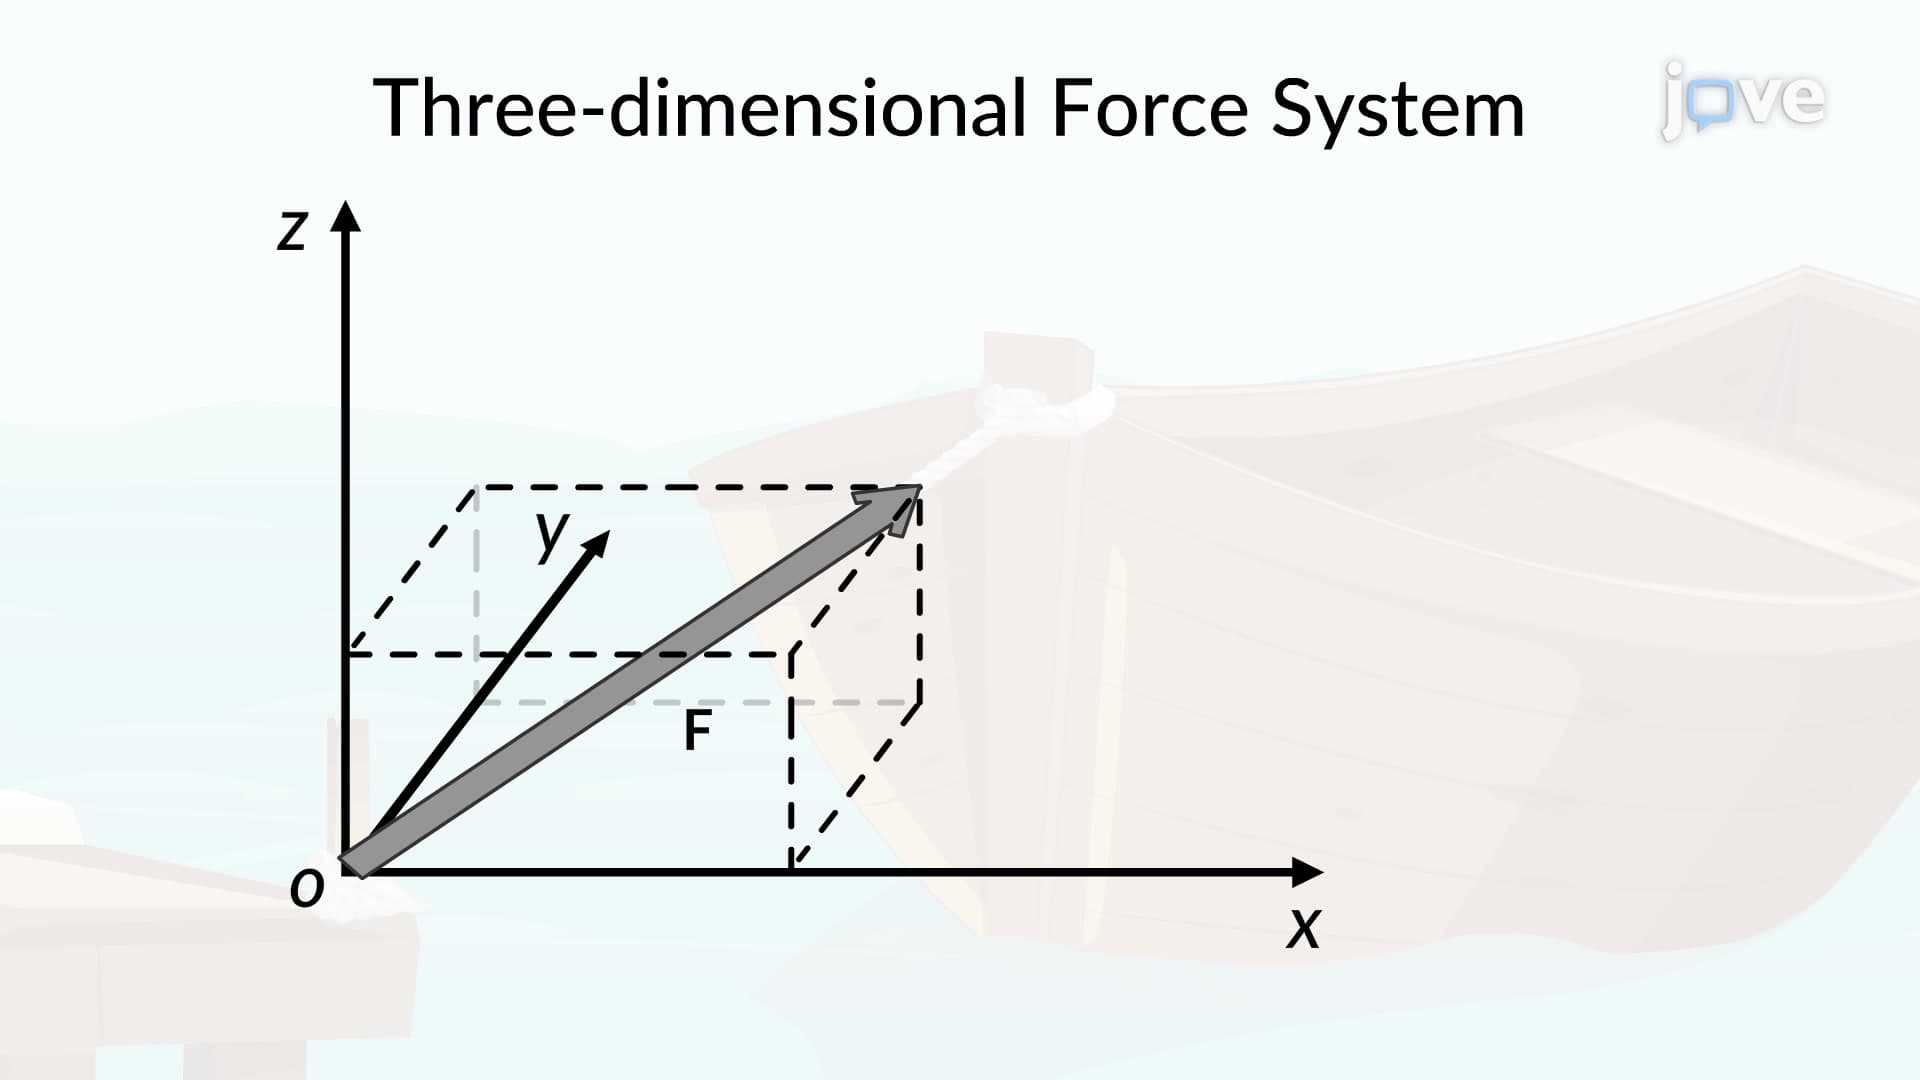
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...