Automatic algorithm for filtering kinematic signals with impacts in the Wigner representation
Related Experiment Video
Updated: Sep 27, 2026
Impacts of Free-falling Spheres on a Deep Liquid Pool with Altered Fluid and Impactor Surface Conditions
Published on: February 17, 2019
A Georgakis1, L K Stergioulas, G Giakas
1Department of Communication Systems, Lancaster University, Lancaster, UK. a.georgakis@lancaster.ac.uk

Abstract:
An automatic filtering algorithm is proposed for the accurate estimation of the second derivatives of kinematic signals with impacts. The impacts considered here occur when a moving object hits a rigid surface. The algorithm performs time-frequency filtering in the Wigner representation, to deal efficiently with the non-stationarities caused by such impacts, and adjusts the parameters of its time-frequency filtering function so that the filtering process adapts to the individual characteristics of the signal in hand. Performance analysis and comparative evaluation with experimentally acquired kinematic impact signals demonstrated a higher accuracy, with performance advantages over two widely used conventional automatic methods: linear phase autoregressive model-based derivative assessment (LAMBDA) and generalised cross-validation using quintic splines (GCVQS). For high impacts, the average absolute relative error in estimating the peak acceleration was 5.7% with the proposed method, 17.2% with a Butterworth low-pass filter optimised to yield minimum overall acceleration RMS error (best-case result), 18.3% with the LAMBDA method, and 37.2% with the GCVQS method. For signals with low impacts, the average absolute relative error was 19.4%, 6.9%, 8.3% and 19.1%, respectively, in each case, which indicates that, for signals with a low-frequency content, there is no need for such time-frequency filtering.
Related Concept Videos
 01:10
Reconstruction of Signal using Interpolation
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:11
Sampling Continuous Time Signal
In the...
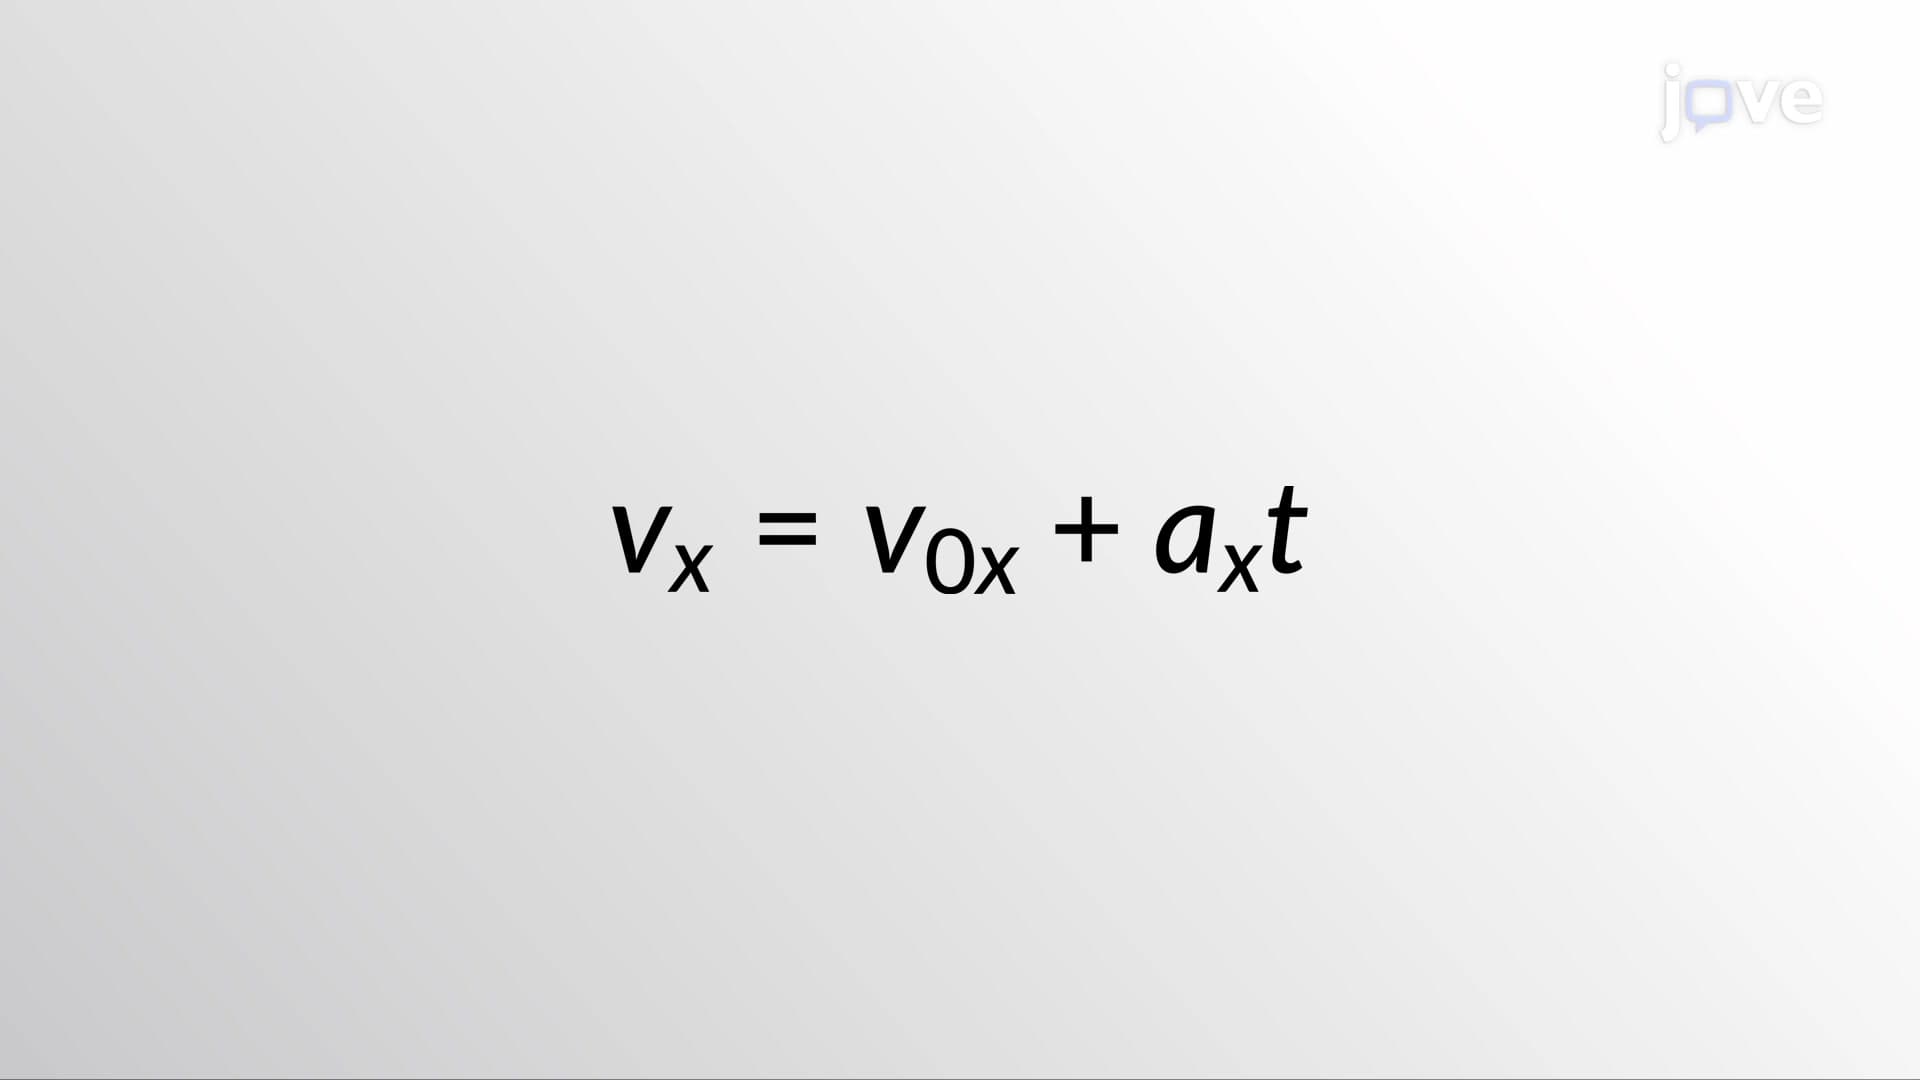 01:26
Kinematic Equations - I