One-Handed Juggling: A Dynamical Approach to a Rhythmic Movement Task
Related Experiment Video
Updated: Sep 27, 2026
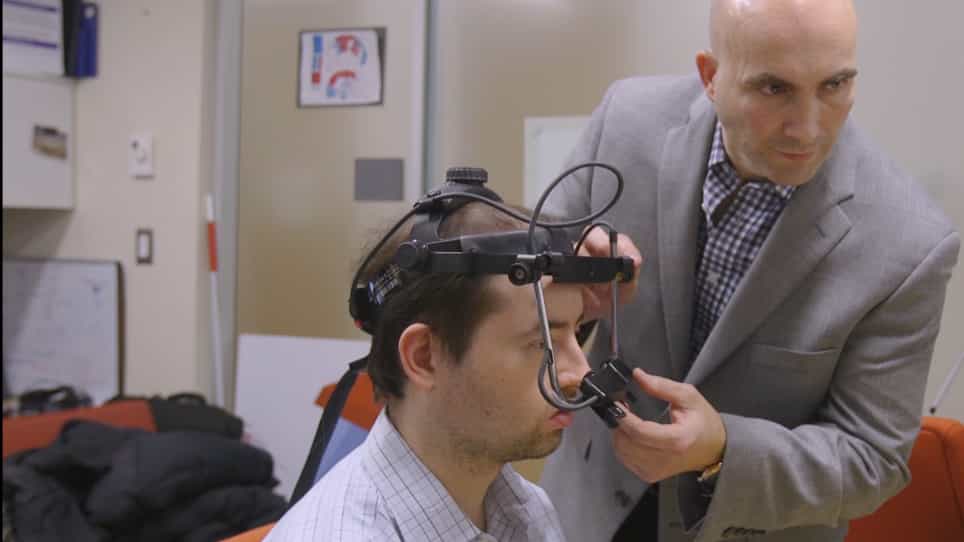
Efficiently Recording the Eye-Hand Coordination to Incoordination Spectrum
Published on: March 21, 2019
S. Schaal1, C. G. Atkeson, D. Sternad
1Georgia Institute of Technology, 801 Atlantic Drive, Atlanta, GA 30306, USA. sschaal@cc.gatech.edu

Abstract:
The skill of rhythmically juggling a ball on a racket was investigated from the viewpoint of nonlinear dynamics. The difference equations that model the dynamical system were analyzed by means of local and nonlocal stability analyses. These analyses showed that the task dynamics offer an economical juggling pattern that is stable even for open-loop actuator motion. For this pattern, two types of predictions were extracted: (a) Stable periodic bouncing is sufficiently characterized by a negative acceleration of the racket at the moment of impact with the ball, and (b) a nonlinear scaling relation maps different juggling trajectories onto one topologically equivalent dynamical system. The relevance of these results for the human control of action was evaluated in an experiment in which subjects (N = 6) performed a comparable task of juggling a ball on a paddle. Task manipulations involved different juggling heights and gravity conditions of the ball. The following predictions were confirmed: (a) For stable rhythmic performance, the paddle's acceleration at impact is negative and fluctuations of the impact acceleration follow predictions from global stability analysis; and (b) for each subject, the realizations of juggling for the different experimental conditions are related by the scaling relation. These results permit one to conclude that humans reliably exploit the stable solutions inherent to the dynamics of the given task and do not overrule these dynamics by other control mechanisms. The dynamical scaling serves as an efficient principle for generating different movement realizations from only a few parameter changes and is discussed as a dynamical formalization of the principle of motor equivalence.
More Related Videos
Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
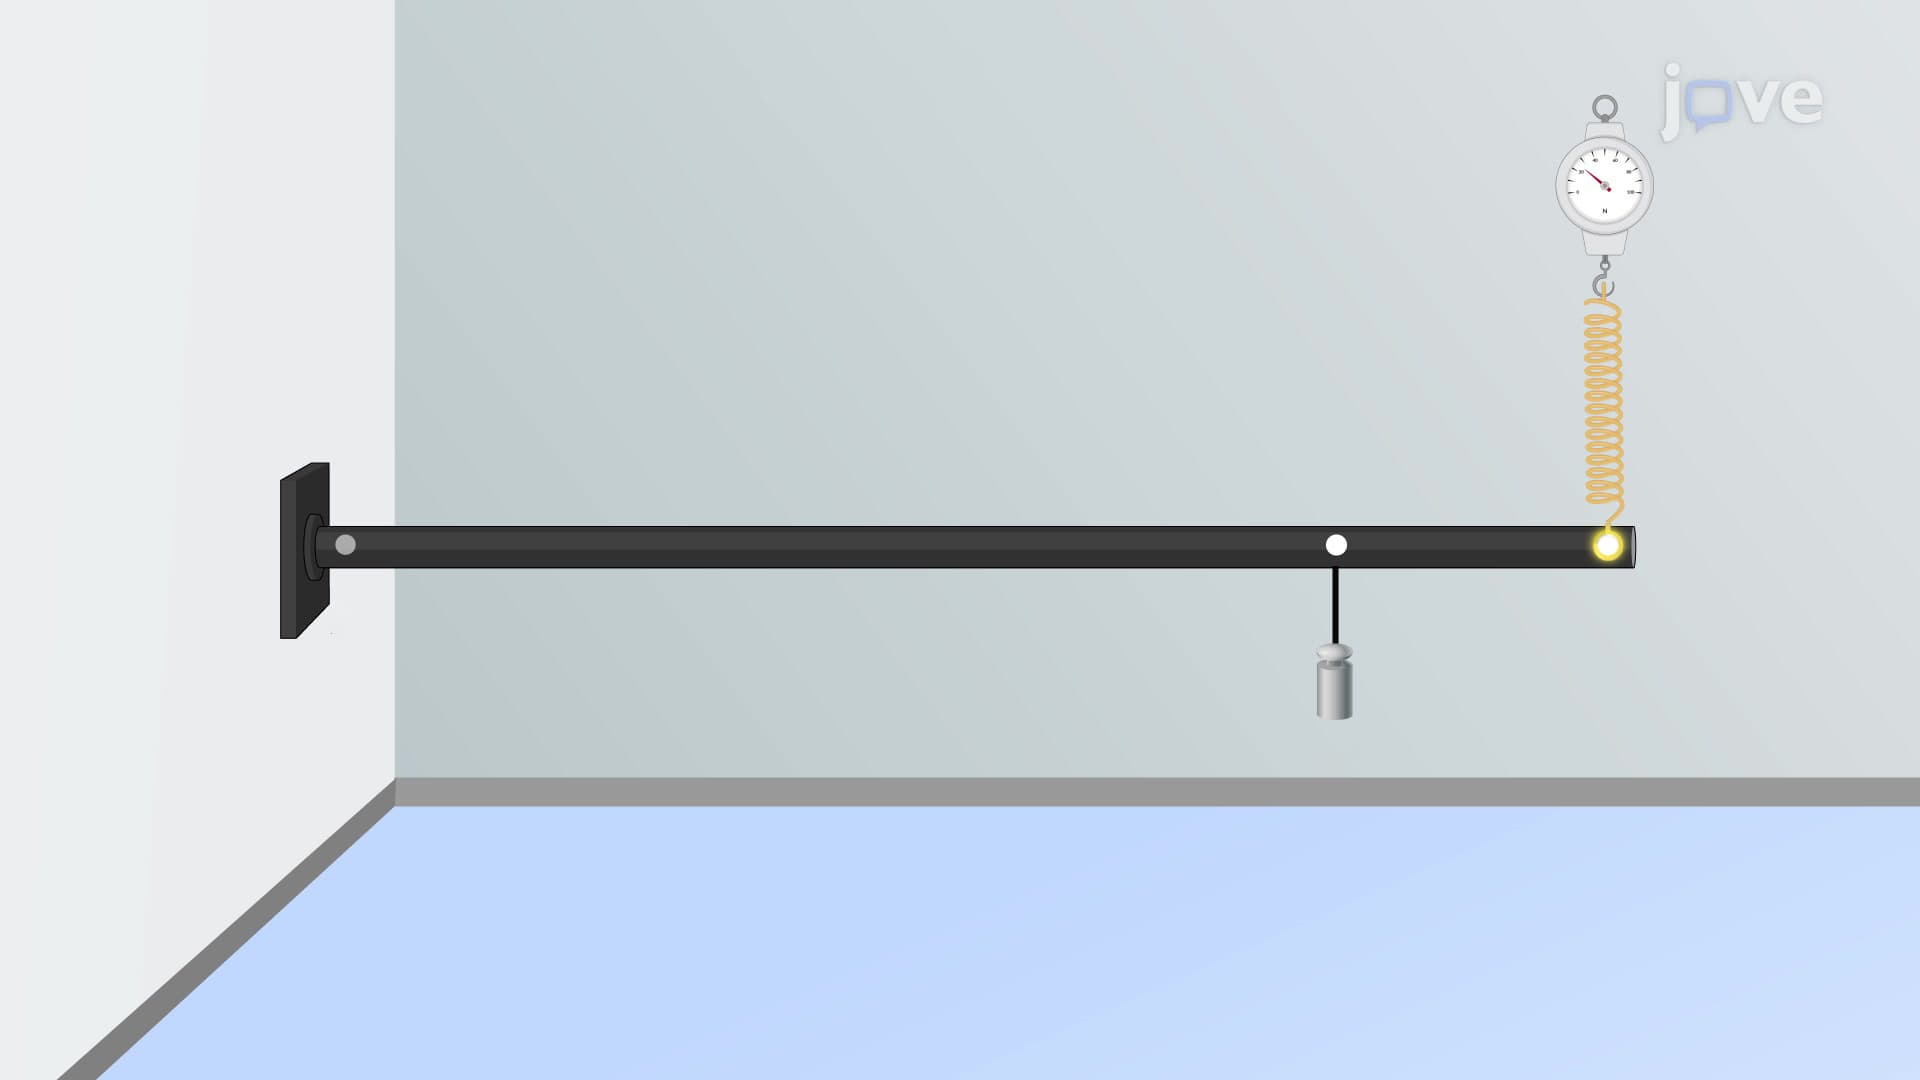
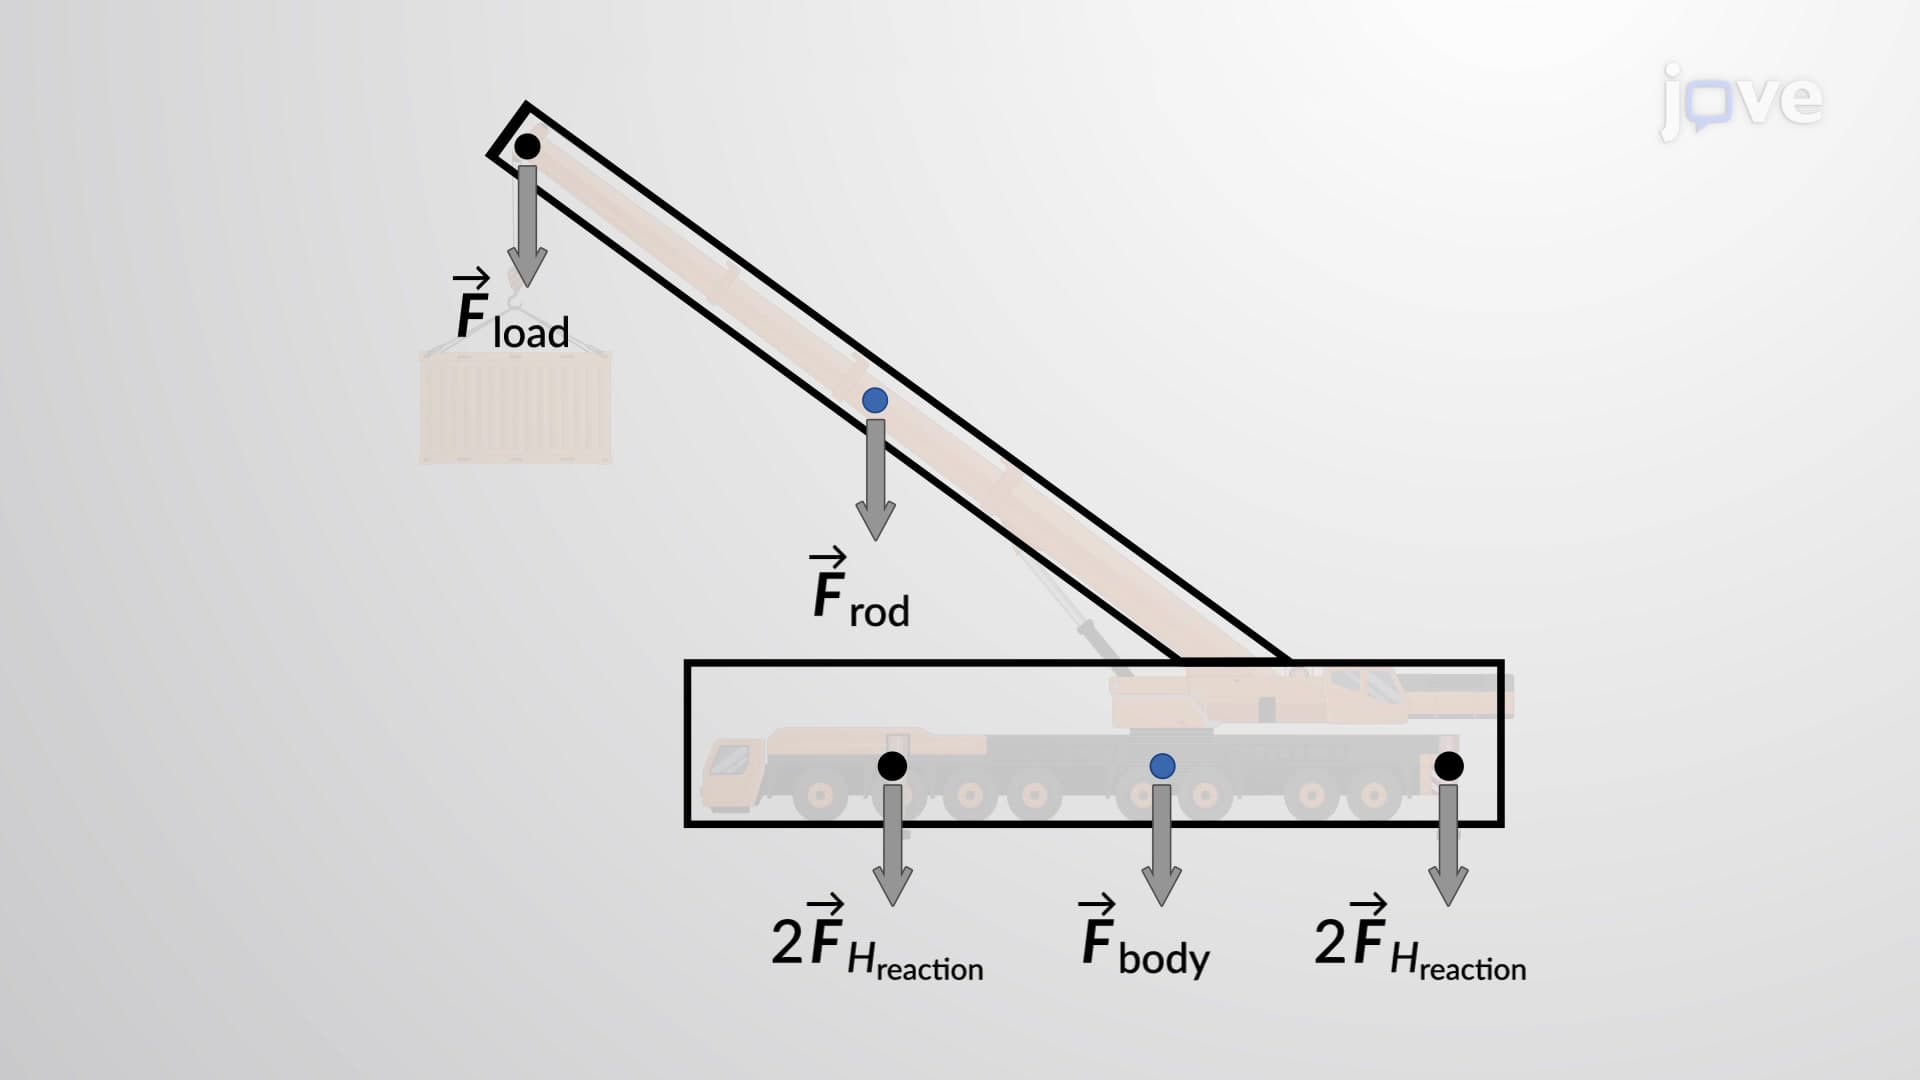
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:30
Dynamics of Circular Motion
Any acceleration must be produced by some force. Therefore, any force or combination of forces can cause centripetal acceleration. A few examples include the tension in the rope on a...
 01:17
Dynamics Of Circular Motion: Applications