Related Experiment Video
Updated: Sep 27, 2026
The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
A Computational Model of the Simplest Motor Program
1Department of Neurological Sciences, Rush Medical College, 2242 West Harrison Street, Chicago, IL 60612, USA.

Abstract:
A computational procedure (program) is defined to generate control signals for the motoneuron pools of agonist and antagonist muscles that will move a limb segment from one stationary position to another. The program accounts for the ability to move different distances with different inertial loads and for the influence of instructions concerning movement speed and accuracy. These motor commands allow the program to produce EMG patterns as well as force and kinematic trajectories that are consistent with much of the data found in the literature of these movements. The program is premised on the notion that kinematically defined tasks are accomplished by programming commands to the motoneuron pools, based on only a few cognitively recognized kinematic and dynamic features of the task. Most of the features found in EMG and kinematic patterns can be considered consequences of the program's algorithmic procedures rather than specifically planned features of those movements.

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 00:46
Motor Units
 01:30
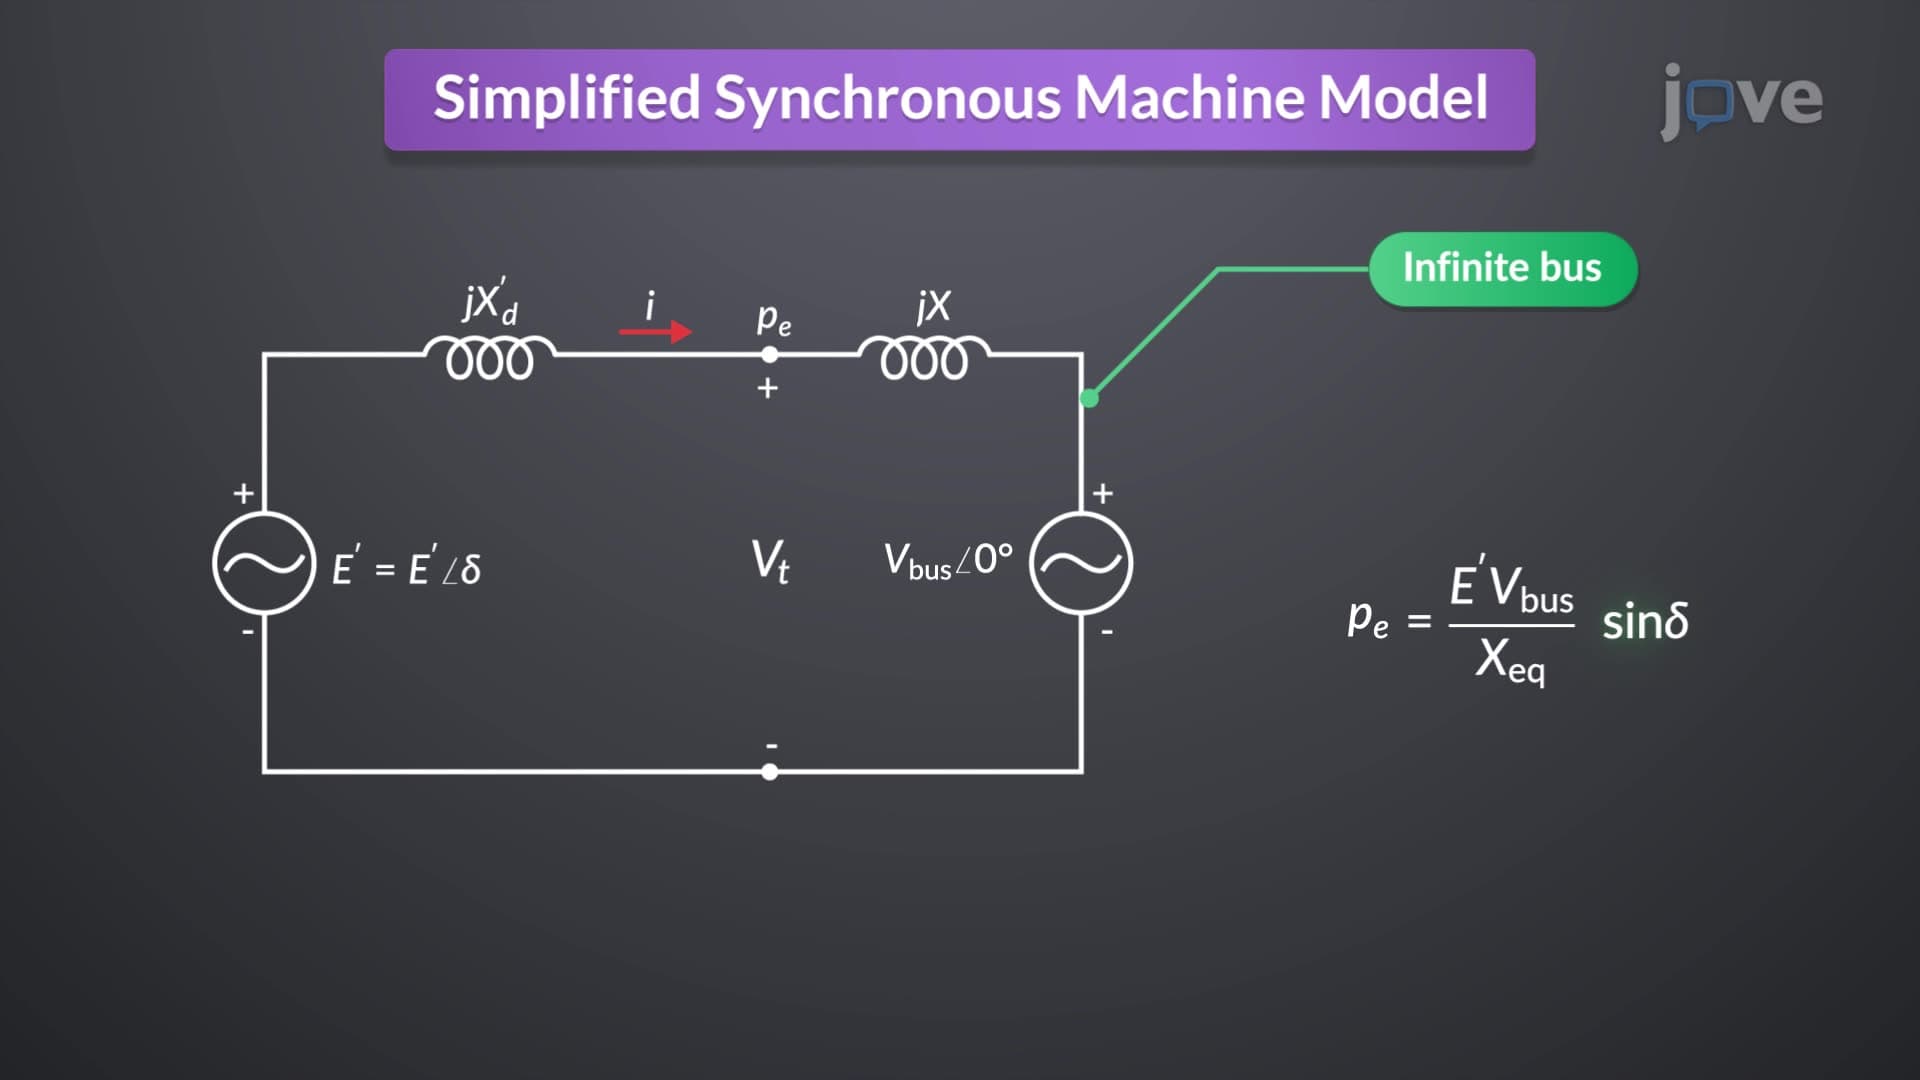
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:11
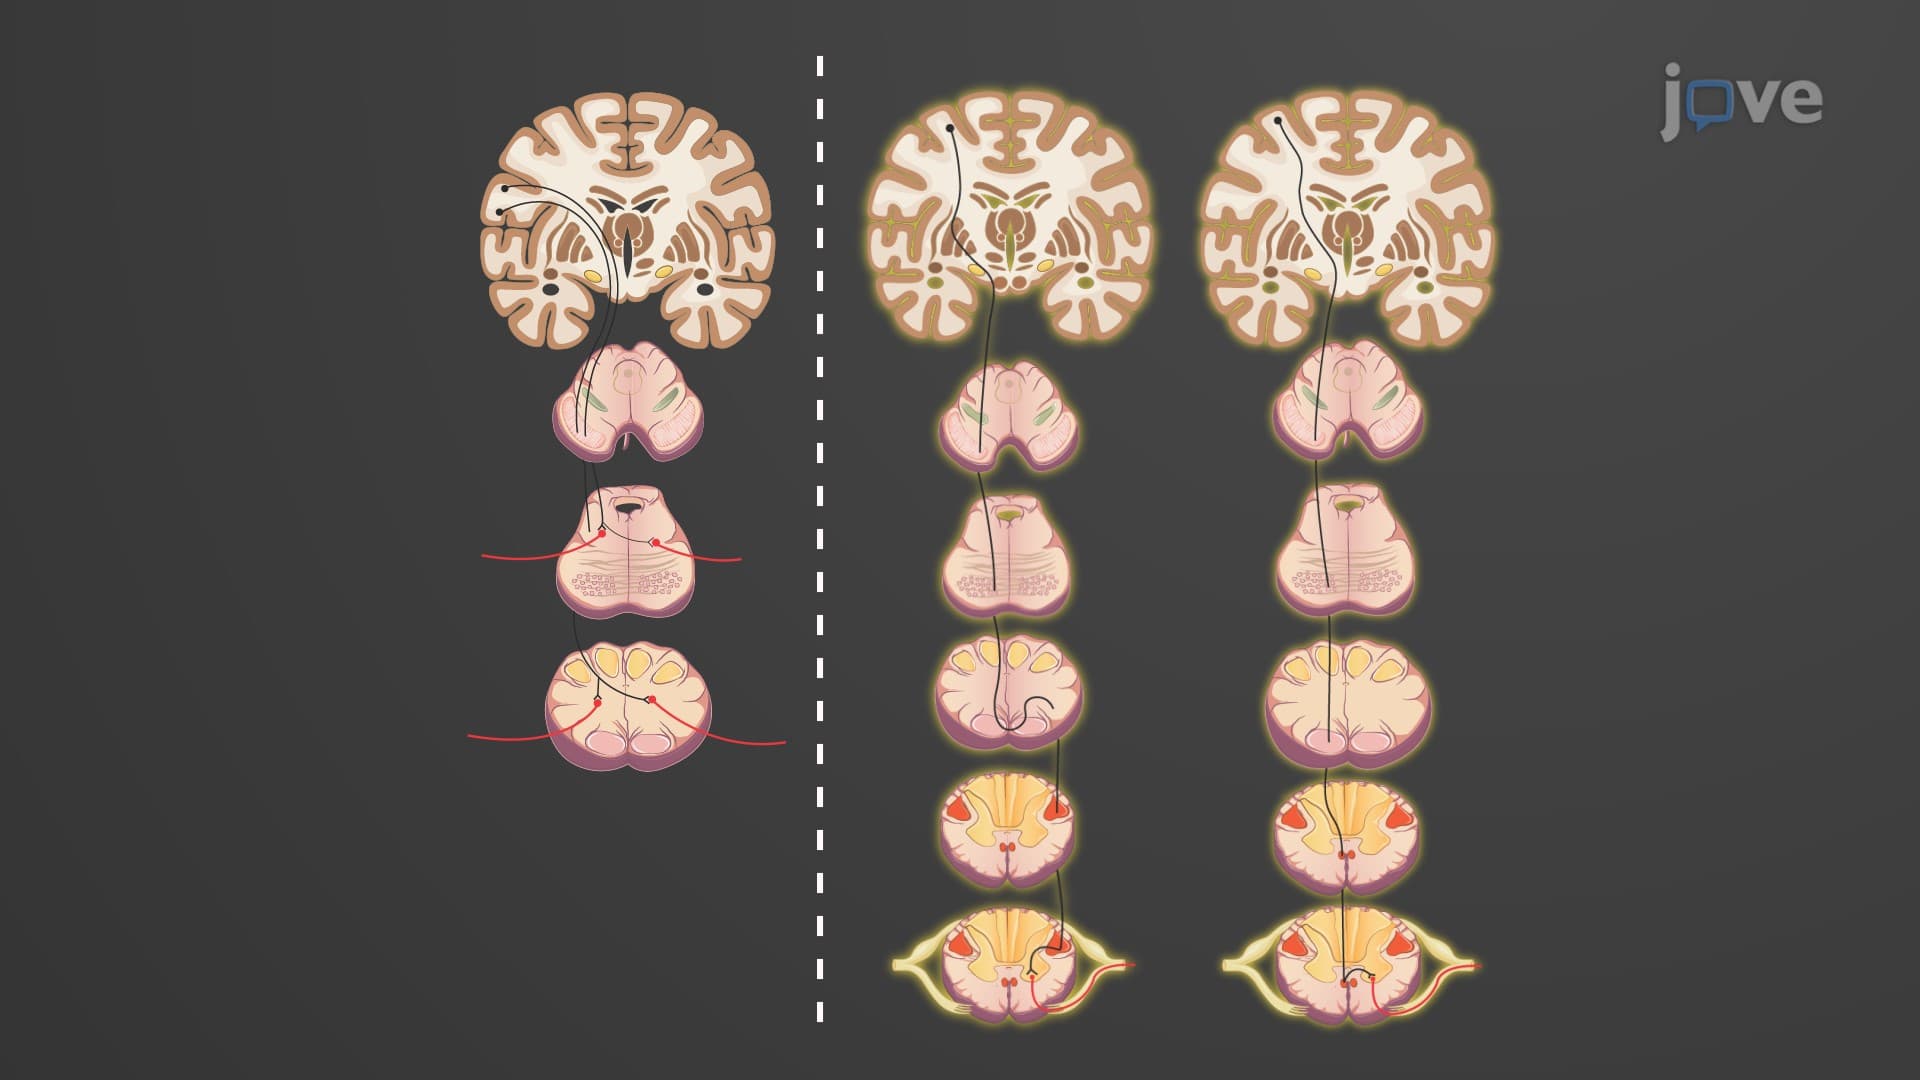
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and the...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...