A neural network model of spiral-planar motion tuning in MSTd
Related Experiment Video
Updated: Sep 27, 2026
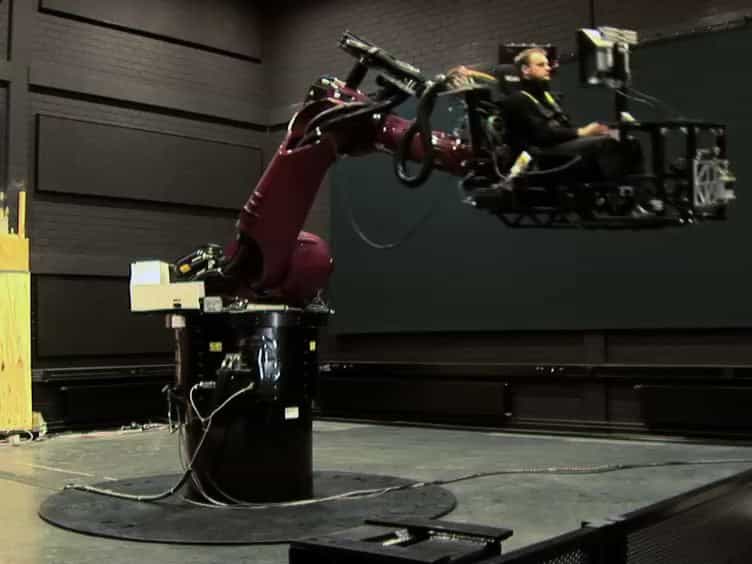
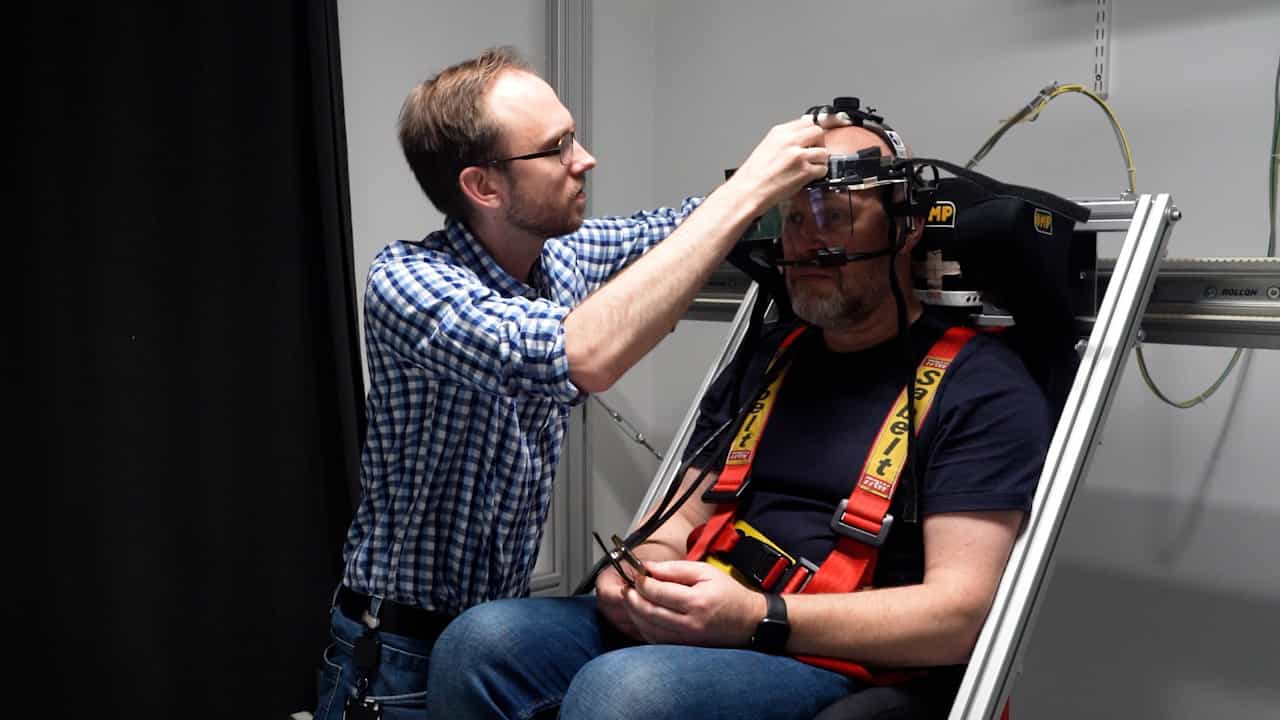
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Scott A Beardsley1, Robert L Ward, Lucia M Vaina
1Brain and Vision Research Laboratory, Department of Biomedical Engineering, Boston University, 44 Cummington Street, Boston, MA 02215, USA.

Abstract:
Neurophysiological studies in MSTd report the existence of motion pattern selective cells whose visual motion properties span a continuum of values, suggesting a role in estimates of self-motion from optic flow. Biologically motivated models of heading estimation support this view, having identified similar visual motion properties within their "neural" structures. While such models have addressed the computational sufficiency of their respective feed-forward designs they have not explicitly examined the underlying computational structures, particularly as they relate to the interaction between planar and spiral motion responses within MSTd. Here we use an expanded stimulus training set that includes planar motions to extend the range of neurophysiological properties identified within an existing network structure [Network: Comput. Neural Syst. 9 (1998) 467]. In doing so, we quantify the emergent planar motion properties within the network hidden layer and examine how they interact, functionally and computationally, with cardinal/spiral motion pattern responses. Throughout the hidden layer we demonstrate that the input activation associated with a unit's preferred planar motion is consistent with an overlapping gradient hypothesis [J. Neurophysiol. 65(6) (1991) 1346]. Together with the change to a peripheral excitation profile in the presence of a unit's preferred spiral motion these results suggest a more complex computational architecture in which the cell's 'classical' receptive field properties are dependent on the type of stimulus used to map them. Based on the computational model we propose an experimental paradigm to investigate the existence of equivalent computational structures in MSTd.
Related Concept Videos
 01:27
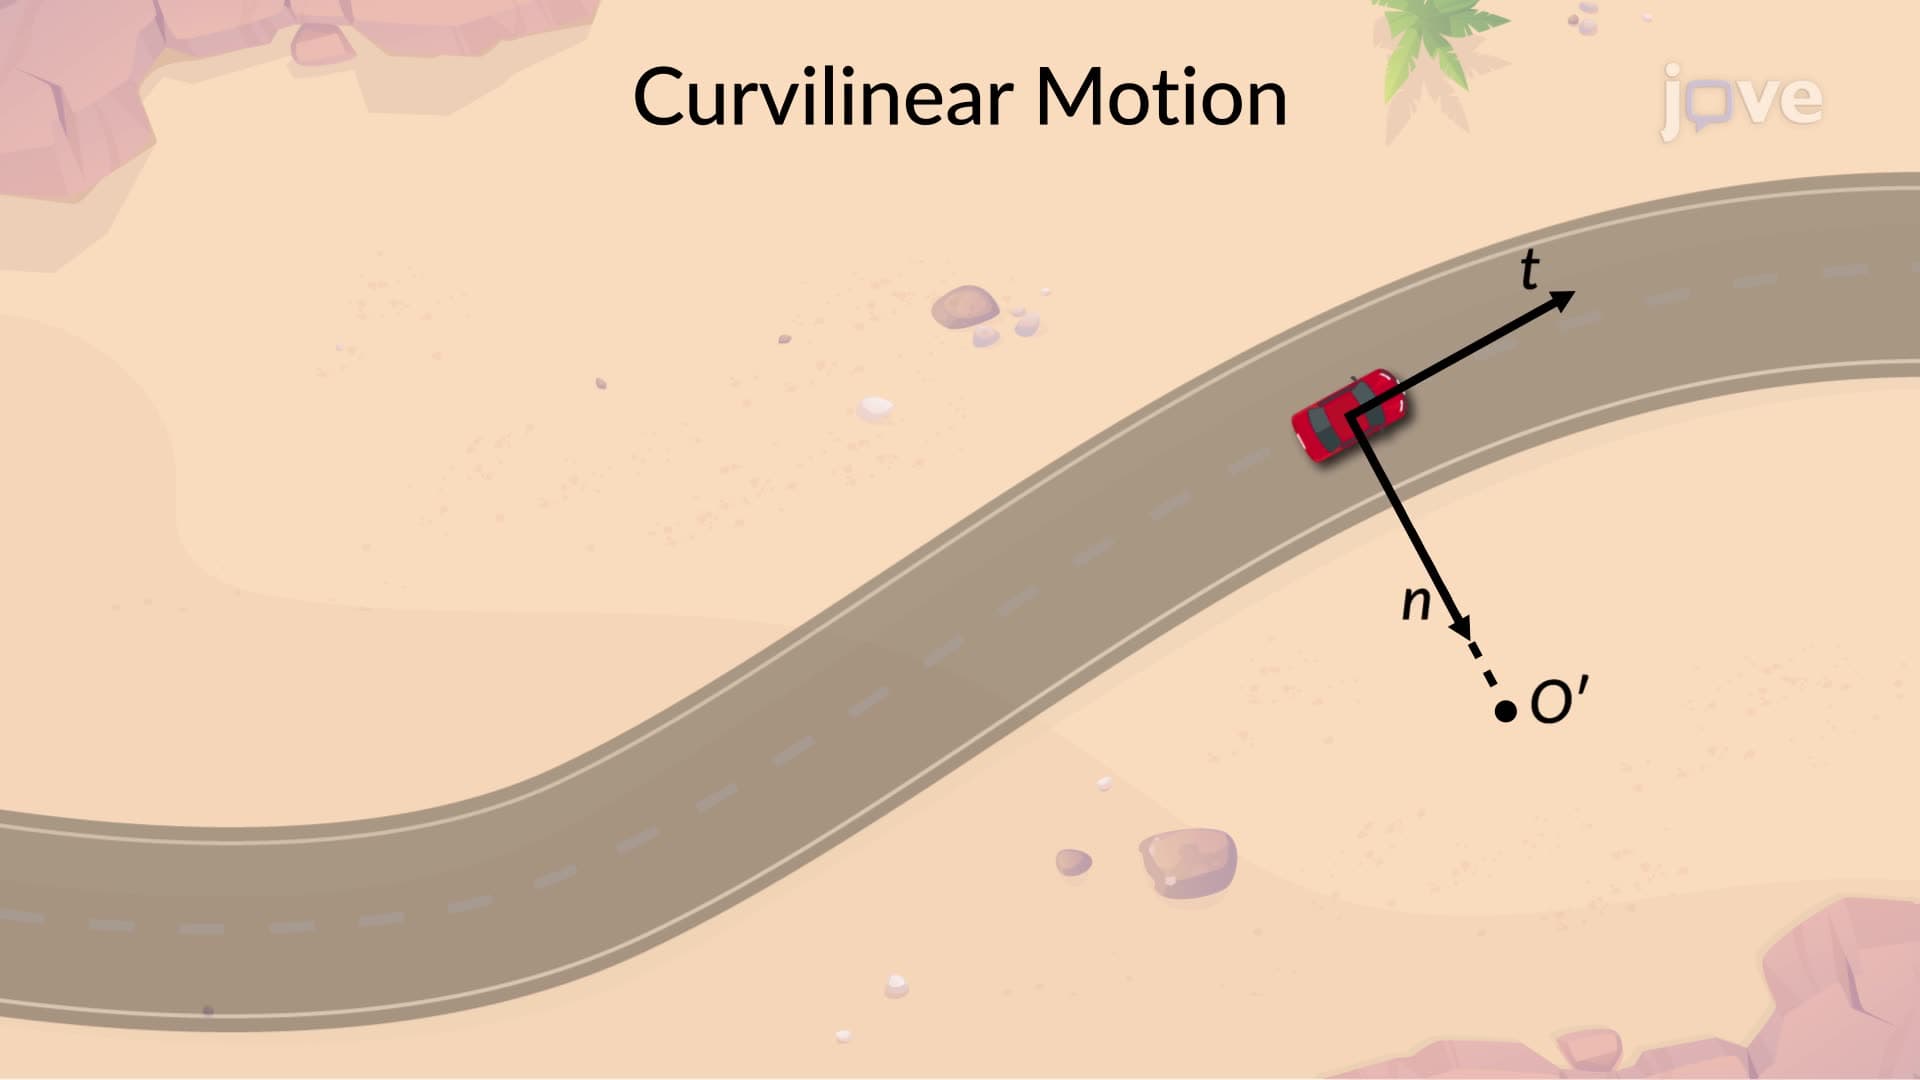
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:27
The Normal and Binormal Vectors
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...