Related Experiment Video
Updated: Sep 26, 2026
Investigating the Deployment of Visual Attention Before Accurate and Averaging Saccades via Eye Tracking and Assessment of Visual Sensitivity
Published on: March 18, 2019
A distributed model of the saccade system: simulations of temporally perturbed saccades using position and velocity
1Research Center, Mitsubishi Chemical Corporation, Japan

Abstract:
Interrupted saccades, movements that are perturbed in mid-flight by pulsatile electrical stimulation in the omnipause neuron region, are known to achieve final eye displacements with accuracies that are similar to normal saccades even in the absence of visual input following the perturbation. In an attempt to explain the neurophysiological basis for this phenomenon, the present paper describes a model of the saccadic system that represents the superior colliculus as a dynamic two-dimensional, topographically arranged array of laterally interconnected units. A distributed feedback pathway to the colliculus from downstream elements, providing both eye position and velocity signals is incorporated in the model. With the help of a training procedure based on a genetic algorithm and gradient descent, the model is optimized to produce both the normal as well as slow saccades with similar accuracy. The slow movements are included in the training set to mimic the accurate saccades that occur despite alterations in alertness, as well as following various degenerative oculomotor diseases. Although interrupted saccades were not included in the training set, the model is able to produce accurate movement of this type as an emergent property for a wide range of perturbed eye velocity trajectories. Our model demonstrates for the first time, that by means of an appropriate feedback mechanism, a single-layered dynamic network can be made to retain a distributed memory of the remaining ocular displacement error even for interrupted and slow saccades. These results support the hypothesis that saccades are controlled by error feedback of signals that code efference copies of eye motion, and further, suggest a possible answer to a long standing question about the kind of the feedback signal, if any, that is received by the superior colliculus during saccadic eye movements.
More Related Videos
Related Concept Videos
 01:34
Velocity and Position by Graphical Method
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:31
Motion in Space: Velocity and Acceleration
 01:11
Relative Velocity in Two Dimensions
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
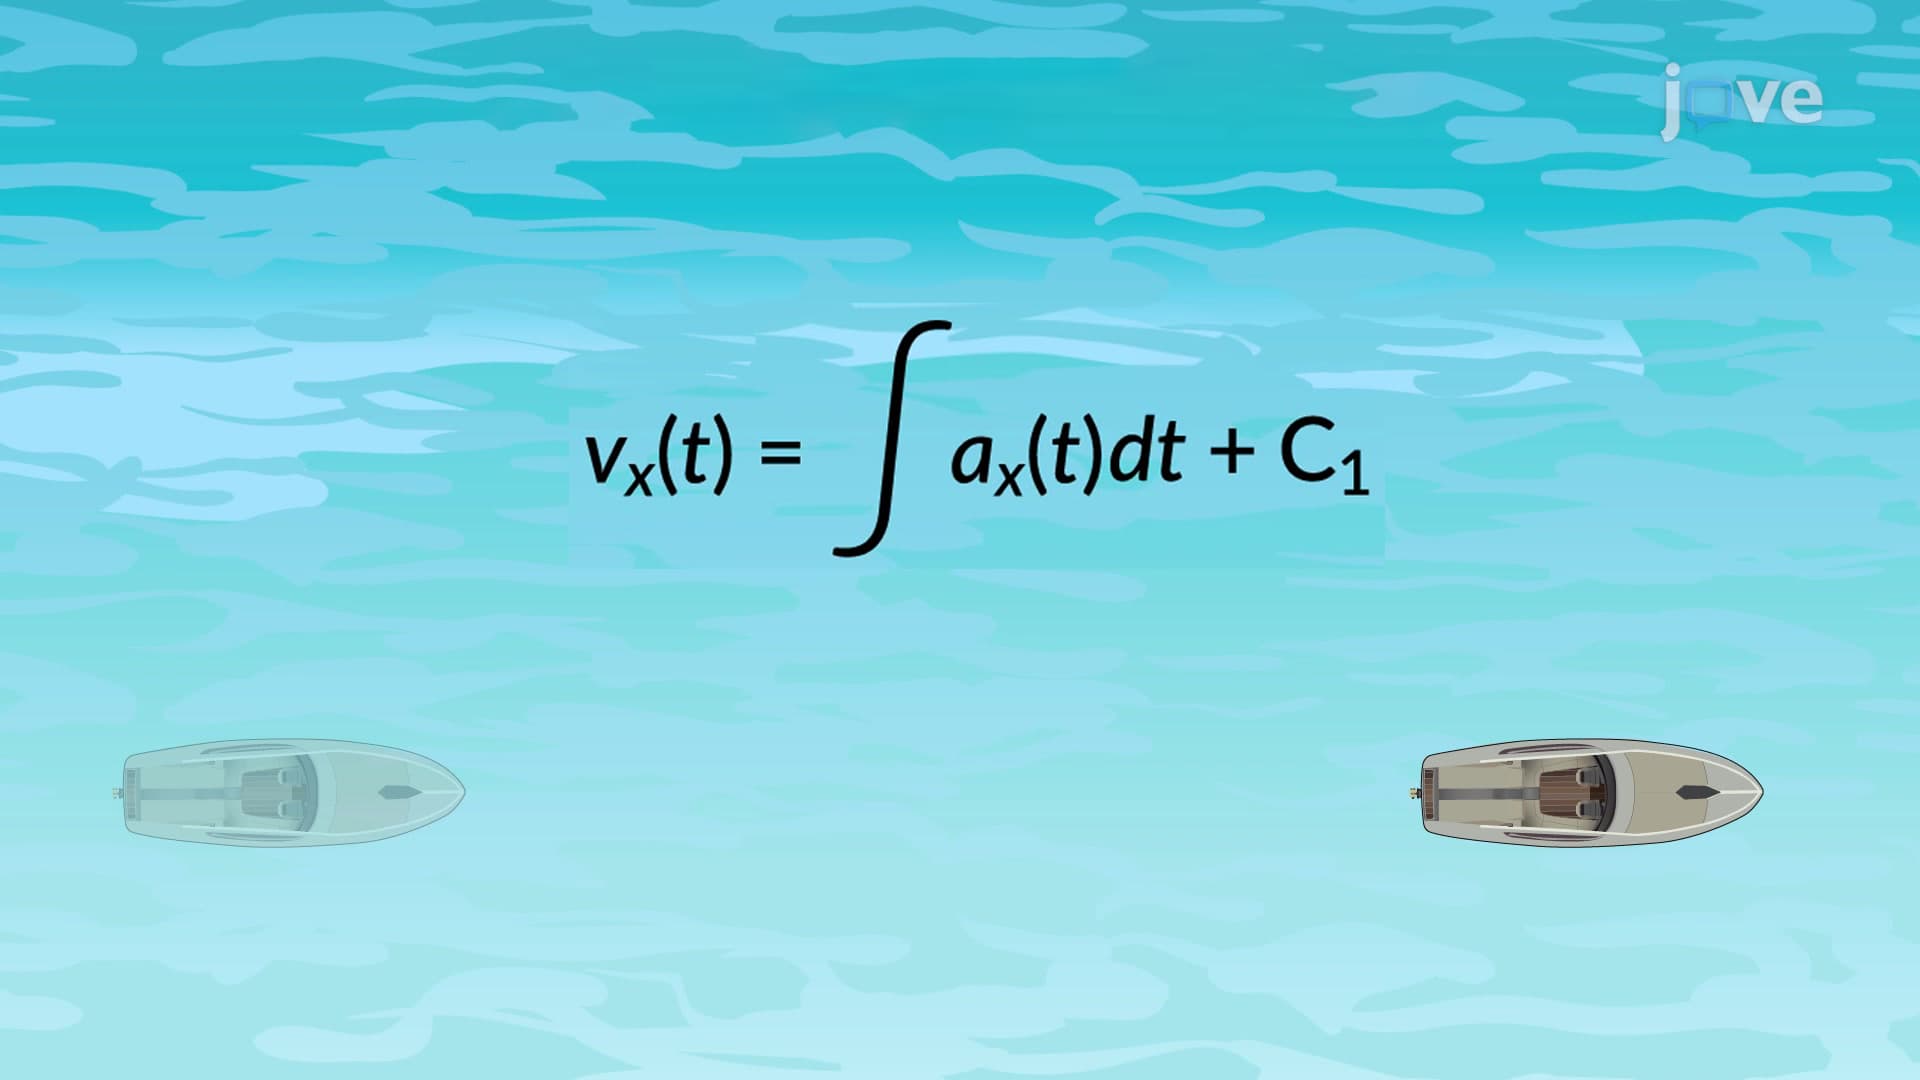 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...