Related Experiment Videos
Adaptive internal state space construction method for reinforcement learning of a real-world agent
1Faculty of Engineering, Tokyo University of Agriculture and Technology, Nakachi 2-24-26 Koganei, Tokyo, Japan

Abstract:
One of the difficulties encountered in the application of the reinforcement learning to real-world problems is the construction of a discrete state space from a continuous sensory input signal. In the absence of a priori knowledge about the task, a straightforward approach to this problem is to discretize the input space into a grid, and to use a lookup table. However, this method suffers from the curse of dimensionality. Some studies use continuous function approximators such as neural networks instead of lookup tables. However, when global basis functions such as sigmoid functions are used, convergence cannot be guaranteed. To overcome this problem, we propose a method in which local basis functions are incrementally assigned depending on the task requirement. Initially, only one basis function is allocated over the entire space. The basis function is divided according to the statistical property of locally weighted temporal difference error (TD error) of the value function. We applied this method to an autonomous robot collision avoidance problem, and evaluated the validity of the algorithm in simulation. The proposed algorithm, which we call adaptive basis division (ABD) algorithm, achieved the task using a smaller number of basis functions than the conventional methods. Moreover, we applied the method to a goal-directed navigation problem of a real mobile robot. The action strategy was learned using a database of sensor data, and it was then used for navigation of a real machine. The robot reached the goal using a smaller number of internal states than with the conventional methods.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
State Space to Transfer Function
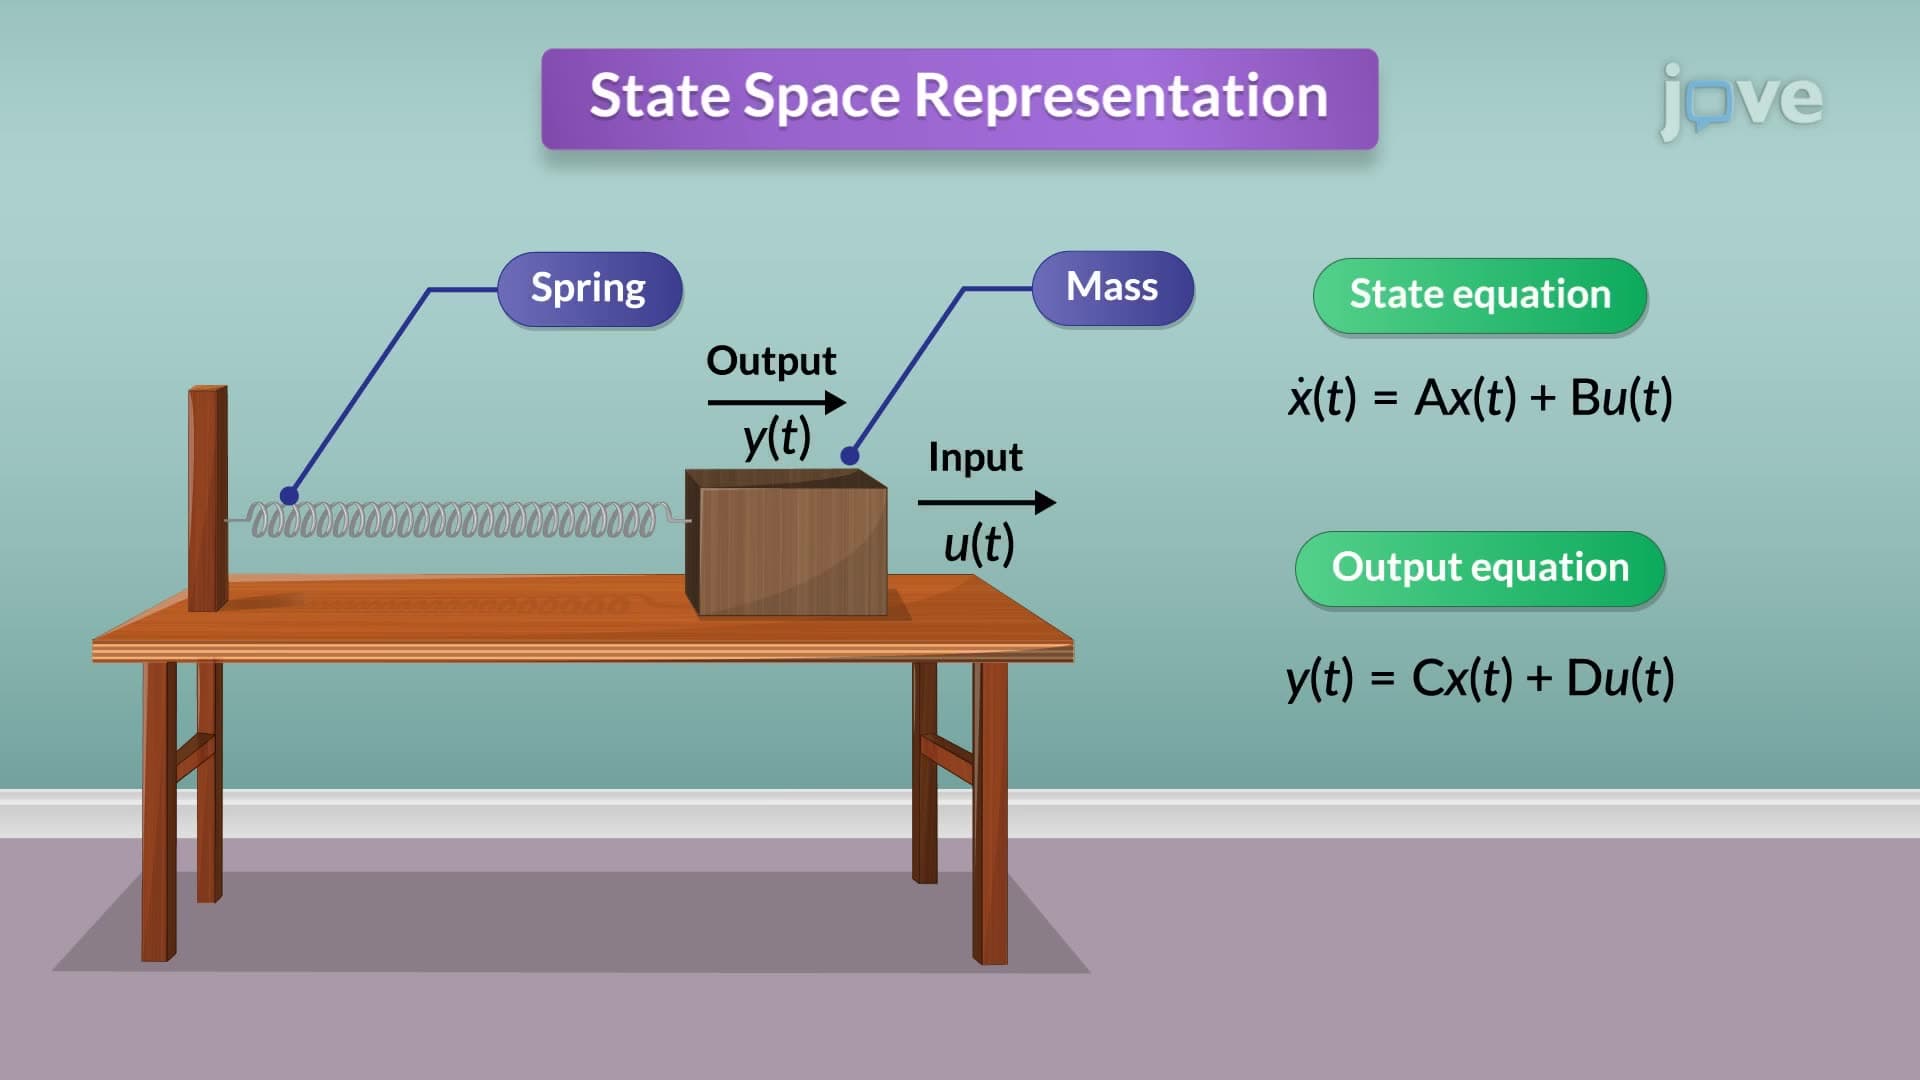
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:16
Statically Indeterminate Problem Solving
 01:23
Transfer Function to State Space
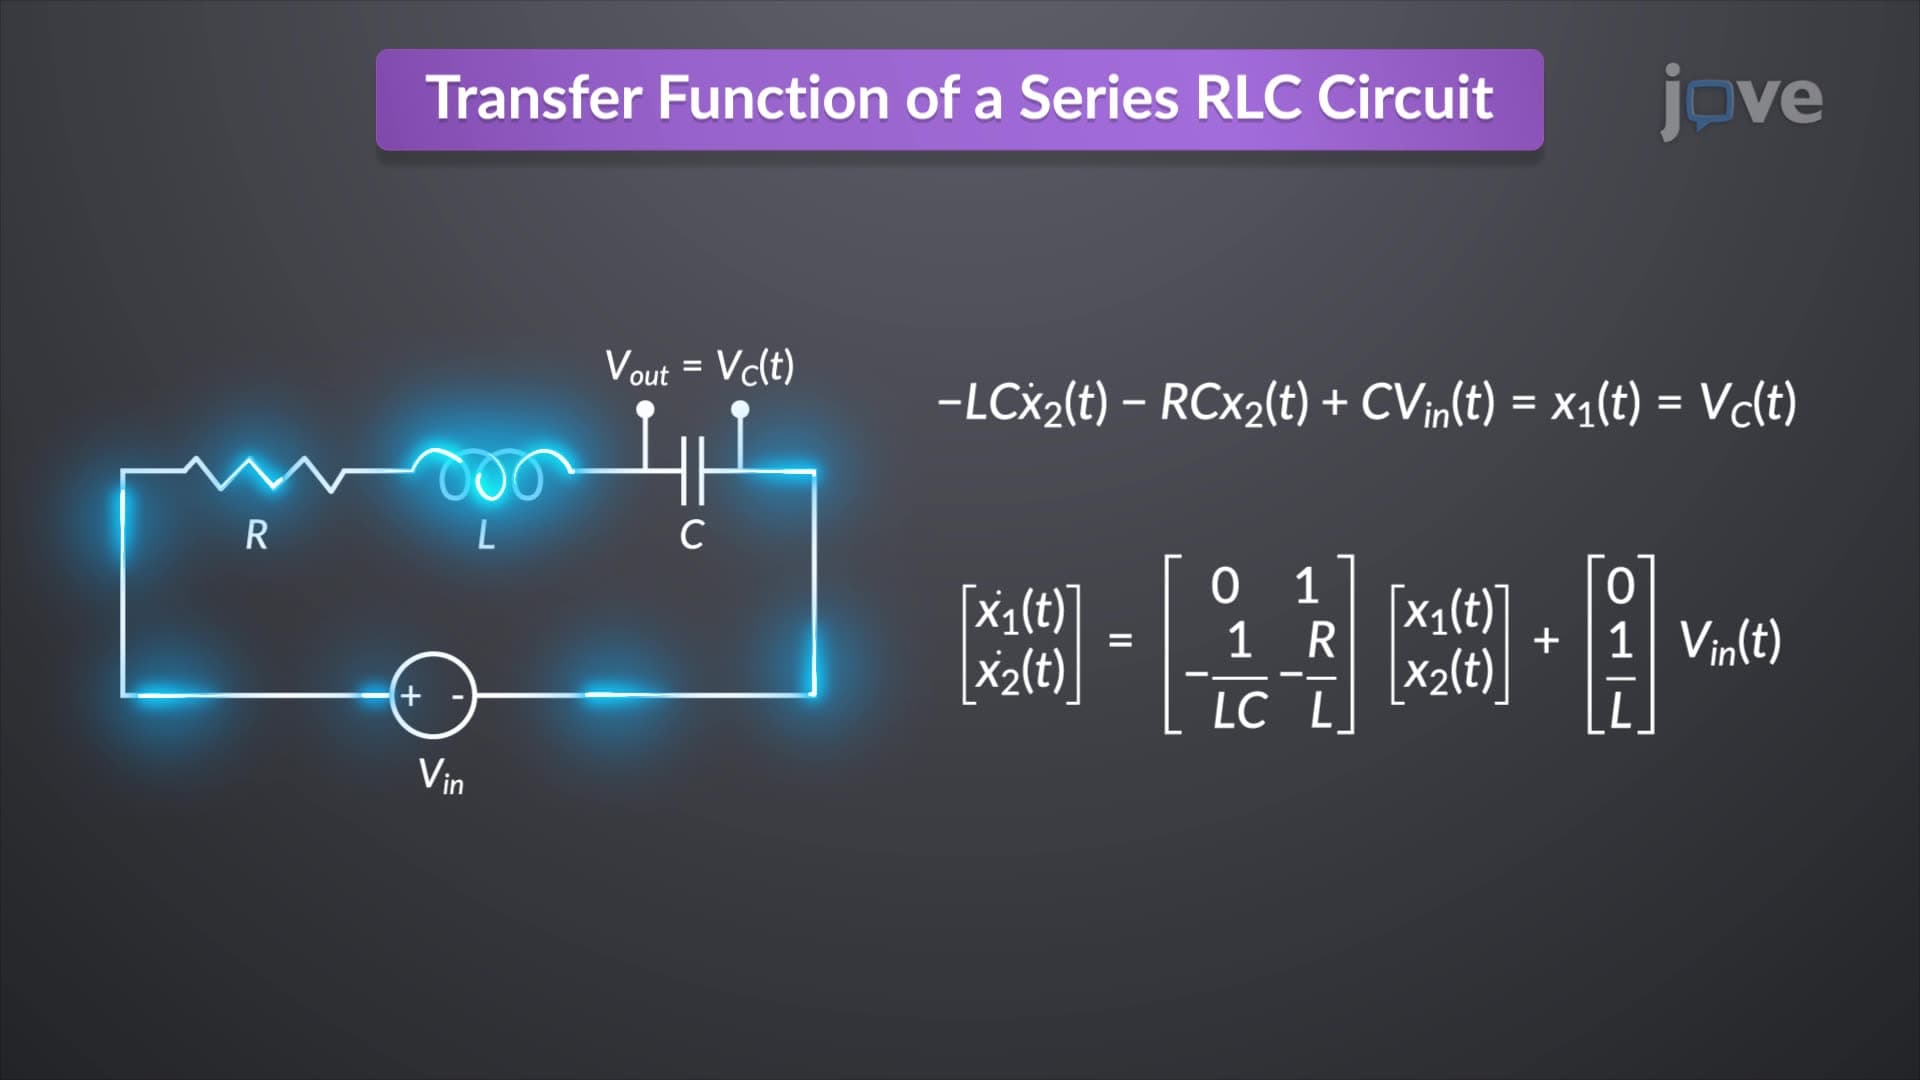
In an RLC...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...