Related Experiment Videos
Reinforcement learning-based predefined-time secure control for fractional-order nonlinear systems with sensor and
Chunyu Liang1, Fang Wang1, Zhen Wang1
1College of Mathematics and Systems Science, Shandong University of Science and Technology, Qingdao, 266590, China.

Abstract:
A secure control problem is investigated for constrained fractional-order nonlinear systems subject to both sensor and actuator attacks. To handle the effects induced by the dual attacks, a nonlinear mapping-based coordinate transformation is elaborately introduced to convert the original state-constrained system into an unconstrained form. Furthermore, by integrating reinforcement learning with predefined-time stability analysis, an adaptive control strategy is developed to achieve predefined-time convergence. The proposed method enhances the transient response of the system while accelerating the convergence of both the tracking error and the policy learning process. A novel reset-based self-triggered mechanism is proposed. On the one hand, the developed mechanism reduces communication load and eliminates the need for continuous state monitoring. On the other hand, the sampling intervals can be adaptively adjusted according to the system states, thereby further alleviating the computational burden. Under the developed control strategy, the closed-loop system is guaranteed to achieve semi-global practical predefined-time stability, and all signals converge to a bounded neighborhood of the origin within the predefined time.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
First Order Systems
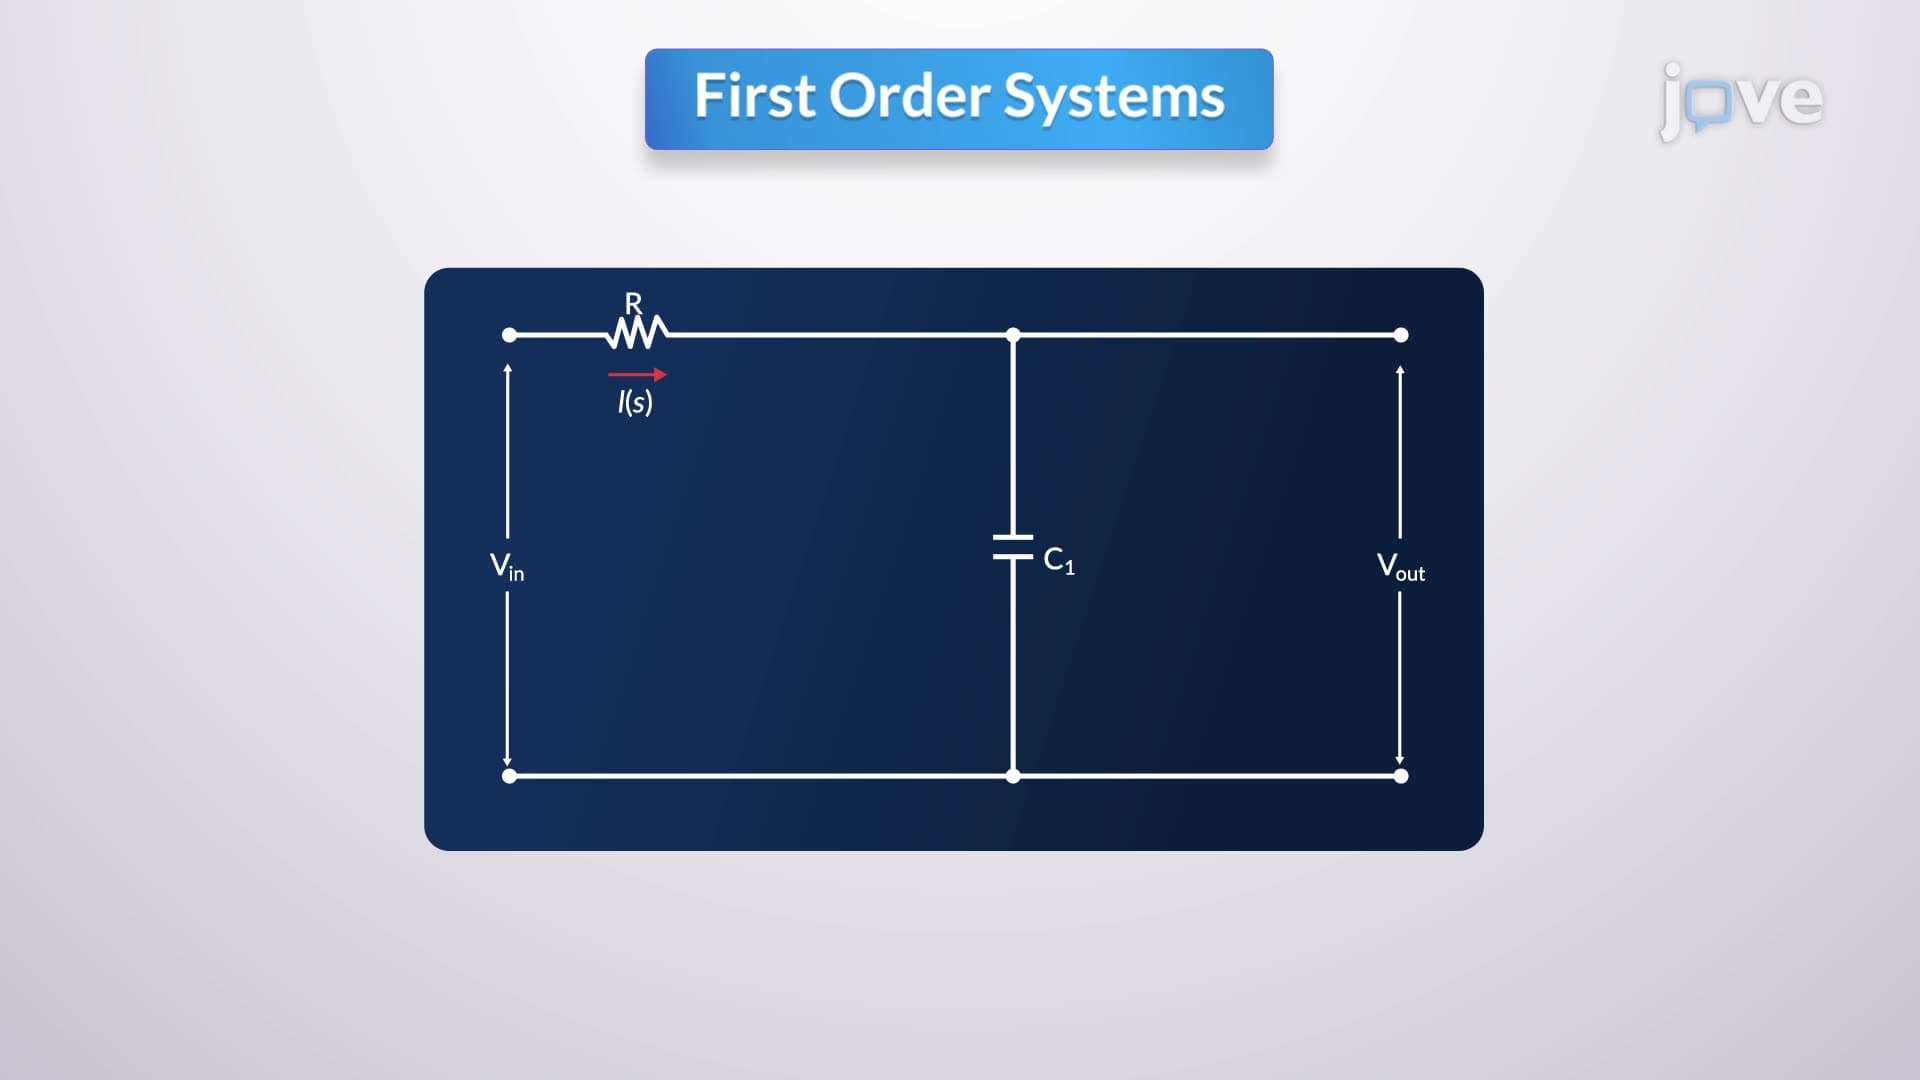
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...