Related Experiment Video
Updated: Sep 26, 2026
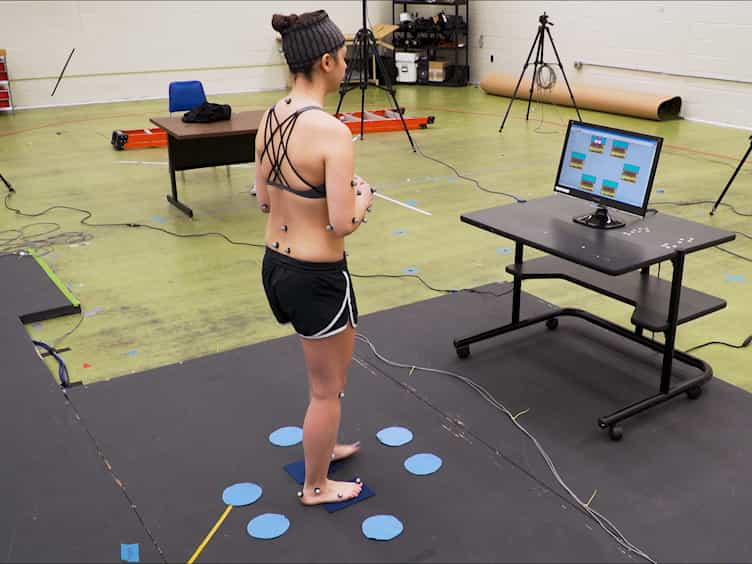

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Isotropic sequence order learning
Bernd Porr1, Florentin Wörgötter
1Department of Psychology, University of Stirling, Scotland. bp1@cn.stir.ac.uk

Abstract:
In this article, we present an isotropic unsupervised algorithm for temporal sequence learning. No special reward signal is used such that all inputs are completely isotropic. All input signals are bandpass filtered before converging onto a linear output neuron. All synaptic weights change according to the correlation of bandpass-filtered inputs with the derivative of the output. We investigate the algorithm in an open- and a closed-loop condition, the latter being defined by embedding the learning system into a behavioral feedback loop. In the open-loop condition, we find that the linear structure of the algorithm allows analytically calculating the shape of the weight change, which is strictly heterosynaptic and follows the shape of the weight change curves found in spike-time-dependent plasticity. Furthermore, we show that synaptic weights stabilize automatically when no more temporal differences exist between the inputs without additional normalizing measures. In the second part of this study, the algorithm is is placed in an environment that leads to closed sensor-motor loop. To this end, a robot is programmed with a prewired retraction reflex reaction in response to collisions. Through isotropic sequence order (ISO) learning, the robot achieves collision avoidance by learning the correlation between his early range-finder signals and the later occurring collision signal. Synaptic weights stabilize at the end of learning as theoretically predicted. Finally, we discuss the relation of ISO learning with other drive reinforcement models and with the commonly used temporal difference learning algorithm. This study is followed up by a mathematical analysis of the closed-loop situation in the companion article in this issue, "ISO Learning Approximates a Solution to the Inverse-Controller Problem in an Unsupervised Behavioral Paradigm" (pp. 865-884).
Related Concept Videos
 01:26
Per-Unit Sequence Models
Zero-sequence currents, which are identical in magnitude and phase, generate a neutral current, resulting in voltage drops across the neutral impedance and the low-voltage winding. If the...
 01:26
Introduction to Sequences
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:29
Sequences
 01:05
Maxam-Gilbert Sequencing
Challenges of the Maxam-Gilbert Method
The...
 01:26
Convergence of Sequences