Centric-minded templates for self-motion perception
Related Experiment Video
Updated: Sep 25, 2026

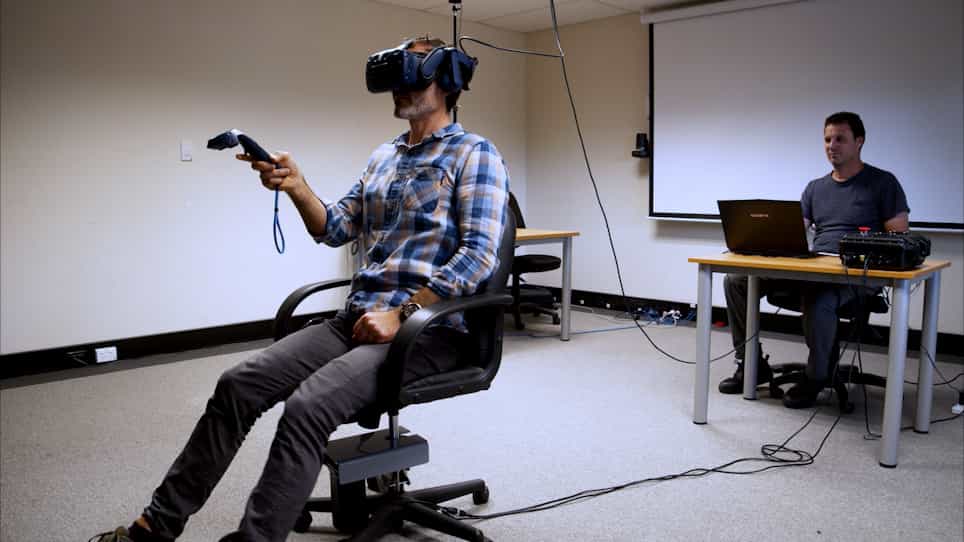
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Paolo Cavalleri1, Silvio P Sabatini, Fabio Solari
1Department of Biophysical and Electronic Engineering, University of Genoa, Via all'Opera Pia 11/A, 16145, Genova, Italy.

Abstract:
We propose a two-layer neuromorphic architecture by which motion field pattern, generated during locomotion, are processed by template detectors specialized for gaze-directed self-motion (expansion and rotation). The templates provide a gaze-centered computation for analyzing motion field in terms of how it is related to the fixation point (i.e., the fovea). The analysis is performed by relating the vectorial components of the act of motion to variations (i.e., asymmetries) of the local structure of the motion field. Notwithstanding their limited extension in space, such centric-minded templates extract, as a whole, global information from the input flow field, being sensitive to different local instances of the same global property of the vector field with respect to the fixation point; a quantitative analysis, in terms of vectorial operators, evidences this property as tuning curves for heading direction. Model performances, evaluated in several situations characterized by conditions of absence and presence of pursuit eye movements, validate the approach. We observe that the gaze-centered model provides an explicit testable hypothesis that can guide further explorations of visual motion processing in extrastriate cortical areas.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:03
Inertial Frames of Reference
 01:26
Rotational Motion about a Fixed Axis
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
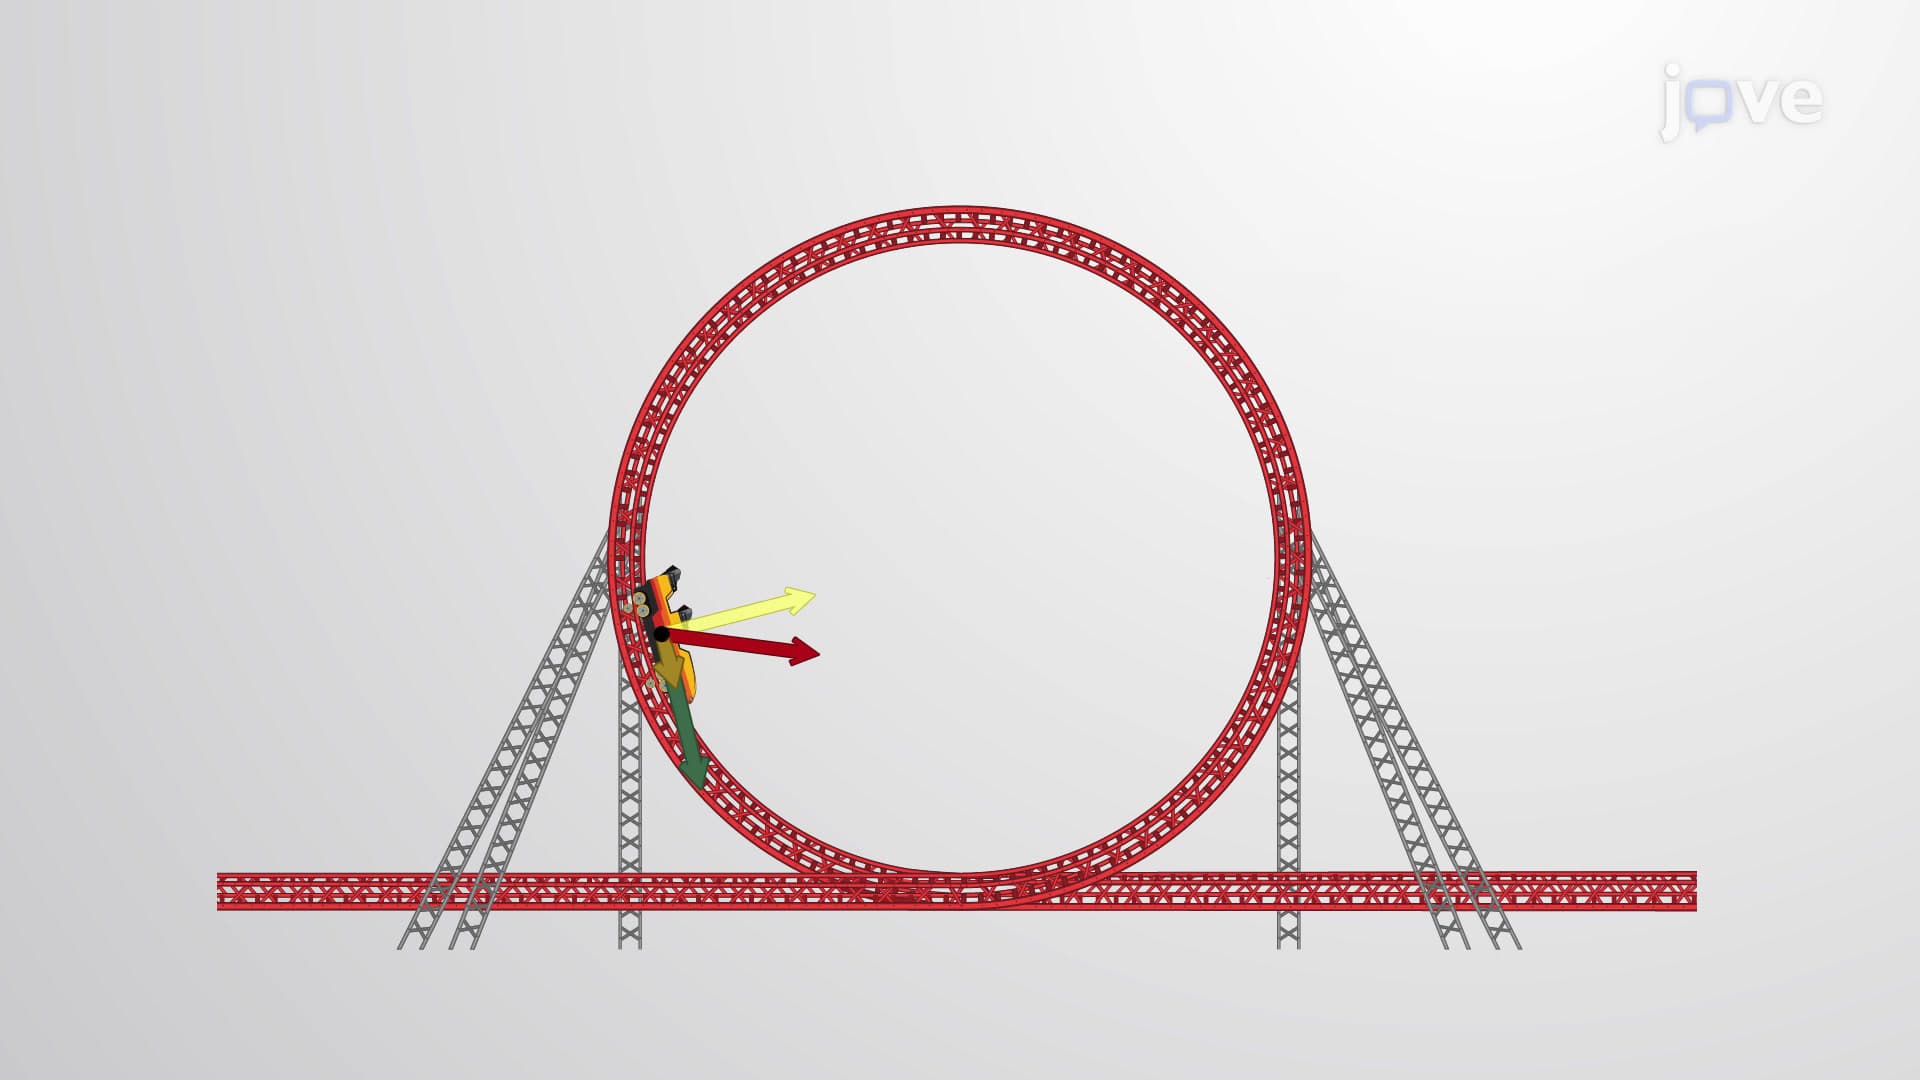
Non-uniform Circular Motion
For example, such accelerations...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...