Impulse response due to jumping on shoes of various stiffness and damping

W Qassem1

  • 1Hijjawi Faculty for Engineering Technology, Yarmouk University, Irbid, Jordan.

Related Concept Videos

Static and Kinetic Frictional Force01:05

Static and Kinetic Frictional Force

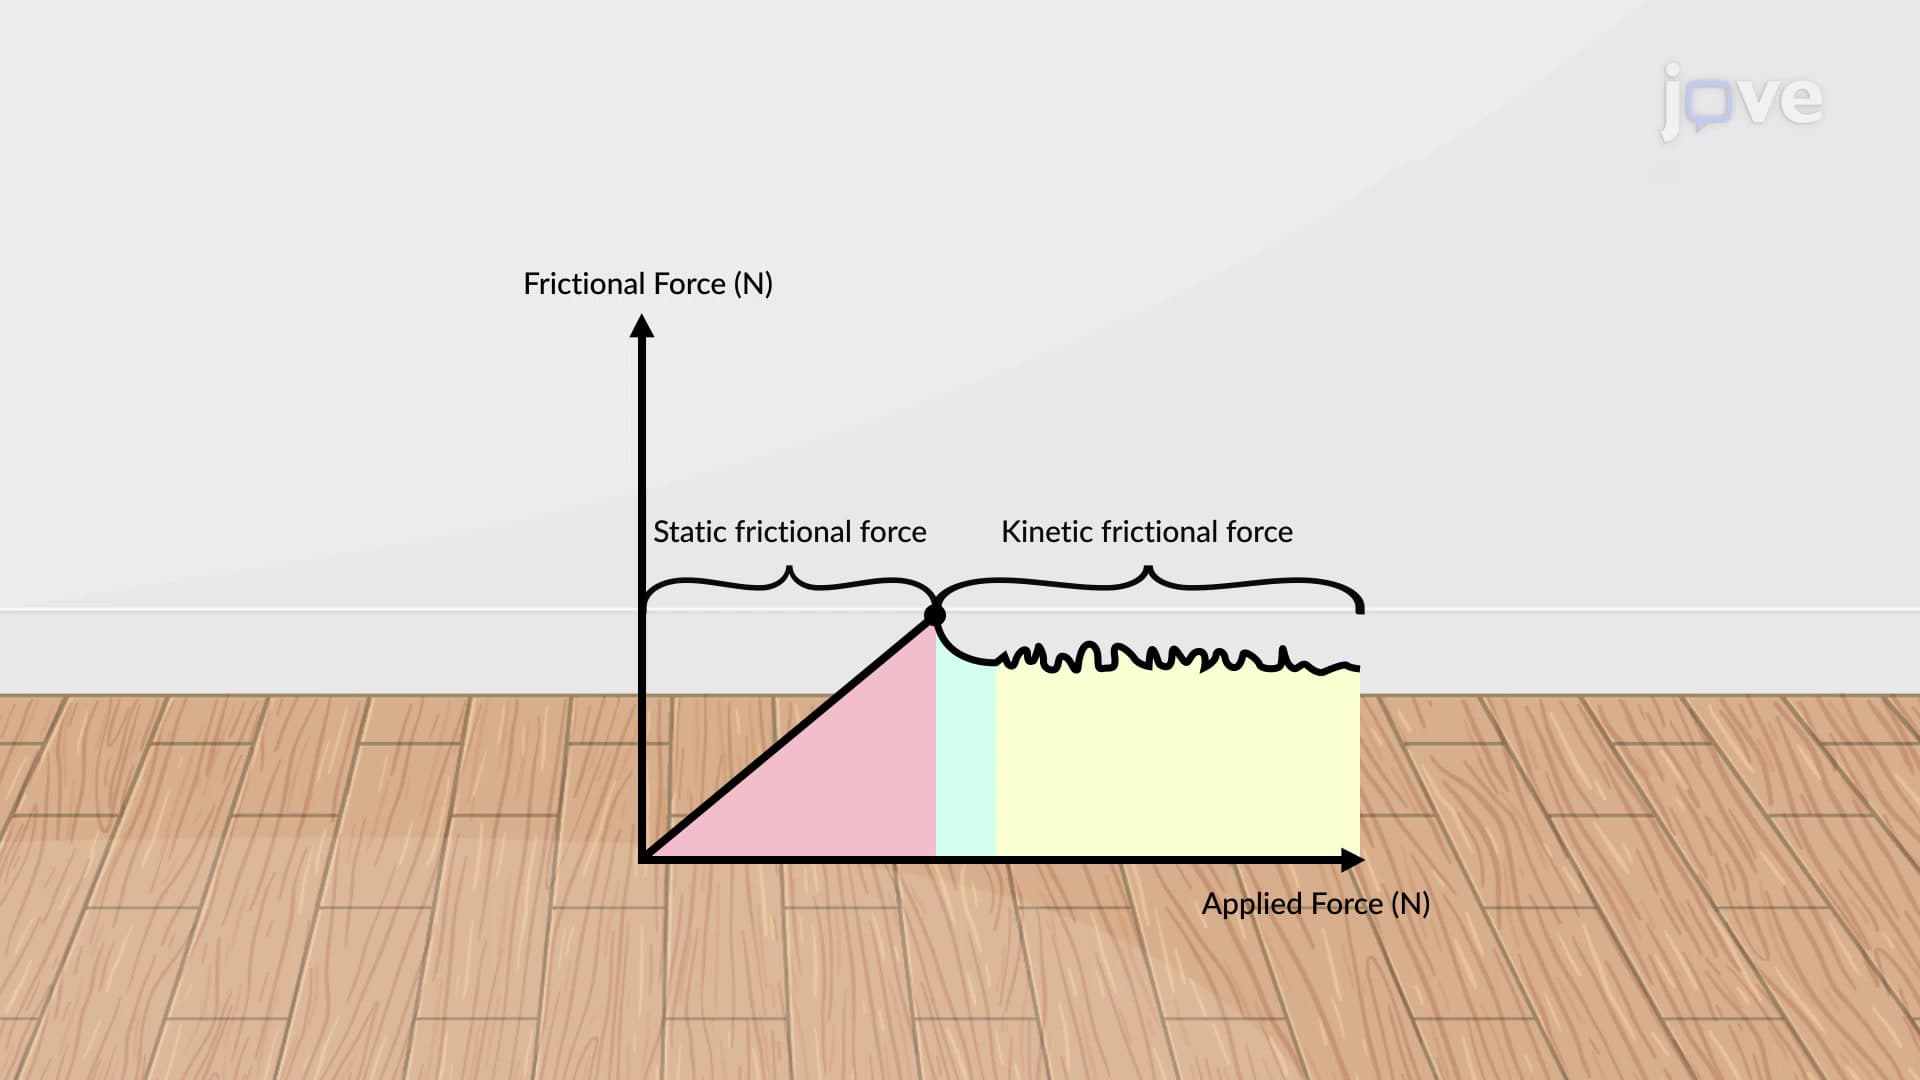
One of the simpler characteristics of sliding friction is that it is parallel to the contact surfaces between systems, and is always in a direction that opposes the motion or attempted motion of the systems relative to each other. If two systems are in contact and moving relative to one another, then the friction between them is called kinetic friction. For example, kinetic friction slows a hockey puck sliding on ice.
However, if two systems are in contact and are stationary relative to one...
Impulse-Momentum Theorem00:49

Impulse-Momentum Theorem

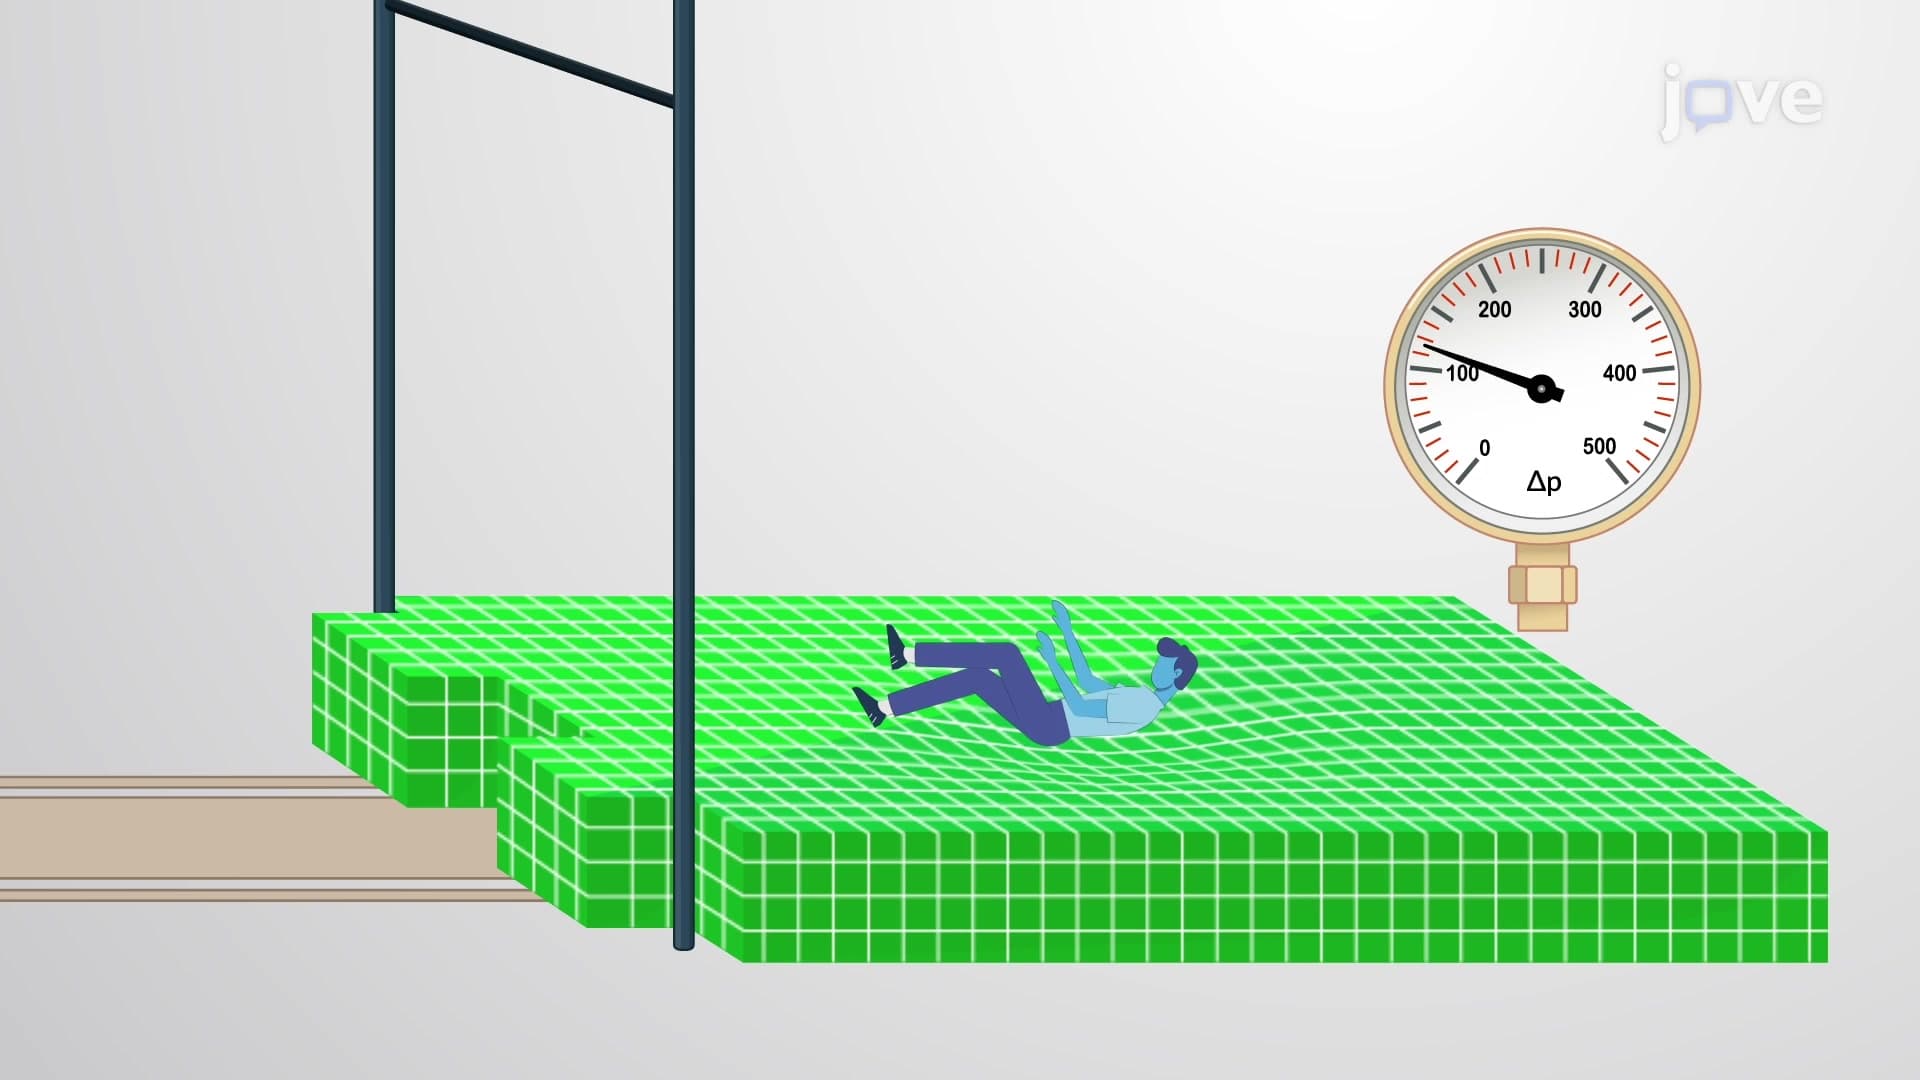
The total change in the motion of an object is proportional to the total force vector acting on it and the time over which it acts. This product is called impulse, a vector quantity with the same direction as the total force acting on the object.
By writing Newton's second law of motion in terms of the momentum of an object and the external force acting on it, and simultaneously using the definition of the impulse vector, it can be shown that the total impulse on an object is equal to its net...
Damped Oscillations01:07

Damped Oscillations

In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Types of Damping01:20

Types of Damping

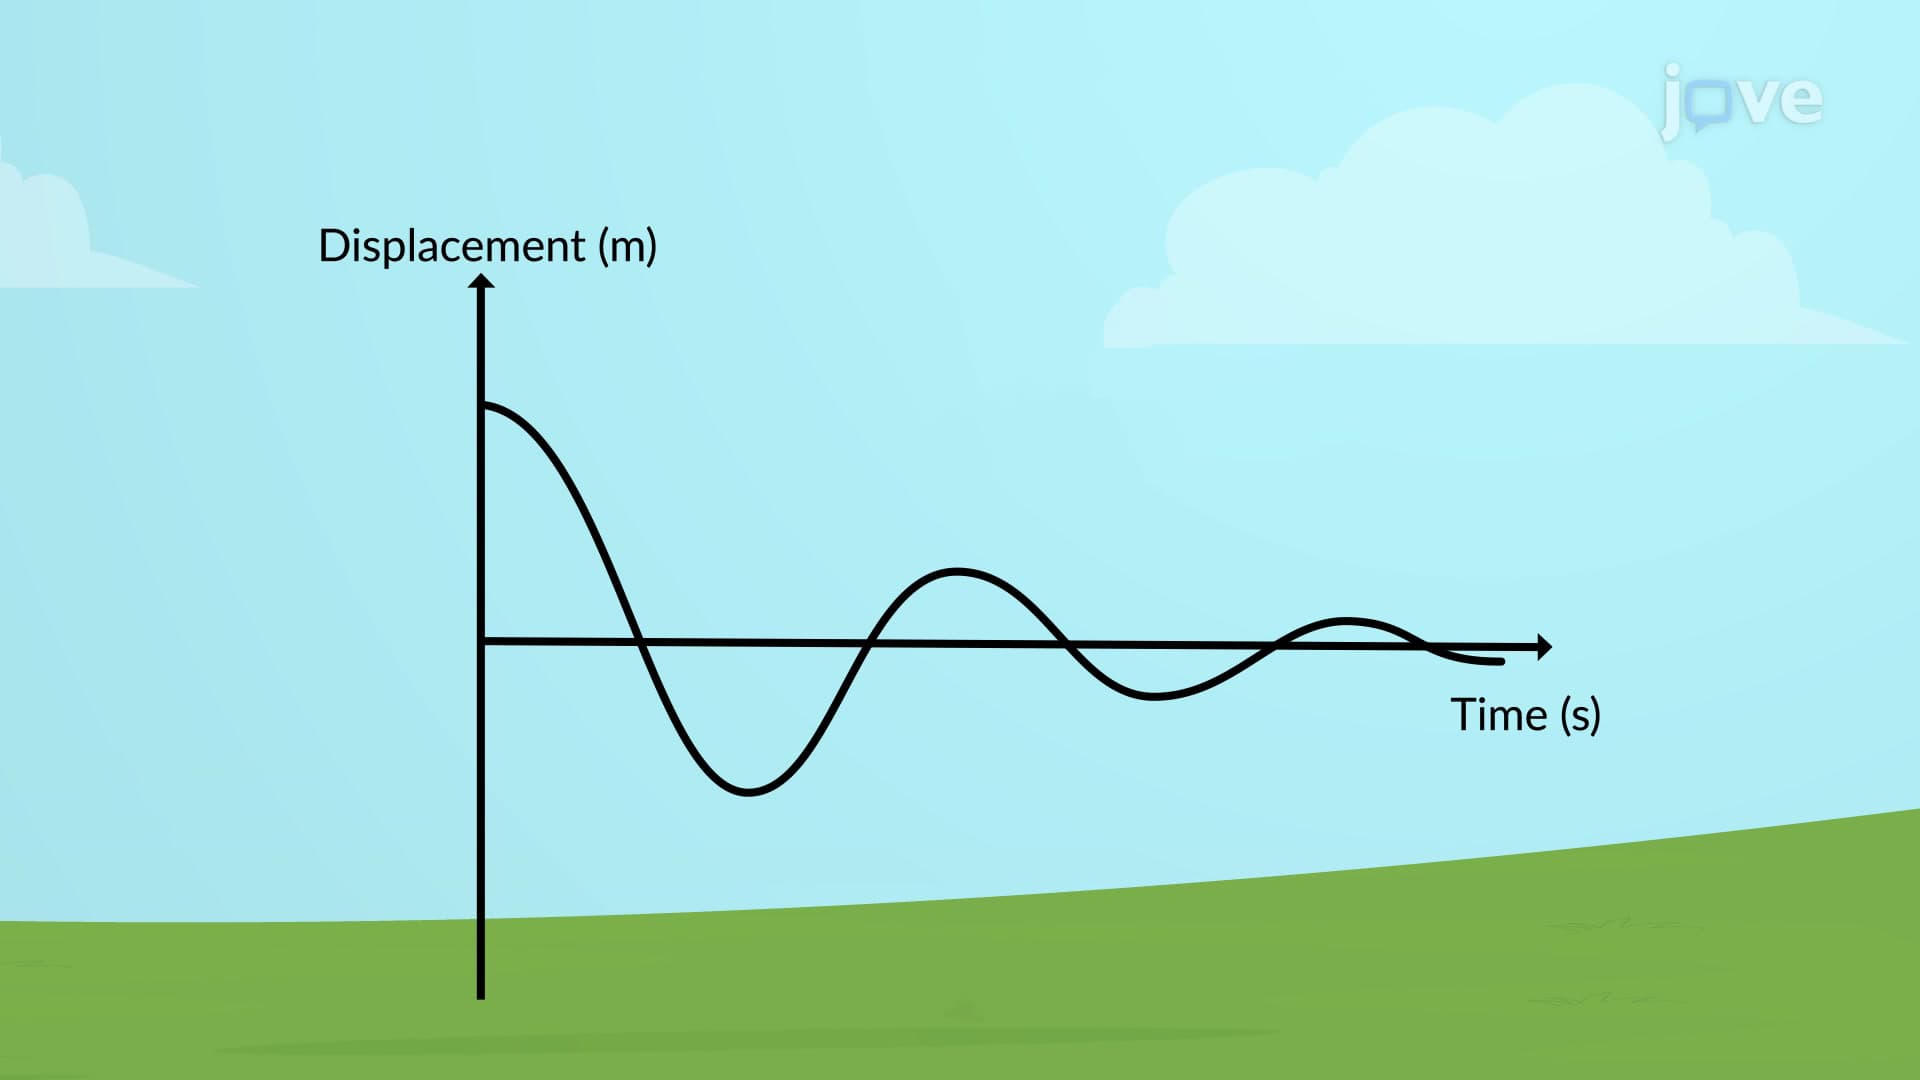
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
Principle of Angular Impulse and Momentum: Problem Solving01:19

Principle of Angular Impulse and Momentum: Problem Solving

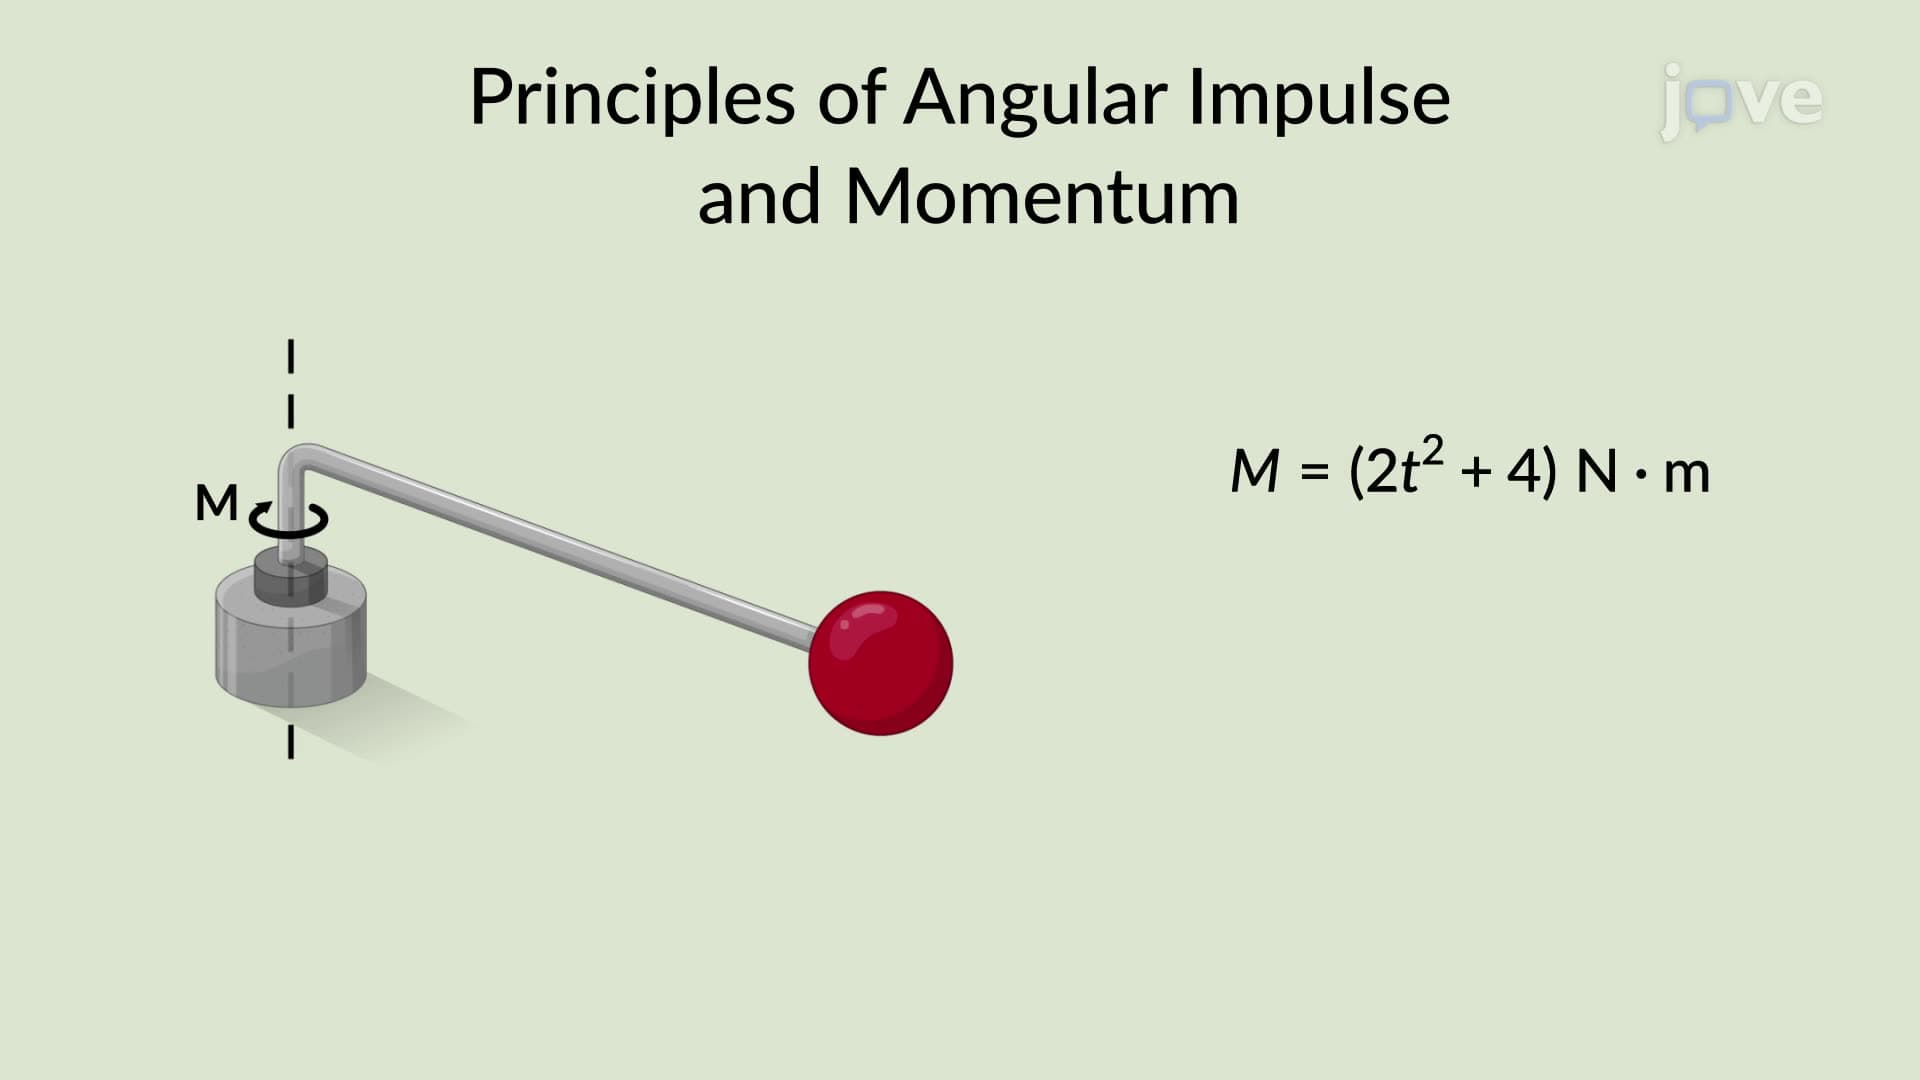
Consider a ball of mass m, attached to a massless rod of known length, subjected to a time-dependent torque. If the initial velocity of the mass is known, then the final velocity of the mass for time t can be determined using the principle of angular impulse and momentum.
Initially, a free-body diagram of the system is drawn to illustrate all the forces acting upon the system, providing a crucial understanding of the dynamics at play. Then, the principle of angular impulse and momentum is...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...