Search of jumping items: visual marking and discrete motion
Related Experiment Video
Updated: Sep 25, 2026
Eye Movements in Visual Duration Perception: Disentangling Stimulus from Time in Predecisional Processes
Published on: January 19, 2024
Elizabeth S Olds1, C Meghan McMurtry
1Department of Psychology, 75 University Avenue West, Wilfrid Laurier University, Waterloo, Ontario N2L 3C5, Canada. eolds@wlu.ca

Abstract:
Watson and Humphreys (1997 Psychological Review 104 90-122) showed that when searching for a target, observers can ignore a previewed set of distractors (other items), effectively decreasing the number of relevant items in a difficult search display and thus speeding performance ('visual marking'). Other researchers have more recently investigated visual marking for continuously moving items, finding that shared features, and preserved inter-item spatial relationships, are helpful. Here, we tested whether visual marking occurs for a set of initial items that moves in one discrete jump (preserving shared features and inter-item spatial relationships). Marking did not occur in these displays, and we interpret this result in the context of previous research on visual marking.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:16
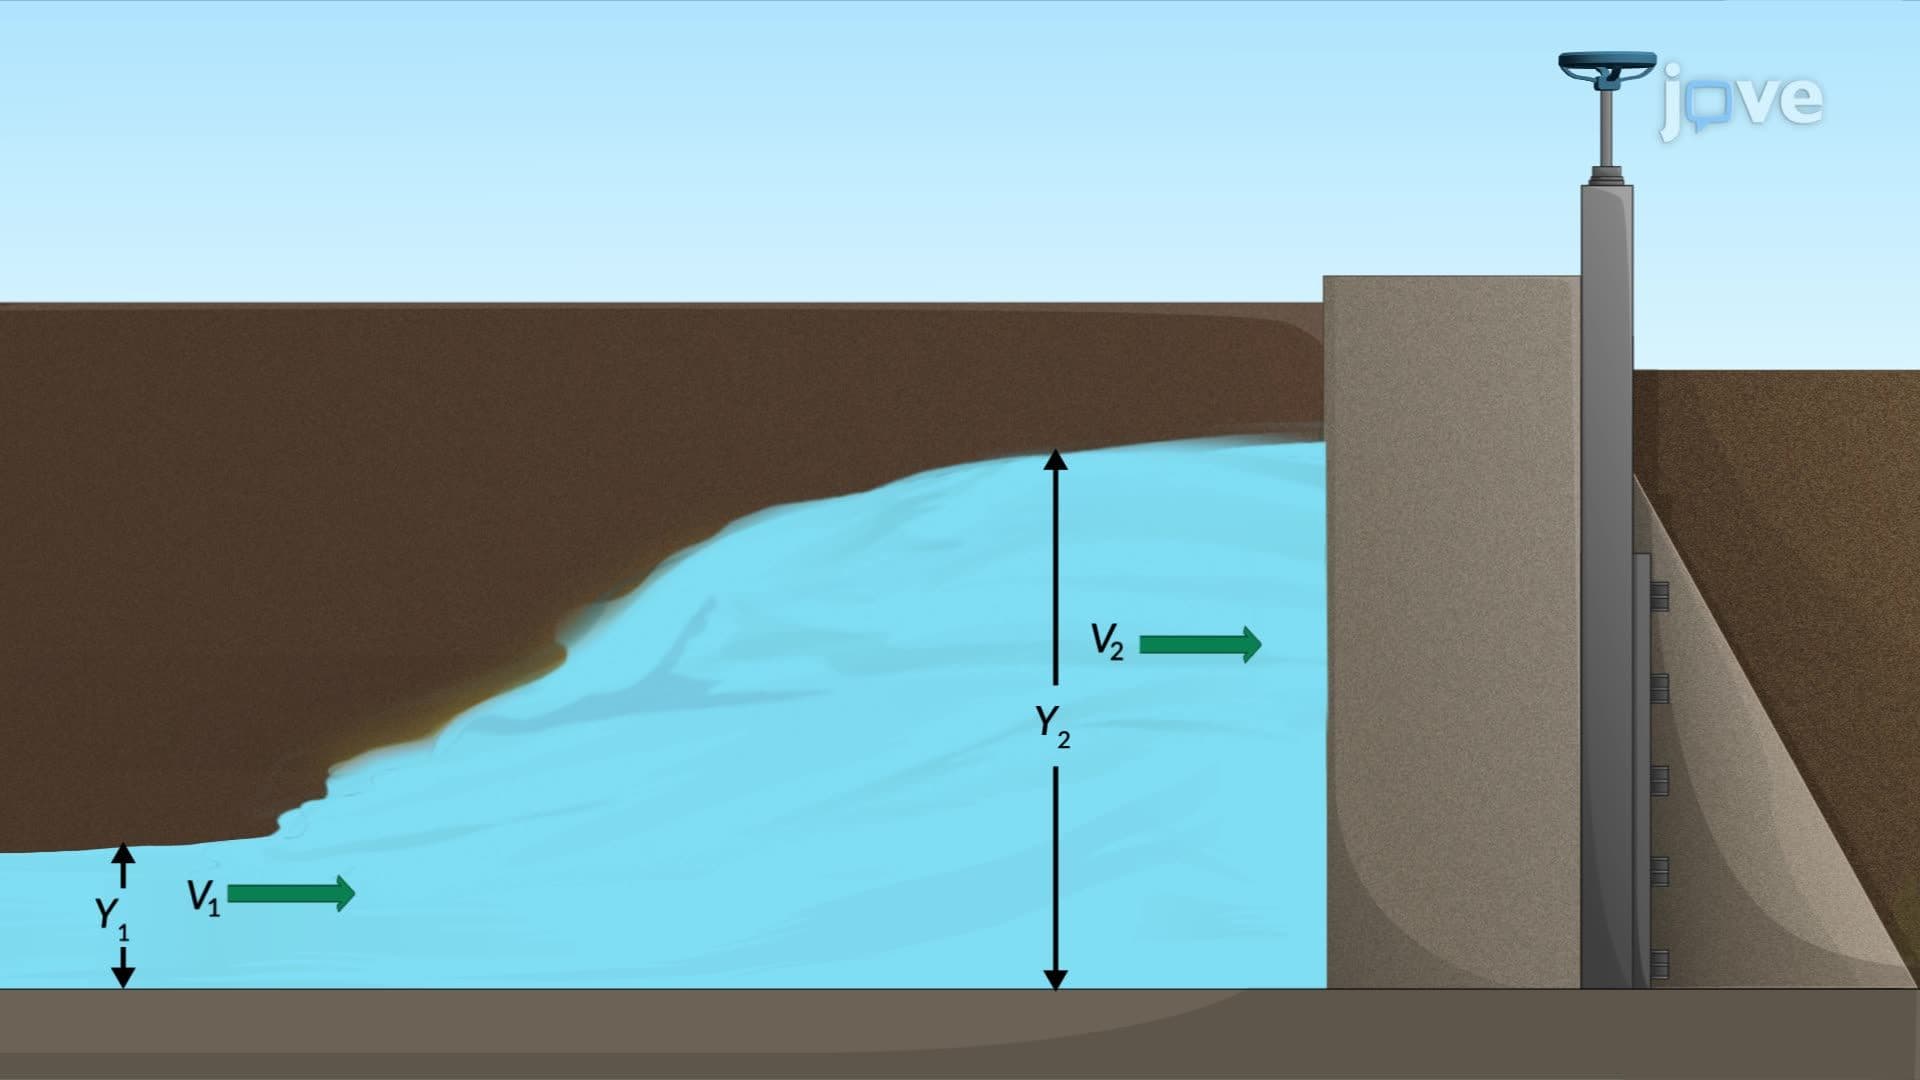
Hydraulic Jump: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:34
Velocity and Position by Graphical Method
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration