Related Experiment Video
Updated: Aug 5, 2026
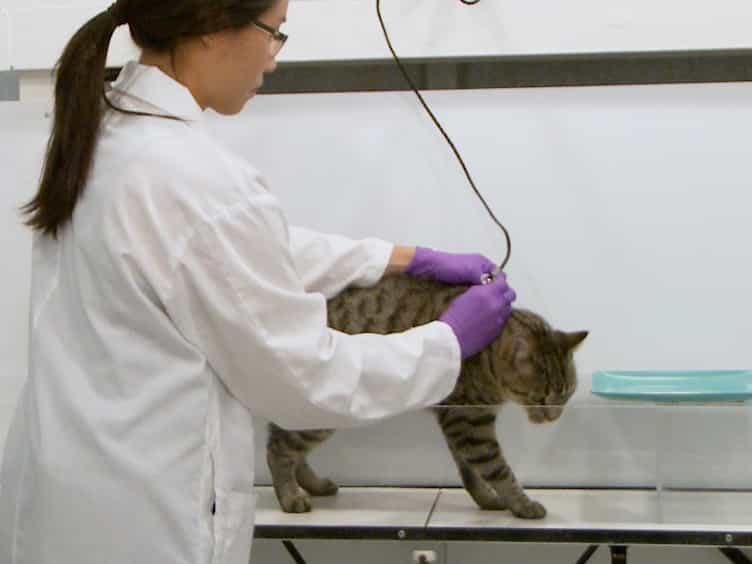
Reversible Cooling-induced Deactivations to Study Cortical Contributions to Obstacle Memory in the Walking Cat
Published on: December 11, 2017
Locomotor adjustments for circumvention of an obstacle in the travel path
Lori Ann Vallis1, Bradford J McFadyen
1Department of Human Biology and Nutritional Sciences, College of Biological Science, University of Guelph, Animal Science/Nutrition Bldg, Guelph, Ontario, N1G 2W1, Canada. lvallis@uoguelph.ca

Abstract:
Independent living requires the navigation of a surrounding environment which is often cluttered with obstacles. When walking around an obstacle in the travel path, safe clearance requires some degree of body-segment reorientation. While body-segmental coordination strategies have been well studied for steering tasks that require moving the body in a new walking direction, it has never been established just what coordination strategies are used in different walking tasks. To address this issue, the current study was designed to investigate the timing of body segment coordination strategies and whole-body anticipatory locomotor adjustments employed when circumventing an obstacle placed in the travel path. Six healthy adults were asked to walk at their natural pace during unobstructed walking, as well as during avoidance to the right or left of a cylindrical obstacle (OBS) located in the travel path. Data analyzed were center of mass (COM) clearance from the OBS, forward velocity, step length and width, yaw angles of the head and trunk, roll angle of the trunk, and medial-lateral COM displacement. Onset of change in these variables from unobstructed walking was calculated as the time from OBS crossing. Avoidance involved two equally used strategies: lead limb close to or away from the OBS during the crossing step. Medial-lateral COM deviations were controlled by changes in step width without changes in trunk roll. There were no differences in the onset times of body segment reorientation for path deviation. These results are in contrast to previous studies on change in travel direction where the head segment initiates the body reorientation. Contrary to a steering task, circumventing an obstacle requires a different coordination for a transient change in COM trajectory with the underlying travel-direction maintained.

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:10
Relative Motion Analysis - Acceleration
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:16
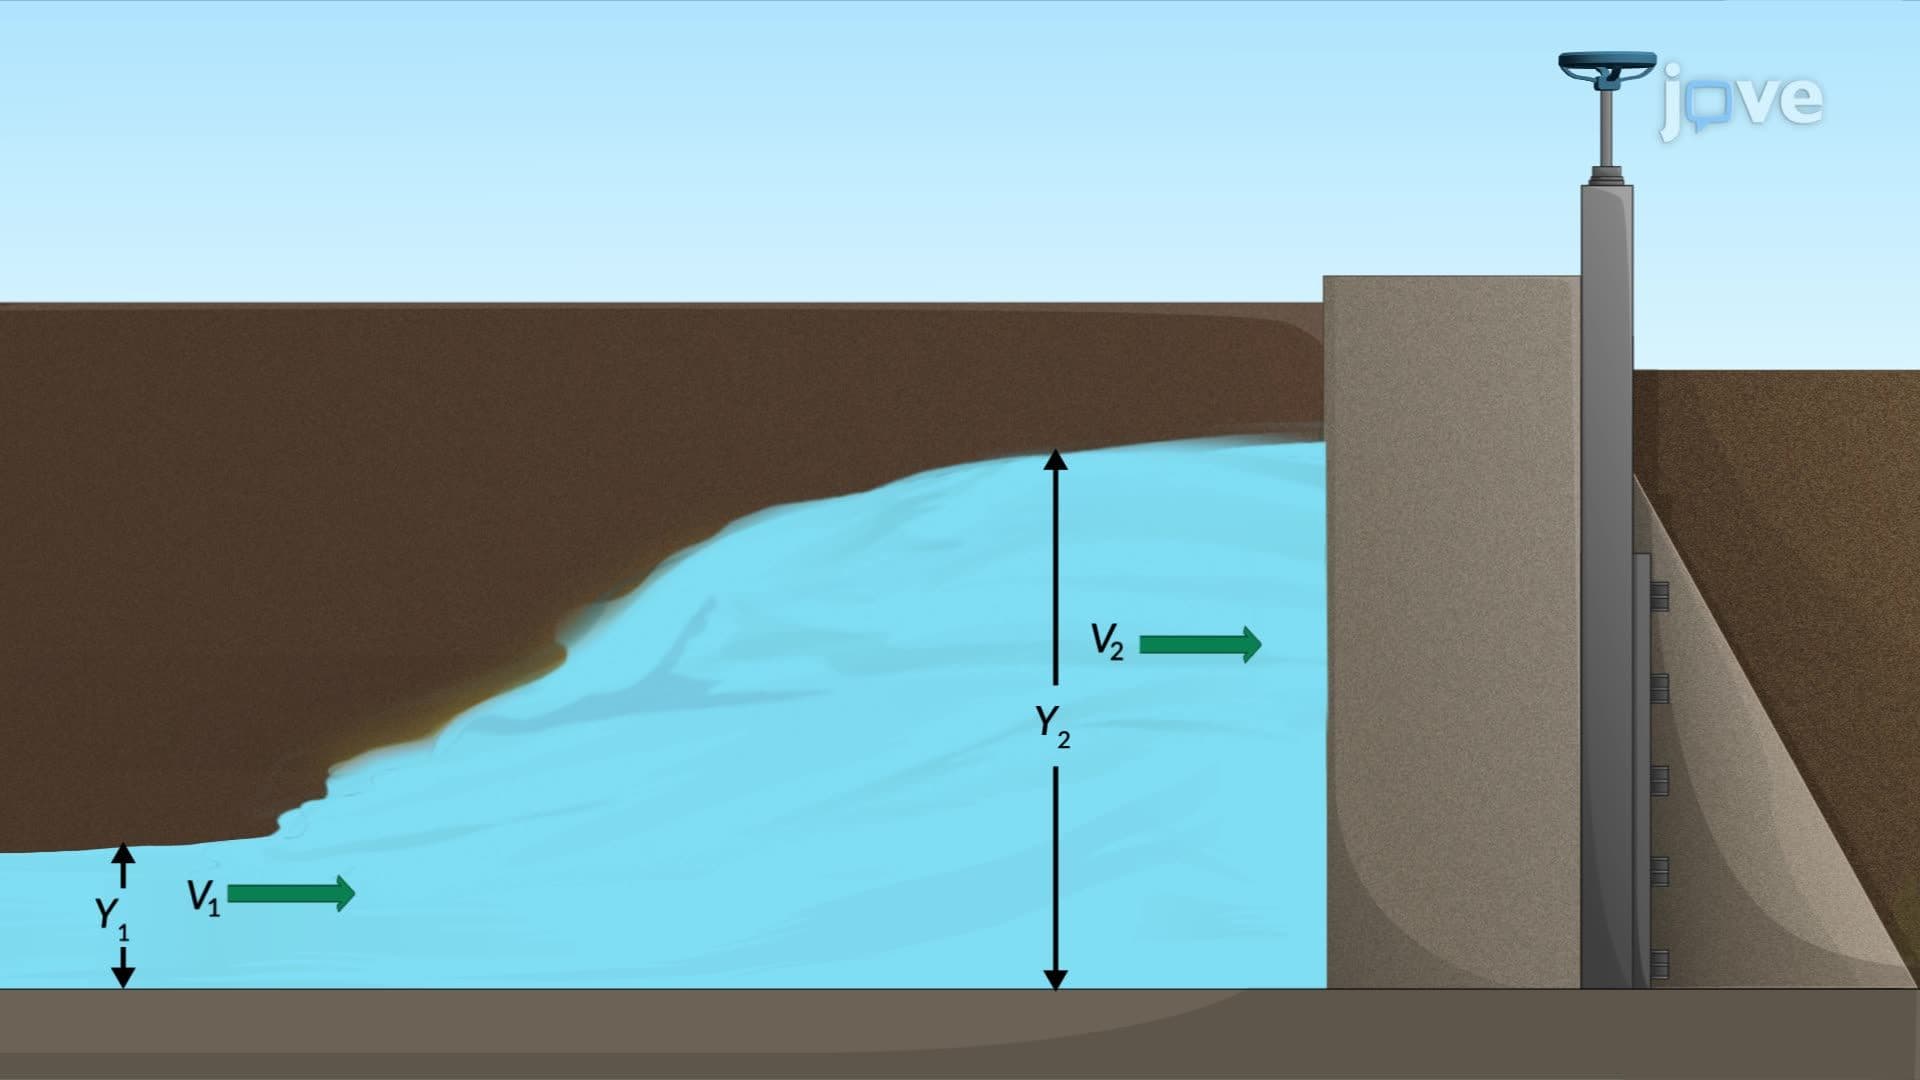
Hydraulic Jump: Problem Solving
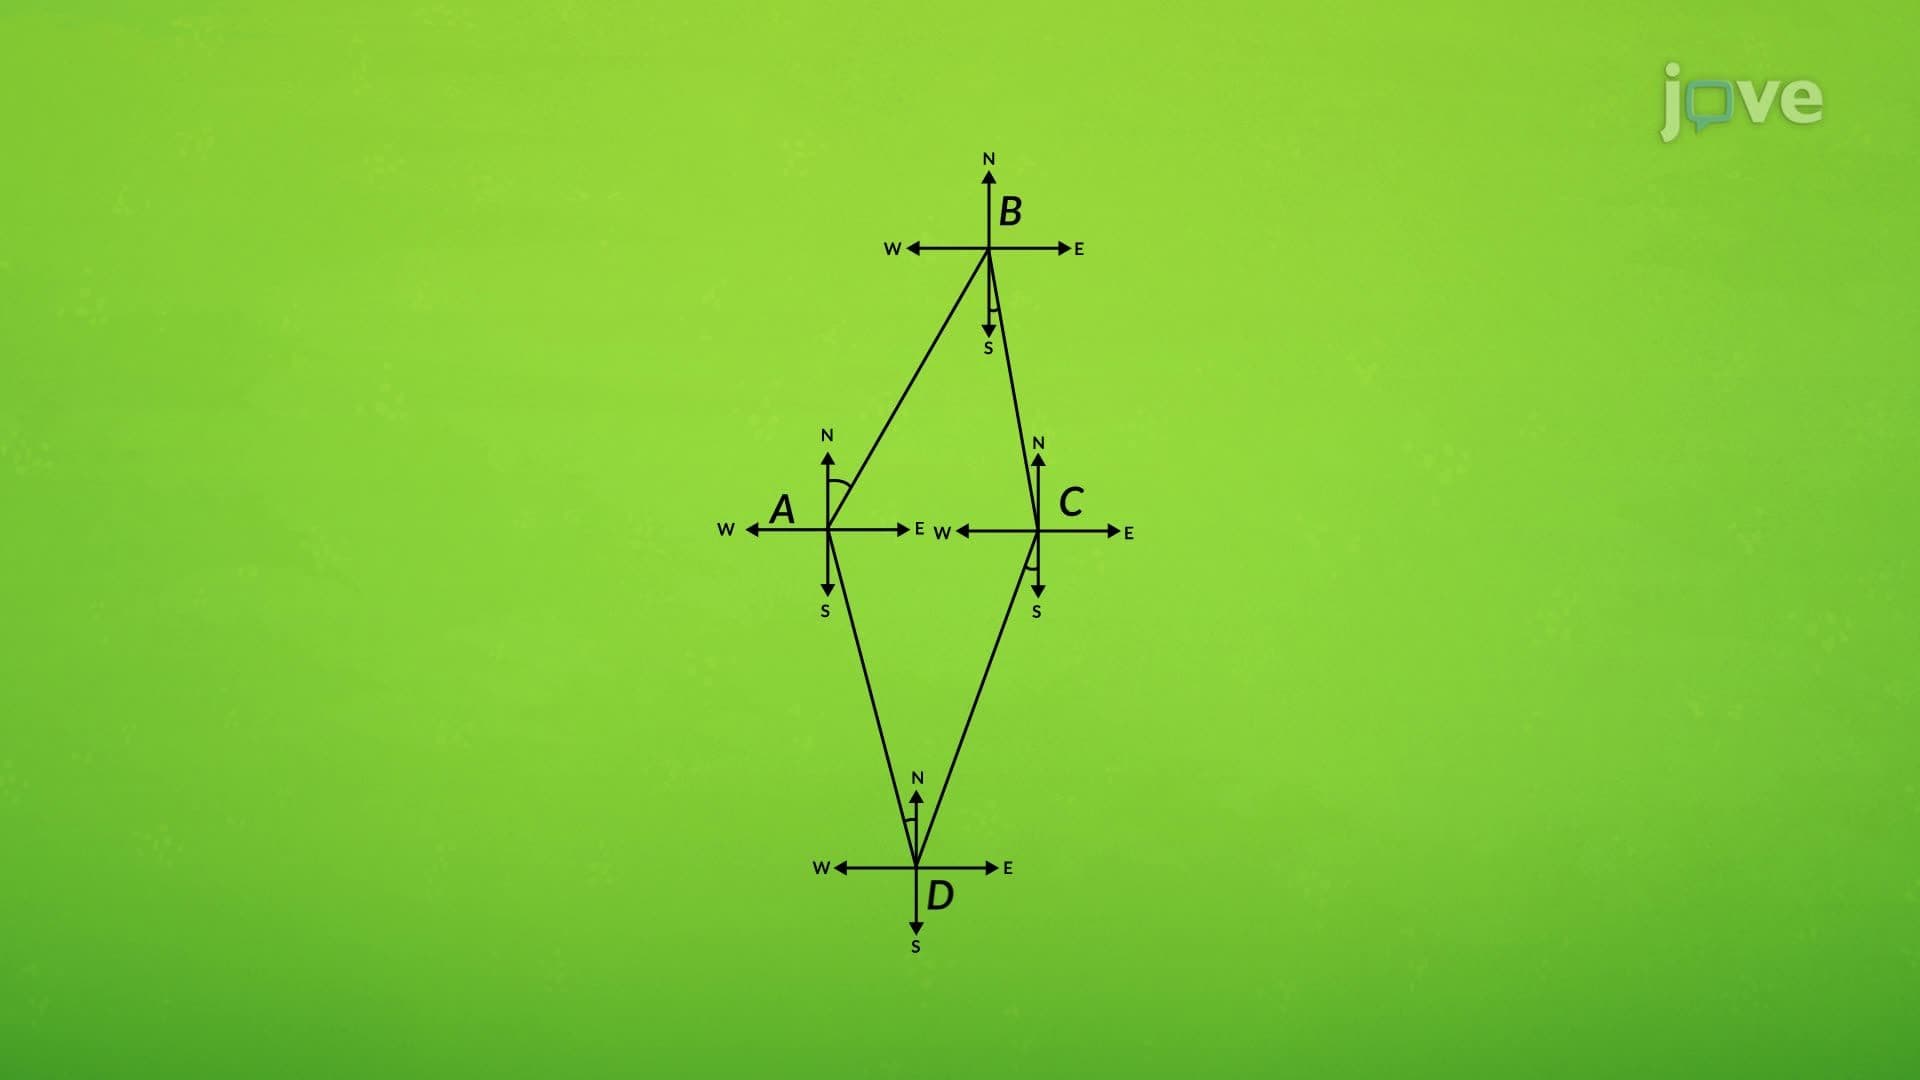 01:12
Adjusting a Traverse