Related Experiment Video
Updated: Sep 20, 2026

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Influence of interaction force levels on degree of motor adaptation in a stable dynamic force field
E J Lai1, A J Hodgson, T E Milner
1Department of Mechanical Engineering, University of British Columbia, 2324 Main Mall, Vancouver, BC, V6T 1Z4, Canada.

Abstract:
Studies have shown that the point-to-point reaching movements of subjects seated in a dark, rotating room demonstrate errors in movement trajectories and endpoints, consistent with the direction of the Coriolis force perturbations created by room rotation. Adaptation of successive reaches and the presence of postrotation aftereffects have indicated that subjects form internal models of the Coriolis field dynamics in order to make appropriate movement corrections. It has been argued that these findings are inconsistent with predictions of peripheral stabilization assumed in equilibrium-point models of motor control. A possibility that has been raised, however, is that the Coriolis field findings may in fact stem from changes in control commands elicited due to the magnitude and destabilizing nature of the Coriolis perturbations. That is, it has been suggested that a perturbation threshold exists, below which central reactions are not necessary in order to maintain movement stability. We tested the existence of a perturbation threshold in normal-speed reaching movements. Twelve normal human subjects performed non-visually guided reaching movements while grasping a robotic manipulandum. The endpoints and trajectory deviations of their movements were measured before, during, and after a position-dependent force field (similar to a Coriolis field in terms of the time history of applied forces) was applied to their movements. We examined the responses to a range of perturbation field strengths from small to considerable. Our experimental results demonstrated a substantial adaptation response over the entire range of perturbation field magnitudes examined. Neither the amount of adaptation after 5 trials nor after 25 trials was found to change as disturbance magnitudes decreased. These findings indicate that there is an adaptive response even for small perturbations; i.e., threshold behavior was not found. This result contradicts the assertion that peripheral stabilization mechanisms enable the central controller to ignore small details of peripheral or environmental dynamics. Our findings instead point to a central dynamic modeler that is both highly sensitive and continually active. The results of our study also showed that subjects were able to maintain baseline pointing accuracies despite exposure to perturbation forces of sizeable magnitude (more than 7 N).
More Related Videos


Related Concept Videos
 01:18
Static Friction
For example, consider a scenario where a truck is connected to a car by a rope, ready to tow it along a road. When no external force is applied by the truck, the car remains stationary and is said to be in static equilibrium. In this case, the forces acting on the car, such as gravity and the...
 01:05
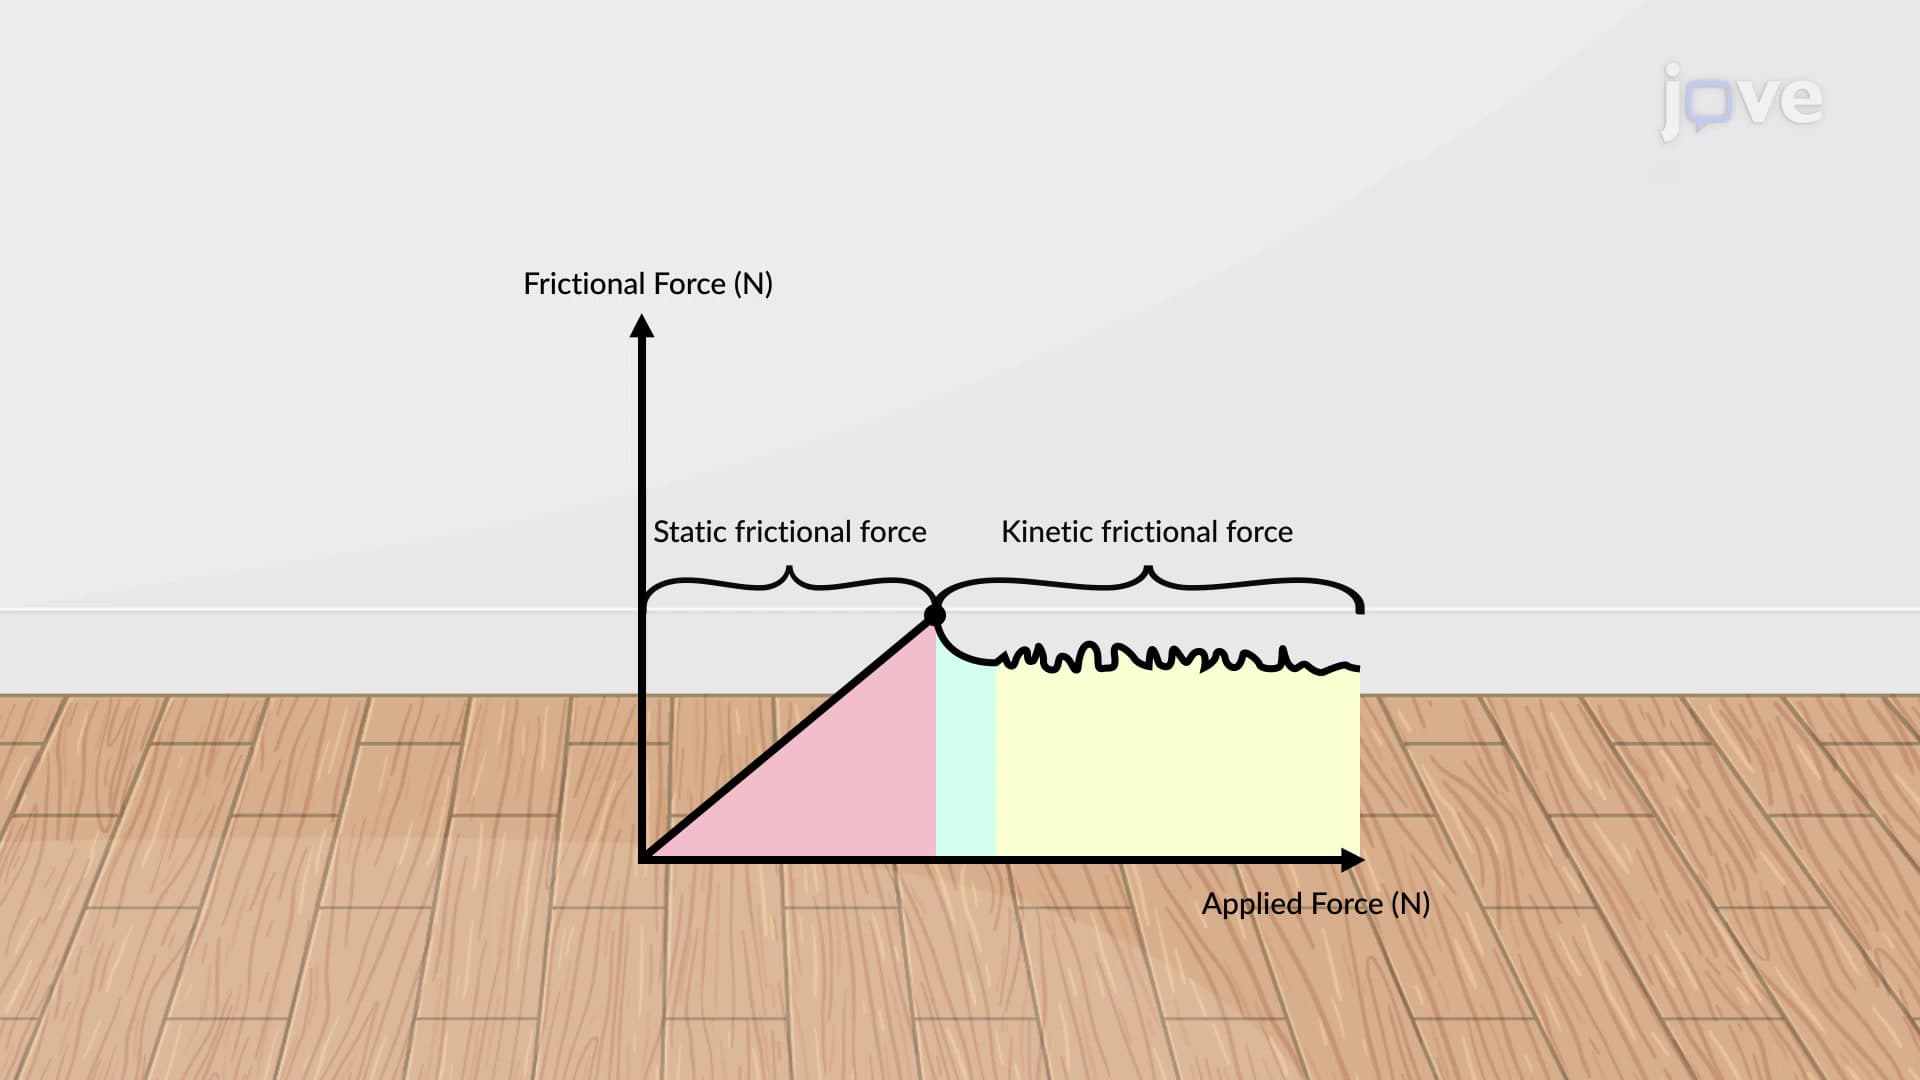
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:14
Stability of structures
 01:06
Forced Oscillations
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...