Task-dependent motor learning
Related Experiment Video
Updated: Aug 30, 2026
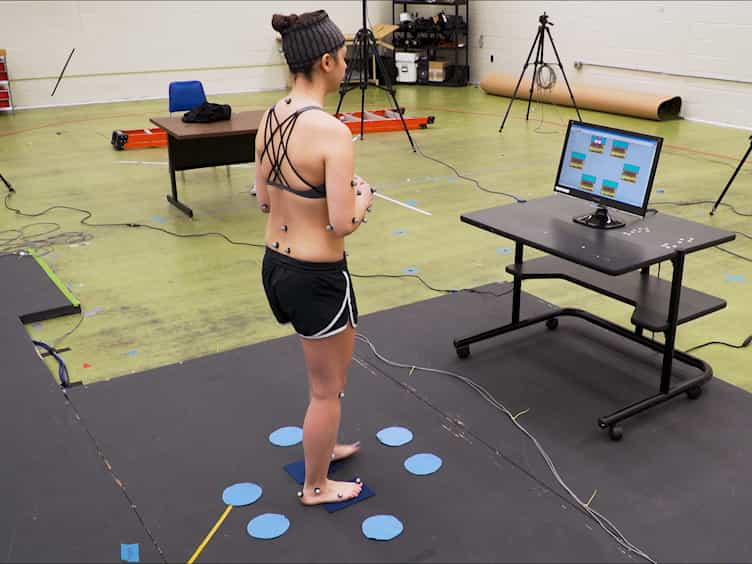
The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Isaac Kurtzer1, Paul DiZio, James Lackner
1Ashton Graybiel Spatial Orientation Laboratory and Volen Center for Complex Systems, Brandeis University, Waltham, MA 02454-9110, USA. isaac@biomed.queensu.ca

Abstract:
We examined whether task-dependent modulation was evident in a motor learning paradigm. Subjects performed reaching movements before, during, and after exposure to a novel force perturbation while adopting either a spatial goal, "continue towards the target", or an effort goal, "keep your effort profile the same". Before the perturbation, the hand trajectories were moderately straight and accurate regardless of the task. However, during and immediately after the perturbation, the reaches exhibited unambiguous task-dependent differences in both the initial and terminal periods of the reach. With the spatial goal, subjects showed terminal compensations to the force-induced displacements indicative of feedback control. In addition, feedforward control was evident in the smaller path deviations with continued exposure and the initial path aftereffects when the perturbation was removed. In contrast, when adopting an effort goal, subjects showed large and chronically deviated endpoints from the perturbation indicating an absence of feedback compensation. They also showed no feedforward adaptation during repeated exposure or visible aftereffects when the perturbation was removed. Therefore, both feedforward and feedback control mechanisms show task-dependent modulation in a motor learning paradigm.
Related Concept Videos
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...
 01:18
Hierarchy of Motor Control