Related Experiment Video
Updated: Aug 30, 2026

Design, Fabrication, and Administration of the Hand Active Sensation Test (HASTe)
Published on: September 8, 2015
Haptically creating affordances: the user-tool interface
Jeffrey B Wagman1, Claudia Carello
1Department of Psychology, University of Connecticut, CT, USA. jeffreywagman@ilstu.edu

Abstract:
Successful use of a hand-held tool requires overcoming the rotational inertia of the hand-plus-tool system. Where an object is grasped affects this rotational inertia. Appropriate choice of grip position may be crucial in the safe, effective, and efficient control of a hand-held tool. In 3 experiments, the authors investigated how choice of grip position on a tool was constrained by task demands. The results suggest that choice of grasp position serves to establish relationships among 3 variables derived from the inertial ellipsoid of the hand-object system (volume, symmetry, and eigenvector angle) in a way that specifically reflected the power or precision constraints of the given task. These variables have previously been shown to play a role in haptic perception of tool function. Changing grasp position on a tool is a way to exert control over the nuances of the user-tool interface.
Related Concept Videos
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:27
Tactile and Chemical Senses
 01:18
Hierarchy of Motor Control
 01:33
Somatosensation
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
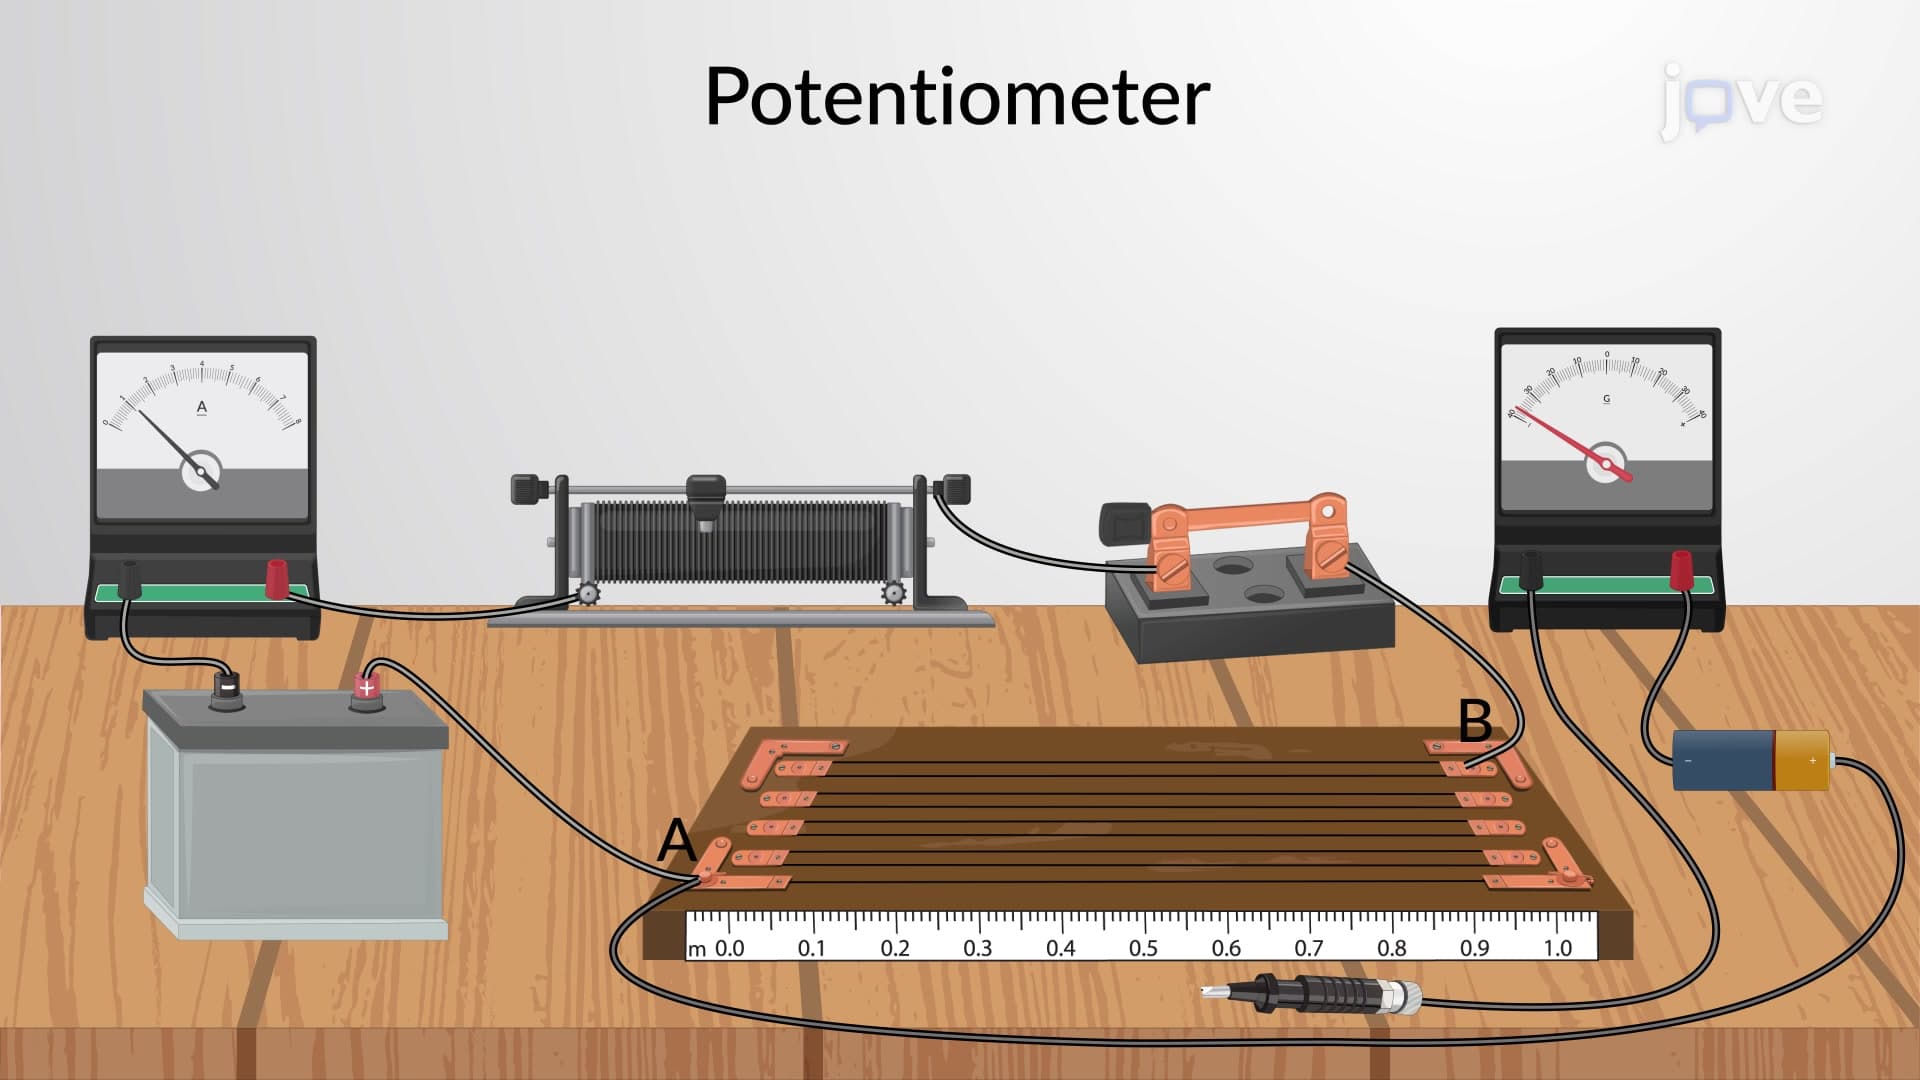
Potentiometer
Suppose the emf of a battery needs to be measured. If the battery is directly connected to a standard voltmeter, the measured quantity is...