Related Experiment Video
Updated: Aug 30, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Predictive and reactive co-ordination of grip and load forces in bimanual lifting in man
R Martyn Bracewell1, Alan M Wing, Harriet M Soper
1Behavioural Brain Sciences Centre, University of Birmingham, Edgbaston B15 2TT, UK.

Abstract:
We investigated the intra- and inter-manual coordination of grip force (GF) and load force (LF) during bimanual lifting and holding of a single object. In a voluntary task involving lifting a predictable load (Experiment 1), we showed scaling of GF to LF generated by either hand, similar to effects seen in previous unimanual studies. Moreover, the GF rates generated by the two hands were correlated. In part this correlation was due to the correlation between the LF rates. However, the GF rates remained correlated when the effects of the correlation in LF rates were partialled out. This novel finding suggests an additional co-ordinative constraint at the level of specification of GFs. As a contrast to the predictable loading in the first experiment, in the second experiment loading was temporally unpredictable and elicited reactive increases in GF. In Experiment 2, the intermanual correlation of GF rates was stronger than in Experiment 1. We speculate that this result reflects greater degrees of co-ordinative constraint at lower levels in the motor control hierarchy.


Related Concept Videos
 01:30
Machines: Problem Solving II
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:24
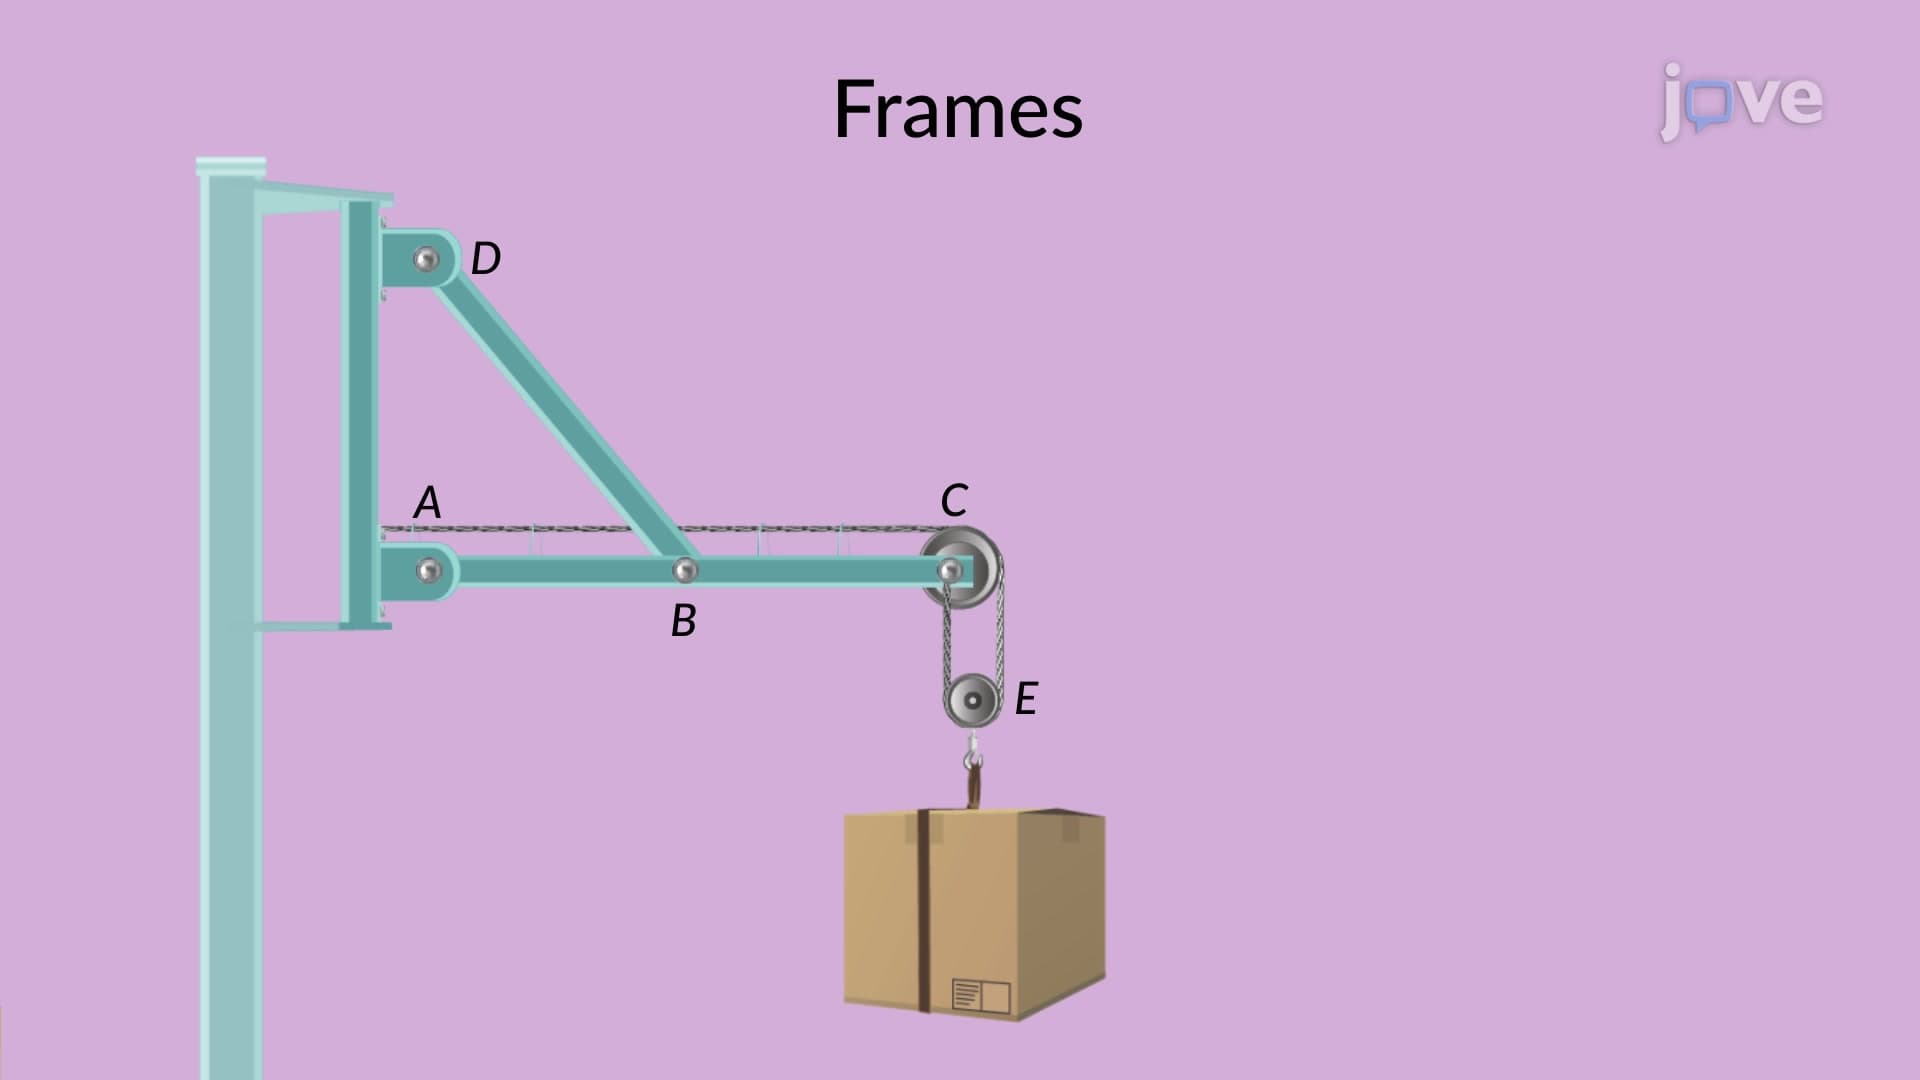
Frames: Problem Solving I
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:26
Frames: Problem Solving II