Related Experiment Video
Updated: Aug 29, 2026

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Which IO model best simulates the real thing?
Floyd S Ota1, Linton L Yee, Francisco J Garcia
1Department of Pediatrics, University of Hawaii John A. Burns School of Medicine, USA.

Objective:
To determine which model best simulates the actual IO procedure in children.
Methods:
Forty emergency and critical care physicians with significant IO experience (6 or more IO procedures) in real children were recruited at 4 academic centers. Study subjects were provided with a kit containing 15 gauge IO needles and 5 IO models; a plastic IO doll leg (PL), a turkey femur/thigh (TT), a turkey tibia/drumstick (TD), a chicken femur/thigh (CT), and a pork rib (PR). Study participants scored the similarity of the bone model to that of placing an IO in a child (0 = no experience, 1 = perfect simulation, 2 = excellent, but not perfect, 3 = good, 4 = moderate, 5 = poor) and the hardness of the bone (H = too hard, J = just right, S = too soft) for each age group (preterm, newborn, 1-4 months, 5-12 months, 12-36 months, 3-6 years, 6-12 years, and >12 years old) of whom they had previous experience. Mean scores were calculated and compared to determine which model provided the best simulation.
Results:
After excluding zero scores, overall mean scores for the CT, TD, TT, PL, and PR models were 3.2, 3.3, 3.3, 3.3, and 4.4 (P < 0.001), respectively. The pork rib had the worst score in all age groups, while the other 4 models had roughly similar scores. All models had substantial percentages of the models classified as too hard or too soft, except for the pork rib, which was predominantly too hard.
Conclusions:
For IO research and teaching purposes, bone models should be age appropriate. This study suggests that there is great variability in preference with the chicken, turkey, and plastic models.

Related Concept Videos
 01:12
Modeling and Similitude
 01:30
Typical Model Studies
 01:30
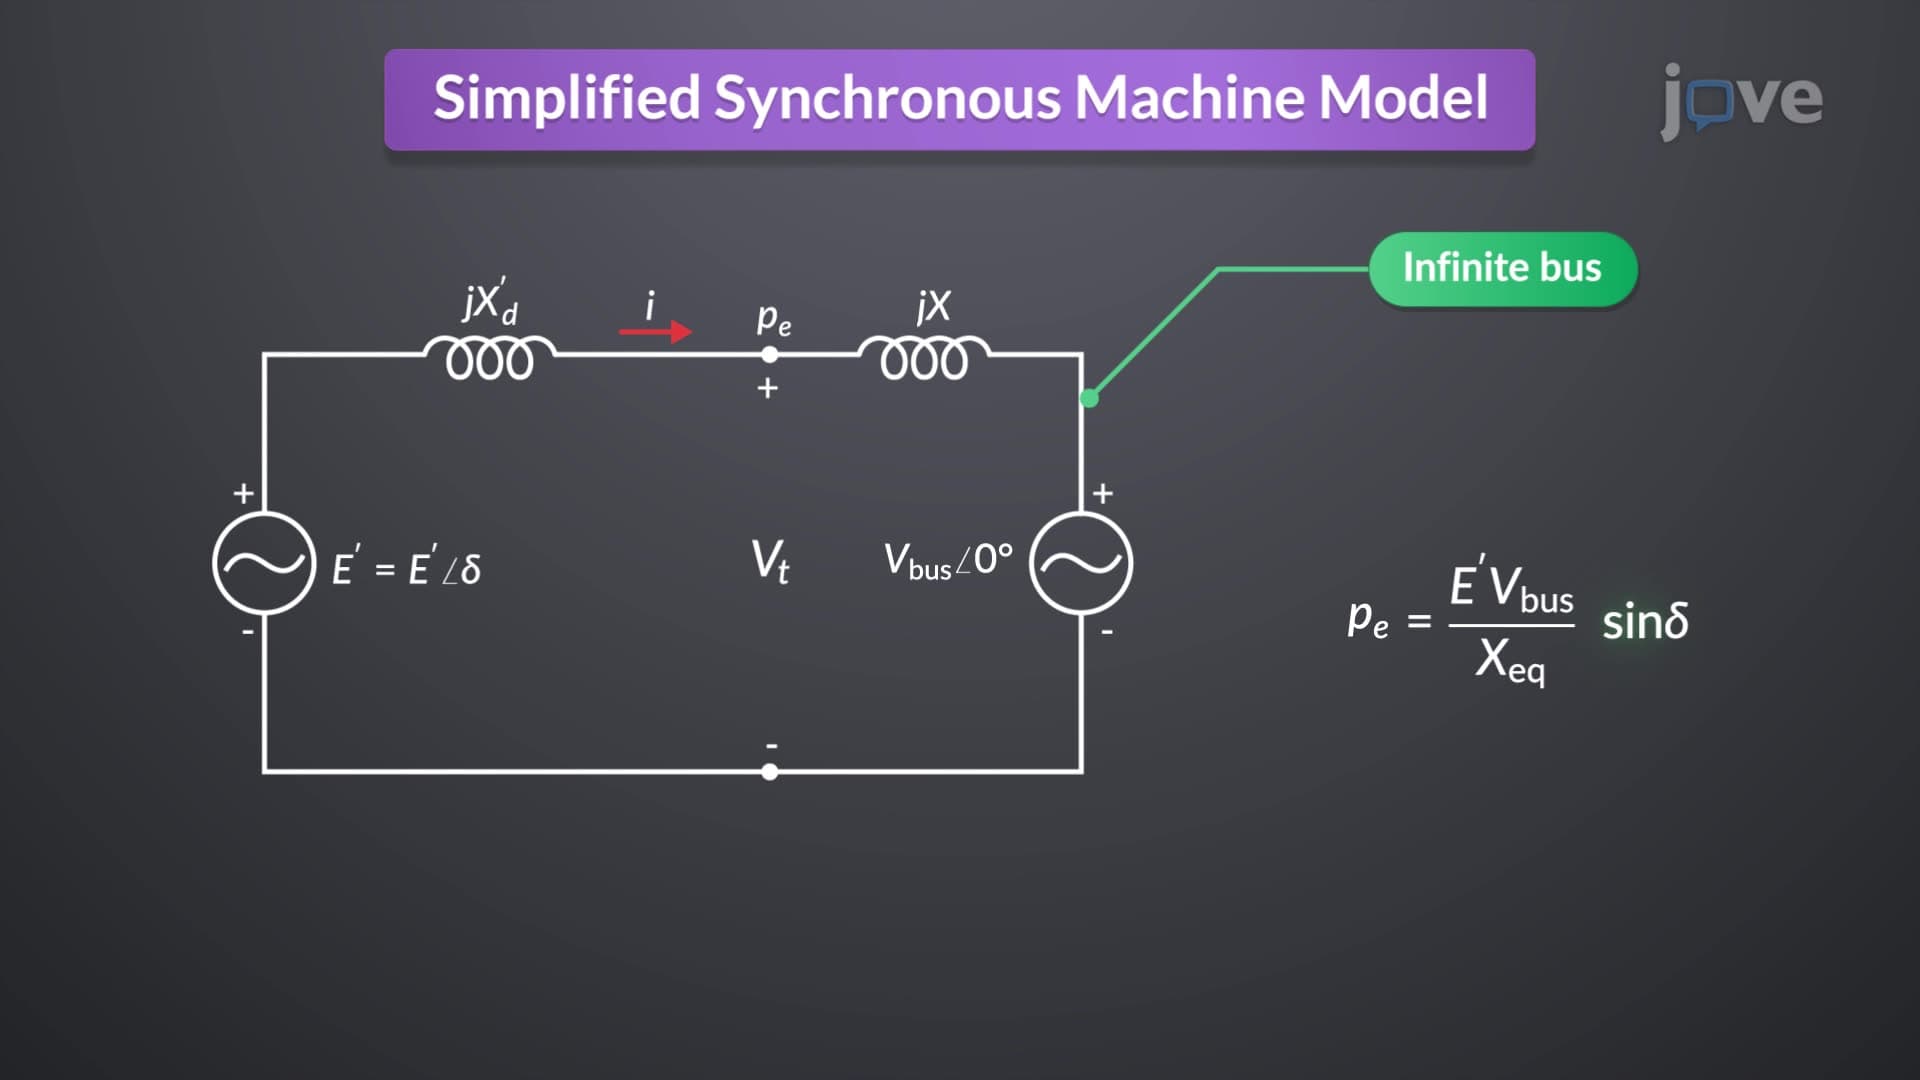
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...