Related Experiment Video
Updated: Aug 29, 2026
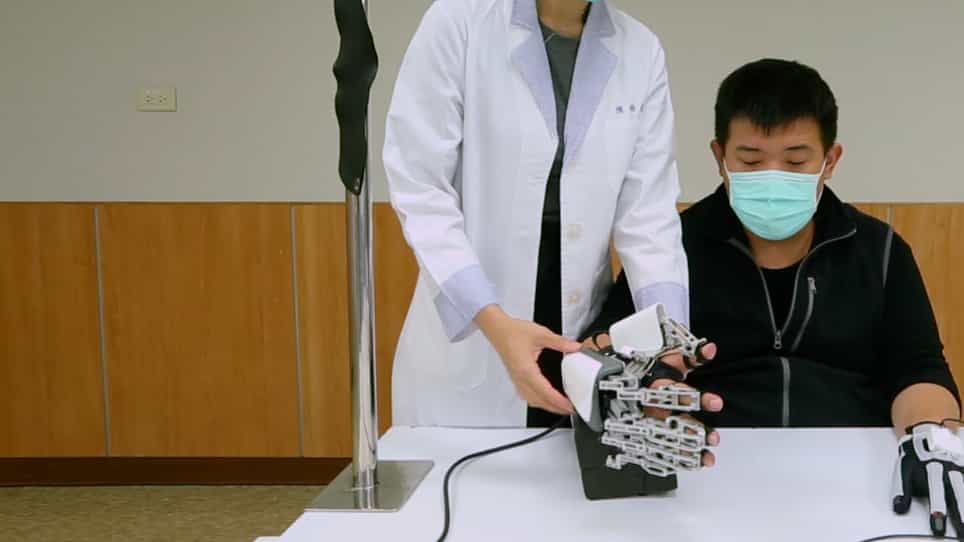
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Adaptive tuning of interlimb attraction to facilitate bimanual decoupling
1Motor Control Laboratory, College of Kinesiology, m/c 194, University of Illinois, P.O. Box 4348, Chicago, IL 60680, USA.

Abstract:
Motor skills that require limbs to concurrently produce different spatiotemporal patterns are often quite difficult to learn. This article outlines a general strategy for training subjects to perform skills that require such disparate limb movements. The strategy is based on the notion that certain preferred movement patterns naturally emerge through the dynamics of the perceptual-motor system, even when quite different movements are intended. The training strategy proposes that the acquisition of relative motion patterns that diverge from preferred patterns can be facilitated by initially "tuning" system dynamics to reduce interlimb attraction. The schedule for the dynamical tuning is adopted from the adaptive training method previously applied to tracking tasks. Preliminary evidence is provided in support of this strategy for learning a bimanual task requiring both structural and metrical interlimb decoupling.
More Related Videos
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
 09:14
Surface Electromyographic Biofeedback as a Rehabilitation Tool for Patients with Global Brachial Plexus Injury Receiving Bionic Reconstruction
Published on: September 28, 2019