Related Experiment Video
Updated: Aug 29, 2026


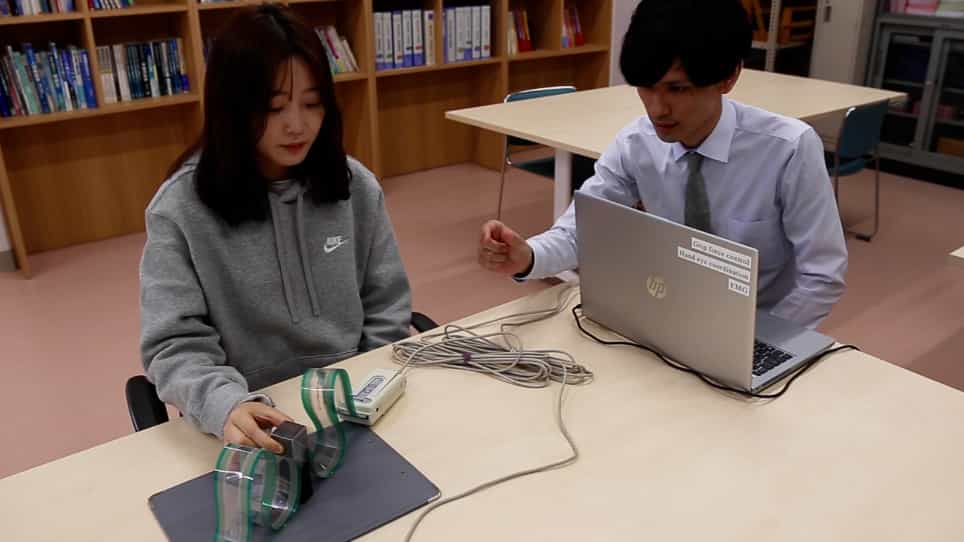
Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
The effects of object weight on the kinematics of prehension
P L Weir1, C L MacKenzie, R G Marteniuk
1Department of Kinesiology, University of Waterloo.

Abstract:
The purpose of these experiments was to determine the effects of object weight and condition of weight presentation on the kinematics of human prehension. Subjects performed reaching and grasping movements to metal dowels whose visible characteristics were similar but whose weight varied (20, 55, 150, 410 g). Movements were performed under two conditions of weight presentation, random (weight unknown) and blocked (weight known). Three-dimensional movements of the thumb, index finger, and wrist were recorded, using a WATSMART system to obtain information regarding the grasp and transport components. The results of the first experiment indicated that object weight and condition of presentation affected the temporal and kinematic measures for both the grasp and transport components. In conjunction with the results of a second experiment, in which time in contact with the dowel was measured, it was shown that the free-motion phase of prehension (i.e., up to object contact) was invariant over the different conditions, however. The changes were observed in the finger-object interaction phase (when subjects applied forces after contact with the dowel), prior to lift-off. These results were interpreted as indicating (a) object weight does not influence the planning and execution of the free-motion phase of prehension and (b) there are at least two motor control phases involved in prehension, one for making contact with the object and the other for finger-object interaction. The changing contributions of visual, kinesthetic, and haptic information during these two phases is discussed.

Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:20
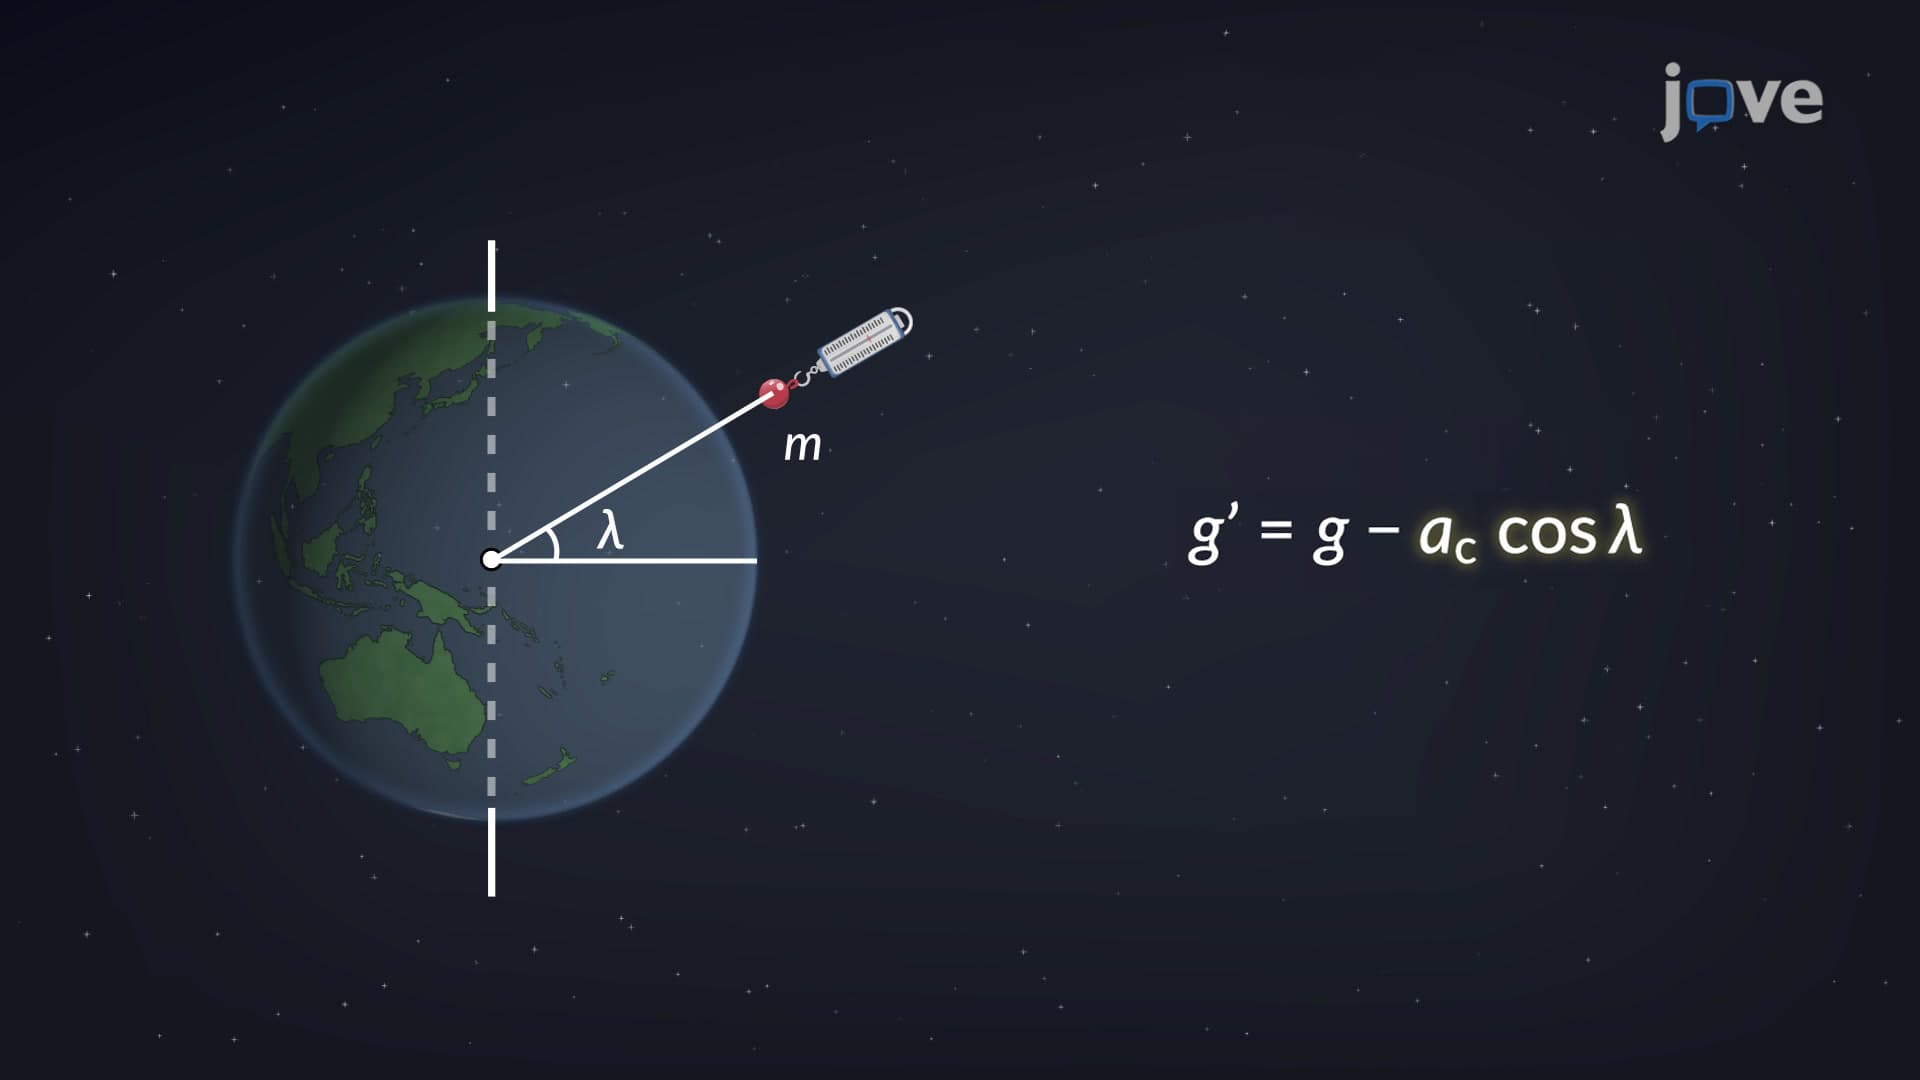
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's angular speed. Since the...
 01:07
Static Equilibrium - II
 01:18
First Law: Particles in Two-dimensional Equilibrium
Newton's first law tells us about the...
 01:05
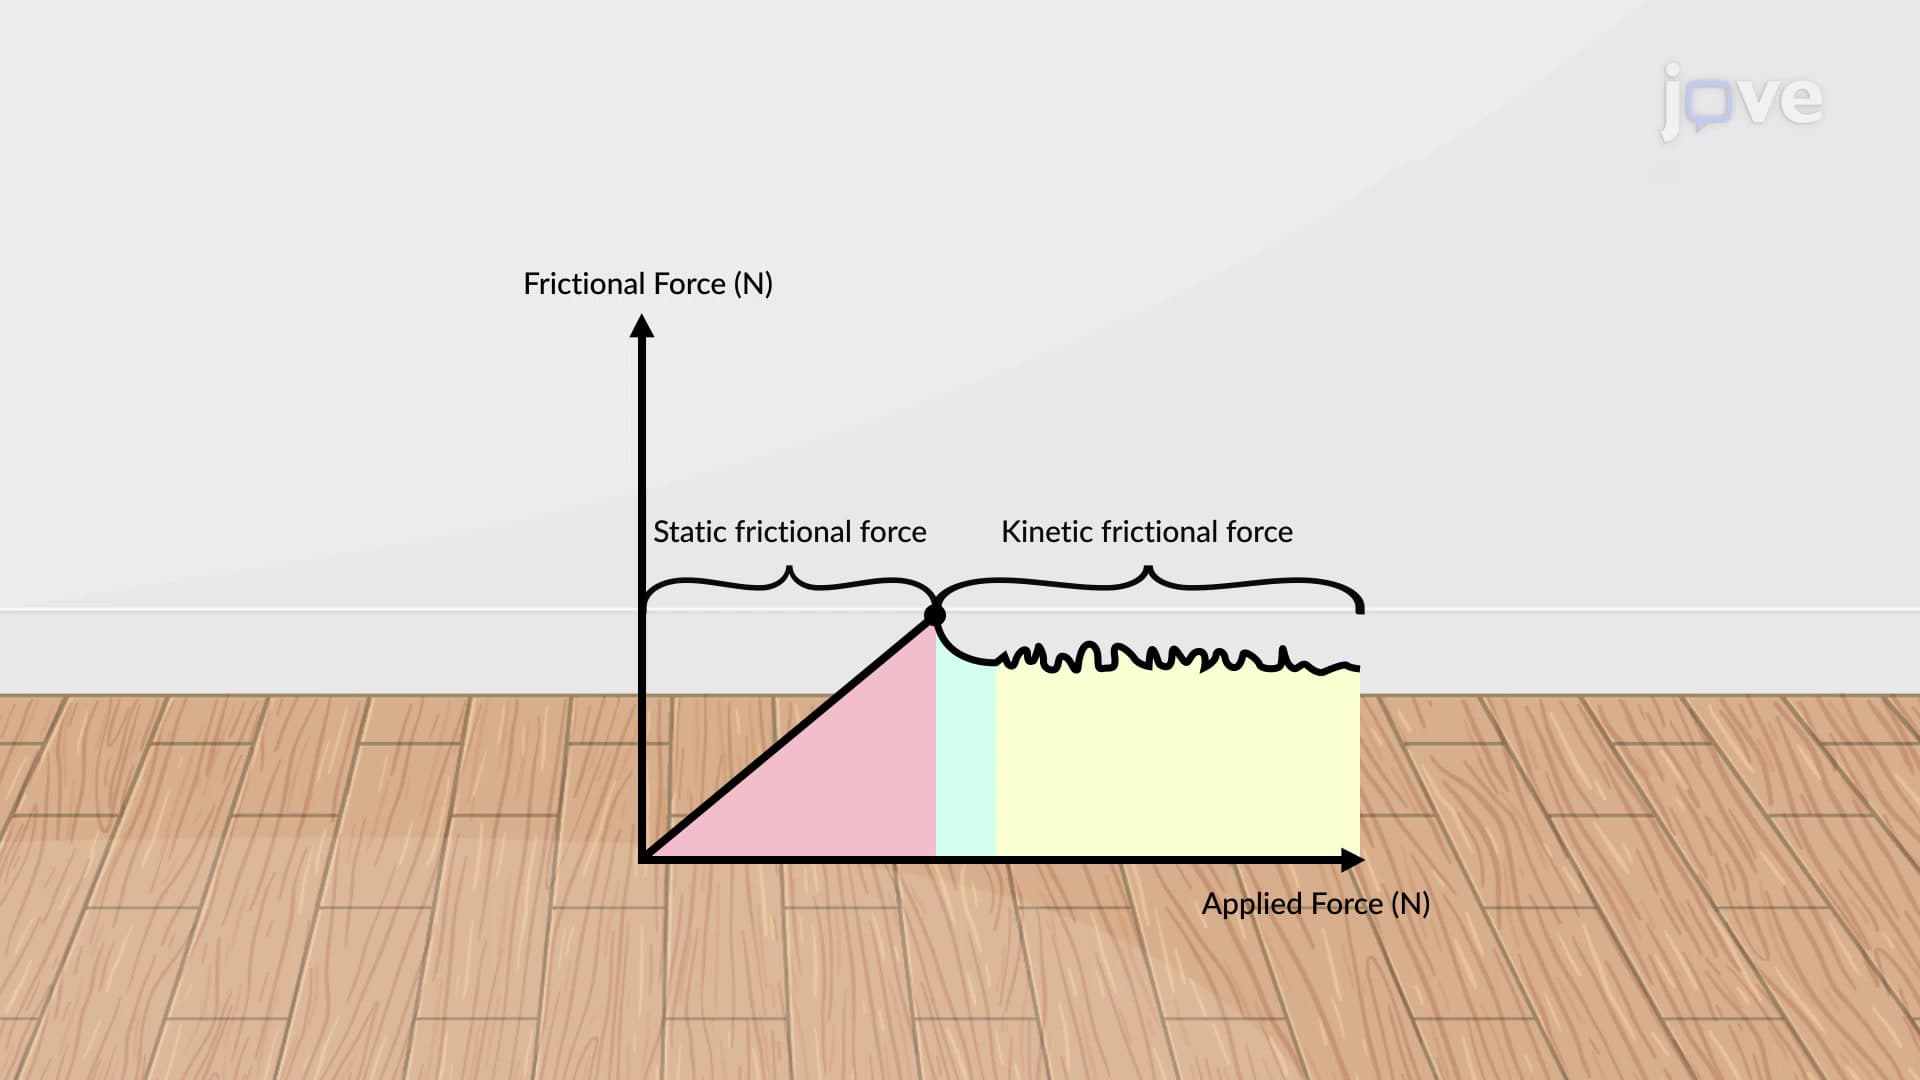
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:19
Impact Loading
In cases of elastic deformation,...