Friction identification in mechatronic systems
Related Experiment Video
Updated: Feb 11, 2026
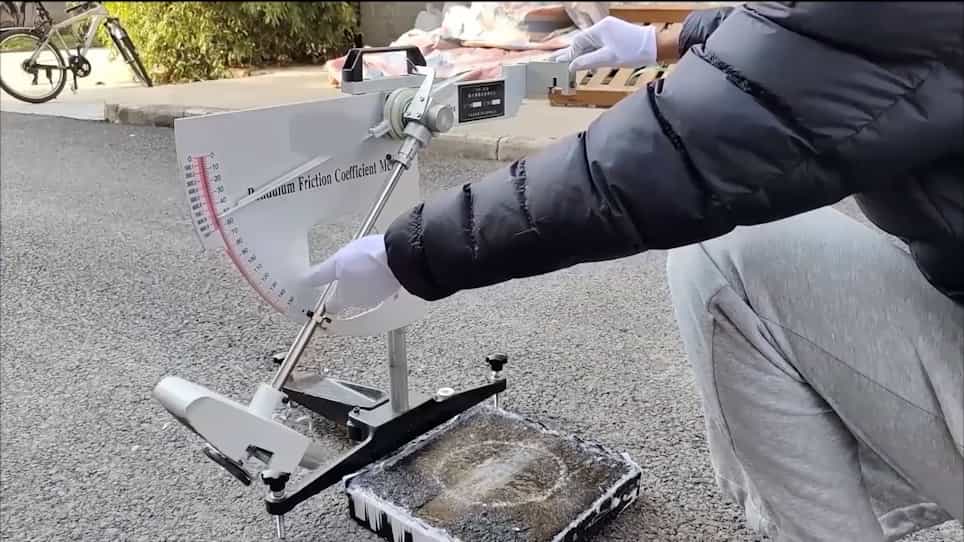
Determination of the Friction Coefficients of Icy Pavements Under Different Amounts of Snowfall
Published on: January 6, 2023
1Department of Mechatronics Engineering, Faculty of Engineering, The Hashemite University, P. O. Box 150459, Zarqa 13115, Jordan. bashir_nouri@yahoo.com

Abstract:
Since no universal friction model exists and the practical measurement of friction is not straightforward, this paper presents an experimental method of identifying friction in mechatronic systems. Friction is perhaps the most important nonlinearity that is found in any mechatronic system of moving parts and influences the system in all regimes of operation. For the purpose of improving the performance of mechatronic systems and solving their servo problem, a better understanding of friction behavior in its two basic regimes is needed. In this paper, the two basic friction regimes, viz., presliding with its hysteresis behavior, which is predominantly position dependent, and gross sliding, which is predominantly velocity dependent, are well exposed and identified.
Related Concept Videos
 01:26
Kinetic Friction
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:21
Friction: Problem Solving
Initially, a visual representation of the...
 01:07
Frictional Force
 01:30
Dry Friction
To illustrate this concept, imagine a wooden crate resting on a rough, non-uniform horizontal surface. When an external force is applied to...
 01:18
Static Friction
For example, consider a scenario where a truck is connected to a car by a rope, ready to tow it along a road. When no external force is applied by the truck, the car remains stationary and is said to be in static equilibrium. In this case, the forces acting on the car, such as gravity and the...