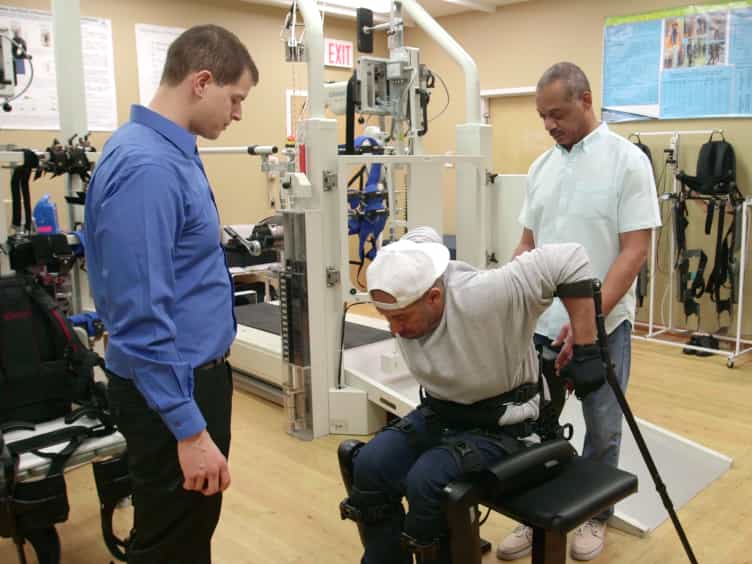
Computer control of a powered two degree freedom reciprocating gait orthosis
Related Experiment Video
Updated: Aug 9, 2026
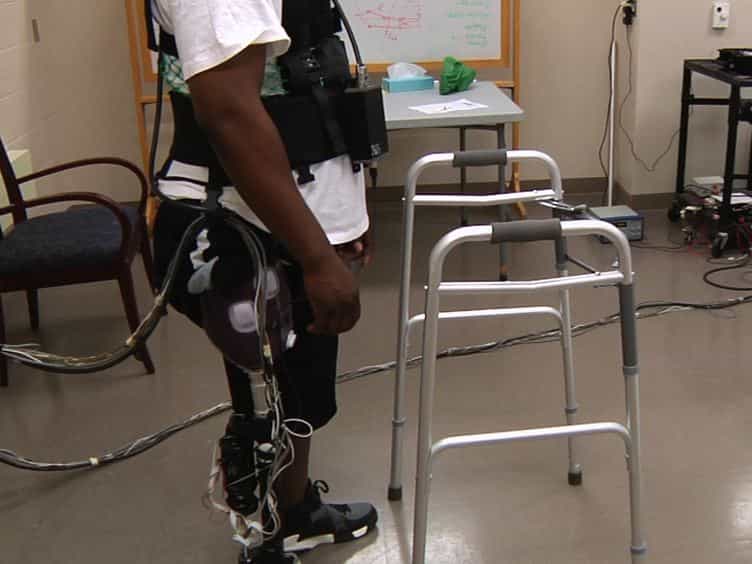
11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Bashir M Y Nouri1, Arafat Zaidan
1Department of Mechanical Engineering, Faculty of Engineering, An-Najah National University, Nablus, West Bank, Palestine. bashir_nouri@yahoo.com
ISA Transactions
|May 3, 2006

Abstract:
The design of a motion control system for a powered reciprocating gait orthosis is considered. Models for the orthosis are obtained using least squares identification. The control system design is based on pole-placement techniques and a restricted Youla parametrization of the controller. Experimental results are included.