Robust and real-time torsional eye position calculation using a template-matching technique
Related Experiment Video
Updated: Aug 24, 2026
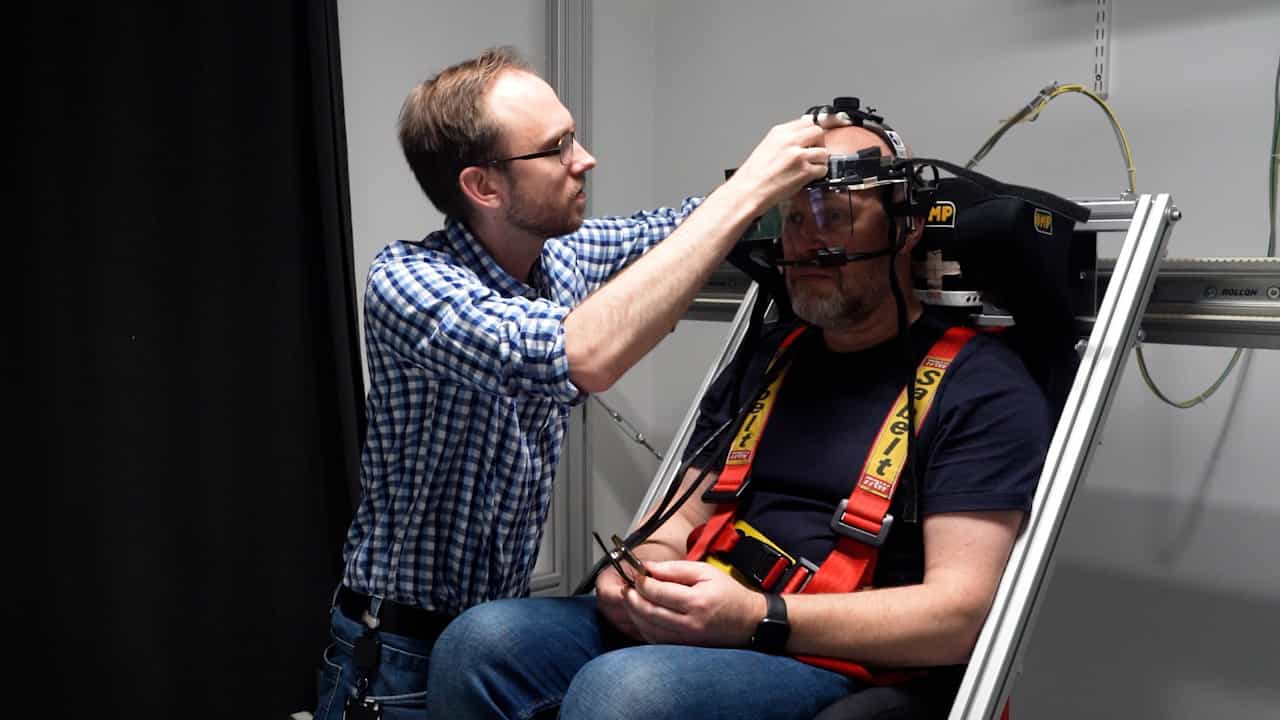
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Danjie Zhu1, Steven T Moore, Theodore Raphan
1Department of Computer and Information Science, Brooklyn College of the City University of New York, 2900 Bedford Avenue, Brooklyn, NY 11210, USA.

Abstract:
Computation of eye rotation about the line of sight (torsion) using image processing techniques has traditionally used cross-correlation of iral signatures sampled from circular arcs centered on the pupil. We have developed a new algorithm that utilizes a template-matching technique to calculate torsional eye position. Iral signatures are obtained from two annuli centered on the pupil center. By assuming that torsional rotation of the eye is constrained between successive video frames (<2 degrees), only a small window of the previous reference signature is necessary to determine relative torsional eye displacement. This dramatically reduces the number of pixels needed for computing torsion. This algorithm is considerably faster, attains a higher accuracy, and exhibits considerably less noise than the cross-correlation technique. Running on a 800 MHz Intel-based Dual Processor Pentium III, with a Matrox frame grabber, the system is capable of processing three-dimensional eye position at a rate of 120 frames/s.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:17
Accessory Structures of the Eye