Multi-objective deep deterministic policy gradient for cobot trajectory planning in automotive spot welding
Related Experiment Video
Updated: Nov 4, 2026

Operation of the Collaborative Composite Manufacturing (CCM) System
Published on: October 1, 2019
Batyrkhan Omarov1,2,3
1Laboratory of Mechanics of Robots and Manipulators, Joldasbekov Institute of Mechanics and Engineering, Almaty, Kazakhstan.

Introduction:
Autonomous trajectory planning is a fundamental challenge in collaborative robotic spot welding because positioning accuracy, motion smoothness, operational safety, energy use, and production efficiency must be optimized simultaneously under industrial constraints.
Methods:
This paper presents a Pareto-Guided Multi-Objective Deep Deterministic Policy Gradient (PMO-DDPG) framework for autonomous cobot trajectory planning in automotive spot welding. The framework combines a deterministic actor with four objective-specific critics for accuracy, smoothness, safety, and productivity, together with phase-dependent preferences for the approach, alignment, welding, and retraction stages. The principal novelty is a two-level multi-objective design that preserves six normalized physical reward components, maps them to four specialized critics for phase-dependent actor updates, and uses a non-dominated policy archive for Pareto-guided selection while retaining actor-only online inference. Simulation and industrial experiments assessed convergence, trajectory quality, collision avoidance, energy consumption, cycle time, success rate, and latency.
Results:
Relative to the Soft Actor-Critic (SAC) baseline, PMO-DDPG reduced trajectory error by 66.4%, collision rate by 82.1%, energy consumption by 15.5%, cycle time by 22.0%, and inference latency by 22.7%, while increasing the success rate by 7.5 percentage points. The proposed method achieved 1.08 mm trajectory error, a 1.2% collision rate, 3.65 kJ energy consumption, a 3.87 s cycle time, a 94.6% success rate, and 21.5 ms inference time. Pareto-front analysis produced non-dominated operating points for different manufacturing priorities, and 100 industrial trials confirmed sub-millimeter positioning and repeatable vision-guided welding.
Discussion:
Within the evaluated simulation and industrial test settings, and without a formal significance test, these descriptive results indicate that PMO-DDPG is a promising accurate, safe, and efficient trajectory-planning approach.
Related Concept Videos
 01:25
Maximizing the Directional Derivative
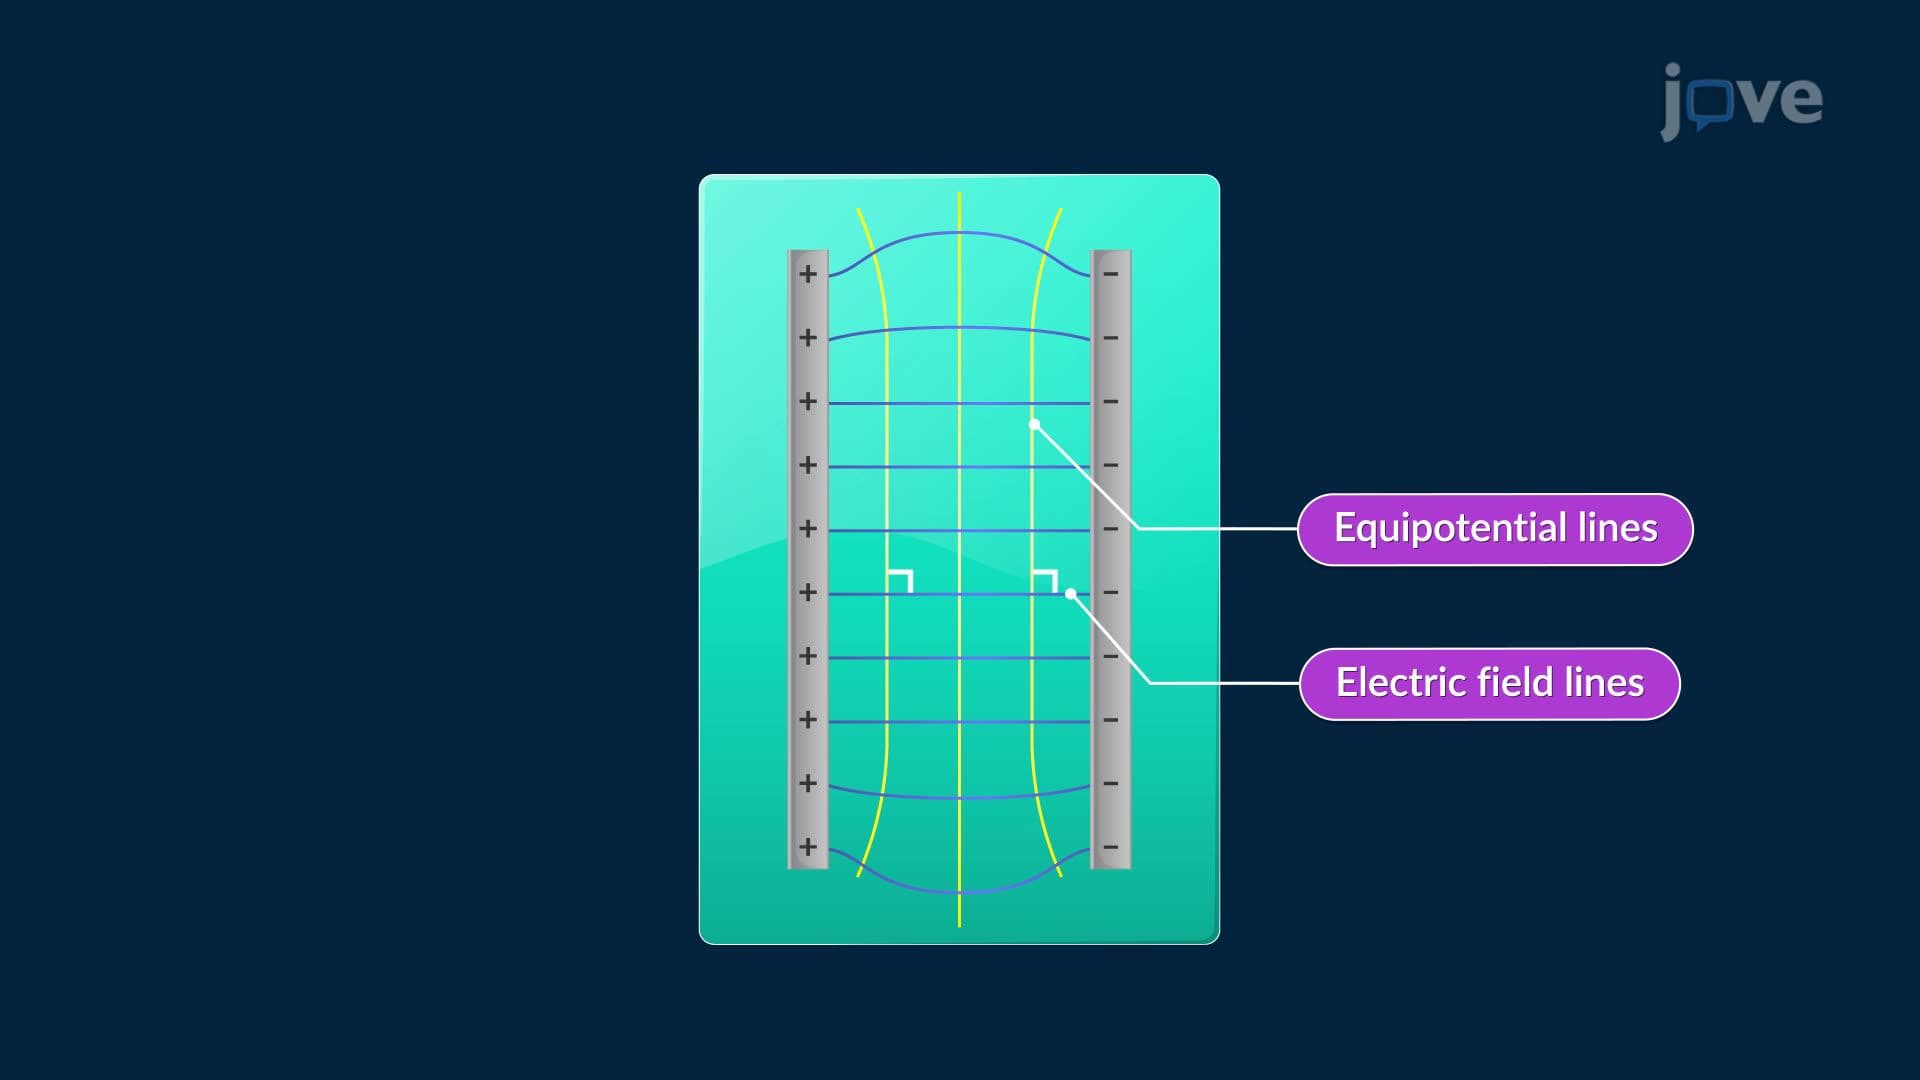 01:26
Orthogonal Trajectories
 01:30
Vector Functions and Motion: Problem Solving
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Implicit Differentiation: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...