Related Experiment Video
Updated: Aug 22, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Detecting and controlling unstable periodic orbits that are not part of a chaotic attractor
1Department of Physics, Faculty of Education, University of Maribor, Koroska cesta 160, SI-2000 Maribor, Slovenia.

Abstract:
A method for controlling unstable periodic orbits (UPOs) that have not been controllable before is presented. The method is based on detecting UPOs that are situated outside the skeleton of a chaotic attractor. The main idea is to exploit flexible parts of the attractor, which under weak external perturbations allow variable excursions of the trajectory away from its originally determined path. After the perturbation, the trajectory of the autonomous system seeks its path back to the chaotic attractor and reveals additional UPOs that are otherwise not used by the system. It is shown that these UPOs can be controlled as easily as the UPOs that form the basic chaotic attractor. The effectiveness of the proposed method is demonstrated on two different chaotic systems with very distinct response abilities to external perturbations. Additionally, some applications of the method in the fields of laser technology, information encoding, and biomedical engineering are discussed.
Related Concept Videos
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:04
Oscillations about an Equilibrium Position
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:19
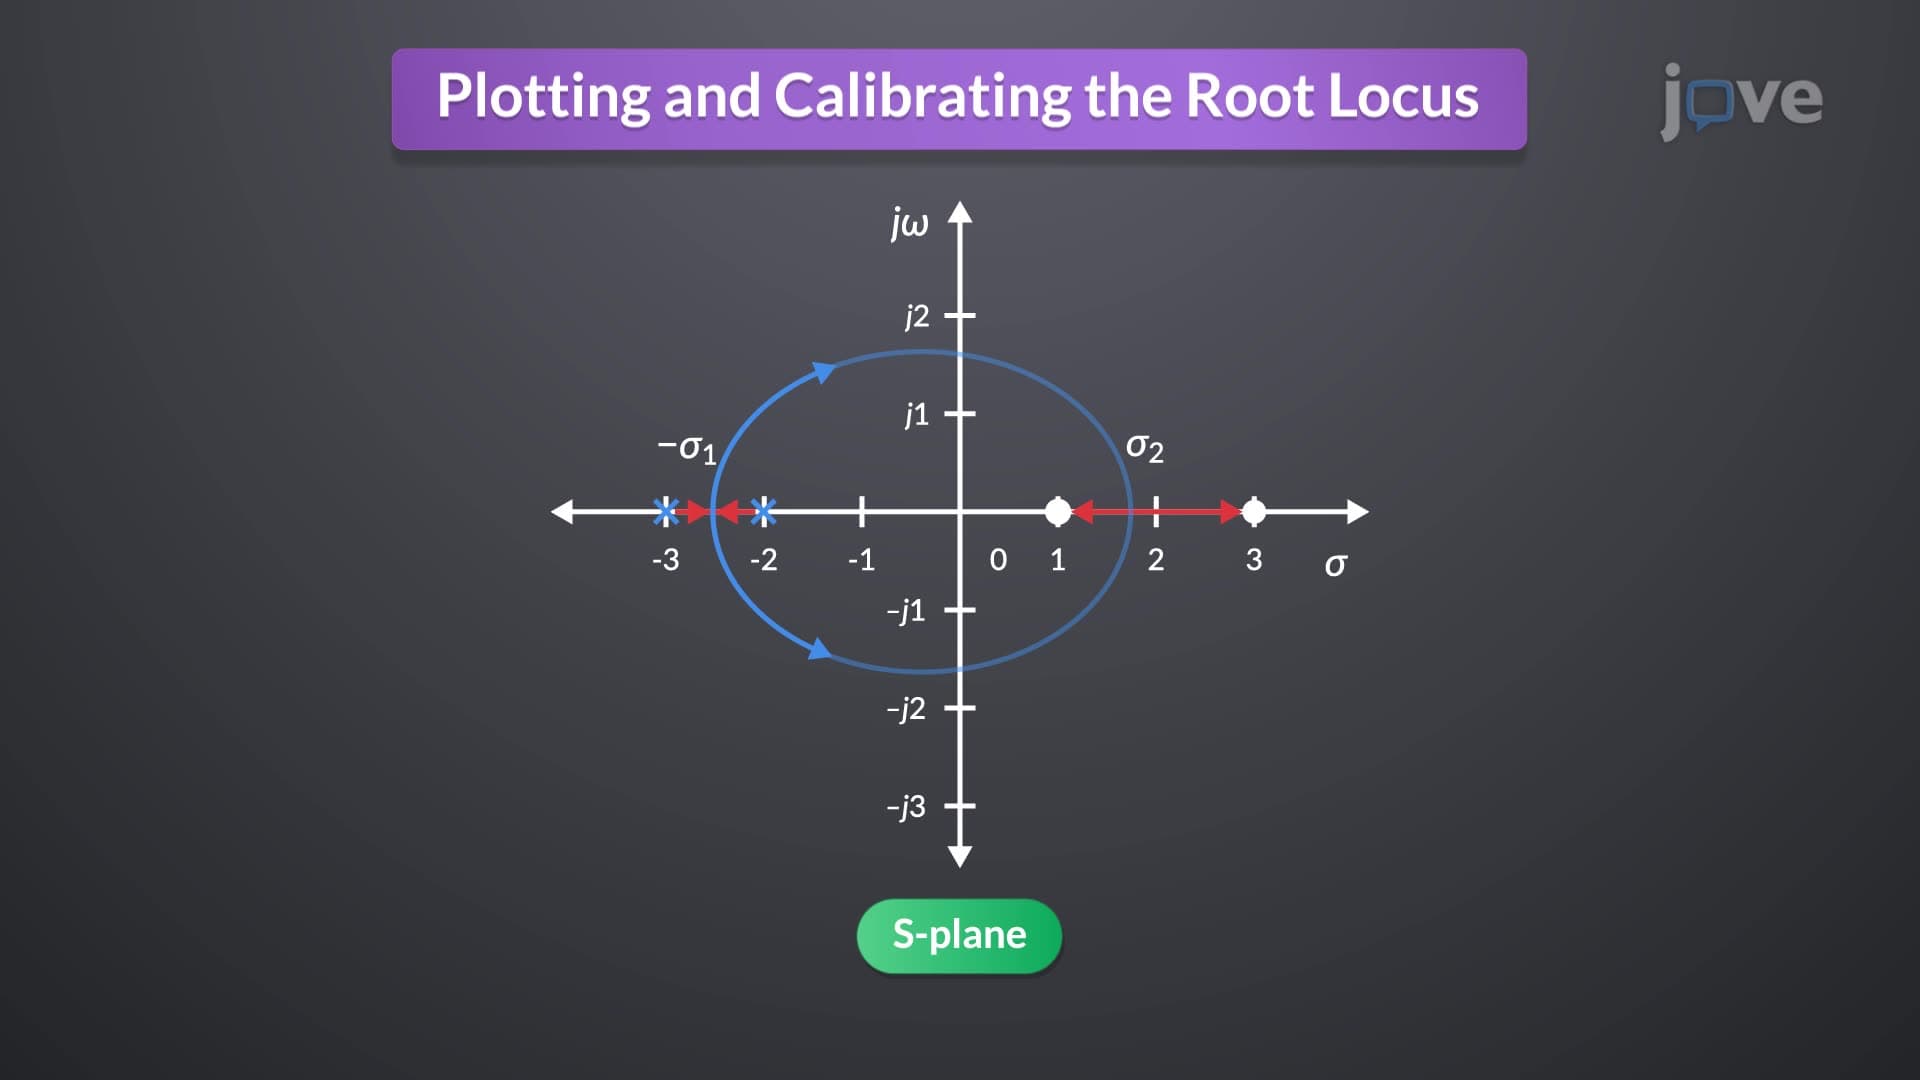
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...