Related Experiment Video
Updated: Aug 22, 2026

Parametric Optimization Design Method for Friction Plates of Hydro-Viscous Clutches
Published on: July 22, 2025
Analysis of the force-sharing problem using an optimization model
R Ait-Haddou1, A Jinha, W Herzog
1Faculty of Kinesiology, Human Performance Laboratory, The University of Calgary, 2500 University Drive NW, Calgary, AB, Canada T2N 1N4.

Abstract:
In biomechanics, one frequently used approach for finding a unique set of muscle forces in the 'force-sharing problem' is to formulate and solve a non-linear optimization problem of the form: min phi(f)= summation operator (f(i)/omega(i))(alpha) subject to Af = b and f > or = 0. Solutions to this problem have typically been obtained numerically for complex models, or analytically for specific musculoskeletal geometries. Here, we present simple geometrical methods for analyzing the solution to this family of optimization problems for a general n-degrees-of-freedom musculoskeletal system. For example, it is shown that the moment-arm vectors of active (f(i) > 0) and passive (f(i) = 0) muscles are separated by a hyperplane through the origin of the moment-arm vector space. For the special case of a system with two degrees-of-freedom, solutions can be readily represented in graphical form. This allows for powerful interpretations of force-sharing calculated using optimization.
Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:23
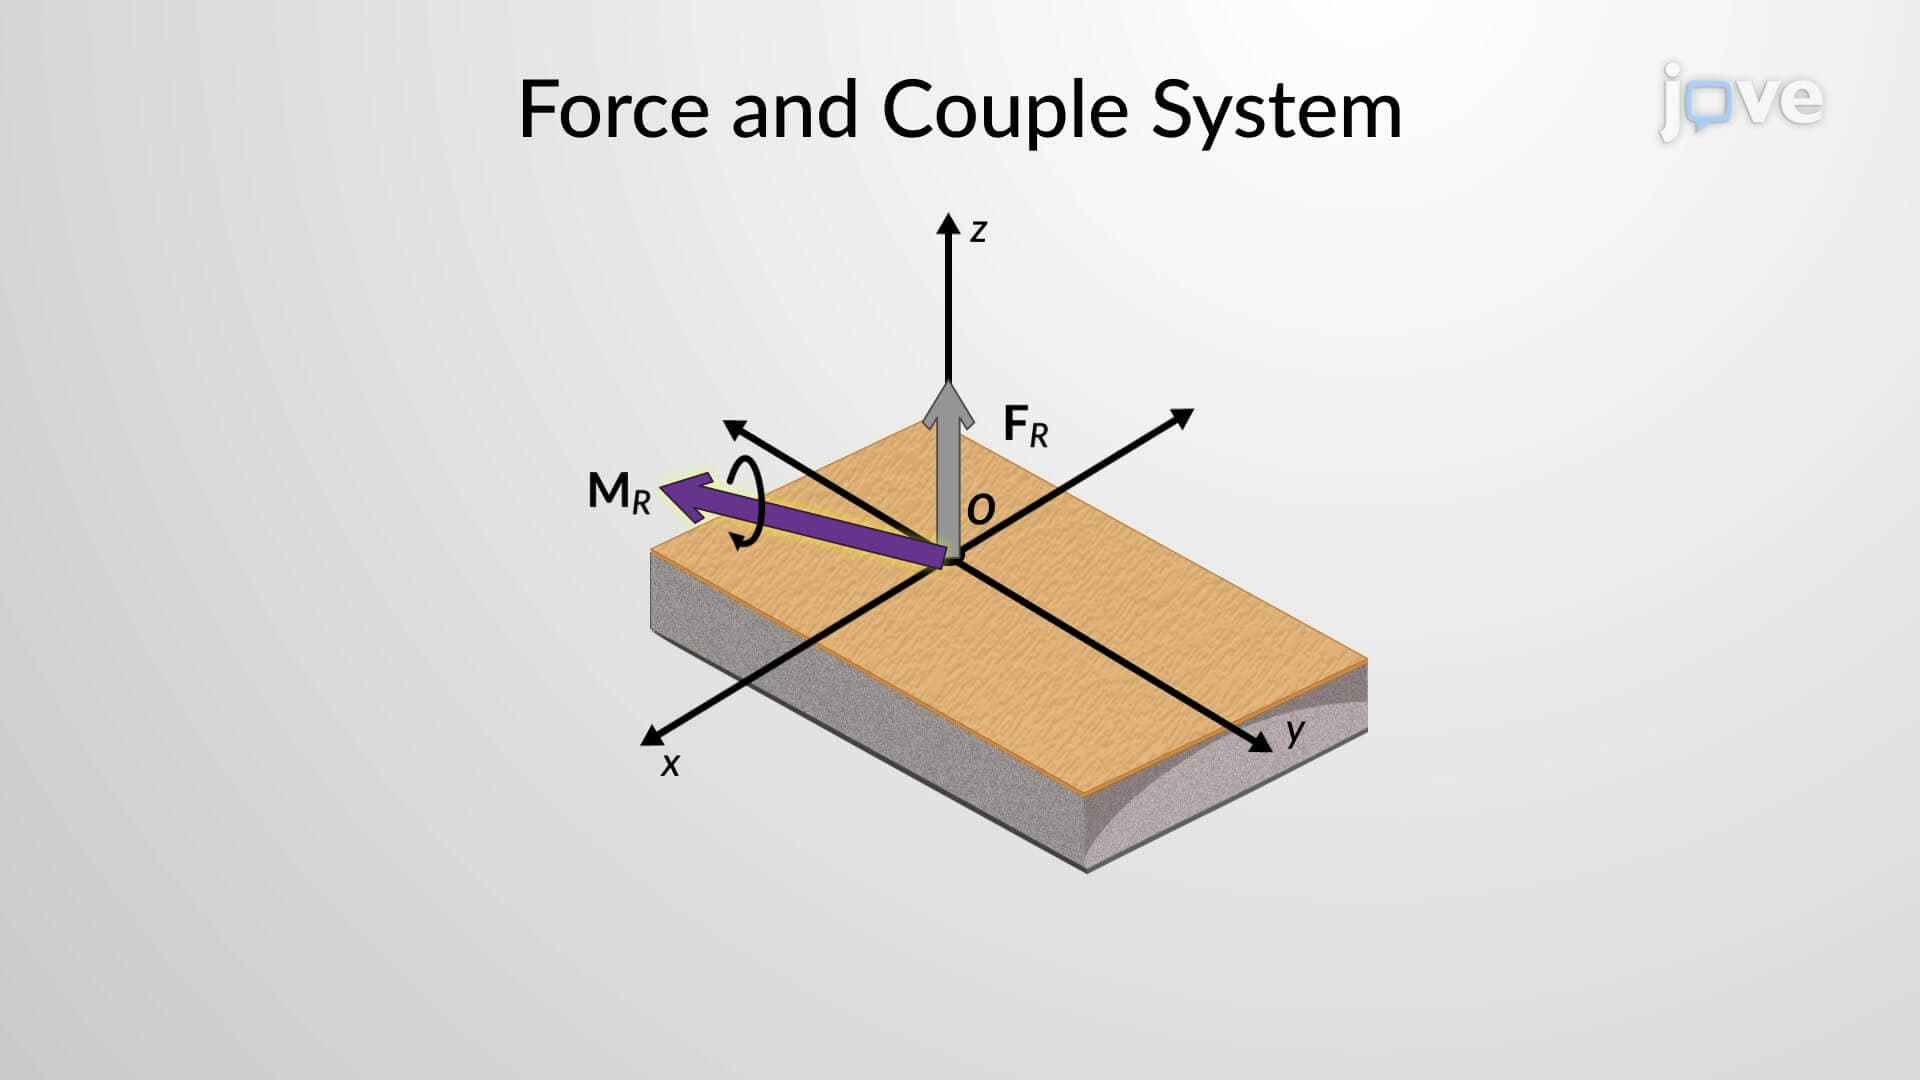
Simplification of a Force and Couple System: II
 01:21
Distributed Loads: Problem Solving
 01:16
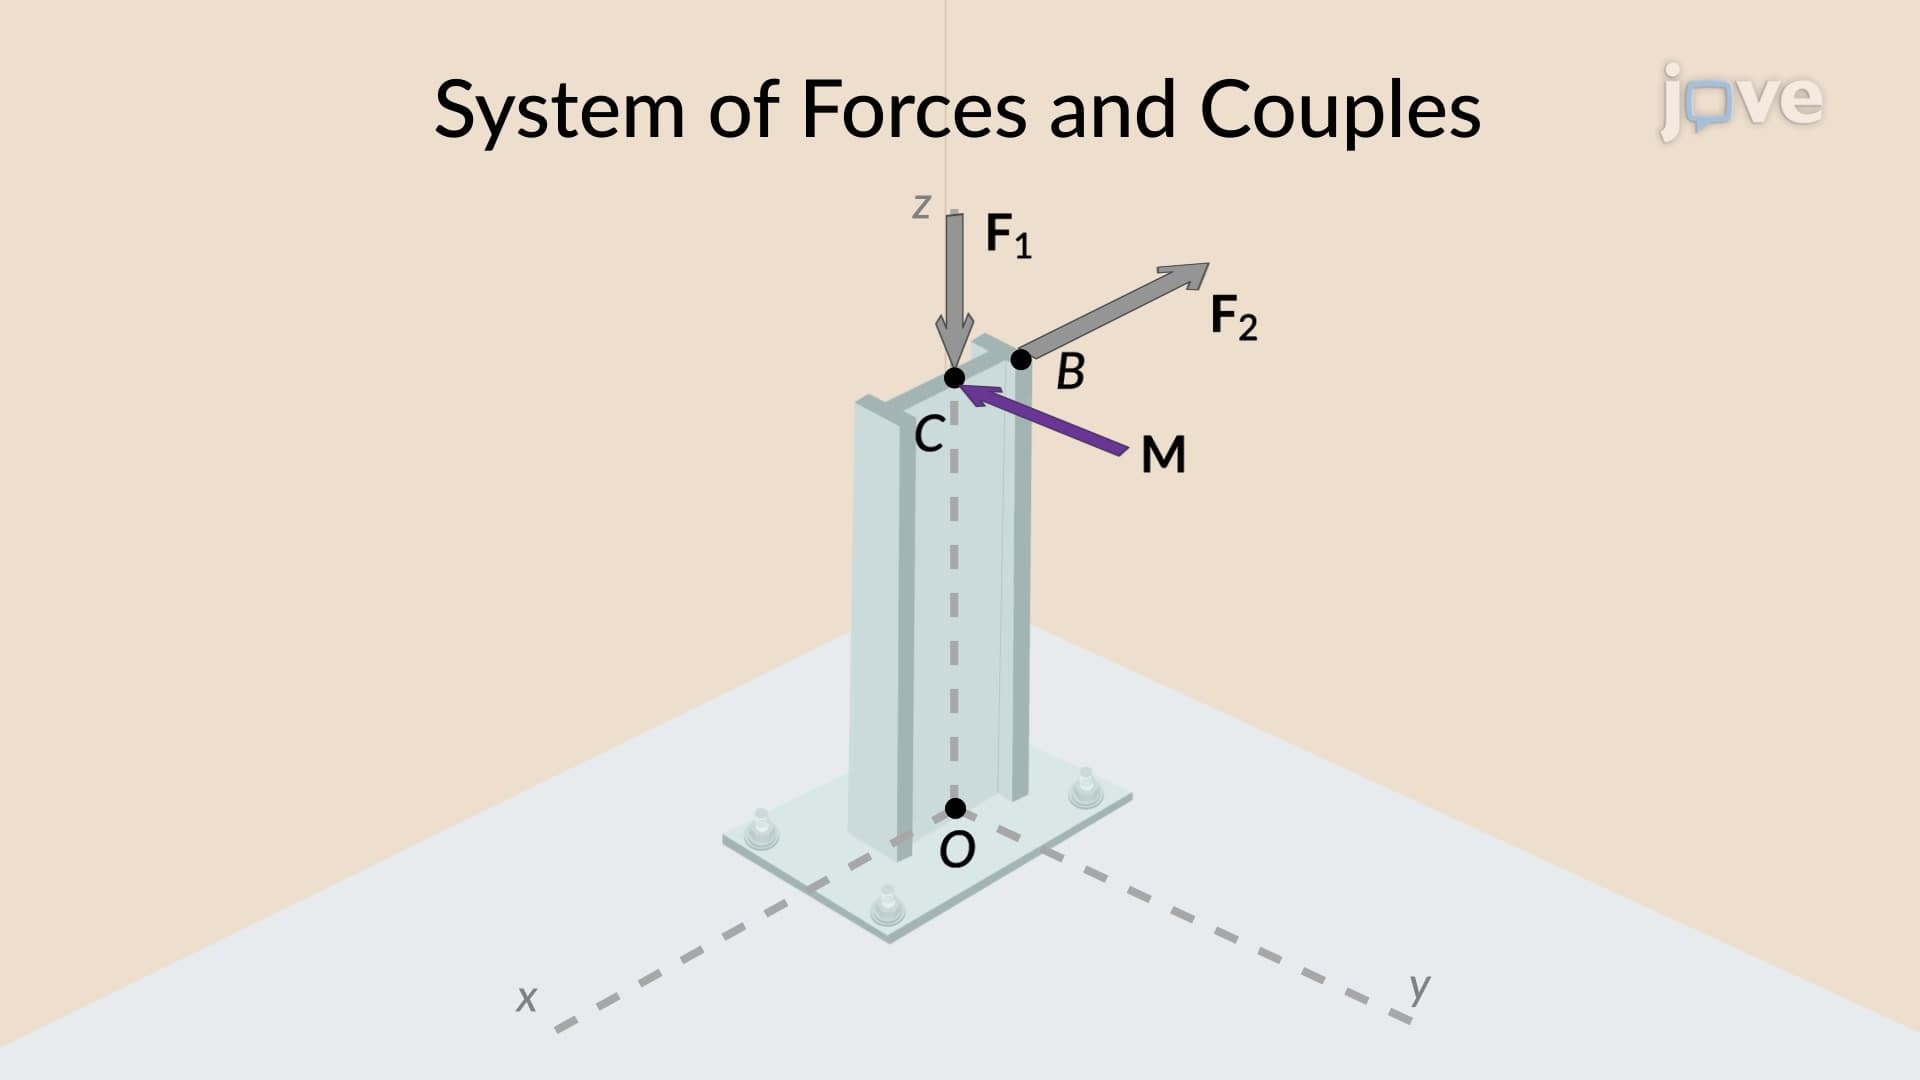
System of Forces and Couples
The principle of transmissibility plays a crucial role in this process. According to...
 01:18
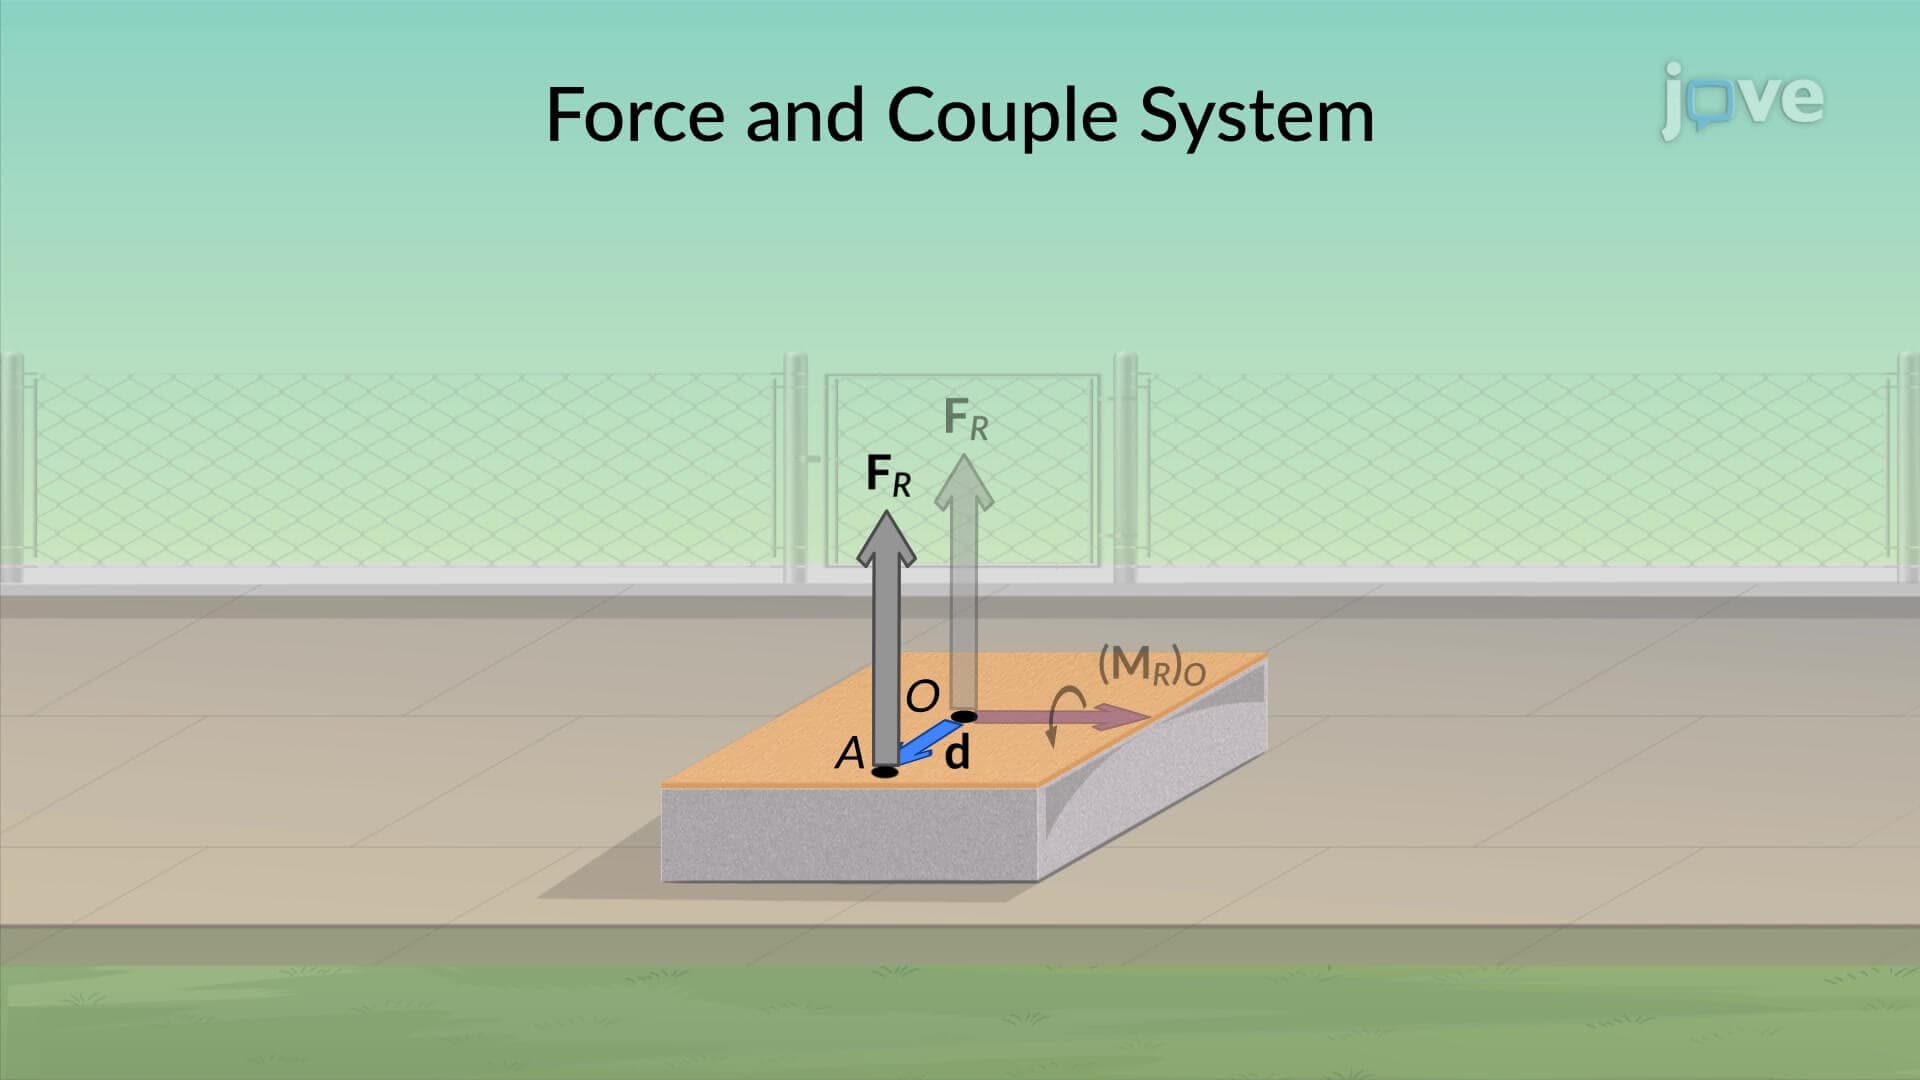
Simplification of a Force and Couple System I