Related Experiment Video
Updated: Aug 22, 2026
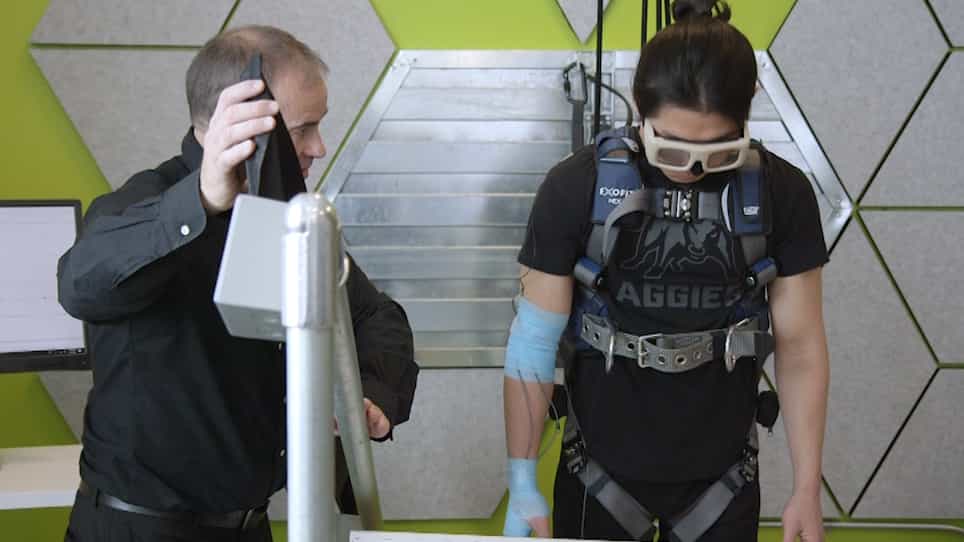
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
A model of cerebellum stabilized and scheduled hybrid long-loop control of upright balance
1Department of Electrical Engineering and Computer Science (LIDS/CSAIL), MIT and MIT-Harvard HST Neuro Engineering Research Collaborative, 32 Vassar Street 32-206, Cambridge, MA 02139, USA. shjo@mit.edu

Abstract:
A recurrent integrator proportional integral derivative (PID) model that has been used to account for cerebrocerebellar stabilization and scaling of transcortical proprioceptive feedback in the control of horizontal planar arm movements has been augmented with long-loop force feedback and gainscheduling to describe the control of human upright balance. The cerebellar component of the controller is represented by two sets of gains that each provide linear scaling of same-joint and interjoint long-loop stretch responses between ankle, knee, and hip. The cerebral component of the model includes a single set of same-joint linear force feedback gains. Responses to platform translations of a three-segment body model operating under this hybrid proprioception and force-based long-loop control were simulated. With low-velocity platform disturbances, "ankle-strategy"-type postural recovery kinematics and electromyogram (EMG) patterns were generated using the first set of cerebeller control gains. With faster disturbances, balance was maintained by including the second set of gains cerebellar control gains that yielded "mixed ankle-hip strategy"-type kinematics and EMG patterns. The addition of small amounts of simulated muscular coactivation improved the fit to certain human datasets. It is proposed that the cerebellum switches control gainsets as a function of sensed body kinematic state. Reduction of cerebellar gains with a compensatory increase in muscular stiffness yielded posture recovery with abnormal motions consistent with those found in cerebellar disease. The model demonstrates that stabilized hybrid long-loop feedback with scheduling of linear gains may afford realistic balance control in the absence of explicit internal dynamics models and suggests that the cerebellum and cerebral cortex may contribute to balance control by such a mechanism.
More Related Videos
Related Concept Videos
 00:49
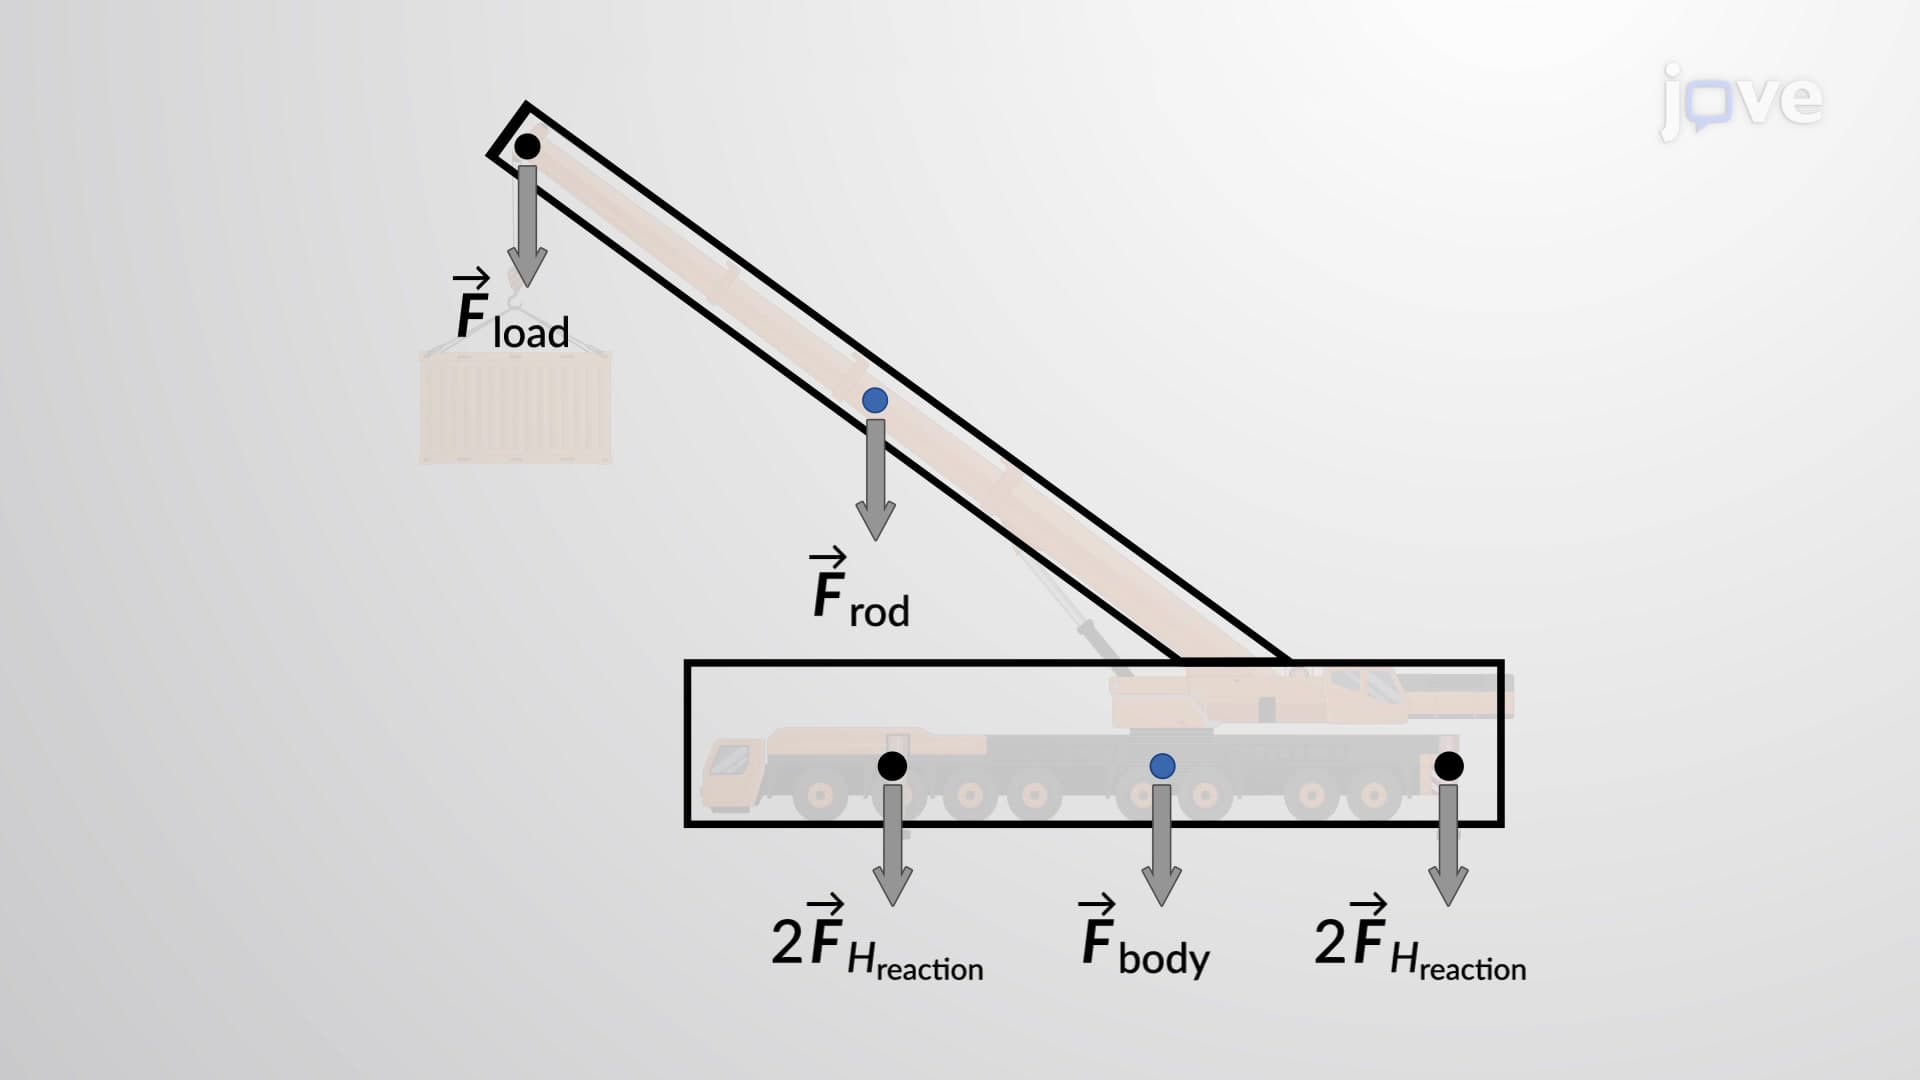
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:15
Equilibrium and Balance
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...