Related Experiment Video
Updated: Aug 22, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Deriving sufficient conditions for global asymptotic stability of delayed neural networks via nonsmooth analysis
1School of Mathematics, The University of New South Wales, Sydney, NSW 2052, Australia.

Abstract:
In this paper, we obtain new sufficient conditions ensuring existence, uniqueness, and global asymptotic stability (GAS) of the equilibrium point for a general class of delayed neural networks (DNNs) via nonsmooth analysis, which makes full use of the Lipschitz property of functions defining DNNs. Based on this new tool of nonsmooth analysis, we first obtain a couple of general results concerning the existence and uniqueness of the equilibrium point. Then those results are applied to show that existence assumptions on the equilibrium point in some existing sufficient conditions ensuring GAS are actually unnecessary; and some strong assumptions such as the boundedness of activation functions in some other existing sufficient conditions can be actually dropped. Finally, we derive some new sufficient conditions which are easy to check. Comparison with some related existing results is conducted and advantages are illustrated with examples. Throughout our paper, spectral properties of the matrix (A + Atau) play an important role, which is a distinguished feature from previous studies. Here, A and Atau are, respectively, the feedback and the delayed feedback matrix defining the neural network under consideration.
Related Concept Videos
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:28
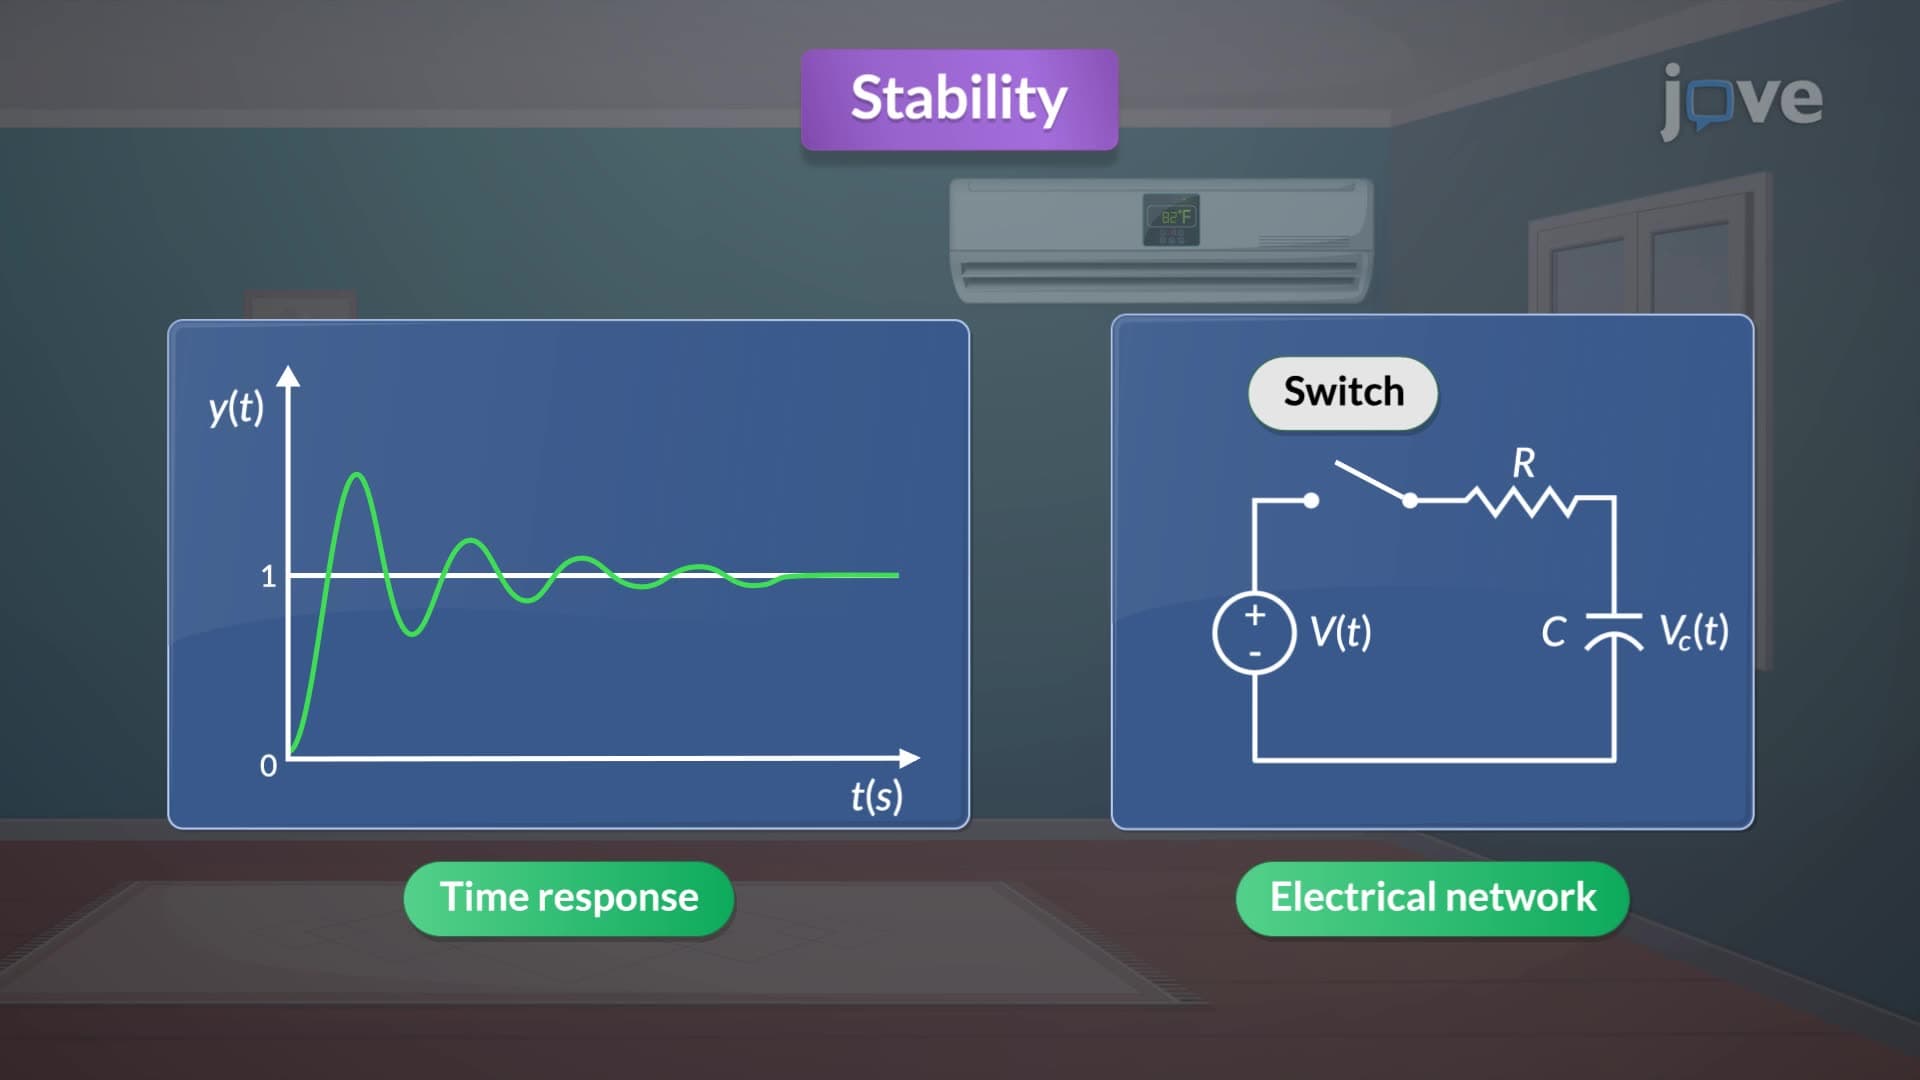
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:37
Neural Regulation