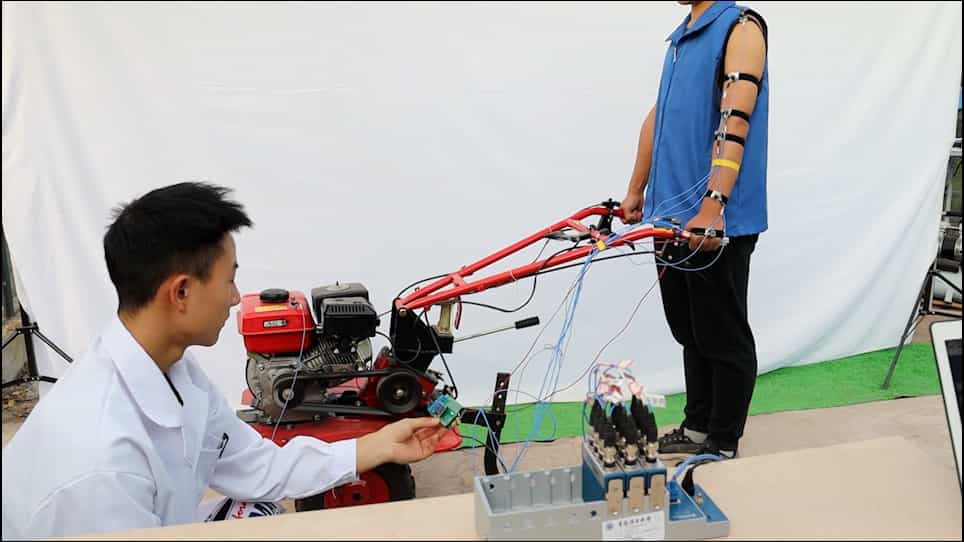
Related Experiment Video
Updated: Aug 21, 2026

Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Ergonomic aspects of five different types of laparoscopic instrument handles under dynamic conditions with respect to
U Matern1, G Kuttler, C Giebmeyer
1Study Group Surgical Technologies, Department of General Surgery, Univ.-Hospital Freiburg, Hugstetter Strasse 55, 79106, Freiburg i.Br., Germany. ulrich.matern@uni-tuebingen.de

Background:
The ergonomic deficiencies of various minimally invasive surgery (MIS) instrument handles are well-known. In the past, many studies have been performed to gain a better understanding of ergonomics in MIS. The current study investigates muscle strain during various dynamic tasks with different instrument handles.
Methods:
Five different handle designs were tested: the axial handle (Aesculap), the vario handle (own model), multifunctional and ring handles (both Karl Storz), and the shank handle (Wilo). Ten subjects without any surgical training tested the following instrument functions: precise dynamic movement, rotation of the closed instrument, and simultaneous opening and closing of the effector. During these three trials, task performance (errors/duration) and the electromyographic activity of the hand and lower arm muscles were measured.
Results:
Regarding the errors and the time required to carry out the tasks, the five handles showed similar results. The muscle activity was lowest for the precise dynamic movement task and highest during the rotation task. The axial handle required significantly more muscle activity than all other handles.
Conclusion:
On the basis of these data, it was possible to construct characteristic muscle activation patterns for each handle. However, these patterns were not task specific. Accordingly, they may form a basis to improve the ergonomics of MIS handles with regard to muscle strain.