Related Experiment Video
Updated: Jul 29, 2026
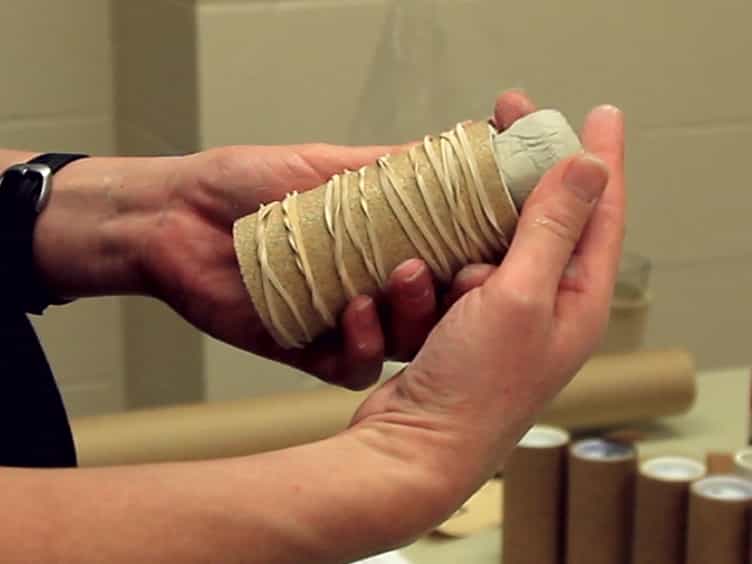

Design, Fabrication, and Administration of the Hand Active Sensation Test (HASTe)
Published on: September 8, 2015
Metamers in the haptic perception of heaviness and moveableness
Kevin Shockley1, Claudia Carello, M T Turvey
1Department of Psychology, University of Cincinnati, Cincinnati, Ohio 45221-0376, USA. kevin.shockley@uc.edu

Abstract:
It is hypothesized that heaviness perception for a freely wielded nonvisible object can be mapped to a point in a three-dimensional heaviness space. The three dimensions are mass, the volume of the inertia ellipsoid, and the symmetry of the inertia ellipsoid. Within this space, particular combinations yield heaviness metamers (objects of different mass that feel equally heavy), whereas other combinations yield analogues to the size-weight illusion (objects of the same mass that feel unequally heavy). Evidence for the two types of combinations was provided by experiments in which participants wielded occluded hand-held objects and estimated the heaviness of the objects relative to a standard. Further experiments with similar procedures showed that metamers of heaviness were metamers of moveableness but not metamers of length. A promising conjecture is that the haptic perceptual system maps the combination of an object's inertia for translation and inertia for rotation to a perception of the object's maneuverability.
Related Concept Videos
 01:33
Somatosensation
 02:26
Responses to Gravity and Touch
 01:01
Weightlessness
 01:28
Apparent Weight and the Earth's Rotation
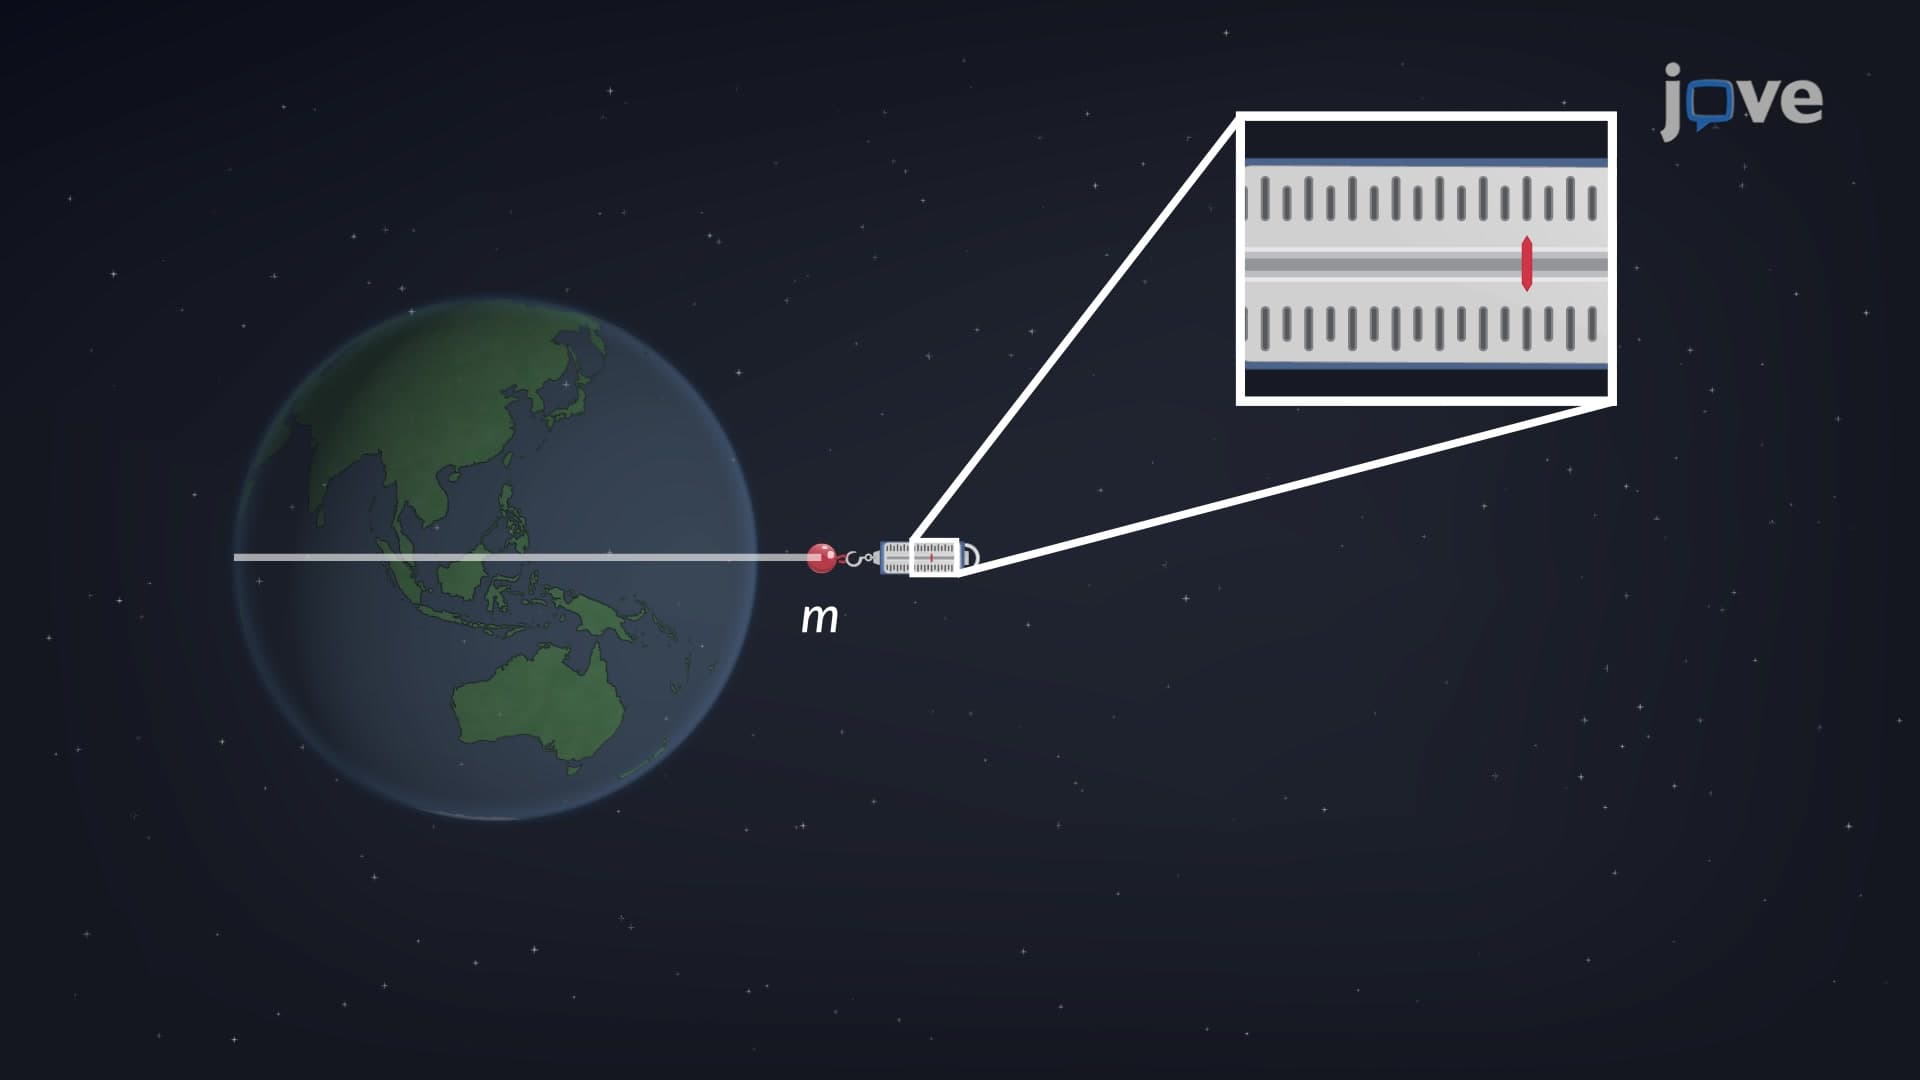
For an object on the Earth's equator, the net centripetal force that accounts for its rotation is the Earth's pull towards its center, or the weight minus the normal force that prevents it from piercing into the Earth's surface. This force,...
 00:55
Composite Bodies
Composite bodies have widespread applications in mechanical engineering, from automobiles to aircraft to rockets. For example, an automobile wheel comprises...
 01:27
Tactile and Chemical Senses