Related Experiment Video
Updated: Jul 12, 2026

Basics of Multivariate Analysis in Neuroimaging Data
Published on: July 25, 2010
Asymptotic biases of the unrotated/rotated solutions in principal component analysis
1Otaru University of Commerce, Midori, Otaru 047-8501, Japan. hogasa@res.otaru-uc.ac.jp

Abstract:
Asymptotic biases of the parameter estimates in principal component analysis with substantial misspecification are derived. The solutions for unstandardized and standardized observed variables are considered with and without orthogonal and oblique rotations. The distribution of observed variables can be non-normal as long as the finite fourth-order moments of the observed variables exist. When multivariate normality holds for the observed variables, substantial reduction of the amount of computation can be achieved. Numerical examples with simulations are given, with some discussion on the tendency of the biases to reduce the absolute values of parameter estimates.

Related Concept Videos
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:14
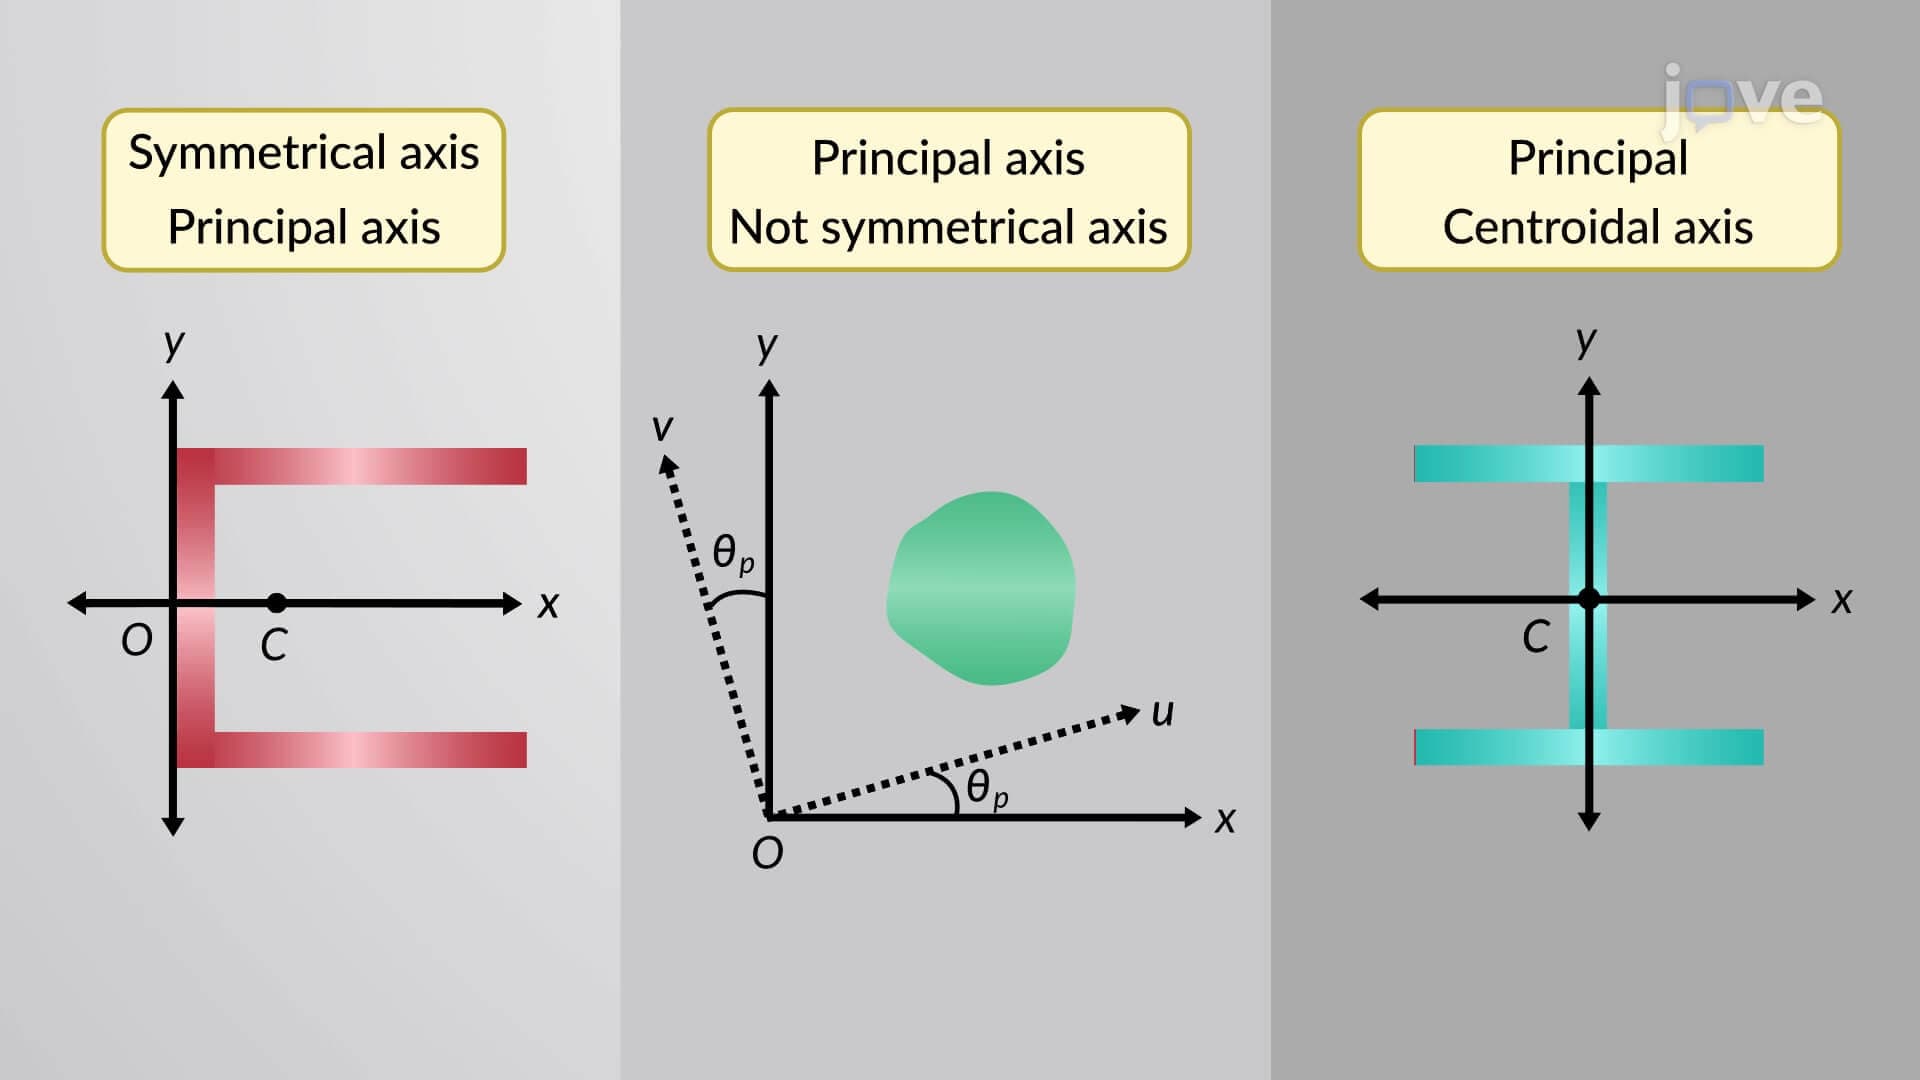
Principal Moments of Area
The principal moment of inertia axes are the...
 01:11
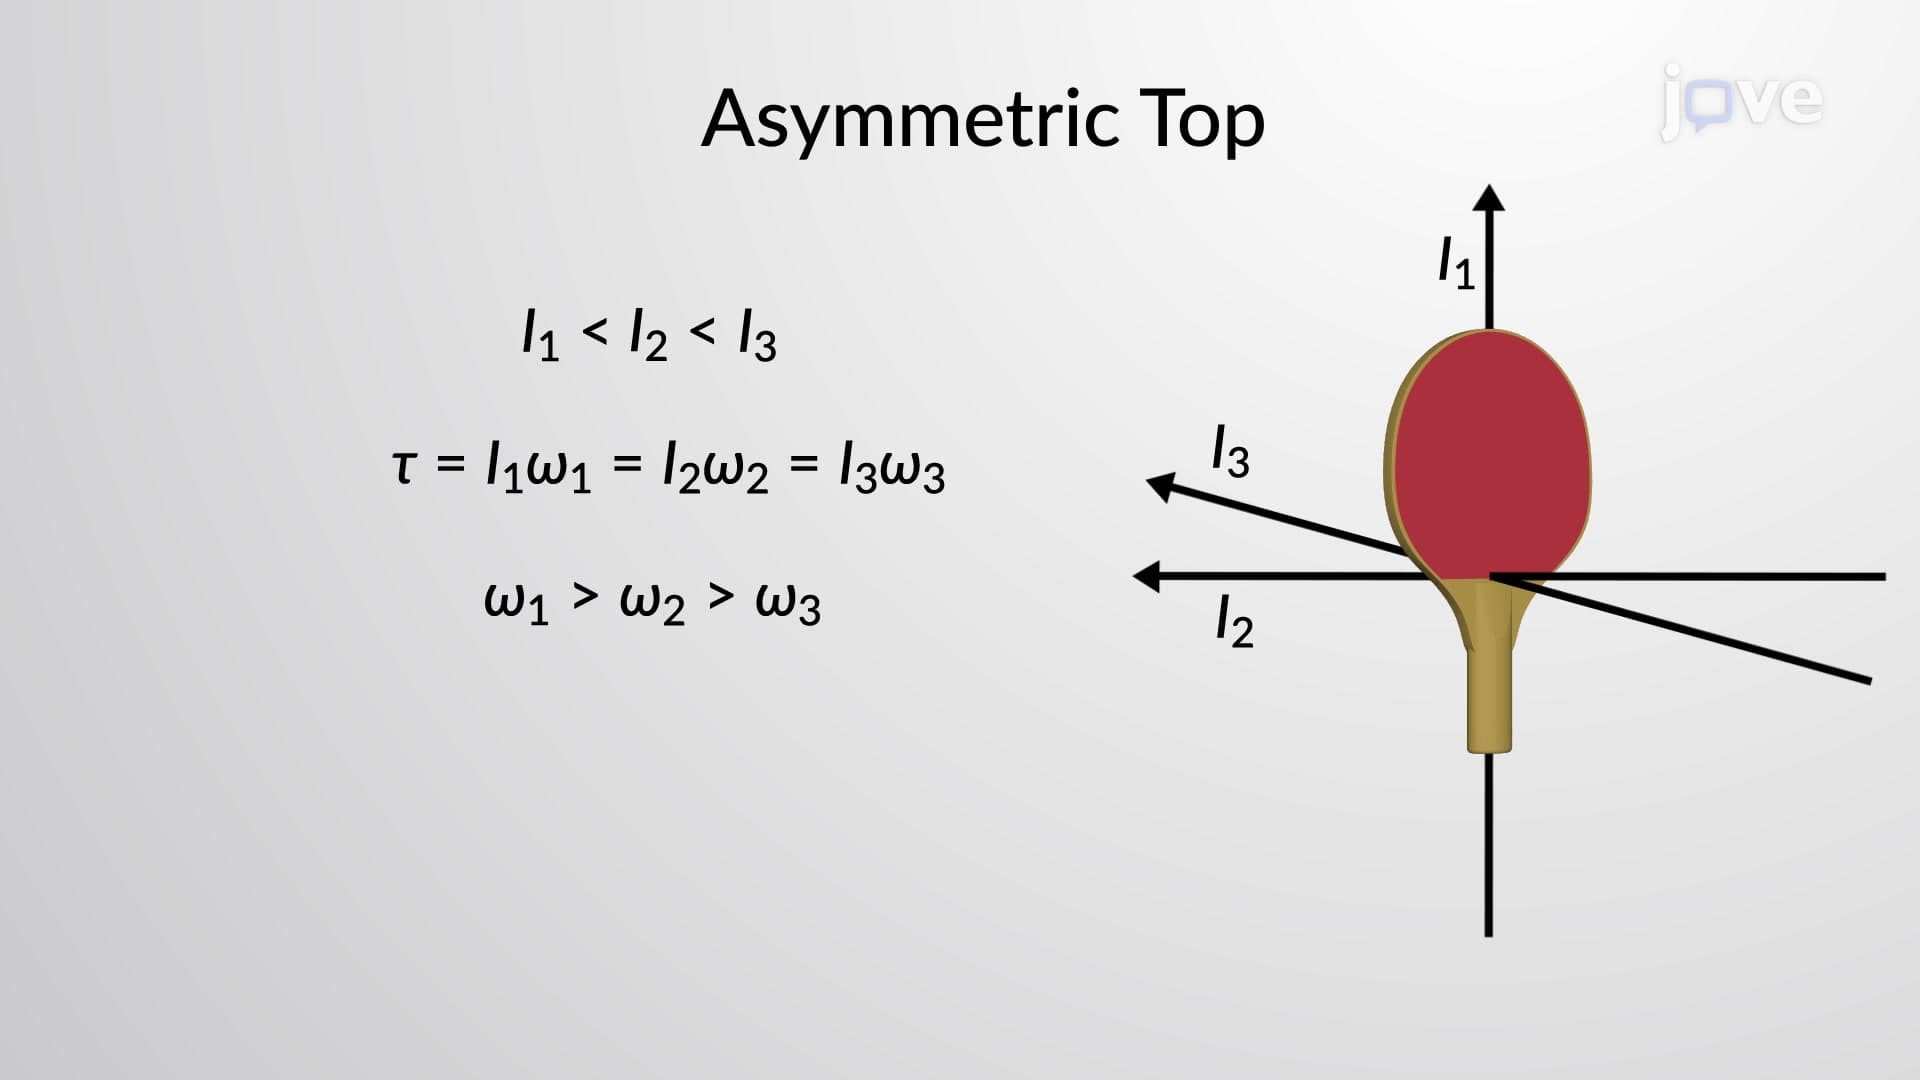
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...