Related Experiment Video
Updated: Aug 21, 2026


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Comparison of some modeling and control issues for a flexible two link manipulator
1Dept. of Mechanical and Aerospace Engineering, University of Missouri, Columbia, Missouri 65211, USA.

Abstract:
The nonlinear dynamics of a flexible two link manipulator presents a challenging modeling and control problem with its lumped actuator dynamics coupled with distributed link dynamics. Issues related to modeling uncertainty and control robustness as well as a good understanding of the experimental issues are essential for advanced modeling and control for such systems. This paper reports some of the advanced modeling, control, and experimental issues for a flexible two link manipulator, including some novel approaches developed by the authors.

Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:23
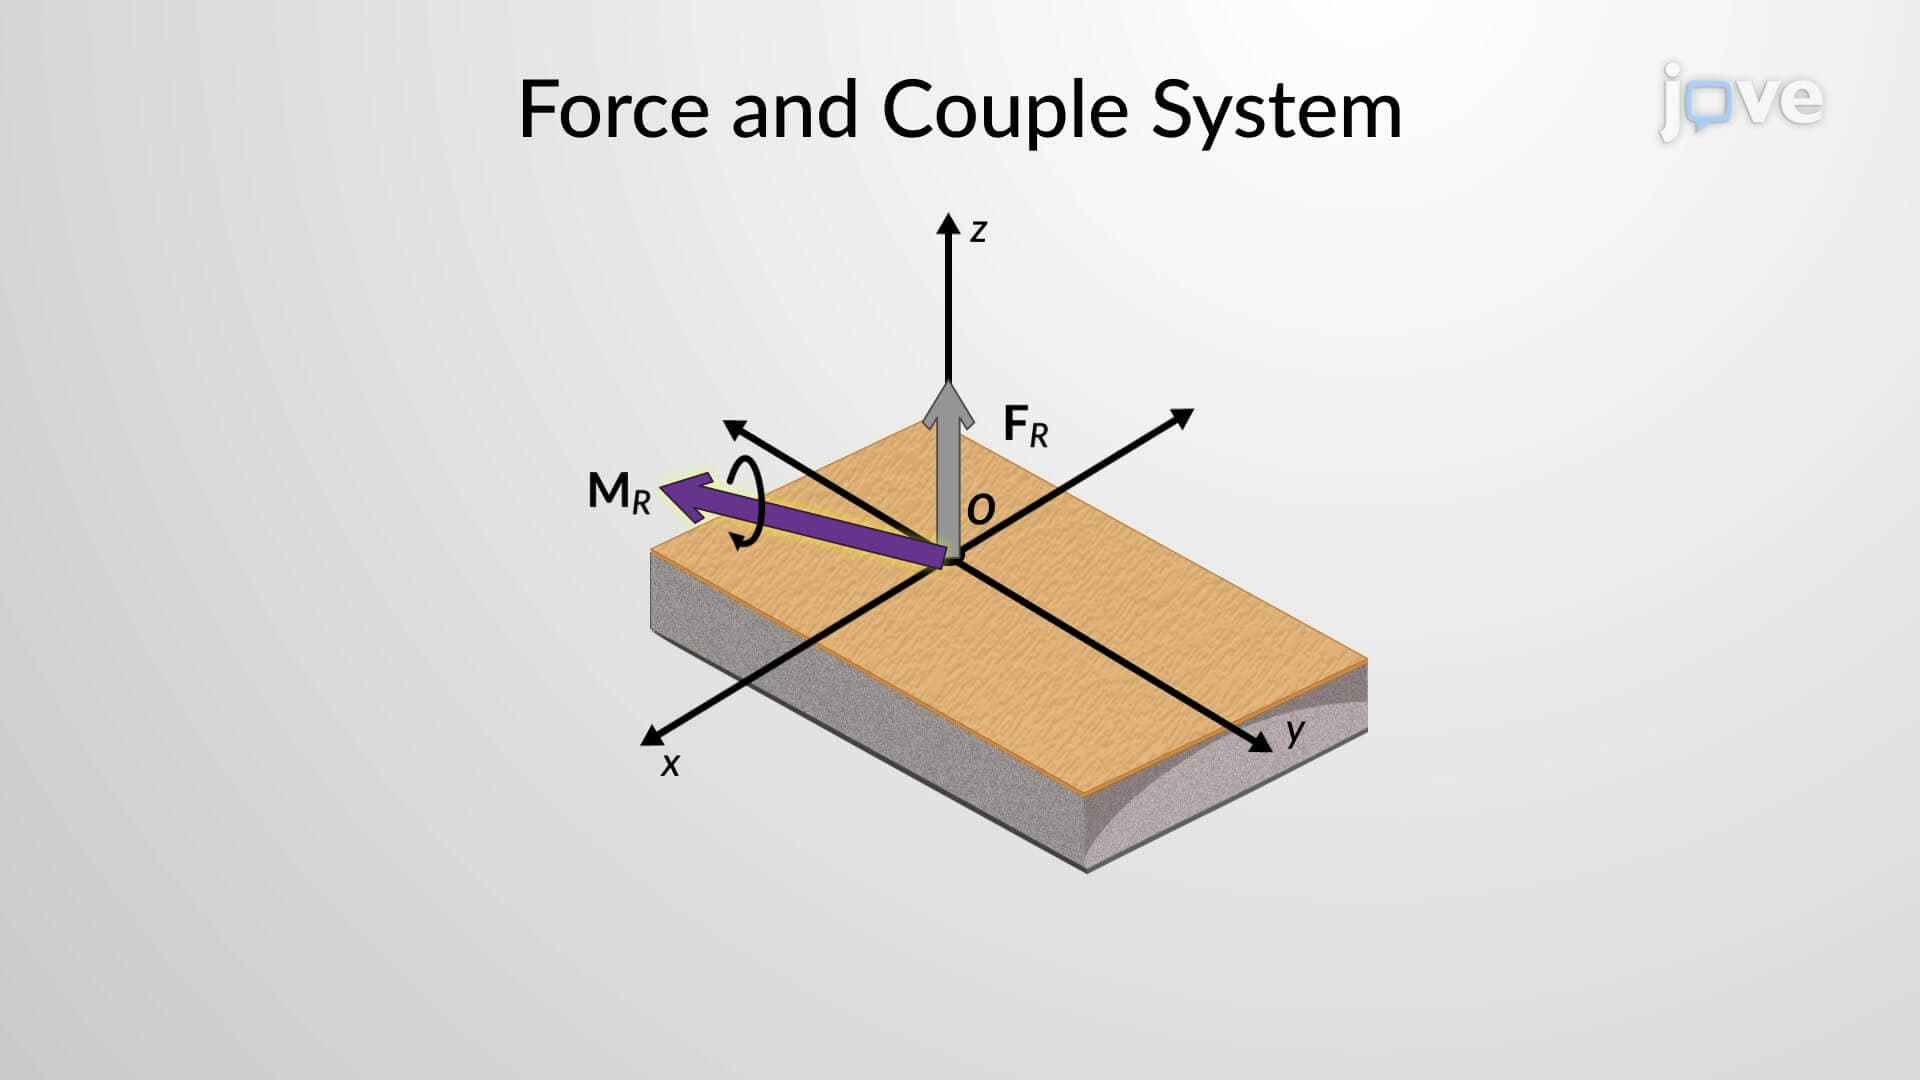
Simplification of a Force and Couple System: II
 01:30
Machines: Problem Solving II
 01:14
Stability of structures
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...