Related Experiment Video
Updated: Aug 21, 2026


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Comparison of two approaches to automated PI controller tuning for an industrial weigh belt feeder
Yanan Zhao1, Emmanuel G Collins
1Department of Mechanical Engineering, Florida A&M University-Florida State University, Tallahassee, Florida 32310, USA. yzhao@eng.fsu.edu

Abstract:
In this paper, two advanced PI controller tuning methods, unfalsified control and fuzzy control, are applied to an industrial weigh belt feeder that has significant nonlinearities. Both methods do not require an explicit plant model. The advantage of the unfalsified PI control design method is that it is able to directly incorporate multiple performance criteria, while the advantage of fuzzy logic is that it is able to directly incorporate human reasoning in the design process. Experimental results exhibit the effectiveness of both control methods. A detailed comparison of the two approaches is given in the areas of allowed design specifications, process knowledge requirements, computational requirements, controller development effort, transient performance, and the ability to handle motor saturation.
Related Concept Videos
 01:24
PI Controller: Design
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:19
PID Controller
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:28
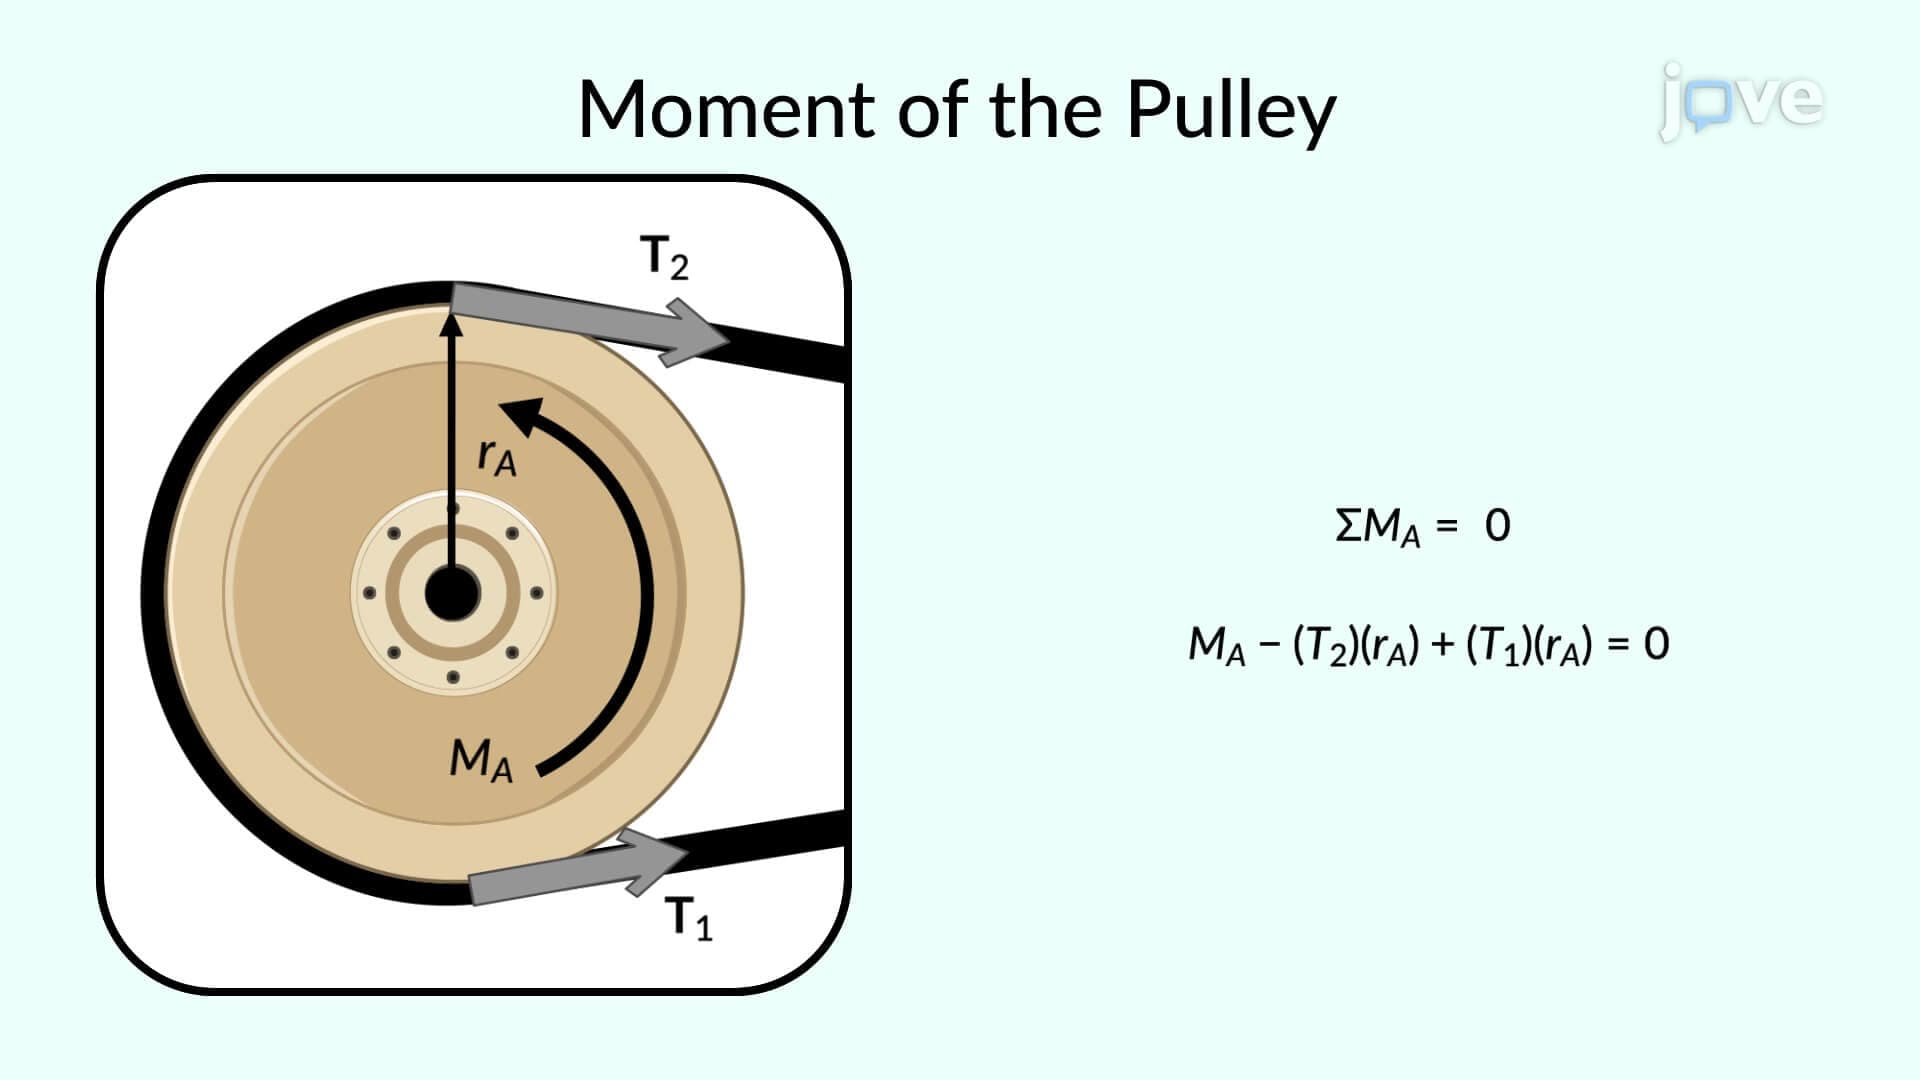
Flat Belts: Problem Solving
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...