Related Experiment Video
Updated: Aug 20, 2026
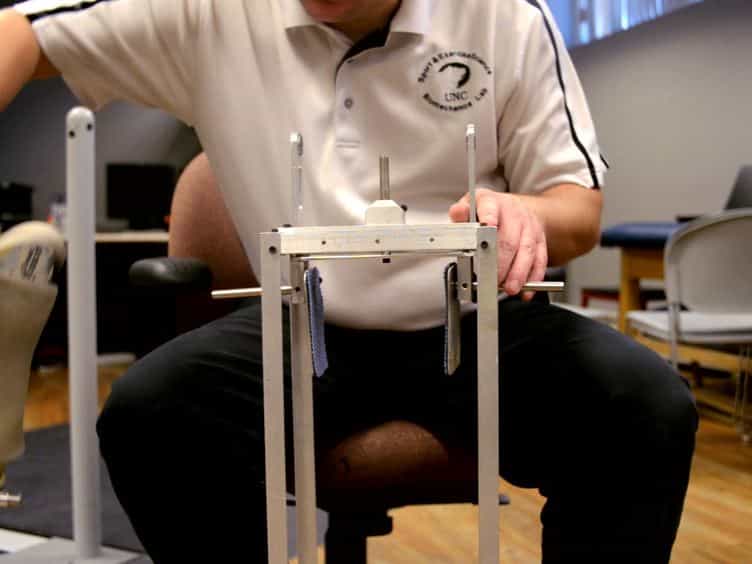
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Adaptations to mass perturbations in transtibial amputees: kinetic or kinematic invariance?
Ruud W Selles1, Johannes B Bussmann, Lisette M Klip
1Department of Rehabilitation Medicine, Erasmus Medical Center Rotterdam, The Netherlands. r.selles@erasmusmc.nl

Objective:
To establish the adaptation strategy transtibial amputees use after mass perturbation of their prosthetic lower leg.
Design:
We investigated whether the measured adaptations to mass perturbation of the lower leg in transtibial amputees can better be described as (1) a kinetic invariance strategy in which kinetics (joint torques) remain the same while kinematics (joint angles) change or (2) a kinematic invariance strategy in which kinematics remain the same while kinetics change.
Setting:
A gait laboratory.
Participants:
Ten transtibial amputees.
Interventions:
Five different mass conditions.
Main Outcome Measures:
Measured joint torques and angles during the swing phase in the different mass conditions.
Results:
Mass perturbation induced more significant changes and larger effect sizes in joint torques than in joint angles.
Conclusions:
Transtibial amputees adapt to mass perturbation primarily by maintaining the same kinematic pattern and adjusting their joint torques, that is, they use a kinematic invariance strategy. This implies that manipulating prosthetic inertial properties does not directly influence gait kinematics and that inertial properties should be evaluated in terms of the energetic cost of the swing phase.

Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...