Related Experiment Video
Updated: Aug 19, 2026


MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Using visual direction in three-dimensional motion perception
1School of Psychology, University of St. Andrews, St. Mary's College, South Street, St. Andrews, Fife, Scotland, KY16 9JP, UK. Julie.Harris@st-andrews.ac.uk

Abstract:
The eyes receive slightly different views of the world, and the differences between their images (binocular disparity) are used to see depth. Several authors have suggested how the brain could exploit this information for three-dimensional (3D) motion perception, but here we consider a simpler strategy. Visual direction is the angle between the direction of an object and the direction that an observer faces. Here we describe human behavioral experiments in which observers use visual direction, rather than binocular information, to estimate an object's 3D motion even though this causes them to make systematic errors. This suggests that recent models of binocular 3D motion perception may not reflect the strategies that human observers actually use.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Vision
 01:25
Relative Motion Analysis using Rotating Axes
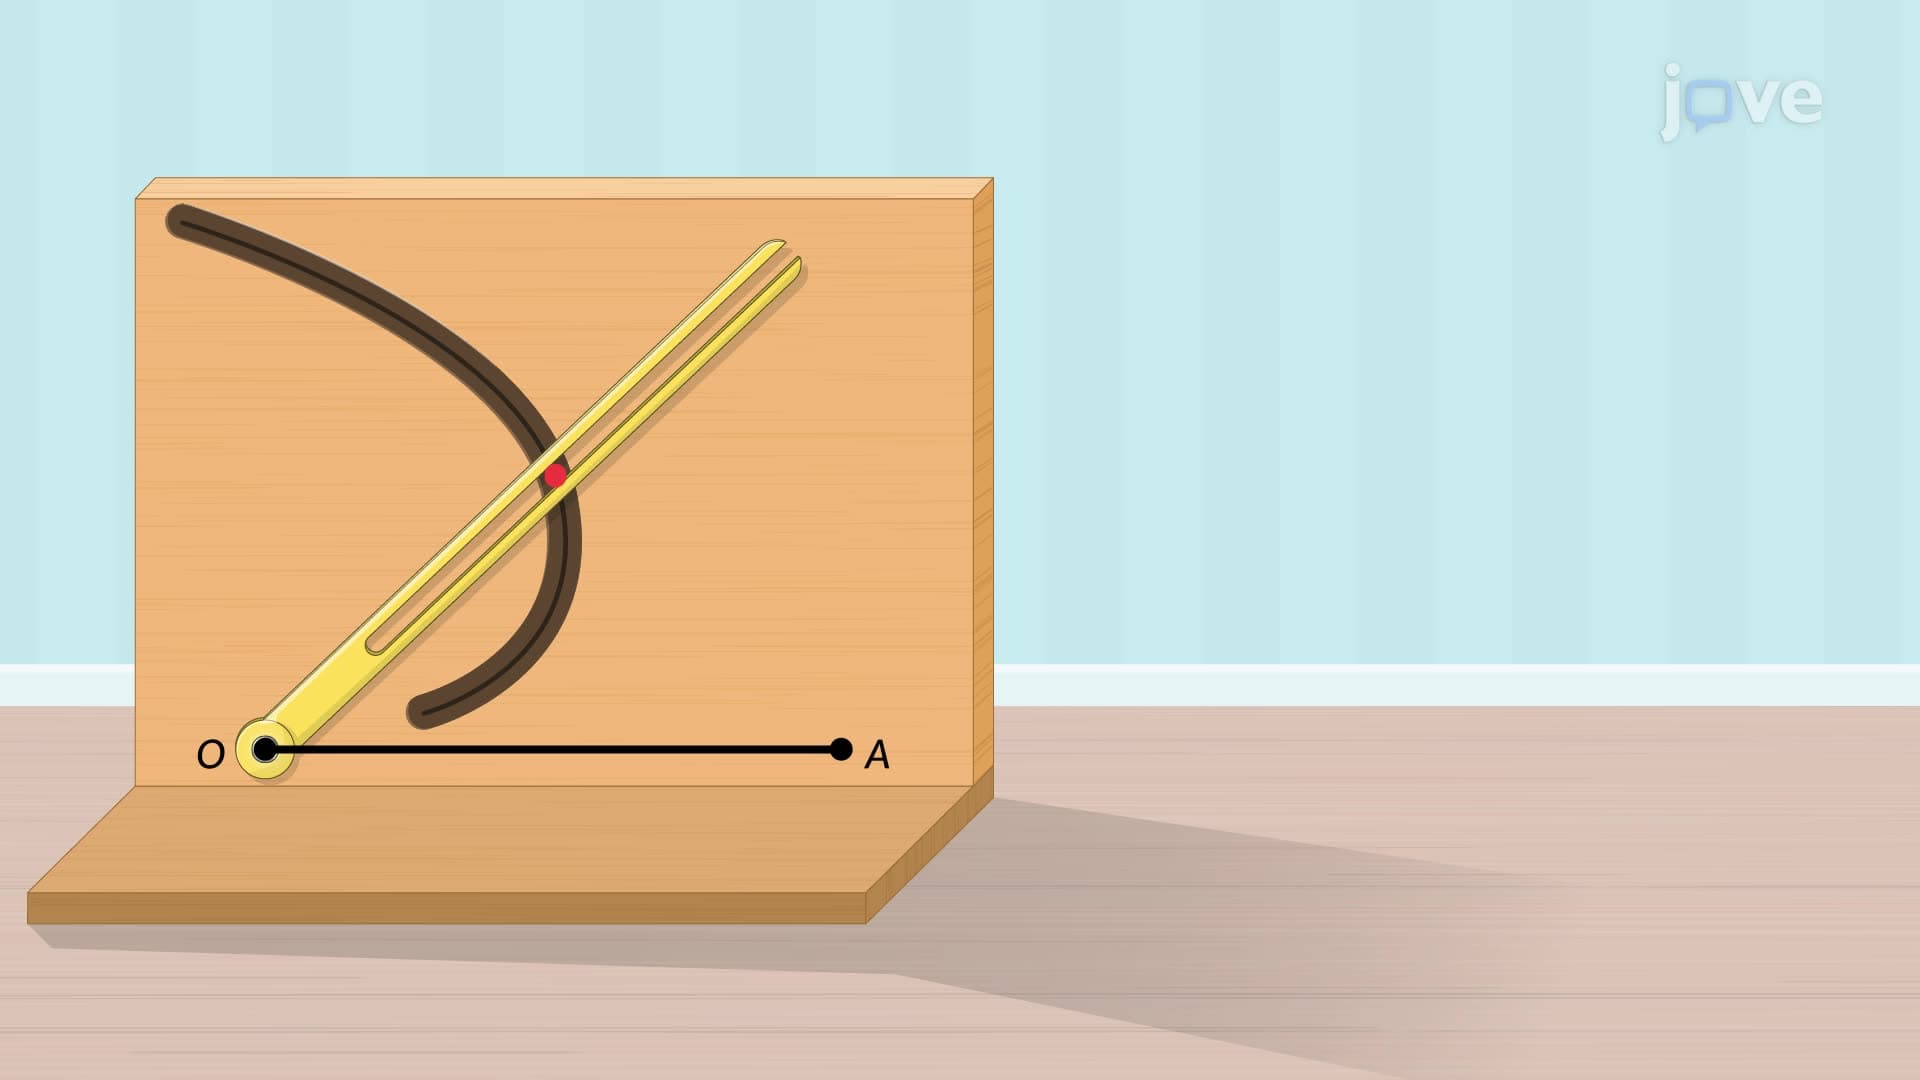
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...