Recursive estimation of 3D motion and surface structure from local affine flow parameters
Related Experiment Video
Updated: Aug 18, 2026
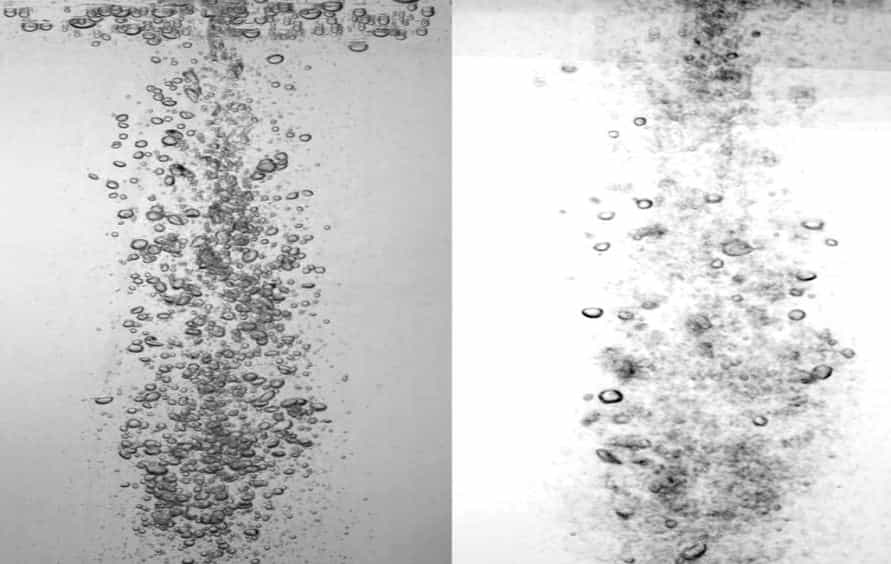
Determining 3D Flow Fields via Multi-camera Light Field Imaging
Published on: March 6, 2013

Abstract:
A recursive structure from motion algorithm based on optical flow measurements taken from an image sequence is described. It provides estimates of surface normals in addition to 3D motion and depth. The measurements are affine motion parameters which approximate the local flow fields associated with near-planar surface patches in the scene. These are integrated over time to give estimates of the 3D parameters using an extended Kalman filter. This also estimates the camera focal length and, so, the 3D estimates are metric. The use of parametric measurements means that the algorithm is computationally less demanding than previous optical flow approaches and the recursive filter builds in a degree of noise robustness. Results of experiments on synthetic and real image sequences demonstrate that the algorithm performs well.
Related Concept Videos
 01:22
Eulerian and Lagrangian Flow Descriptions
The Eulerian method focuses on fixed points in space where fluid properties, such as velocity, pressure, and temperature, are observed as the fluid moves between these...
 01:30
Vector Functions and Motion: Problem Solving
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:29
Application of Linearization and Approximation
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...