Related Experiment Video
Updated: Aug 18, 2026
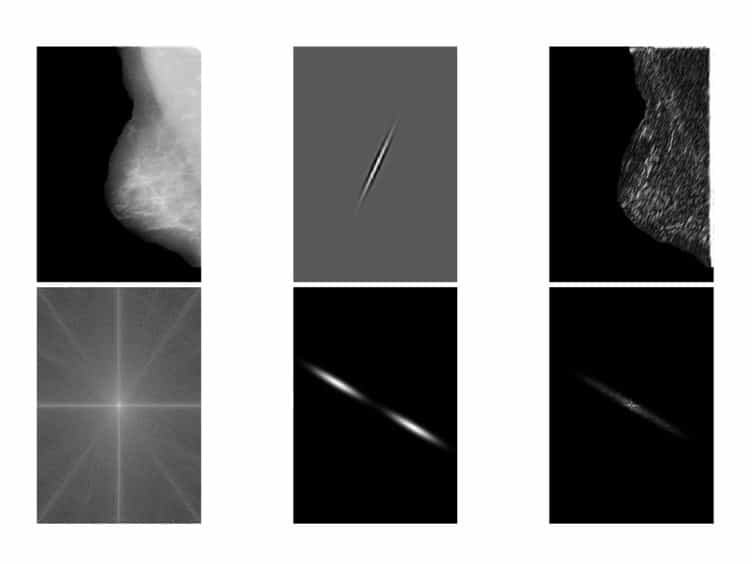
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
The influence of spatial and temporal noise on the detection of first-order and second-order orientation and motion
Timothy Ledgeway1, Claire V Hutchinson
1School of Psychology, University of Nottingham, University Park, UK. txl@psychology.nottingham.ac.uk

Abstract:
Thresholds for identifying the direction of second-order motion (contrast-modulated dynamic noise) are consistently higher than those for identifying spatial orientation, unlike first-order gratings for which the two thresholds are typically the same. Two explanations of this phenomenon have been proposed: either first-order and second-order patterns are encoded by separate mechanisms with different properties, or dynamic noise selectively impairs ("masks") sensitivity to second-order motion direction but not orientation. The former predicts the two thresholds should remain distinct for second-order patterns, irrespective of the temporal structure (static vs. dynamic) of the noise carrier. The latter predicts direction thresholds should be higher than orientation thresholds, for both second-order and first-order motion patterns, when dynamic (but not static) noise is present. To resolve this issue we measured direction and orientation thresholds for first-order (luminance) and second-order (contrast or polarity) modulations of static or dynamic noise. Results were decisive: The two thresholds were invariably the same for first-order stimuli but markedly different (direction thresholds approximately 50% higher) for second-order stimuli, regardless of the temporal properties (static or dynamic) and the overall contrast of the noise, or the drift temporal frequency of the envelope. This suggests that first-order and second-order motion are encoded separately and that the mechanisms encoding second-order stimuli cannot determine direction at the absolute threshold for spatial form.
More Related Videos
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:02
¹H NMR: Interpreting Distorted and Overlapping Signals
As Δν decreases and the signals move closer, the doublets appear increasingly distorted. The intensities of the inner lines increase at the cost of those of the outer lines as the signals are slanted or...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
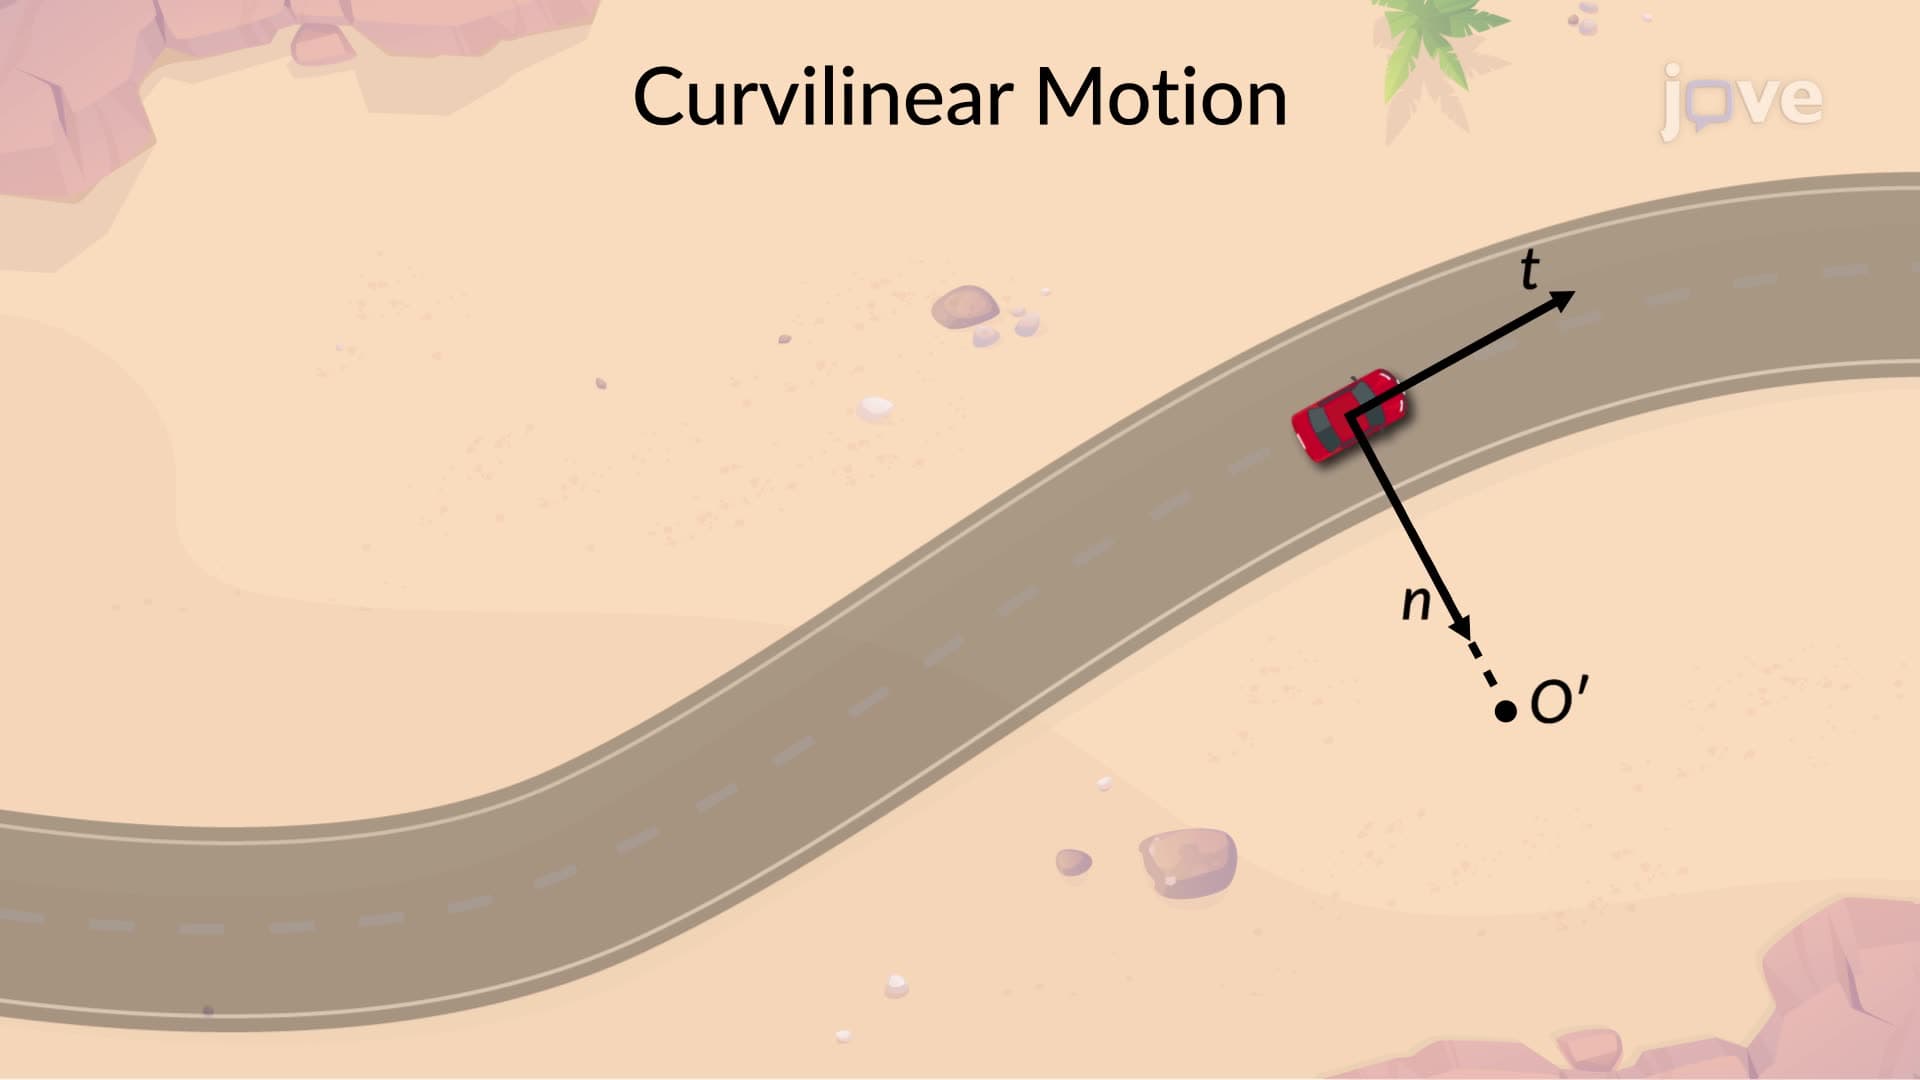 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...